-
Datei
gaak02.bas
Impuls ist da 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „Status abfragen, bevor es ins Hauptprogramm geht / BASCOM“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Merker.1 'Merker, Blinker ist an 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „Status abfragen, bevor es ins Hauptprogramm geht / BASCOM“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak02.bas
Impuls ist da 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „Ich verstehe den Timer0 beim ATtiny 13 nicht.“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Merker.1 'Merker, Blinker ist an 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „Ich verstehe den Timer0 beim ATtiny 13 nicht.“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak02.bas
Impuls ist da 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „RC Kanal auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Merker.1 'Merker, Blinker ist an 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „Probleme Bascom Servo Steuerung / Kanalauswertung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
ms5611.c
) - off) >> 15; // off = (((int64_t)MS5611_CAL_OFF) * 65536) + ((((int64_t)MS5611_CAL_TCO) * dT) / 128); // sens = (MS5611_CAL_SENS * 32768) + (MS5611_CAL_TCS * dT / 256); // pres = (((raw * sens) / 2097152) - off) / 32768; #ifdef MS5611_DEBUG uart_printf("ms5611_get_pressure() : raw=%l off=%l sens=%
in „Hilfe beim Auslesen eines Sensors“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak02.bas
Impuls ist da 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „RC-Empfänger auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Merker.1 'Merker, Blinker ist an 'Programmstart, Reset-Routine: 'Tiny13 auf 4,8 MHz umschalten: Clkpr = 128 'Taktvorteiler Schreibschutz aufheben Clkpr = 1 'Taktvorteiler auf 1:2 Clkpr = 1 'einstellen 'PB1 (Pin 6) wird der Impulseingang, alles andere werden Ausgänge Portb = &B00010 'Ports erstmal auf L-Pegel
in „RC-Empfänger auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
schematic.pdf
C 1 1 t L 4 2 2 3 1 2 5 10k F IC6 GND 2 1 2 0 20 44 5 R5 C 2 RESET (AD7)PA7 45 100 D 2 23 (AD6)PA6 46 A LAP4-TOP OK1 V F z XTAL2 (AD5)PA5 47 0 3R37 o 1,2k LED6 5 GND 4 p H (AD4)PA4 7 R v 1 18 6 C 21 1 0 24 XTAL1
in „Finde Packages von Eagle nicht beim Bestellen“ · Platinen ·
-
PDF
schematic.pdf
C 1 1 t L 4 2 2 3 1 2 5 10k F IC6 GND 2 1 2 0 20 44 5 R5 C 2 RESET (AD7)PA7 45 100 D 2 23 (AD6)PA6 46 A LAP4-TOP OK1 V F z XTAL2 (AD5)PA5 47 0 3R37 o 1,2k LED6 5 GND 4 p H (AD4)PA4 7 R v 1 18 6 C 21 1 0 24 XTAL1
in „Schematic + Board“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
via_datasheet.pdf
GP14/GPY2 124 43 SLIN# GP13/GPX2 125 42 PD0 GP12/GPX1 126 41 PD1 GP11/GPSB1 127 40 PD2 GP10/GPSA1 128 1 2 3 4 5 6 7 8 9 1 1 1 1 1 1 1 1 1 1 2 2 2 2 2 2 2 2 2 2 3 3 3 3 3 3 3 3 3 PD3 ) ) N K X A T A T R P D E C0 P A D G L E S L Q Q D D D D C ET C P S K D D D D E C E O V S U D E W W VA W T A H C S V I
-
Datei
uart.txt
V1.24.8d Professional Automatic Program Generator © Copyright 1998-2006 Pavel Haiduc, HP InfoTech s.r.l. http://www.hpinfotech.com Project : Version : Date : 09.08.2007 Author : F4CG Company : F4CG Comments: Chip type : ATmega8535 Program type : Application Clock frequency : 8,000000 MHz Memory model : Small External SRAM size : 0 Data Stack size : 128 *****************************************************/ #include <mega8535.h> #include <stdio.h> #include <lcd.h> #define xtal 8000000L #define baud 9600 typedef unsigned char byte; /* table for the
in „UART Senden und empfangen“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
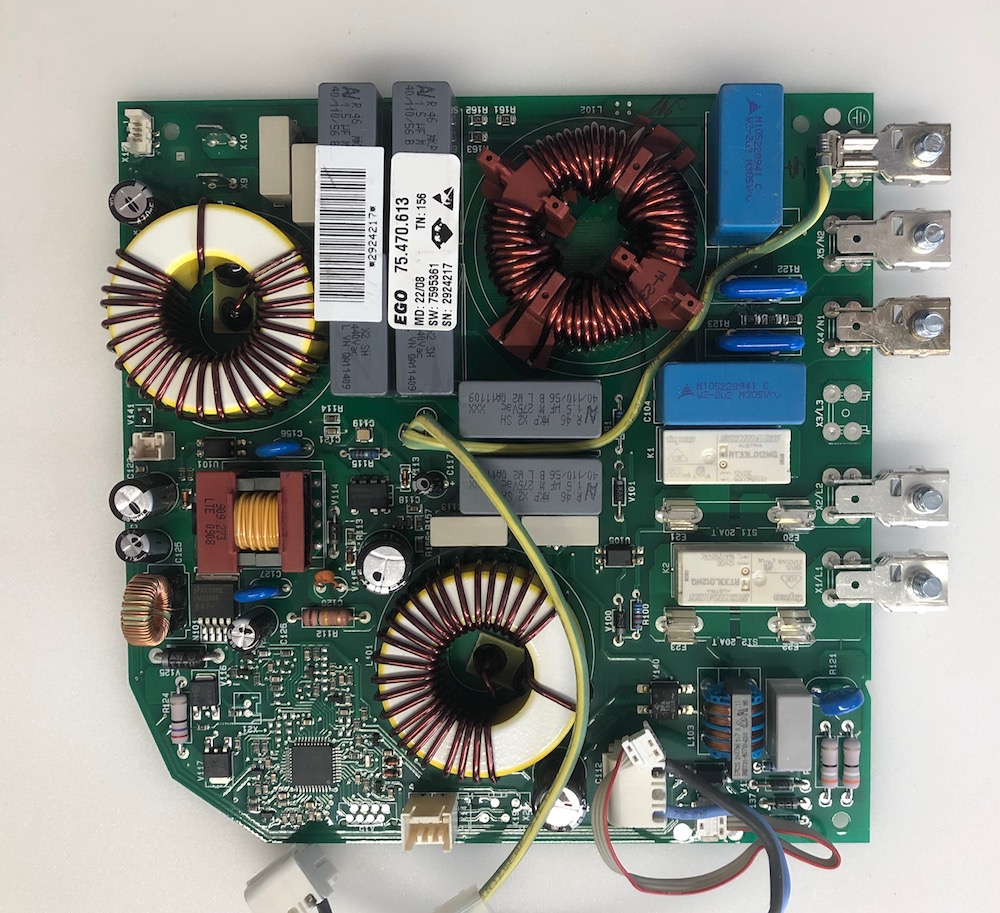
Bestückte Leiterplatte eines Netzteils
EGO 75.470.613 HD 22/08 SW 2924217 TN 156 R181 R182 L102 L103 R122 R103 R101 R102 R112 R113 R114 R115 R116 R117 R118 R119 R120 R121 R123 R124 R125 R126 R127 R128 R129 R130 R131 R132 R133 R134 R135 R136 R137 R138 R139 R140 R141 R142 R143 R144 R145 R146 R147
in „EGO Herdplatte defekt“ · Analoge Elektronik und Schaltungstechnik · · Platinenfotos
-
PDF
700185_wiesmeier_christoph_2016.pdf
C C 6 D 2 7 2 C1 R173 01D 2 u U R B 8 CR63 SAMPLE 0 9 W 2F I 270 R105 VP C 1 AIN 4 270 R173 S 1 3 L 22 0 1 F C1 L 100 U 5 0 0 LOG 270 R105U VP C C 21 AIN L3 4.7u 1uF 2 1U$5 F B$4 _ C31 22 100n C18 3 L 9 2 L 100 3T023SRBM4D 270 C14 D P 1 L 12 /9 <=1u 12 20 5 T D3 T W 2 C18 9 (10u/33u)/2A 1 k 1 0 2 910
in „2A 1s Li-ion Lader + Protection“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
mci.h
/*---------------------------------------------------------------------------- * R T L - F l a s h F i l e S y s t e m *---------------------------------------------------------------------------- * Name: MCI_LPC23XX.H * Purpose: Multimedia Card Interface Driver for LPC23xx definitions
in „NXP verschenkt ARM-Chips“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
_BV(PB5)); // use PD1 as SS //DDRD |= _BV(PD1); // enable spi, set as master, scale sck freq with 128 SPCR |= (_BV(SPE) | _BV(MSTR) | _BV(SPR1) | _BV(SPR0)); } uint8_t SPIWrite8(uint8_t data) { SPDR = data; while(!(SPSR & (1<<SPIF))); return SPDR; } uint8_t SPIRead8(void) { SPDR = 0x00; while(!(SPSR
in „AD7793 Single Conversion Mode“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
dc_motor_l6203.c
bidirektional mit Poti Ein ATtiny25 steuert mit seinen PWM-Ausgaengen OC0A+OC0B einen H-Brueckentreiber (hier L6203 IN1+IN2) an und bestimmt damit die Drehzahl und Drehrichtung. Letztgenannte werden per Poti vorgegeben, wobei die Mittenstellung den Motor stoppt und Rechts- oder Linksdrehung eine proportionale
in „Drehzahlregler für DC-Motor, ATmega48-328“ · Projekte & Code ·
-
Datei
diamex-timeouts.txt
root@home2l:/ # avrdude -c stk500v2 -p t85 -P /dev/cuau1 -t -v -i 10 avrdude: Version 6.4 Copyright (c) Brian Dean, http://www.bdmicro.com/ Copyright (c) Joerg Wunsch System wide configuration file is "/usr/local
in „DIAMEX-AVR-USB timeouts mit avrdude auf FreeBSD“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ds1879a.pdf
VDDA = 5.0 V ± 5%; TA = 25 °C) Pins Parameter Min Typ Max Units CMR Reference voltage 2.25 volts LINE_L, LINE_R, Input impedance 30k 70k 100k AUXA_L, AUXA_R, AUXB_L, AUXB_R, MIC CIN_L, CIN_R 35k 50k 65k FDXI 30k 70k 100k FOUT_L, FOUT_R Output impedance 3.5k 5k 6.5k AOUT_L, 10k 10k AOUT_R max load for full-scale
in „Informationen über ISA-Karten“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
RTD2660-Board.pdf
D D D D D D N N N N N N U U U U U U M I P 3 5 4 P 1 2 / M T T G G // D E R E R E R E G R G R G R B L B L B L P G G [ [ N / GND VO 0 W 4 3 S K D / A / A / A / A / A / A / A / A / A O ] 3 N O O 1 电电电电 C3 C10 [ / M M D C 0 1 2 3 4 5 6 7 I O I O I O I O I O I [P] C T T ] LM1117-3.3 N I WW D E E E E E D
in „Parallel RGB Frequenz/Einzelbild?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
tFXKSKyORc24h2V2.pdf
3 4 4 D D D D D 2 P --> 2 P SLICER 2 P 2 P 2 P PITCH BEND+ 2 0 7 0 2 0 FLIP REC. 7 0 CENSOR 1 0 1 D128 1 1 D133 1 1 D138 1 1 D143 1 1 D147 1 1 K RP25 K RP26 K 7 S 0 S 0 S 0 S 0 S 0 L P0RP2501 P10K2502 L P0RP2601 P10K2602 L P KR0 1SS355 1 P 1SS355 1 P 1SS355 1 P 1SS355 1 P 1SS355 1 P L L L 0 N0KR0 1 6
in „Risiko | Nicht?“ · Offtopic ·
-
PDF
STM8_Programming_Manual.pdf
64 DIV LS 22x64/f - 2 x128/f 2 ms - 4 ms 0100 2 x APR /f 32 to 64 DIV LS 23x64/f - 2 x128/f 4 ms - 8 ms 0101 2 x APR /f 32 to 64 DIV LS 2 x64/f - 2 x128/f 8 ms - 16 ms 0110 2 x APR /f 32 to 64 DIV LS 25x64/f - 2 x128/f 16 ms - 32 ms 0111 2 x APR DIV LS 32 to 64 26x64/f - 2 x128/f 32 ms - 64 ms 1000 2 x APR DIV LS 32 to 64 2 x64/f - 2 x128/f 64 ms - 128 ms 1001 2 x APR DIV LS 32 to 64 28x64/f - 2 x128/f 128 ms - 256 ms 1010 2 x APR DIV LS 32 to 64 29x64/f - 2 x128/f 256 ms
in „STLINK V2 und China Boards“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
definition_tn2313.txt
xml ********** ;************************************************************************* ;* A P P L I C A T I O N N O T E F O R T H E A V R F A M I L Y ;* ;* Number : AVR000 ;* File Name : "tn2313def.inc" ;* Title : Register/Bit Definitions for the ATtiny2313 ;* Date : 2005-01-11 ;* Version : 2.14
in „Attiny2313 programmieren“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
tn2313def.inc
xml ********** ;************************************************************************* ;* A P P L I C A T I O N N O T E F O R T H E A V R F A M I L Y ;* ;* Number : AVR000 ;* File Name : "tn2313def.inc" ;* Title : Register/Bit Definitions for the ATtiny2313 ;* Date : 2010-08-20 ;* Version : 2.35
in „Welche .def ist die richtige?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
tn2313def.inc
xml ********** ;************************************************************************* ;* A P P L I C A T I O N N O T E F O R T H E A V R F A M I L Y ;* ;* Number : AVR000 ;* File Name : "tn2313def.inc" ;* Title : Register/Bit Definitions for the ATtiny2313 ;* Date : 2005-10-01 ;* Version : 2.20
in „AVR000: Register and Bit-Name Definitions“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
tn2313def.inc
xml ********** ;************************************************************************* ;* A P P L I C A T I O N N O T E F O R T H E A V R F A M I L Y ;* ;* Number : AVR000 ;* File Name : "tn2313def.inc" ;* Title : Register/Bit Definitions for the ATtiny2313 ;* Date : 2005-11-04 ;* Version : 2.21
in „ATTINY2313 16Mhz“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
hardware_t.cpp
(int lX = BOTT_PLANE_MIN; lX < BOTT_PLANE_MAX; lX++) { UI_Plane1[lX] = *(UI_Plane1_Flash + lX); Buffer_UI2Plane[lX] = 0; UI_Plane2[lX] = 0; UI_Plane3[lX] = 0xFFFFFFFF; UI_Plane4[lX] = 0; UI_Plane5[lX] = 0;
in „Wittig(welec) DSO W20xxA Open Source Firmware (Teil4)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.c
UART0_CONTROLC UCSR0C #define UART0_DATA UDR0 #define UART0_UDRIE UDRIE0 #define UART0_UBRRL UBRR0L #define UART0_UBRRH UBRR0H #define UART0_BIT_URSEL URSEL0 #define UART0_BIT_U2X U2X0 #define UART0_BIT_RXCIE RXCIE0 #define UART0_BIT_RXEN RXEN0 #define UART0_BIT_TXEN TXEN0 #define UART0_BIT_UCSZ0 UCSZ00
in „Timerberechnung die hunderste“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.c
UART0_CONTROLC UCSR0C #define UART0_DATA UDR0 #define UART0_UDRIE UDRIE0 #define UART0_UBRRL UBRR0L #define UART0_UBRRH UBRR0H #define UART0_BIT_URSEL URSEL0 #define UART0_BIT_U2X U2X0 #define UART0_BIT_RXCIE RXCIE0 #define UART0_BIT_RXEN RXEN0 #define UART0_BIT_TXEN TXEN0 #define UART0_BIT_UCSZ0 UCSZ00
in „Fehler beim kompilieren des Bootloadertoutorials in C“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.c
UART0_CONTROLC UCSR0C #define UART0_DATA UDR0 #define UART0_UDRIE UDRIE0 #define UART0_UBRRL UBRR0L #define UART0_UBRRH UBRR0H #define UART0_BIT_URSEL URSEL0 #define UART0_BIT_U2X U2X0 #define UART0_BIT_RXCIE RXCIE0 #define UART0_BIT_RXEN RXEN0 #define UART0_BIT_TXEN TXEN0 #define UART0_BIT_UCSZ0 UCSZ00
in „Wie macht man solche Lichtmodes? Lauflicht, PWM und Co“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
R8C22-23_Group_Hardware_Manual.pdf
Page 81 of 501 REJ09B0251-0200 R8C/22 Group, R8C/23 Group 10. Clock Generation Circuit 10.3.8 fOCO128 fOCO128 is generated by fOCO divided-by-128. The clock fOCO128 is used for capture signal of timer RD (channel 0). Rev.2.00 Aug 20, 2008 Page 82 of 501 REJ09B0251-0200 R8C/22 Group, R8C/23 Group 10.
in „Fragen zu Renesas µC (R5F2122CKFP)“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
datasheet_1_.pdf
C A7 A6 A5 A4 A3 A2 A1 A0 REG[0Bh] bits 7-0 P1 A15 A14 A13 A12 A11 A10 A9 A8 REG[0Ch] bits 7-0 P2 L7 L6 L5 L4 L3 L2 L1 L0 REG[0Dh] bits 7-0 P3 A7 A6 A5 A4 A3 A2 A1 A0 REG[0Eh] bits 7-0 P4 A15 A14 A13 A12 A11 A10 A9 A8 REG[0Fh] bits 7-0 P5 L7 L6 L5 L4 L3 L2 L1 L0 REG[10h] bits 7-0 P6 A7 A6 A5 A4 A3
in „Display Ansteuerung mit Epsonlohnenswert oder zu aufwendig?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
s1d13700.pdf
C A7 A6 A5 A4 A3 A2 A1 A0 REG[0Bh] bits 7-0 P1 A15 A14 A13 A12 A11 A10 A9 A8 REG[0Ch] bits 7-0 P2 L7 L6 L5 L4 L3 L2 L1 L0 REG[0Dh] bits 7-0 P3 A7 A6 A5 A4 A3 A2 A1 A0 REG[0Eh] bits 7-0 P4 A15 A14 A13 A12 A11 A10 A9 A8 REG[0Fh] bits 7-0 P5 L7 L6 L5 L4 L3 L2 L1 L0 REG[10h] bits 7-0 P6 A7 A6 A5 A4 A3
in „Quarz für S1D13700“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
RP6RobotBaseLib.h
MC_IDLE 0 #define MC_MOVEDIST_R 1 #define MC_MOVEDIST_L 2 #define MC_ROTATE 4 #define MC_CHANGE_DIR_R 32 #define MC_CHANGE_DIR_L 64 void setMotorDir(uint8_t left_dir, uint8_t right_dir); /** * These Macros return the current direction value. * They return
in „PIC < > AVR (mit IIC)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
zl_step, max_step=23; u8 fb_color_mnu=0; v u8 wert_x=30; #define u_set_h OCR0B=pwm_wert #define u_set_l OCR0A=pwm_wert #define u_set_z OCR0A=255;OCR0B=255 #define v_set_h OCR1B=pwm_wert #define v_set_l OCR1A=pwm_wert #define v_set_z OCR1A=255;OCR1B=255 #define w_set_h OCR2B=pwm_wert #define w_set_l OCR2A
in „BLDC Ansteuerung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
timer.txt
V1.24.8d Professional Automatic Program Generator © Copyright 1998-2006 Pavel Haiduc, HP InfoTech s.r.l. http://www.hpinfotech.com Project : Version : Date : 02.08.2007 Author : F4CG Company : F4CG Comments: Chip type : ATmega8535 Program type : Application Clock frequency : 8,000000 MHz Memory model : Small External SRAM size : 0 Data Stack size : 128 *****************************************************/ #define xtal 8000000L #asm .equ __lcd_port=0x15 //Port #endasm #include <lcd.h> #include <mega8535.h> #include <stdlib.h> typedef unsigned char
in „sekundenzähler mit timer“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
08_wie_testprog.c
output PR2 = 0b01111100 ; T2CON = 0b00000101 ; CCP1CON = 0b00001100 ; CCP2CON = 0b00111100 ; CCPR1L = 0 ; //Minimum CCPR2L = 128 ; //Minimum } //Pild_PIC_7 fTON(void) { for(int i=200;i>0;i--) { //Akustik Laut=1; fDelay_us(150); Laut =0; fDelay_us(150); } } main(void) { fPortinitialisierung(); fTON(
in „PIC ignoriert endlosschleife“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
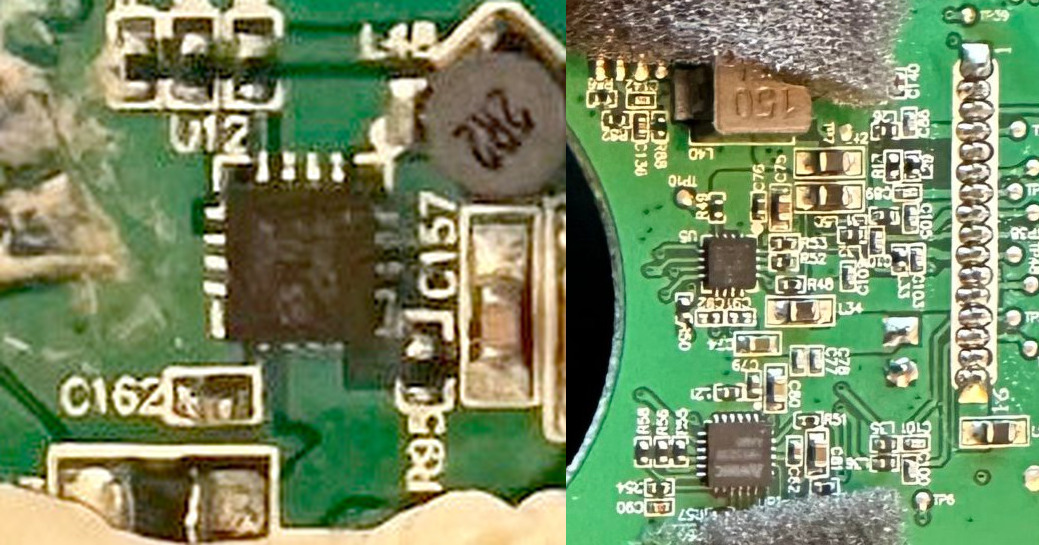
Makroaufnahme einer Leiterplatte mit elektronischen Bauteilen
U12 L4B 2R2 C157 R95 C162 150 L40 C76 R48 C101 C102 C103 C104 C105 C106 C107 C108 C109 C110 C111 C112 C113 C114 C115 C116 C117 C118 C119 C120 C121 C122 C123 C124 C125 C126 C127 C128 C129 C130 C131 C132 C133
in „Bang & Olufsen Beoplay A2 Bauteil identifizieren“ · Analoge Elektronik und Schaltungstechnik · · Platinenfotos
-
Datei
avr200.asm
multiplies signed the two register variables mp8s and ;* mc8s. The result is placed in registers m8sH, m8sL ;* The routine is an implementation of Booth's algorithm. If all 16 bits ;* in the result are needed, avoid calling the routine with ;* -128 ($80) as multiplicand ;* ;* Number of words :10 + return ;
in „Suche Routine zum Dividieren zweier 16 Bit Zahlen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Avr200.asm
multiplies signed the two register variables mp8s and ;* mc8s. The result is placed in registers m8sH, m8sL ;* The routine is an implementation of Booth's algorithm. If all 16 bits ;* in the result are needed, avoid calling the routine with ;* -128 ($80) as multiplicand ;* ;* Number of words :10 + return ;
in „16 Bit Zahl am LCD in decimal Form ausgeben“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
avr200.asm
multiplies signed the two register variables mp8s and ;* mc8s. The result is placed in registers m8sH, m8sL ;* The routine is an implementation of Booth's algorithm. If all 16 bits ;* in the result are needed, avoid calling the routine with ;* -128 ($80) as multiplicand ;* ;* Number of words :10 + return ;
in „Eine Frage bzg. Macro in AVR-Assembler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
240x128.ASM
command ; //\\ call send_command ; || movlw 0x03 ; || movwf zaehlerH ; || movlw 0x81 ; || movwf zaehlerL ; || auto_clear movlw 0x00 ; || movwf data_byte call send_data_auto ; || decfsz zaehlerL,f ; || goto auto_clear ; || decfsz zaehlerH,f ; || goto auto_clear ; || movlw 0xB2 ; || movwf command ; \\// call
in „T6963C mit PIC 16F877“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
CamperDisplay.pdf
1 + V V V V 1 R FILL75 + V R 2 3 4 8 STM32F100C8 1 OUT75 R T 6 - K 4 T C 2 WATERREF100nF - V 1 R C L U L MEMCS 1 CE VDD 8 2 LM339 C10 D N +3,3V C47 2 MISO S25FL127S HOLD 7 1 OUT75 9 I UNFILTEREDGND I MISO 3 6 C45 R R WP SCK SCK 0 1 0 4 D 8 10nF 100nF DGND 4 GND U5 MOSI 5 MOSI 6 R 6 R I 7 3 +3,3V 1 S
in „Akku und Wasserstandsdisplay für Wohnmobile“ · Projekte & Code ·
-
PDF
displayinterface_arduino.pdf
: stxlcd.printf("%P%l",2); // gehe zu Zeile 2 und lösche diese stxlcd.printf("%P%l",1); // gehe zu Zeile 1 und lösche diese, Ausgabeposition // ist jetzt 1,1 (links oben) stxlcd.printf("Hallo\n\rWelt"); // in der ersten Zeile
in „Arduino: serielles Ansprechen eines HD44780 Displays über SoftSerial“ · Projekte & Code ·
-
Datei
laufs3n.asm
Zeile8 retlw .4 ;Zeile7 retlw .8 ;Zeile6 retlw .16 ;Zeile5 retlw .32 ;Zeile4 retlw .64 ;Zeile3 retlw .128 ;Zeile2 call row1 ;Zeile1 return ;rowpcl ********************************************************* ;row1 *********************************************************** row1 movlw .0 movwf dsend call data_send
in „PIC - ORG?PCLATH - ich kapiers einfach nicht =(“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Propeller_Layout_20070717.pdf
2 1 30 111 5 2 R 2 43 D9 18 8 2 8 7 6 5 4 3 2 1 3 1 2 1 C1 3 2 1 9 31 105 2 C200 1 45 16 2 2 8 R 1:L 3: : : : : : ::L:L:L:L:L: : 1 26 15 1 3 4 0 47 14 1 G 1 C 1 C 1 2 R 4 2 2 2122232 4 5 6 171811 1 1 2 1 48 13 4 2 4 R191 1 2 1 27 14 C 09 1 2 3 4 5 6 71 1 1 2 N3 2 1 7 2:L X 1 1 2 1 2 2 1 C C R CRC R
-
Datei
servo.c
für den UART benötigt #define baudrate 9600 // 9600 Baud #define uartnumber (frequency/(baudrate*16l)-1) //Externe Funktionen #include <io.h> #include <inttypes.h> #include <interrupt.h> #include <sig-avr.h> #include <avr/delay.h> //Um zu wissen für was uint8_t u.s.w. steht siehe inttypes.h typedef
-
Datei
spi_drv.h
prototypes and the macros of the //! low level functions (drivers) of: //! - SPI //! - for AT90CAN128/64/32. //! //! This file can be parsed by Doxygen for automatic documentation generation. //! This file has been validated with AVRStudio-413528/WinAVR-20070122. //! //! @version $Revision: 3.20 $ $
in „Probleme mit AT90CAN64 SPI Übertragung“ · Mikrocontroller und Digitale Elektronik ·