-
Datei
send_r_v_2_0.c
-------- #define F_CPU 3686400 #include <avr/io.h> #include <E:\AVR_Programme\IR_fern\Bibliotheken\rc5.h> //------------------------------------------------------------------ //------------------------------------------------------------------ //-------Variablendeklaration----------------------------
in „Verwendung einer .h und .c; AVR“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
auszug_vom_code.txt
;Festlegung ;RB4 --> LCD Bit4 ;RB5 --> LCD Bit5 ;RB6 --> LCD Bit6 ;RB7 --> LCD Bit7 ;RC6 --> LCD E fallende Flanke notwendig ;RC7 --> LCD RS High-->Daten Low-->Befehle #define E PORTC,6 #define RS PORTC,7 ;LCD Iniziallisierung lcd_init
in „Startadressen EA DIP204-4 mit KS0073“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
RGB_Led1.asm
counter2 cpi Counter2, 5 brlo Loop ; Nur alle 5 Durchläufe die Taste checken! ldi Counter2, 0 cbi PORTC, 2 sbis PIND, 0 rjmp R_dunkler R_D_Weiter: sbis PIND, 1 rjmp R_heller R_H_Weiter: sbis PIND, 2 rjmp G_dunkler G_D_Weiter: sbis PIND, 3 rjmp G_heller G_H_Weiter: sbis PIND, 4 rjmp B_dunkler B_D_Weiter: sbis PIND, 5 rjmp B_heller B_H_Weiter: sbis PIND, 7 rjmp SelectRandColor RC_Weiter: rjmp Loop R_dunkler: cpi ZielR, 0x00 breq R_D_Weiter dec ZielR mul ZielR, ZielR mov ZielR2, r1 sbi PORTC, 2 rjmp R_D_Weiter R_heller
in „Mysterium...“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
same70j21.h
************************************************************************ */ #define CHIP_FREQ_SLCK_RC_MIN _UL_(20000) #define CHIP_FREQ_SLCK_RC _UL_(32000) /**< \brief Typical Slow Clock Internal RC frequency*/ #define CHIP_FREQ_SLCK_RC_MAX _UL_(44000) #define CHIP_FREQ_MAINCK_RC_4MHZ _UL_(4000000) #define CHIP_FREQ_MAINCK_RC_8MHZ _UL_(8000000) #define CHIP_FREQ_MAINCK_RC_12MHZ _UL_(12000000) #define CHIP_FREQ_CPU_MAX _UL_(300000000) #define CHIP_FREQ_XTAL_32K _UL_(32768) #define CHIP_FREQ_XTAL_12M _UL_(12000000) #define
in „SAM Atmelstudio7 Interupts ohne ASF“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
define SCLK_bm 0b00000100 // Variablen uint32_t freq = 1; // 1 Hz void spi_delay(void) { _delay_us(0.5); // Delay nur noch an einer Stelle ändern } void spi_start(void) { DDSPORT.OUTCLR = FSYNC_bm; // set FSYNC (PD0) to low spi_delay(); } void spi_stop(void) { DDSPORT.OUTSET = FSYNC_bm; // set FSYNC (
in „Atmel XMEGA128A1 und DDS AD9835“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
_C-Versuchsboard_Schaltplan.pdf
1 2 3 4 5 6 7 8 5 MSTBV3 0 + K4 3 X1-3 4 1G6RW 8 5 1 9 8 7 6 5 4 3 2 1 8 5 A E P 2 X1-2 + X Q8 B L K4 BC817 2 V S O 1 X1-1 + K3 2 K 5 R12 4 1G6RW MSTBV3 R 1 + GND 3 K S 7 3 A 4K7 R Q7D B D X2-3 A R29 BC817 2 L
in „Problem mit ATmega32“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
omnitronic_p1500_1__sch.pdf
2SA940 Limiter switch (ON) 3 GND 2SC1815 7 2.2k On rear panel 10k 240k T230 1 4 0.68 GND 1N4148 10k R1 5 R279 2SC1815 C225 10k R303 +24V 4.7k U202A 10n B R224 6 10k + - 1/2 RC4558 10k B 10k -15V 2SC4468 R254 + C224 R286 47k 100uF 25V T210 5 6 1k 1 1 R275 R274 U202A 1 GND VR202 2 LM13600D (1/2) 390 1/2 RC4558
in „Fehlersuche Endstufe (inkl. Schaltplan)“ · Analoge Elektronik und Schaltungstechnik ·
-
 Bild
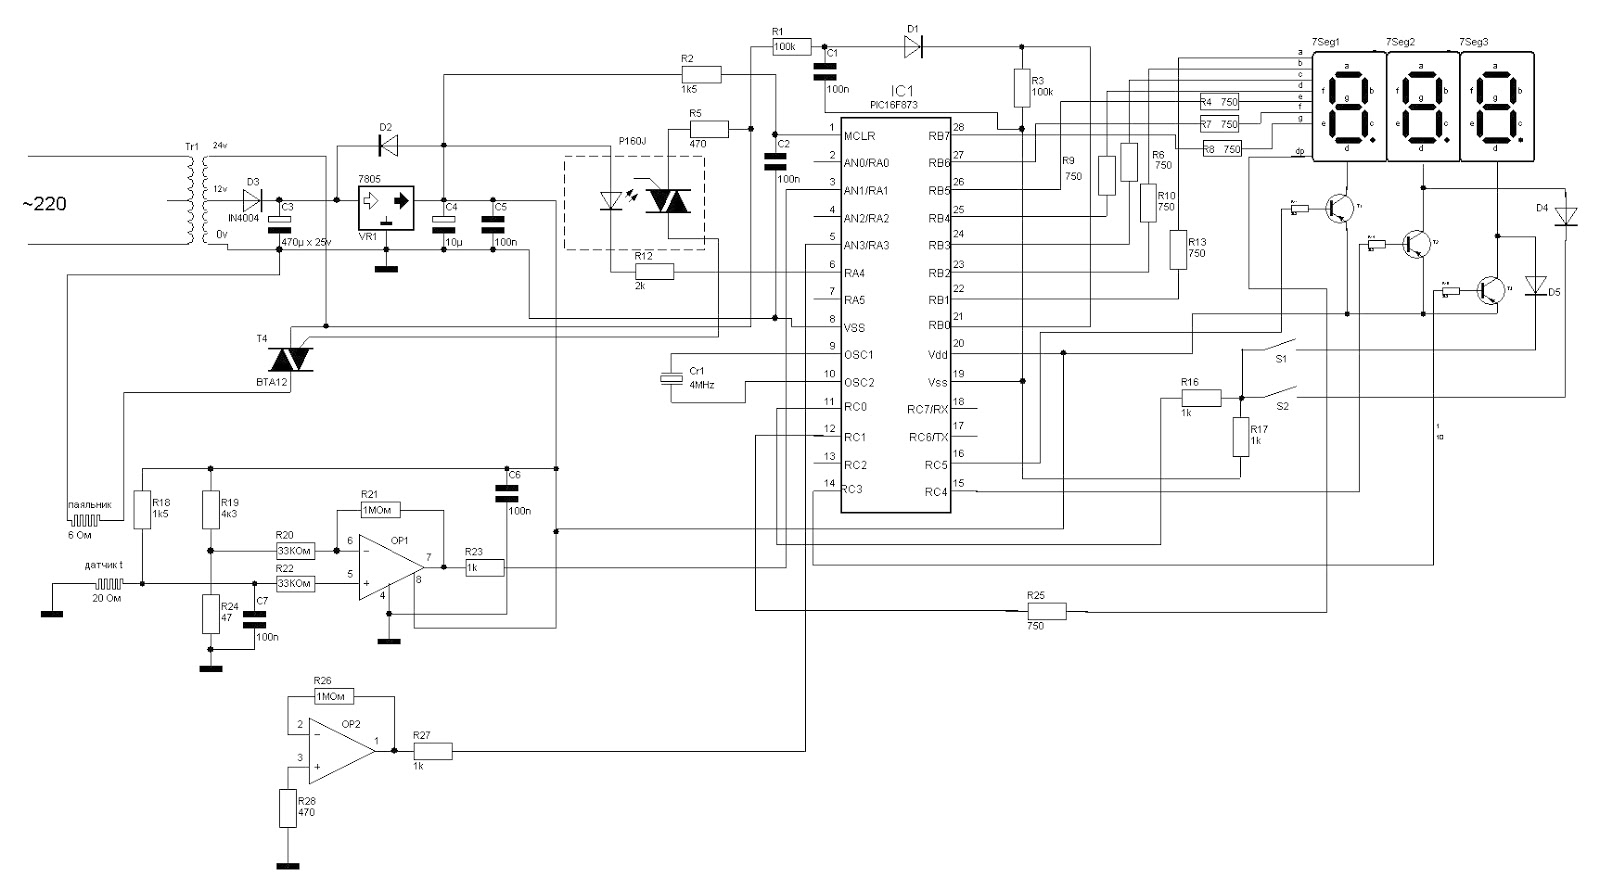
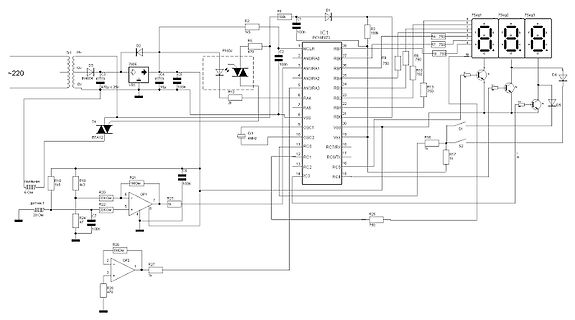
Schaltplan mit Mikrocontroller und 7-Segment-Anzeige
Tr1 24v D3 1N4004 0v R2 1k R1 100k C1 D1 IC1 PIC16F873 MCLR RB7 7Seg1 7Seg2 7Seg3 R3 100k R4 750 R5 100n C2 470 P160J R6 750 R7 750 R8 750 R9 750 R10 750 R13 750 R16 750 R17 750 R20 330k R21 1M R22 750 R23 750 R24 20 Ohm R25 750 R26 1M R27 1k R28 47u C6 100n C7 100n T4 BTA12 S1 S2 Vdd Vss AN0 bis AN4 RA0 bis RA5 RC0 bis RC6 OP1 OP2
in „Weller WSD81 Fehlermeldung“ · Mechanik, Gehäuse, Werkzeug · · Schaltpläne
-
Datei
irsnd-main-avr.c
V2V_RESDN 0x31 // volume #define V2V_RIGHT 0x10 #define V2V_LEFT 0x11 // matrix // // PB 0 1 2 3 4 5 6 7 //PD0 PWR HELP MUTE VOL+ UP OK DWN VOL- //PD1 G H E F C D A B // output port is declared but IRSND will take care of it #define IR_OUT PD5 #define ROW_0 PD0 #define ROW_1 PD1 #define WAS_R0 PD2 /
in „IR Fernbedienung mit IRSND“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
Schaltplan einer Elektronikschaltung
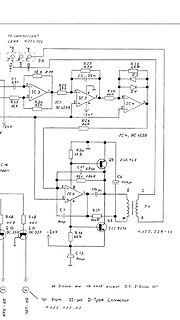
LAMP 1.721.256 J3 R19 68 K C1 22n IC 3 R22 12K R20 33K IC3 R23 27K R27 4.7K C2 22n R29 10K D3 D4 IC4 RC 4559 -20V R24 10K C14 100n Q9 2SA 968 R30 68R C11 68p R51 180K C6 100u 8 5 2 IC4 RC 4559 8 C10 1n 5 2 T1 11 8 R21 100R Q8 2SC 2238 1.022.229-00 C7 100p R66 4K7 R68 4K7 Q13 BC 337 Q15 BC 337 -20V R48
in „Spannungsversorgung EL Folie“ · Analoge Elektronik und Schaltungstechnik · · Schaltpläne
-
PDF
PH-1_Phono_preamp.pdf
is left off the board, or is replaced by 0.01µF ceramic capacitor. Filament Jumper Wire Schedule V5 V6 V7 V8 4 5 4 5 4 5 4 5 +H J1 J2 J3 J4 J5 J6 J7 J8 J9 J10 J11 J12 C16 5 4 5 4 5 4 5 4 -H V1 V2 V3 V4 With a 12.6V PS Tubes V1 & V5 V2 & V6 V3 & V7 V4 & V8 If tubes are 6.3V: J2 only J5 only J8 only
in „Kondensatoren für Aikido RIAA“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
gaak03.bas
Schaltmodul zum Einschalten eines Soundmoduls und Ein/Ausschalten eines 'Wechselblinkers einer schwimmenden RC-gesteuerten Ente. 'Die Funktion ist Folgendermaßen: 'Durch schnelles Schalten des Steuerknüppels von der Neutralstellung zu einer 'Endlage (kurzer oder langer Kanalimpuls) wird eine Aktion ausgelöst.
in „Status abfragen, bevor es ins Hauptprogramm geht / BASCOM“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Schaltmodul zum Einschalten eines Soundmoduls und Ein/Ausschalten eines 'Wechselblinkers einer schwimmenden RC-gesteuerten Ente. 'Die Funktion ist Folgendermaßen: 'Durch schnelles Schalten des Steuerknüppels von der Neutralstellung zu einer 'Endlage (kurzer oder langer Kanalimpuls) wird eine Aktion ausgelöst.
in „Ich verstehe den Timer0 beim ATtiny 13 nicht.“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Schaltmodul zum Einschalten eines Soundmoduls und Ein/Ausschalten eines 'Wechselblinkers einer schwimmenden RC-gesteuerten Ente. 'Die Funktion ist Folgendermaßen: 'Durch schnelles Schalten des Steuerknüppels von der Neutralstellung zu einer 'Endlage (kurzer oder langer Kanalimpuls) wird eine Aktion ausgelöst.
in „RC Kanal auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Schaltmodul zum Einschalten eines Soundmoduls und Ein/Ausschalten eines 'Wechselblinkers einer schwimmenden RC-gesteuerten Ente. 'Die Funktion ist Folgendermaßen: 'Durch schnelles Schalten des Steuerknüppels von der Neutralstellung zu einer 'Endlage (kurzer oder langer Kanalimpuls) wird eine Aktion ausgelöst.
in „Probleme Bascom Servo Steuerung / Kanalauswertung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
gaak03.bas
Schaltmodul zum Einschalten eines Soundmoduls und Ein/Ausschalten eines 'Wechselblinkers einer schwimmenden RC-gesteuerten Ente. 'Die Funktion ist Folgendermaßen: 'Durch schnelles Schalten des Steuerknüppels von der Neutralstellung zu einer 'Endlage (kurzer oder langer Kanalimpuls) wird eine Aktion ausgelöst.
in „RC-Empfänger auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Kuhschwanz.pdf
haben wir beim oberen End-Anschlag des Pot einen Teiler aus 200k zu 1,01M, was einem Verhältnis von 83,5% entspricht. Zur Erinnerung, die Höhen werden mit 5% Verhältnis geteilt. Am unteren Ende des Pot haben wir für Gleichstrom einen Teiler von 1,2M zu 10k, was 0,83% entspricht. Gegenüber den Höhen mit dem Teilerverhältnis von 5% ergibt das bei Reglerstellung oben eine Anhebung von Faktor 16,7, also rund 24dB, am unteren Ende ergibt sich eine Absenkung von rund 16dB. Aus dem Längswiderstand am Schleifer des Tieftonreglers zum
in „Kuhschwanz vs Linkwitz-Riley“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
ausgabe.txt
period to 50 usec avrdude: error: usbtiny_transmit: avrdude: error: usbtiny_receive: (expected 4, got -5) avrdude: AVR device initialized and ready to accept instructions Reading | avrdude: error: usbtiny_receive: (expected 4, got -5) avr_read(): error reading address 0x0000 read operation not supported for memory "signature" avrdude: error reading signature data for part "ATmega8", rc=-2 avrdude: error reading signature data, rc=-1 avrdude: error: usbtiny_transmit: avrdude done. Thank you.
in „Keine Verbindung zwischen uISP-Stick und Atmega-8A“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
DOGM.c
( &lcd_buffer[1][0], "%3u\xdfC ",ambient_temp); sprintf( &lcd_buffer[2][0], "%2u.%1u V %2u.%1u V", rc_supply/10000, (rc_supply%10000)/1000 , ecu_supply/10000, (ecu_supply%10000)/1000 ); ecu_display_lcdbuffer( 3 ); /* // Glow lcd_gotoxy(9,1); lcd_putchar(4); // Temp lcd_gotoxy(11,1); lcd_putchar(5); /
in „EA DOG-M Display (ST7046) und customchars. ARGH!“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
KM62256C.pdf
. Precharge circuit. A9 3 26 I/O8 A8 4 25 I/O7 A14 1 28 VCC A13 5 24 I/O6 A12 2 WE 6 28-TSOP 23 I/O5 A3 27 WE VCC 7 22 I/O4 A7 3 26 A13 A14 8 Type1 - Forward 21 VSS A4 A12 9 20 I/O3 A5 A6 4 25 A8 A7 10 19 I/O2 A5 5 24 A9 A6 11 17 I/O1 A6 Memory array A5 13 16 A1 Row
in „billig RAM's abzugeben“ · Markt ·
-
 Bild
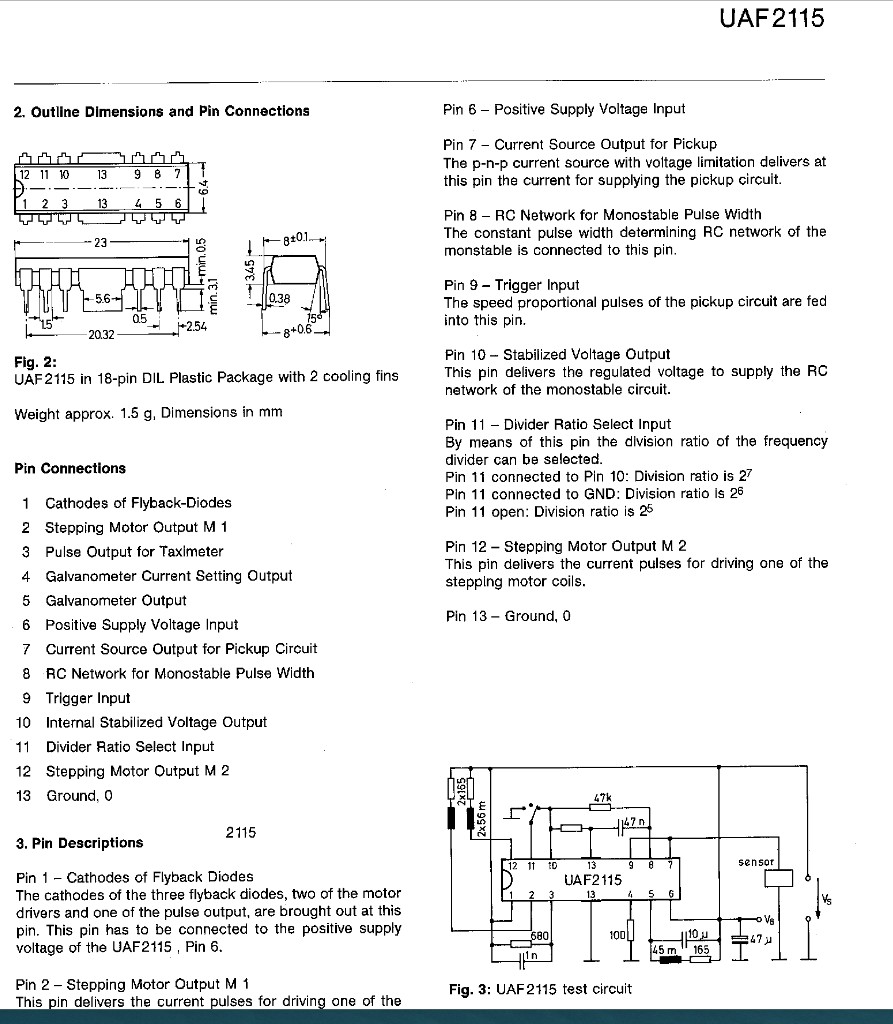
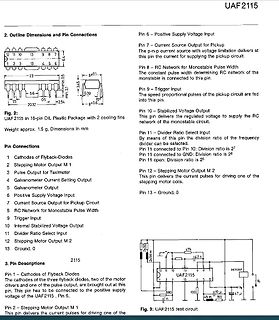
Datenblatt-Ausschnitt UAF2115 mit Pinbelegung und Schaltplan
Motor Output M 1 Pin 3 – Pulse Output for Taximeter Pin 4 – Galvanometer Current Setting Output Pin 5 – Galvanometer Output Pin 6 – Positive Supply Voltage Input Pin 7 – Current Source Output for Pickup Circuit Pin 8 – RC Network for Monostable Pulse Width Circuit Pin 9 – Trigger Input Pin 10 – Internal
in „MOSFET Dimensionierung für Signalwandlung“ · Mikrocontroller und Digitale Elektronik · · Screenshots
-
PDF
AN-3008.pdf
Examples of Snubber Designs Then from Figure 18, V PK = 1.42 (340) = 483 V. dV Table 2 describes snubber RC values for - . Figures 31 Thus, it will be necessary to use a 600 V device. Using the dts previously stated formulas for ω0, C and R we find: dV and 32 show possible R and C values for a 5.0V/
in „MOC3063 vs MOC3063M“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
rnvn2dualmotor.pdf
Wannenstecker Standard-Belegung nach RN-Definition). Sogar Motorstrom wird als analog Signal (0 bis 2,5V) für AD-Port geliefert. • Notaus-Lötkontakte um Motoren durch Schalter/Taster zu deaktivieren • Optional aufsteckbares I2C/RS232/RC Schnittstellenboard RN-MotorControl erhältlich • Überlastungsschutz
in „Ansteuerung von Motor-Treiber mit PWM“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
SRAM_k6x4008c1f.pdf
CMOS SRAM 1) RECOMMENDED DC OPERATING CONDITIONS Item Symbol Min Typ Max Unit Supply voltage Vcc 4.5 5.0 5.5 V Ground Vss 0 0 0 V Input high voltage V IH 2.2 - Vcc+0.5 2) V Input low voltage V IL -0.5 3) - 0.8 V Note: 1.Commercial Product: T A=0 to 70 °C, otherwise specified Industrial Product: A=-40
in „SRam und ADC extern takten“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
628512-55__SAM.pdf
CMOS SRAM 1) RECOMMENDED DC OPERATING CONDITIONS Item Symbol Min Typ Max Unit Supply voltage Vcc 4.5 5.0 5.5 V Ground Vss 0 0 0 V Input high voltage V IH 2.2 - Vcc+0.5 2) V Input low voltage V IL -0.5 3) - 0.8 V Note: 1.Commercial Product: T A=0 to 70 °C, otherwise specified Industrial Product: A=-40
in „Epromm Ersetzt durch statisches Ram“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
stepper_cnt=0; volatile uint8_t xsteps=10; uint8_t stepper1[16] PROGMEM = {0x07,0x36,0x55,0x63,0x78,0x6b,0x5d,0x3e, 0x8f,0xbe,0xdd,0xe0,0xd3,0xb5,0x86}; uint8_t stepper2[16] PROGMEM = {0x07,0x36,0x55,0x63,0x78,0x6b,0x5d,0x3e, 0x8f,0xbe,0xdd,0xe0,0xd3,0xb5,0x86}; /**------------------------------------------
in „XMEGA DMA transfer nach PORT“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
ISG3400VP.c
InPortA1 = 0x00; UBYTE InPortA2 = 0x00; UBYTE InPortc = 0x00; UBYTE InPortA3 = 0x00; UBYTE InPortC5 = 0x00; UBYTE InPortC4 = 0x00; //Interner Oszillato mit 8MHz OSCCON = 0b01110010; CMCON = 0x07; //Komparator abschalten UCON = 0x00; UCFG = 0x00; //Alle Ausgangsports initialisieren // SetOutputsIni
in „PIC18F2550 digitaler Eingang RC4“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
make.txt
funsigned-bitfie lds -fpack-struct -fshort-enums -Wall -Wstrict-prototypes -Wa,-adhlns=infrared/r c5.lst -std=gnu99 -DF_CPU=12000000 infrared/rc5.c \ | sed 's,\(.*\)\.o[ :]*,\1.o \1.d : ,g' > infrared/rc5.d; \ [ -s infrared/rc5.d ] || rm -f infrared/rc5.d 'sed' is not recognized as an internal or external
in „GCC, Toolchain: 'make' macht's nicht mehr“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
hxk80aa_cdo00096_r600a_220v_50hz_12-2016_desd564p102.pdf
12900 Household 220V, 50Hz, RC 3µF, ePTC consumption incl., static cooling (alternative use of PTC +2W) Evap. temp. in °C -45 -40 -35 -30 -25 -23.3 -20 -15 -10 -6.7 -5 0 5 7.2 10 15 20 Capacity in W 57.8 78.9 105 115 136 172 213 243 259 Power cons. in W 51.5 60.4 70.4 74.0 81.3 92.8 105 113 117 Current cons. in A 0.28 0.31 0.34 0.35 0.38 0.42 0.46 0.50 0.52 COP in W/W 1.12 1.31 1.49 1.55 1.67 1.86 2.04 2.16 2.23 ASHRAE LBP 220V, 50Hz, RC 3µF, ePTC consumption
-
PDF
71v416.pdf
VSS V DD 11 SO44-1 34 V SS SO44-2 V SS 12 33 V DD F I/O I/O A14 A15 I/O3 I/O4 I/O 4 13 32 I/O 11 I/O 5 14 31 I/O 10 I/O 6 15 30 I/O 9 G I/O NC A12 A13 WE I/O5 I/O 7 16 29 I/O 8 WE 17 28 NC* H NC A8 A9 A10 A11 NC A5 18 27 A14 3624 tbl 11 A6 19 26 A13 A7 20 25 A12 A8 21 24 A11 A9 22 23 A10 3624 drw 02 *
-
PDF
ENC_Drehratensensor.pdf
Scale Factor Linearity Response Weight (kHz) Voltage (deg./sec.) Velocity=0) (%FS) (Hz) (g) ENC-03RC-R 30.8 2.7-5.25V 300 1.35Vdc 0.67mV/deg./sec. 5 50 0.2 ENC-03RD-R 32.2 2.7-5.25V 300 1.35Vdc 0.67mV/deg./sec. 5 50 0.2 Operating Temperature Range: -5°C to 75°Storage Temp. Range: -30°C to 85°C Cat.No.S42E
in „Drehratensensor aus Gyro verwenden - Frage zu Schaltung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Simple__C-based_ADCs__Part_1_.pdf
right, with C. 3. If C = 1, then return with VX ←SAR. 4. Output SR OR SAR to OUT: OUT ← SR OR SAR. 5. Input from IN. 6. If IN = 1, then go to 2. 7. Else, set SAR to SAR AND /SR: SAR ← SAR AND (NOT SR). (Alternative: SAR ←▯ SAR AND (SR EOR 1111...). 8. Go to 2. The 1 bit, initially in C, is shifted right
in „Frage zu kapazitiven Sensoren“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
t-wintec-wsg2000.c
normal, 1 - start, 2 - marked */ unsigned char padding_1; unsigned int second: 6, minute: 6, hour: 5; /* UTC(?) */ unsigned int day: 5, month: 4, year: 6; /* add 2000 to year */ signed int latitude; /* divide by 1E7 for degrees */ signed int longitude; /* divide by 1E7 for degrees */ unsigned short
-
Datei
main.c
PORTA.PIN7CTRL = 0x07; // Input Disable on pin PA7 PORTA.PIN6CTRL = 0x07; // Input Disable on pin PA6 PORTA.PIN5CTRL = 0x07; // Input Disable on pin PA5 PORTA.PIN4CTRL = 0x18; // Pull up on pin PA4 PORTA.PIN3CTRL = 0x18; // Pull up on pin PA3 PORTA.PIN2CTRL = 0x18; // Pull up on pin PA2 PORTA.PIN1CTRL = 0x18; /
in „ATXmega - Pin Eingang oder Ausgang“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ATMEGA88-DB.pdf
Rev. 2545H-10/06 1. Updated typos. 2. Updated “Features” on page 1. 3. Updated “Calibrated Internal RC Oscillator” on page 32. 4. Updated “System Control and Reset” on page 44. 5. Updated “Brown-out Detection” on page 46. 6. Updated “Fast PWM Mode” on page 120. 7. Updated bit description in “TCCR1C –
in „Schieberegister SN54HC595 mit Atmel atmega 88 ansteuern“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
MT48LC16M16A2.PDF
VOL – 0.4 V Table 16: DD Specifications and Conditions (-6A) Notes 1, 5, 6, 11, 13 apply to the entire table; notes appear onDD/VDDQ = +3.3V ±0.3V Parameter/Condition Symbol -6A Units Notes Operating current: Active mode; Burst = 2; READ or WRITE; RC = RC DD1 135 mA 3, 18
in „[Verkaufe] 5xSDRAM (4Meg x 16 x 4 Banks) und 5xFLASH (64Meg 8 o. 16 Bit)“ · Markt ·
-
PDF
CentiBOB201psk.pdf
8 0 C 1 0 - 1 4 5 3 3 D 1 X X 2 W X TESER_ WS 1 2 1 _ + - R S X 4 2 1 2$P X E NO_ WS 2 1 _ 1$P 4 N 2 R 3 S T A T 5 + 5 k 3 R 1 D L t e U 1 n . P 1 e o V 6 D as e C 3 O H a E su h : t R rc o V e H M in E h R S 311J + 1
in „ARM Board mit Linux-OS“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
new__3.asm
BANK SELECTION MES. init ; ADC initialisieren ; ADC einschalten BSF ADCON0, 0 ; ADON=1 BCF ADCON0, 5 ; ADCHS2=0 BCF ADCON0, 4 ; ADCHS1=0 BCF ADCON0, 3 ; ADCHS0=0 ; ADC Speed 5 MHz BSF ADCON0, 7 ; ADCS1=1 BCF ADCON0, 6 ; ADCS0=0 ; Daten rechtsbündig BSF STATUS,RP0 ; Bank1 clrf ADCON1 BSF ADCON1, 7 ;
in „Pic 16f pwm funktioniert nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
test.c
bufidx ^= 1; } int main() { // // Clock // // Internen 32Mhz Oszillator einschalten OSC.CTRL = OSC_RC32MEN_bm; // Warten bis Oszillator stabil ist while ((OSC.STATUS & OSC_RC32MRDY_bm) == 0); // System Clock selection CCP = CCP_IOREG_gc; CLK.CTRL = CLK_SCLKSEL_RC32M_gc; // DFLL ein (Auto Kalibrierung
in „Xmega Soundcheck“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
sd679x_SDH771x_20190619032536964.pdf
产品特点 产品列表 • 高压直供技术, 外围少BOM成本低 Part No In-MOS Rds_on Package Pin • 省COMP补偿电容,防潮湿防漏电防断裂 SDH6981R 550V 6.5 SOP-8 9W • 4PIN用于散热, 性能极佳 SDH6983R 550V 4.0 SOP-8 15W SDH6984R 550V 1.9 SOP-8 18W • SDH6984RC为巴西市场定制低谐波方案 SDH6984RC 550V 1.9 SOP-8 18W SDH6983D 550V 4.0 DIP-8 18W SDH6984D 550V 1.9 DIP-8 24W SILAN COMPANY CONFIDENTIAL Page 10 SDH6984RC – 最佳的单次谐波T管解决方案 单次谐波 Vinac 3 5 7 9 11 <30*λ <10 <7 <5 <3 127V 24.7 5.8 5.1 1.3 1.3 220V 13.7 5.4 3.9 1.6 1.5 SILAN COMPANY CONFIDENTIAL Page 11 SDH790X – 去VCC电容,低谐波 产品特点: Ø 高压单芯片工艺 Ø 无VCC电容 Ø 无COMP电容
in „Unbekanntes IC in LED-Leuchte mit 3-step Dimmfunktion“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
FULLTEXT01.pdf
line. 23 Figure 2.17: Parallel RC circuit design in order to maintain stability within band Figure 2.18: Series RC circuit design in order to maintain stability within band 24 0 ) -1 1 ) ( , . ( -2 n ( ( d d -3 -4 1.0 1.5 2.0 2.5 3.0
in „Buchempfehlung HF-Verstärker gesucht“ · HF, Funk und Felder ·
-
 Bild
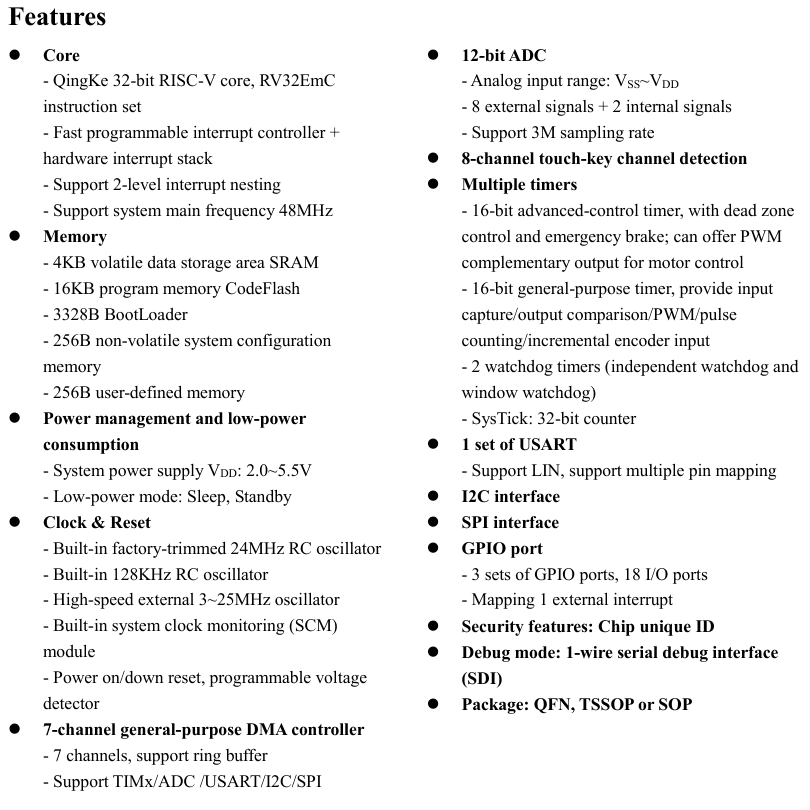
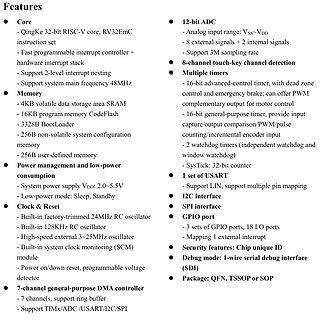
Technische Spezifikationen eines Mikrocontrollers
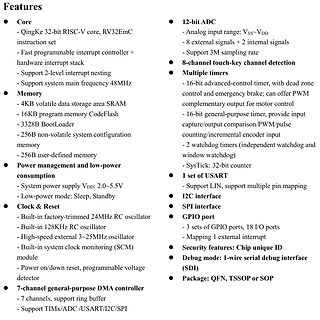
256B user-defined memory Power management and low-power consumption - System power supply VDD: 2.0~5.5V - Low-power mode: Sleep, Standby Clock & Reset - Built-in factory-trimmed 24MHz RC oscillator - Built-in 128KHz RC oscillator - High-speed external 3~25MHz oscillator - Built-in system clock monitoring
in „CH32V003F4P6 Breakout Platine mit Port Expander und Extras“ · Mikrocontroller und Digitale Elektronik · · Screenshots
-
 Bild
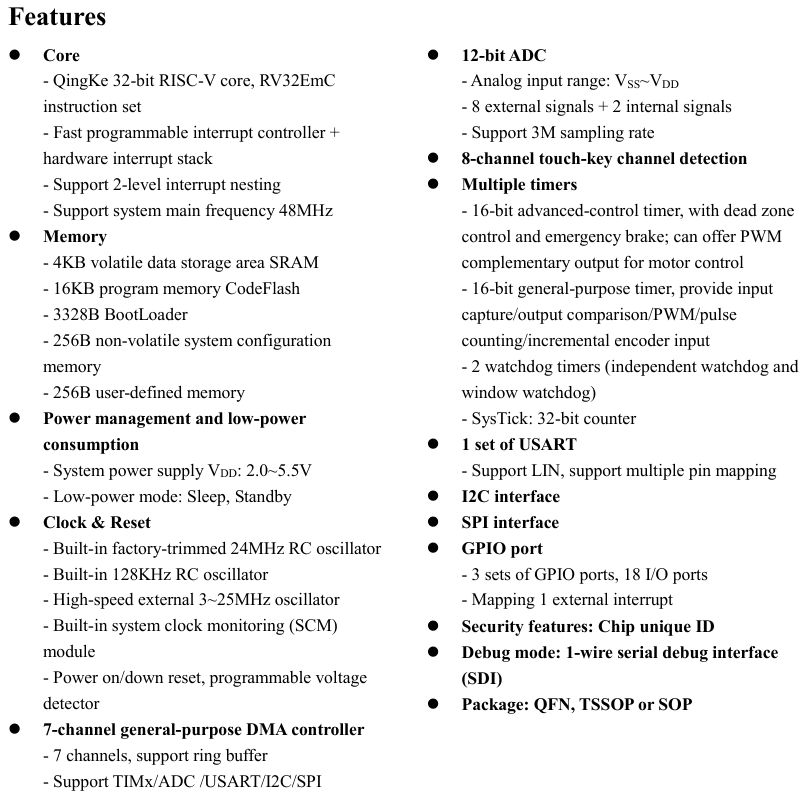
Technische Spezifikationen eines Mikrocontrollers
256B user-defined memory Power management and low-power consumption - System power supply VDD: 2.0~5.5V - Low-power mode: Sleep, Standby Clock & Reset - Built-in factory-trimmed 24MHz RC oscillator - Built-in 128KHz RC oscillator - High-speed external 3~25MHz oscillator - Built-in system clock monitoring
in „CH32V006 und CH32V007 von WCH“ · Mikrocontroller und Digitale Elektronik · · Screenshots
-
PDF
LeCroy-TS-8500-Datasheet.pdf
delay time 20 ns or more (delay time on the screen) c X axis (CH1) Input coupling AC, DC, GND Input RC 1 MΩ ± 1.5% // 16 pF ± 2 pF, Sensitivity 50 Ω input: 50 Ω ±1% Range Same as CH1 Accuracy ±2% Max. input voltage Frequency response DC – 10 MHz, -3 dB 1 MΩ input ±400 V max. (DC + AC peak) c Y axis CH1
in „Hat jedes Oszilloskop einen Anschluss für einen Computermonitor?“ · Offtopic ·
-
PDF
mwmanual.pdf
adjusted to 5.5 volts, the maximum output current can be calculated by: Iout = Pout / Vout i.e. Iout = 50 watts / 5.5 volts = 9.09 amps. The output voltage can also be adjusted lower than 5 volts. However, due to
in „Stromquelle gesucht - ca. 60 V 0-50 A“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
uPC254.pdf
L pin 0j--RAAl'----'\RACIv----.JII'R""B.r---or pI' 1-.0- - - - - - - 2 0 kfl Fixed Resistor RA. RB 5.1 kn Potentiometer Rc. 10.0 kn Null Range ±1.2 mVTyp. OPEN LOOP FREQUENCY RESPONSE LARGE SIGNAL FREQUENCY RESPONSE 120 28 V±= ±15 V ~ ~ V±= ±15 V 100 ~ 24 80 0. 20 IX! > ic cI 16 (!);60 ~ .~ Q) " .n
in „Was ist ein C254D?“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
TravelLogic-TL2x18E.pdf
Requirements • USB 2.0 port • XP, Vista, Win 7, Win 8 (32 / 64 bits) TL2018E TL2118E Multi channel 18/2 2.5K/18 18 , Time-out Bus Trigger I²C c I g l n c T t c f 1-Wire, 3-Wire, 7-Segment, AccMeter, ADC, APML, CAN, Close Caption, CEC, DALI, DMX512, k DP-Aux, EDID, FlexRay, Line Decoding, Line Encoding, HD
-
Datei
DOGM_128x64.c
D5 | X X // D6 | X X // D7 | D7 ist immer "0" und ergibt damit den Zeilenabstand // ___________________________________ ________________________________ // D0 | // D1 | // D2 | // D3 | page 1 (usw. bis page 7) // D4 | // D5 | // D6 | // D7 | // // Das Display hat 8 Zeilen: oberste Zeile: DOGM_line 0 // unterste Zeile: DOGM_line 8 // // Es können 21 Zeichen pro Zeile dargestellt werden: DOGM_position 1...21 // // Dieses
in „I2C + SPI auf einem yC“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
DOGM_128x64.c
D5 | X X // D6 | X X // D7 | D7 ist immer "0" und ergibt damit den Zeilenabstand // ___________________________________ ________________________________ // D0 | // D1 | // D2 | // D3 | page 1 (usw. bis page 7) // D4 | // D5 | // D6 | // D7 | // // Das Display hat 8 Zeilen: oberste Zeile: DOGM_line 0 // unterste Zeile: DOGM_line 8 // // Es können 21 Zeichen pro Zeile dargestellt werden: DOGM_position 1...21 // // Dieses
in „Unknown keyword in #FUSES "INTRC"“ · Mikrocontroller und Digitale Elektronik ·