-
Datei
main.c
******************************************* #include <msp430x14x.h> #include <stdlib.h> #include <stdio.h> #include <signal.h> #include <initialization.h> unsigned char id_low = 0xFF; unsigned char id_high = 0xFF; interrupt (PORT1_VECTOR) P1_ISR(void) { if(P1IFG
in „Bitprobleme mit SPI“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
hauptfunktion.c
char spi_itoabuffer[33]; uint8_t spi_var =0; uint8_t spi_data_array[4]; uint8_t spi_tx_address[5] = {0xE7,0xE7,0xE7,0xE7,0xE7}; uint8_t spi_rx_address[5] = {0xD7,0xD7,0xD7,0xD7,0xD7}; int main(void){ //extern_interrupt_init(); // INT0 -> falling edge usart_init(USART_MYUBRR); timer_interrupt_init(); //
in „NRF24L01 und Atmega328P“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
avrdude-fuse-probl.txt
4000 0xff 0xff flash 65 6 32 0 yes 1024 32 32 4500 4500 0xff 0xff signature 0 0 0 0 no 3 0 0 0 0 0x00 0x00 lock 0 0 0 0 no 1 0 0 4500 4500 0x00 0x00 calibration 0 0 0 0 no 2 0 0 0 0 0x00 0x00 lfuse 0 0 0 0 no 1 0 0 4500 4500 0x00 0x00 hfuse 0 0 0 0 no 1 0 0 4500 4500 0x00 0x00 Programmer Type : avr910
in „Probleme mit AVRDude“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
ds1302.h
rtc_ram_write(DRTC* dRtc, uint8_t addr, uint8_t d); // Register Addresses #define RTCR_SEC ((uint8_t)0x00) #define RTCR_MIN ((uint8_t)0x01) #define RTCR_HR ((uint8_t)0x02) #define RTCR_DATE ((uint8_t)0x03) // day of month 1-31 #define RTCR_MONTH ((uint8_t)0x04) #define RTCR_DAY ((uint8_t)0x05) // weeekday, 1-7 #define RTCR_YEAR ((uint8_t)0x06) // 00-99 (2000-2099) #define RTCR_CONTROL ((uint8_t)0x07) #define RTCR_CHARGER ((uint8_t)0x08) #define RTCR_CLOCKBURST ((uint8_t)0x1F) // internal functions // implement the 3-wire-interface #endif
-
Datei
cfg_ad9833.c
Manuelle Berechnung fuer 5845000 Hz // FTW frequency tuning word #define FTW 62760209 #define FA (0x4000 | (FTW & 0x3FFF) ) // LSB fuer F0 #define FB (0x4000 | ((FTW>>14) & 0x3FFF) ) // MSB fuer F0 // PINs #define FSYNC_LOW PORTB &= ~(1<<PB0) #define FSYNC_HIGH PORTB |= (1<<PB0) #define CLK_LOW PORTB
in „AD9833 Programmieren“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Fast_Signal_mit_XY-Display.txt
115200 ' Baudrate uart.Recv.enable ' Senden aktivieren uart.Send.enable ' Empfangen aktivieren dim x as integer dim y as single Do for x = 1 to 2000 y = fsin(x/20) print "#58M";str(x);"<"; ' send x-value print "#59M";str(y);"<"; ' send y value next print "#58M-9999999<" ' clear display Loop
in „Projekt: Virtuelle Instrumente an serielle Schnittstelle“ · Projekte & Code ·
-
PDF
DE_16DE0001_TECHNIK_LEITUNGSSCHUTZSCHALTER.pdf
mit Hülse ohne Hülse Leiterquerschnitt1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 mm² x x x 1,5 mm² x x x x x x 2,5 mm² x x x x x x 4 mm² x x x x x x 6 mm² x x x x x 10 mm² x x x x 16 mm² x x x 25 mm² x x LS Schalter 10 kA flexibel massiv mit Hülse ohne Hülse Leiterquerschnitt1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 mm² x x x 1,5 mm² x x x x x x 2,5 mm² x x x x x x 4 mm² x x x x x x 6 mm² x x x x x 10 mm² x x x x 16 mm² x x x 25 mm² x x x 35 mm² x x 1028 Technische Änderungen vorbehalten Leitungsschutzschalter Belastbarkeit
in „Fi-Schutzschalter nur für die Hälfte der Wohnung?“ · Haus & Smart Home ·
-
PDF
DE_20DE0001_TECHNIK_LEITUNGSSCHUTZSCHALTER.PDF
Hülse ohne Hülse Leiterquerschnitt1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 mm² x x x 1,5 mm² x x x x x x 2,5 mm² x x x x x x 4 mm² x x x x x x 6 mm² x x x x x 10 mm² x x x x 16 mm² x x x 25 mm² x x LS Schalter 10 kA flexibel massiv mit Hülse ohne Hülse Leiterquerschnitt1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 Leiter 2 Leiter 1 mm² x x x 1,5 mm² x x x x x x 2,5 mm² x x x x x x 4 mm² x x x x x x 6 mm² x x x x x 10 mm² x x x x 16 mm² x x x 25 mm² x x x 35 mm² x x 1128 Technische Änderungen vorbehalten Leitungsschutzschalter Belastbarkeit
in „Heizstrahler Schalterkontakt brennt fest“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
Correvit_cds-m_S-CE_d.pdf
.. 85° C Relative Feuchte: 5 ... 80%, nicht kondens. Schutzart: IP 67 Abmessungen (LxBxH): ca. 164 x 78 x 84 mm Nettogewicht: 1600 g Schock: 50 g Halbsinus, 6 ms Vibration: 10 g, 10 ... 150 Hz Serielle Schnittstelle zum Anschluß an PC Automatische Sensor-Identifikation und Funktionskontrolle Bremstest
in „AVR Spannungsfolgung mit Opptokoppler“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
MMA3202.pdf
span and filter cut-off are factory set and require no external devices. A MMA3202D: X-Y AXIS SENSITIVITY full system self-test capability verifies system functionality. MICROMACHINED ACCELEROMETER Features –100/50g Sensitivity in two separate axes: 100g X-axis and 50g Y-axis Integral
in „Lagebestimmung mit Beschleunigssensor“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Sensirion_Humidity_SHT21_Sample_Code_V1.2.pdf
bit RE = 0 DelayMicroSeconds(50); DisplayPrivateWriteByte(0, 0x0C); // display on, cursor off, blink off DelayMicroSeconds(50); DisplayPrivateWriteByte(0, 0x01); // clear display, cursor 1st. row, 1st. line DelayMicroSeconds(2000); DisplayPrivateWriteByte(0, 0x06
in „SHT11 SHT21 unterschiedliche Luftfeuchte Werte“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
MAX.pdf
CURRENTS vs. VCOM AND SINGLE SUPPLY vs. TEMPERATURE vs. TEMPERATURE 70 4 100 6 3 100 A 3 V+ = 12V X V+ = 16.5V X V+ = 16.5V X V- = 0V M V- = -16.5V M V- = -16.5V M 60 10 VCOM = ±15V 10 VCOM = ±15V T A +125°C V OR V = ±15V VNCOR V NO= ±15V NC NO 50 E 1 E 1 ) A A ( TA= +85°C K K N 40 E 0.1 E 0.1 RO L
in „Digitalpotentiometer in analogen Anwendungen“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
lcd.c
activeProc; #if LCD_RW_PIN_USED == 0 uint8_t last_y; #endif /* ** constants/macros */ #define PIN(x) (*(&x - 2)) /* address of data direction register of port x */ #define DDR(x) (*(&x - 1)) /* address of input register of port x */ #if LCD_IO_MODE #define lcd_e_delay() __asm__ __volatile__( "rjmp
in „HD44780 atmega168“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
siemens_cx65_cam.pdf
-0.2V 2. Sensor • Optical size : 1/4 inch optical format • Total pixel numbers : 698(H)x502(V) • Signal pixel numbers : 660(H)x492(V) • Pixel pitch : 5.4um(H)x5.4um(V) (square pixel) • Image size : 3.564mm(H) x 2.657mm(V) • Color filter : Primary color filter, Bayer arrangement (GR line
in „Digitale Cmos Kamera auslesen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Haartrockner.pdf
Gegenüberstellung verschiedener Typen eines RCD 30 mA (Kennlinien nach SCHUPA) Bei einem Fehlerstrom von 5xI Δn (5 x 30 mA) = 150 mA gelten für Abschaltzeiten (VDE 0664, HÖRMANN, 2009): RCD unverzögert max. 40 ms RCD kurzzeitverzögert bis zu 200 ms Bei einem Fehlerstrom von 1xI Δn beträgt die Abschaltzeit
in „wir schmeißen mal einen Föhn in die Badewanne.“ · Offtopic ·
-
PDF
AN1045-D.pdf
Using equation (5.3), the theoretical steady state case 2 VDRM * V S (1 ) p) temperature rise is: R x DIL(1 * p ) T * T + (66.7 W) (30⋅CńW) + 2000⋅C Worst case becomes: CSS A and DRM (T1) = 0;DRM (T2) = Spec. max. value and L = Spec. Max. Value R(ton) + R (3 s) + (40⋅C measured rise)ń2000+0.02 Figure
in „Zwei Triacs in Reihe - warum?“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
log.txt
65 10 8 0 no 4096 8 0 9000 9000 0x00 0x00 flash 65 10 256 0 yes 262144 256 1024 4500 4500 0x00 0x00 lfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 hfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 efuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 lock 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 calibration 0 0 0 0 no 1 0 0 0 0 0x00 0x00 signature 0 0 0 0 no 3 0 0 0 0 0x00 0x00 Programmer Type : STK500V2 Description : Atmel STK500 Version 2.x firmware Programmer Model: AVRISP Hardware
in „Bootloader mega2560“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.s
AREA DATA, READWRITE GPIOC_CRH EQU 0x40011004 GPIOC_ODR EQU 0x4001100C LED EQU 0x20000000 ;Register für RCC RCC_APB1ENR EQU 0x4002101C ;RCC APB1 peripheral clock enable register RCC_APB2ENR EQU 0x40021018 ;RCC APB2 peripheral clock enable
in „STM32 ASM Interrupt“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
20110325_log.txt
!USBD: Could not load driver for attached device [usbmsc.c:GetBotMaxBlockSize] Using MaxBlockSize 0x10000 (default 0x2000) USBMSC: Compiled Sep 4 2006 22:23:15 USBMSC: Modified, using block size = 0x10000 LcdInit ERROR: LCD not busy Storage devices: \USBDisk Key = mode, value = 0x00000001 INFO: Flashing
in „Pollin - Receiver-Mainboard mit Twin DVB-[T,C] Tuner, NXP PNX8950EH“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
WCU_Kilobot_Schematic.txt
6500 1400 6500 1600 @@@D27 R9.2 2 0 6500 1600 6500 1600 @@@D27 @@@D32 3 0 6500 1600 6600 1600 6600 2000 @@@D32 U2-B.7 2 0 6600 2000 6400 2000 @@@D32 @@@O43 2 0 6600 2000 6600 2000 *SIGNAL* $$$9017 64 0 U2-C.10 @@@D30 2 0 2700 1700 2200 1700 R10.1 @@@D30 2 0 2200 1800 2200 1700 @@@D30 R8.2 2 0 2200 1700
-
Datei
init.c
0xB3; //P6=0x80; PORTDIR7 = 0xFD; //0b11111101 //P7=0x; PORTDIR8 = 0xBF;//0x07 //P8=0x; PORTDIR9 = 0x64; //P9=0x; PORTDIR10 = 0x00; //P10=0x; //Timer einstellen //------------------------------- TA0 = 0x07D0; //Timer Reload Register auf 2000 setzen TA0MR = 0x40; //auf "Timer Mode " einstellen TABSR = 0x01; //Timer T0 Start Flag setzen //Interrupt Control Register //------------------------------- // S1RIC = 1; //Priority Level = 1 TA0IC
-
PDF
H_TTIG_RIWETA_-_PC.pdf
Spritzgegossene Funktionsteile bis 16.000 g ■ Thermoformen Im Vakuumverfahren gezogene Teile bis 2000 x 2000 mm Werkstoffnummer 2301 Dichte ISO 1183 1,20 g/cm3 Probekörperzustand Mechanische Eigenschaften Streckspannung ISO 527 63 MPa Zugfestigkeit ISO 527 - MPa Reißdehnung ISO 527 >80 % Zug-E-Modul
-
Datei
EEVBLOG_CMU200.txt
WCDMA and data E2E for CMU-B21/var. 14 B66: Versatile base band board B83: HW option for CMU200: CDMA2000 Signalling Unit (requires CMU-U65) B85: HW-option for CMU200: 8K/8K ENH/13K speech codec for CDMA2000 signalling unit CMU-B83/V12 B89: HW option for CMU200: 1xEV-DO Signalling Module (requires CMU-B83
in „Option B41 bei einer CMU200 nachrüsten.“ · HF, Funk und Felder ·
-
Datei
crt0.s
--------------- .module crt0 .globl _main .area _HEADER (ABS) ;; Reset vector .org 0 jp init .org 0x08 reti .org 0x10 reti .org 0x18 reti .org 0x20 reti .org 0x28 reti .org 0x30 reti .org 0x38 reti .org 0x100 init: ;; Stack at the top of memory. ld sp,#0xffff ;; Initialise global variables call gsinit
in „Retro Fieber: Z80 oder 68000 ?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
log.txt
% avrdude -c dragon_isp -P usb -p t45 -vvvv -B 10 avrdude: Version 6.2 Copyright (c) 2000-2005 Brian Dean, http://www.bdmicro.com/ Copyright (c) 2007-2014 Joerg Wunsch System wide configuration file is "/etc/avrdude.conf" User configuration file is "/home/nusse/.avrduderc" User configuration
in „AVR Dragon Probleme: RSP_FAILED“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Yumurta.c
; sek=0; } if (sek==0 && dez==0 && min==0 && ADC<30000) { cli(); a=10; while (ADC<30000 && a>00) { x=600; a=a--; while (x>100&&(ADC<30000)) { x=x--; PORTC=0b10011111; _delay_us(100); PORTC=0b10001111; _delay_us(x); } x=100; while(x>0&&(ADC<30000)) { x=x--; ausgabe(); } } PORTC=0b00000111; PORTD=0b00000000; _delay_ms(2000); sei(); while (ADC<30000) {} min=0; dez=0; sek=0; i=190; } ausgabe(); } } ISR (TIMER1_OVF_vect) { sek=sek--; if (sek<0) { sek=9; dez=dez--; if (dez<0) { dez=5; min=min--; } } TCNT1=31250; }
in „Programme haben plötzlich bugs. AVR Studio 4 und STK500“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
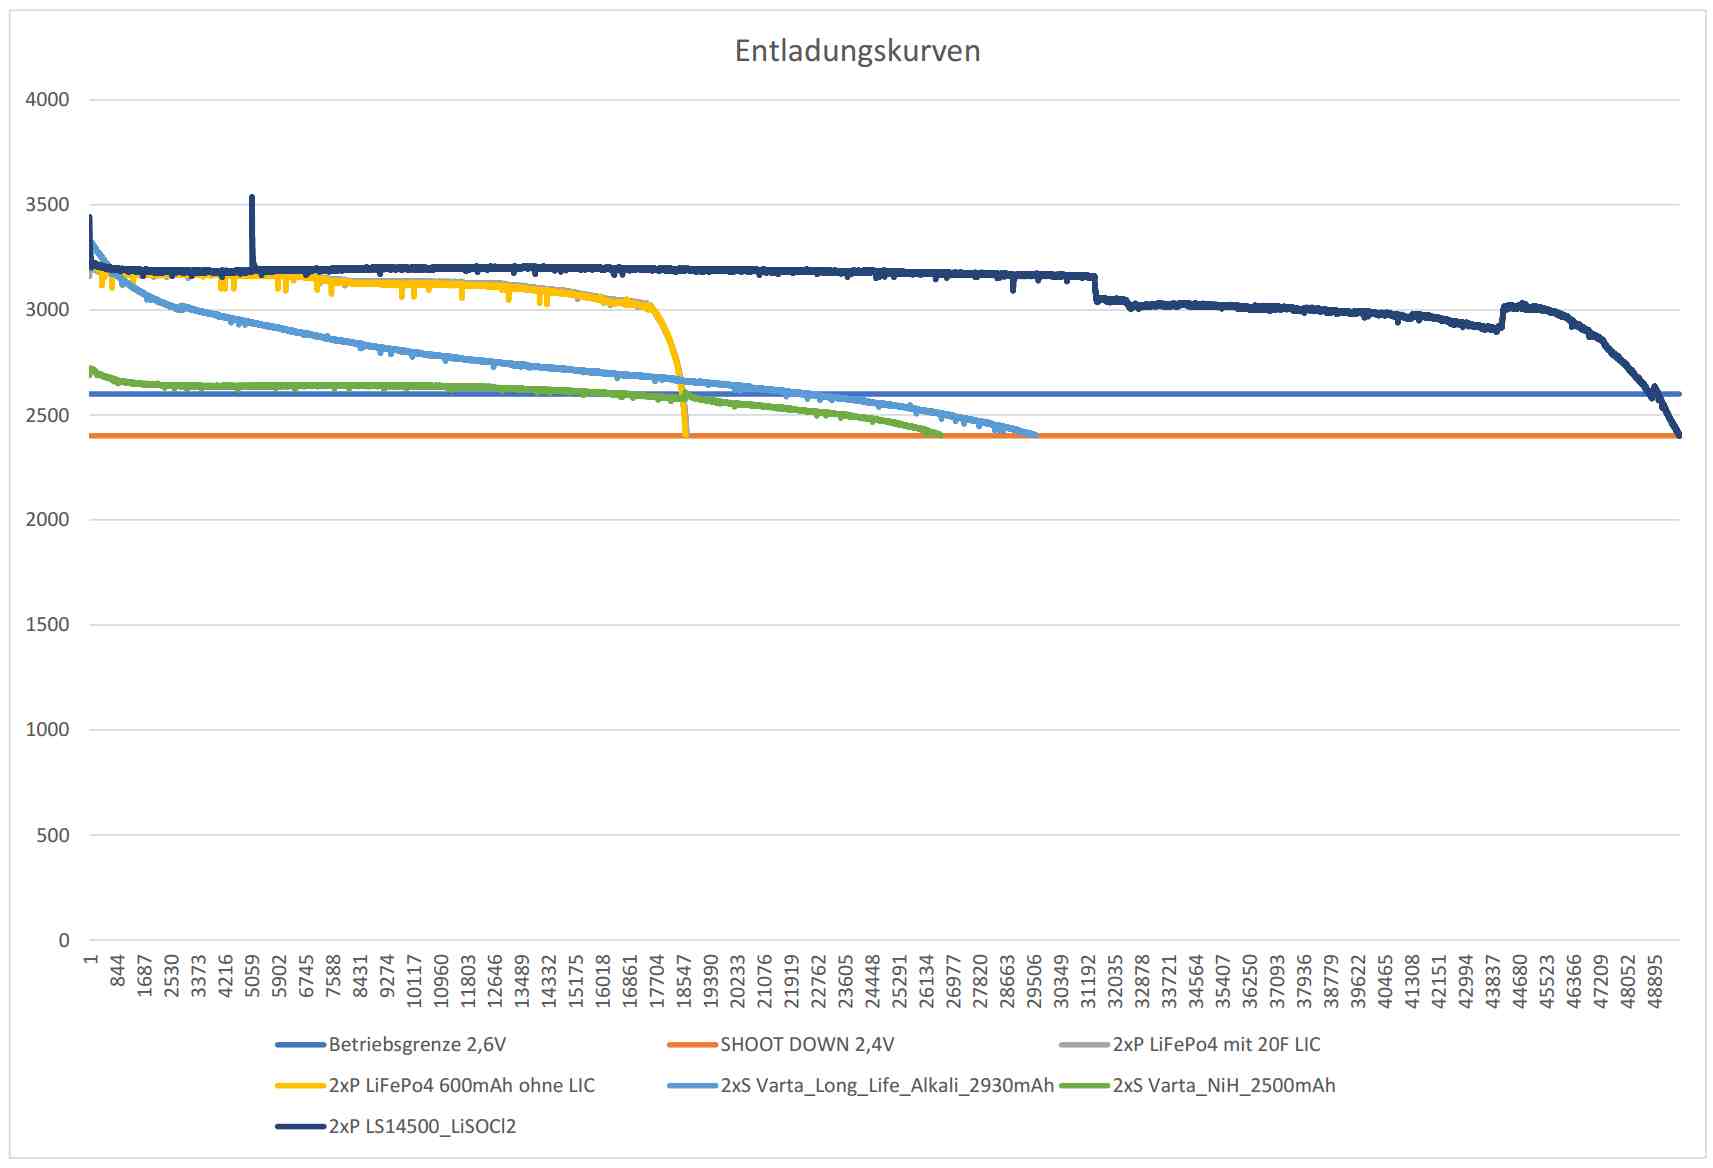
Diagramm verschiedener Entladungskurven
Entladungskurven 4000 3500 3000 2500 2000 1500 1000 500 0 1 844 1857 2530 3373 4216 5059 5902 6745 7588 8431 9274 10117 10960 11803 12646 13489 14332 15175 16018 16861 17704 18547 19390 20233 21076 21919 22762 23605 24448 25291 26134 26977
in „ESP8266 mit 3 AAA Batterien Versorgen“ · Mikrocontroller und Digitale Elektronik · · Diagramme
-
Datei
sdram.c
**********************/ void sdramInit(void) { volatile unsigned int i, dummy = dummy; // SCS &= ~0x00000002; // SCS |= 0x00000002; EMC_CTRL = 0x00000001; PCONP |= 0x00000800; /* Turn on EMC PCLK */ PINSEL4 = 0x50000000; #ifdef USE_32_BIT_DATABUS PINSEL5 = 0x55010115; PINSEL7 = 0x55555555; #else PINSEL5
in „OpenOCD Probleme bei Konfiguration des externen Speichers beim LPC2478“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
fft232slow.asm
buffer ldi CH, FFT_N/2 ;Number of elements ub_l1: lpmw A, Z+ ;Get a vector value (A = r, B = i) ldiw X, BflyBuf ; addw X, A ; ldw A, X+ ; ldw B, X+ ;/ FMULS16 A, A, T4, T2 ;A = sqrt(A * A + B * B); 0..32767 (scalar) FMULS16 B, B, T8, T6 ; addw T2, T6 ; adcw T4, T8 ; SQRT32 ;/ movw T2L, AL ; AL = sqrt(
in „Schnelle FFT in Assembler“ · Digitale Signalverarbeitung / DSP / Machine Learning ·
-
PDF
datenblatt_pic.pdf
BLOCK DIAGRAM OF THE TIMER0/WDT PRESCALER CLKOUT (= FOSC/4) Data Bus M 8 0 1 RA4/T0CKI U M SYNC pin X U 2 TMR0 reg 1 0 X Cycles T0SE T0CS PSA Set Flag bit T0IF on Overflow 0 M 8-bit Prescaler U Watchdog 1 X 8 Timer 8 - to - 1 MUX PS2:PS0 PSA 0 1 WDT Enable bit M U X PSA WDT Time-out Note: T0CS, T0SE,
in „Flußdiagramm Digitale stoppuhr auf PIC 16F84A“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
16F84.pdf
BLOCK DIAGRAM OF THE TIMER0/WDT PRESCALER CLKOUT (= FOSC/4) Data Bus M 8 0 1 RA4/T0CKI U M SYNC pin X U 2 TMR0 reg 1 0 X Cycles T0SE T0CS PSA Set Flag bit T0IF on Overflow 0 M 8-bit Prescaler U Watchdog 1 X 8 Timer 8 - to - 1 MUX PS2:PS0 PSA 0 1 WDT Enable bit M U X PSA WDT Time-out Note: T0CS, T0SE,
in „Probleme mit Taktversorgung auf Steckbrett“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
stm32f4x7_eth_bsp.h
ETH_LINK_GPIO_PORT GPIOB #define ETH_LINK_GPIO_CLK RCC_AHB1Periph_GPIOB // PHY registers #define PHY_MICR 0x11 // MII Interrupt Control Register #define PHY_MICR_INT_EN ((uint16_t)0x0002) // PHY Enable interrupts #define PHY_MICR_INT_OE ((uint16_t)0x0001) // PHY Enable output interrupt events #define PHY_MISR 0x12 // MII Interrupt Status and Misc. Control Register #define PHY_MISR_LINK_INT_EN ((uint16_t)0x0020) // Enable Interrupt on change of link status #define PHY_LINK_STATUS ((uint16_t)0x2000) // PHY link
in „STM32-E407 Ethernet / UDP“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
TLC5749.c
TLC5749.c * * Created: 19.12.2014 16:18:08 * Author: Christian */ volatile char lightdata [ 36 ] = { 0x00,0x00,0x00,0x00,0x00,0x00, 0x00,0x00,0x00,0x00,0x00,0x00, 0x00,0x00,0x00,0x00,0x00,0x00, 0x00,0x00,0x00,0x00,0x00,0x00, 0x00,0x00,0x00,0x00,0x00,0x00, 0x00,0x00,0x00,0x00,0x00,0x00 }; volatile char LSB [ 24 ] = { 0x23,0x22,0x20,0x1F,0x1D,0x1C, 0x1A,0x19,0x17,0x16,0x14,0x13, 0x11,0x10,0xE ,0xD ,0xB ,0xA , 0x8, 0x7 ,0x5 ,0x4 ,0x2 ,0x1 }; volatile char MSB [ 24 ] = { 0x22,0x21,0x1F,0x1E,0x1C,0x1B, 0x19,0x18,0x16,0x15,0x13,0x12
in „TLC5947 und ATmega16 Bitmanipulation“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
carrera.asm
Lux' LCD-Routinen .def wh = r27 ; für Hannes Lux' LCD-Routinen .def WR0 = r30 .def WR1 = r31 .org 0x000 rjmp main ; Reset Handler .org INT0addr rjmp int0_handler ; IRQ0 Handler .org INT1addr rjmp int1_handler ; IRQ1 Handler .org OC1Aaddr rjmp timer1_compare ; Timer Compare Handler .include "lcd_4x40
in „Entprellung / Blockieren von Mehrfachinput“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
reg,unsigned char data); unsigned char MPU6050_Read_Reg(unsigned char reg); void main(void) { LATA=0x00; TRISA=0x00; ANSELA=0x00; LATB=0x00; TRISB=0x00; ANSELB=0x00; LATC= 0b11111101; TRISC=0b11111100; ANSELC=0x00; LATD=0x00; TRISD=0x00; ANSELD=0x00; LATE=0x00; PORTE=0x00; TRISE=0x00; INTCONbits.GIE=
in „PIC18 + MPU6050 funktionier nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
filter.c
Bestimmung der // Fehler der drei mit float rechnenden Filteralgorithmen float referenceFilter(float x) { static double y; y += K * (x - y); return (float)y; } // Originalfilter des TE mit float gerechnet float classicFilter(float x) { static float y; // y += K * (x - y); y += (float)((float)K * (float
in „PT1 Filter mit sehr kleine Koeffizienten und Rundung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
LCD-I2C.pdf
1 2 3 4 5 6 t t n f h g w f e i i o p e L R t t t t t t A B B B B B B A X4 6Pin Tasten 30 - 500 1 2 3 4 5 6 1 D CD4051 470-1050 D A 11 PCF8574 Low 1,5V V 10 B 100 µA * 2000 = 0,2 V C 9 13 X0 14 X1 X 3 15 6 X2 INH 12 X3 1 X4 5 X5 IN7 2 X6 S E IN8 4 X7 S E V V 8 7 CD4051B IC2
in „Pollin Display HB10401“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
lcd.c
/////////////////////////////// void InitLCD( void ) { BootLCD(); } void BootLCD( void ) { DDRD = 0xFF; PORTD = 0xFF; delay_ms( 2000 ); WriteLCDData8( 0xCF ); delay_ms( 5 ); WriteLCDData8( 0xCF ); delay_ms( 5 ); WriteLCDData8( 0xCF ); delay_ms( 5 ); // // Set to 4-bit Mode // WriteLCDData8( 0xDF );
in „HD44780 unter CodeVision“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
TLC59116.pdf
00 (2) LED12 output state control (1) R = read, W = write (2) Default value LDRx = 00: LED driver x is off (default power-up state). LDRx = 01: LED driver x is fully on (individual brightness and group dimming/blinking not controlled). LDRx = 10: LED driver x is individual brightness can be controlled
in „Verstehe TWI überhaupt nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
GTR_Neu_IV.c
ms; uint32_t Wait1; uint32_t Wait2; uint32_t Timeout1; uint32_t Timeout2; uint8_t SendHeader [] = {0x3a,'V', 'A', 'L', 0x00, 'V','M', 0x00,0x01,0x00,0x01,'A', 0xff,0xff,0xff,0xff,0xff,0xff,0xff,'V','a', 'r', 'i', 'a', 'b', 'l', 'e', 'R', 0x0A,0xff,0xff,0xff,0xff,0xff,0xff,0xff,0xff,0xff,0xff,0xff,0xff
in „Taschenrechner Kommunikation“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
lmv7219.pdf
DCK 5 1000 178.0 8.4 2.25 2.45 1.2 4.0 8.0 Q3 LMV7219M7X SC70 DCK 5 3000 178.0 8.4 2.25 2.45 1.2 4.0 8.0 Q3 LMV7219M7X/NOPB SC70 DCK 5 3000 178.0 8.4 2.25 2.45 1.2 4.0 8.0 Q3 Pack Materials-Page 1 PACKAGE MATERIALS INFORMATION www.ti.com 26-Jan-2013 *All dimensions
in „Operations verstärker als Komparator verschlechterung der Slewrate?“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
PSOne.h
<PB5); } return 0; } // Ende Beispiel * * */ #ifndef PSONE_H_ #define PSONE_H_ #define PSOne_Left 0x0001 #define PSOne_Down 0x0002 #define PSOne_Right 0x0004 #define PSOne_Up 0x0008 #define PSOne_Start 0x0010 #define PSOne_JoyR 0x0020 // Joystick rechts drücken #define PSOne_JoyL 0x0040 // Joystick links drücken #define PSOne_Select 0x0080 #define PSOne_Sqr 0x0100 #define PSOne_X 0x0200 #define PSOne_O 0x0400 #define PSOne_Tri 0x0800 #define PSOne_R1 0x1000 #define PSOne_L1 0x2000 #define PSOne_R2 0x4000 #define PSOne_L2 0x8000 typedef
-
Datei
log2.txt
65 10 8 0 no 4096 8 0 9000 9000 0x00 0x00 flash 65 10 256 0 yes 262144 256 1024 4500 4500 0x00 0x00 lfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 hfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 efuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 lock 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 calibration 0 0 0 0 no 1 0 0 0 0 0x00 0x00 signature 0 0 0 0 no 3 0 0 0 0 0x00 0x00 Programmer Type : STK500V2 Description : Atmel STK500 Version 2.x firmware Programmer Model: AVRISP Hardware
in „Bootloader mega2560“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
erase.txt
0xff 0xff flash 33 6 128 0 yes 131072 256 512 4500 45 00 0xff 0xff lfuse 0 0 0 0 no 1 0 0 9000 90 00 0x00 0x00 hfuse 0 0 0 0 no 1 0 0 9000 90 00 0x00 0x00 efuse 0 0 0 0 no 1 0 0 9000 90 00 0x00 0x00 lock 0 0 0 0 no 1 0 0 9000 90 00 0x00 0x00 calibration 0 0 0 0 no 4 0 0 0 0 0x00 0x00 signature 0 0 0 0 no 3 0 0 0 0 0x00 0x00 Programmer Type : Arduino Description : Arduino Hardware Version: 2 Firmware Version: 1.18 Topcard : Unknown Vtarget : 0.0 V Varef : 0.0 V Oscillator : Off SCK period : 0.1 us avrdude: AVR device
in „ATMega128a verflasht Turigy 9xr“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main_Os.asm
r0, [sp, #4] 1a: f7ff fffe bl 0 <main> 1e: 2878 cmp r0, #120 ; 0x78 20: bfcc ite gt 22: f44f 5200 movgt.w r2, #8192 ; 0x2000 26: f44f 4200 movle.w r2, #32768 ; 0x8000 2a: 8322 strh r2, [r4, #24] 2c: f44f 4280 mov.w r2, #16384 ; 0x4000 30: 8322 strh r2, [r4, #24] 32: e7fe b.n 32 <main+0x32> 34: 40023800 .word 0x40023800 38: 40020c00 .word 0x40020c00
in „C++ Exceptions mit gcc-arm-none-eabi“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.cpp
x1[1] ); double betrag_x2 = sqrt( x2[0]*x2[0] + x2[1]*x2[1] ); double skalarprodukt = x1[0] * x2[0] + x1[1] * x2[1]; double determinante = x1[1] * x2[0] - x1[0] * x2[1]; double res = /*acos*/ ( skalarprodukt
in „Netzmessung: Frequenz, Amplitude, Phase aus ADC-Samples“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
lcd_drv.h
0x80 #define LCD_LINE2 (0x80 + 0x40) #endif #ifdef LCD_2X20 #define LCD_COLUMN 20 #define LCD_LINE 2 #define LCD_LINE1 0x80 #define LCD_LINE2 (0x80 + 0x40) #endif #ifdef LCD_2X24 #define LCD_COLUMN 24 #
in „Benötige Hilfe bei 4x20 LCD Treiber von Peter Danegger“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
; USART_PutChar(&USARTE0,senden ); while(USART_IsTXDataRegisterEmpty(&USARTE0) == 0){}; _delay_ms(2000); } } void usart_init(void) { PORTE.DIRSET = PIN3_bm; // PD3 (TXF0) as output, Transmitter PORTE.DIRCLR = PIN2_bm; // PD2 (RXF0) as input, Receiver USARTE0.CTRLA = 0x05; //Interruptlevel low: fuer TX
in „Xmega128A1 USART sendet falsche Zeichen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
log.txt
65 10 8 0 no 4096 8 0 9000 9000 0x00 0x00 flash 65 10 256 0 yes 262144 256 1024 4500 4500 0x00 0x00 lfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 hfuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 efuse 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 lock 0 0 0 0 no 1 0 0 9000 9000 0x00 0x00 calibration 0 0 0 0 no 1 0 0 0 0 0x00 0x00 signature 0 0 0 0 no 3 0 0 0 0 0x00 0x00 Programmer Type : STK500V2 Description : Atmel STK500 Version 2.x firmware Programmer Model: AVRISP Hardware
in „Bootloader mega2560“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
D865GBF_D865GLC_TechProdSpec.pdf
MB SS 256 Mbit 32 M x 8/empty 8 256 MB SS 512 Mbit 32 M x 16/empty 4 512 MB DS 256 Mbit 32 M x 8/32 M x 8 16 512 MB SS 512 Mbit 64 M x 8/empty 8 1024 MB DS 512 Mbit 64 M x 8/64 M x 8 16 Note: In the second column, “DS” refers
in „VS: Intel D865GBF, Pentium 4 (3GHz/1M/800) SL7PM, Matrox G45“ · Markt ·