-
PDF
Schematic_Ventilsteuerung_2022-02-11.pdf
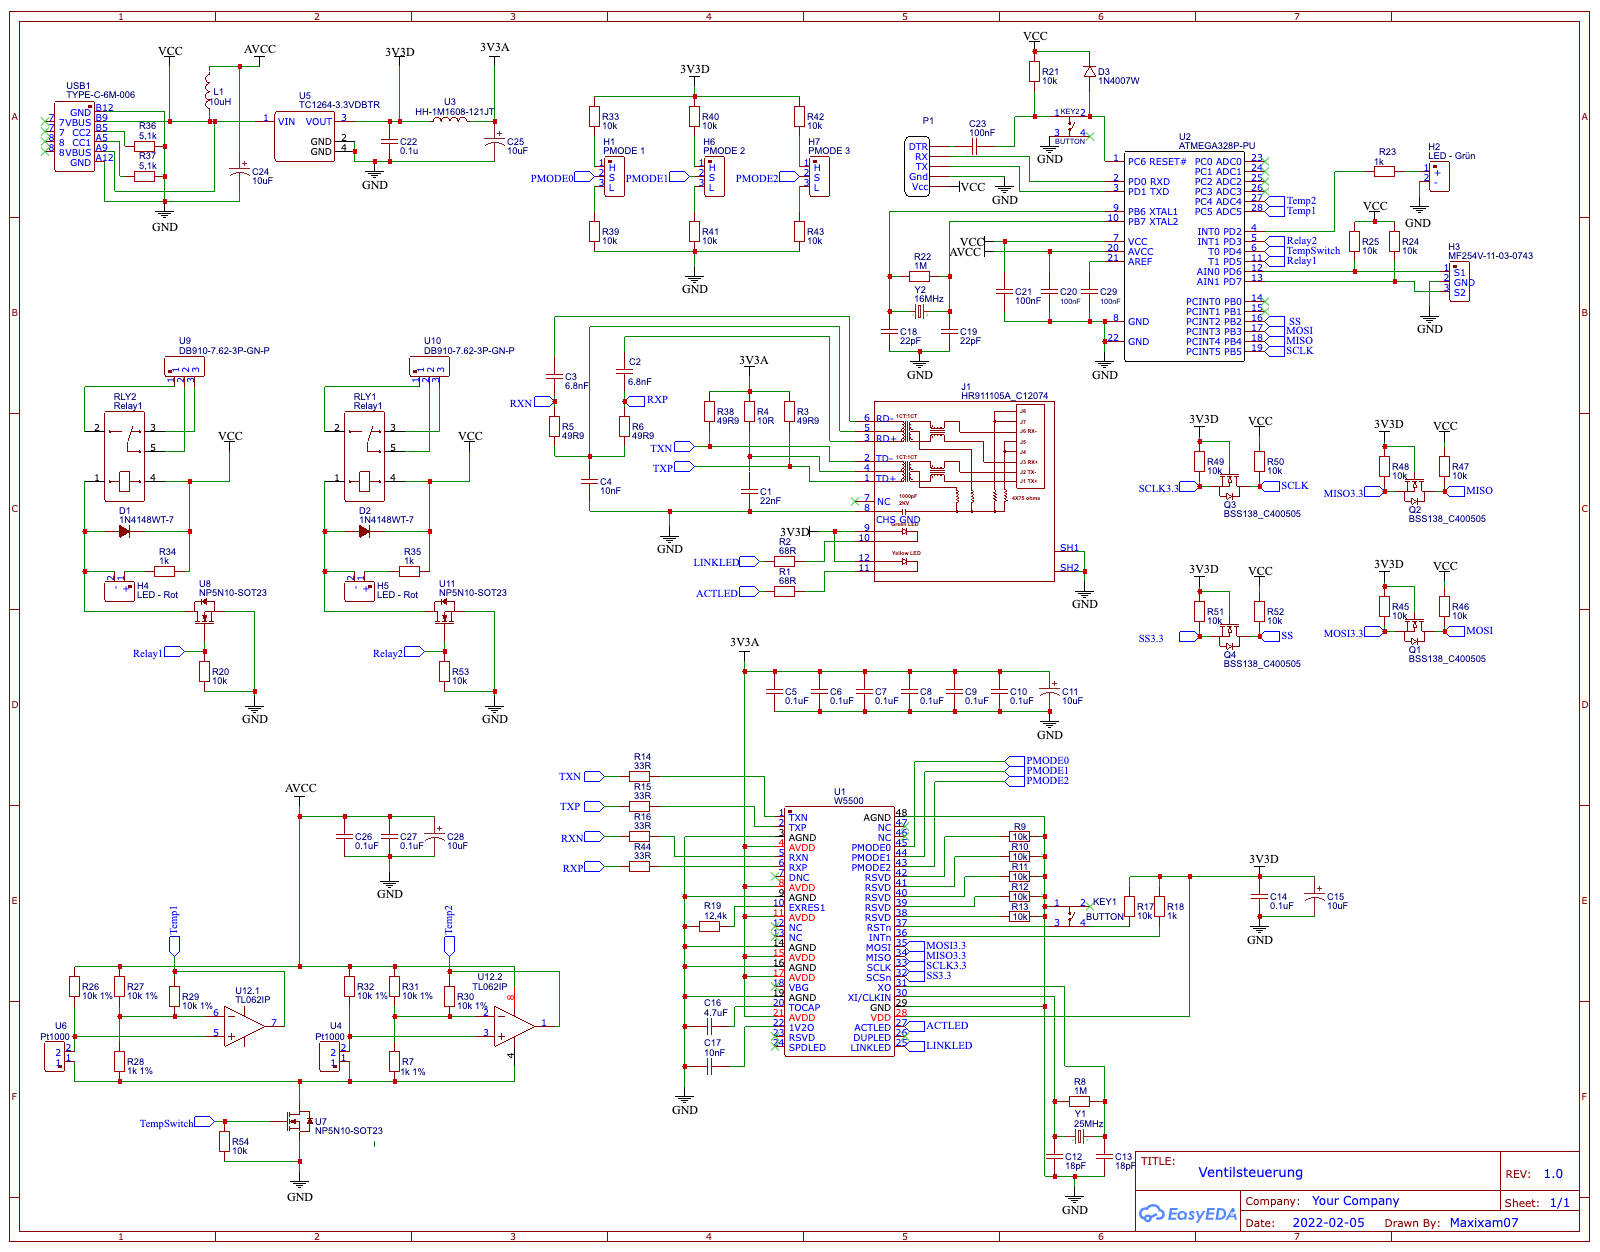
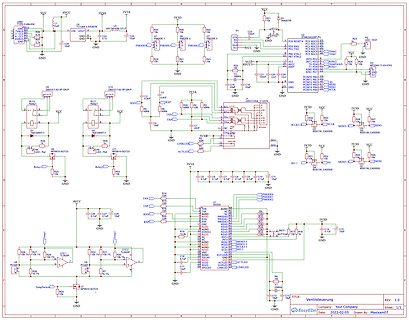
C30 10uH U5 U3 R33 R40 R42 100nF 100nF U2 GND B12 TC1264-3.3VDBTR HH-1M1608-121JT 10k 10k 10k DTR ATMEGA328P-PU H2 77 VBUS B9 1 VIN VOUT 3 RX 1 23 R23 LED - Gr▯ün 7 B5 R36 H1 H6 H7 TX PC6 RESET# PC0 ADC0 120R 87 CC2 A5 5,1k GND 2 C22 PMODE 1 PMODE 2 PMODE 3 Gnd GND PC1 ADC1 24 1+ 88 CC1 A9 4 0.1u 10uF
in „Funktioniert diese Atmega328 Schaltung?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AVR_ASM_Tutorial.pdf
Bauteile wie LEDs, Taster oder LCDs angeschlossen werden. Der Port C (PC0-PC5) spielt beim AT90S4433/Atmega8 eine Sonderrolle: mit diesem Port können Analog-Spannungen gemessen werden. Aber dazu später mehr! An Pin 17-19 ist die Stiftleiste zur Verbindung mit dem ISP-Programmer angeschlossen, über den der
in „ASM Tutorial jetzt als PDF“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Mega32_mF_42.bas
oder ADCSR gemeldet werden, den jeweils ' .....anderen Registernamen einsetzen. ' ' Angepasst an Mega32, 16/11/2009 ' Ä, Ö, Ü, a, ö, ü, ß in den Charaktergenerator eingebaut, ' .....gemäß ASCII-Zeichensatz, deutsche Variante. ' ' Hinweis zum Mega32: ' - JTAG-Interface des Mega32 muss ausgeschaltet sein
in „Pollin 16080 Touch mit ATMEGA32 und BASCOM“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
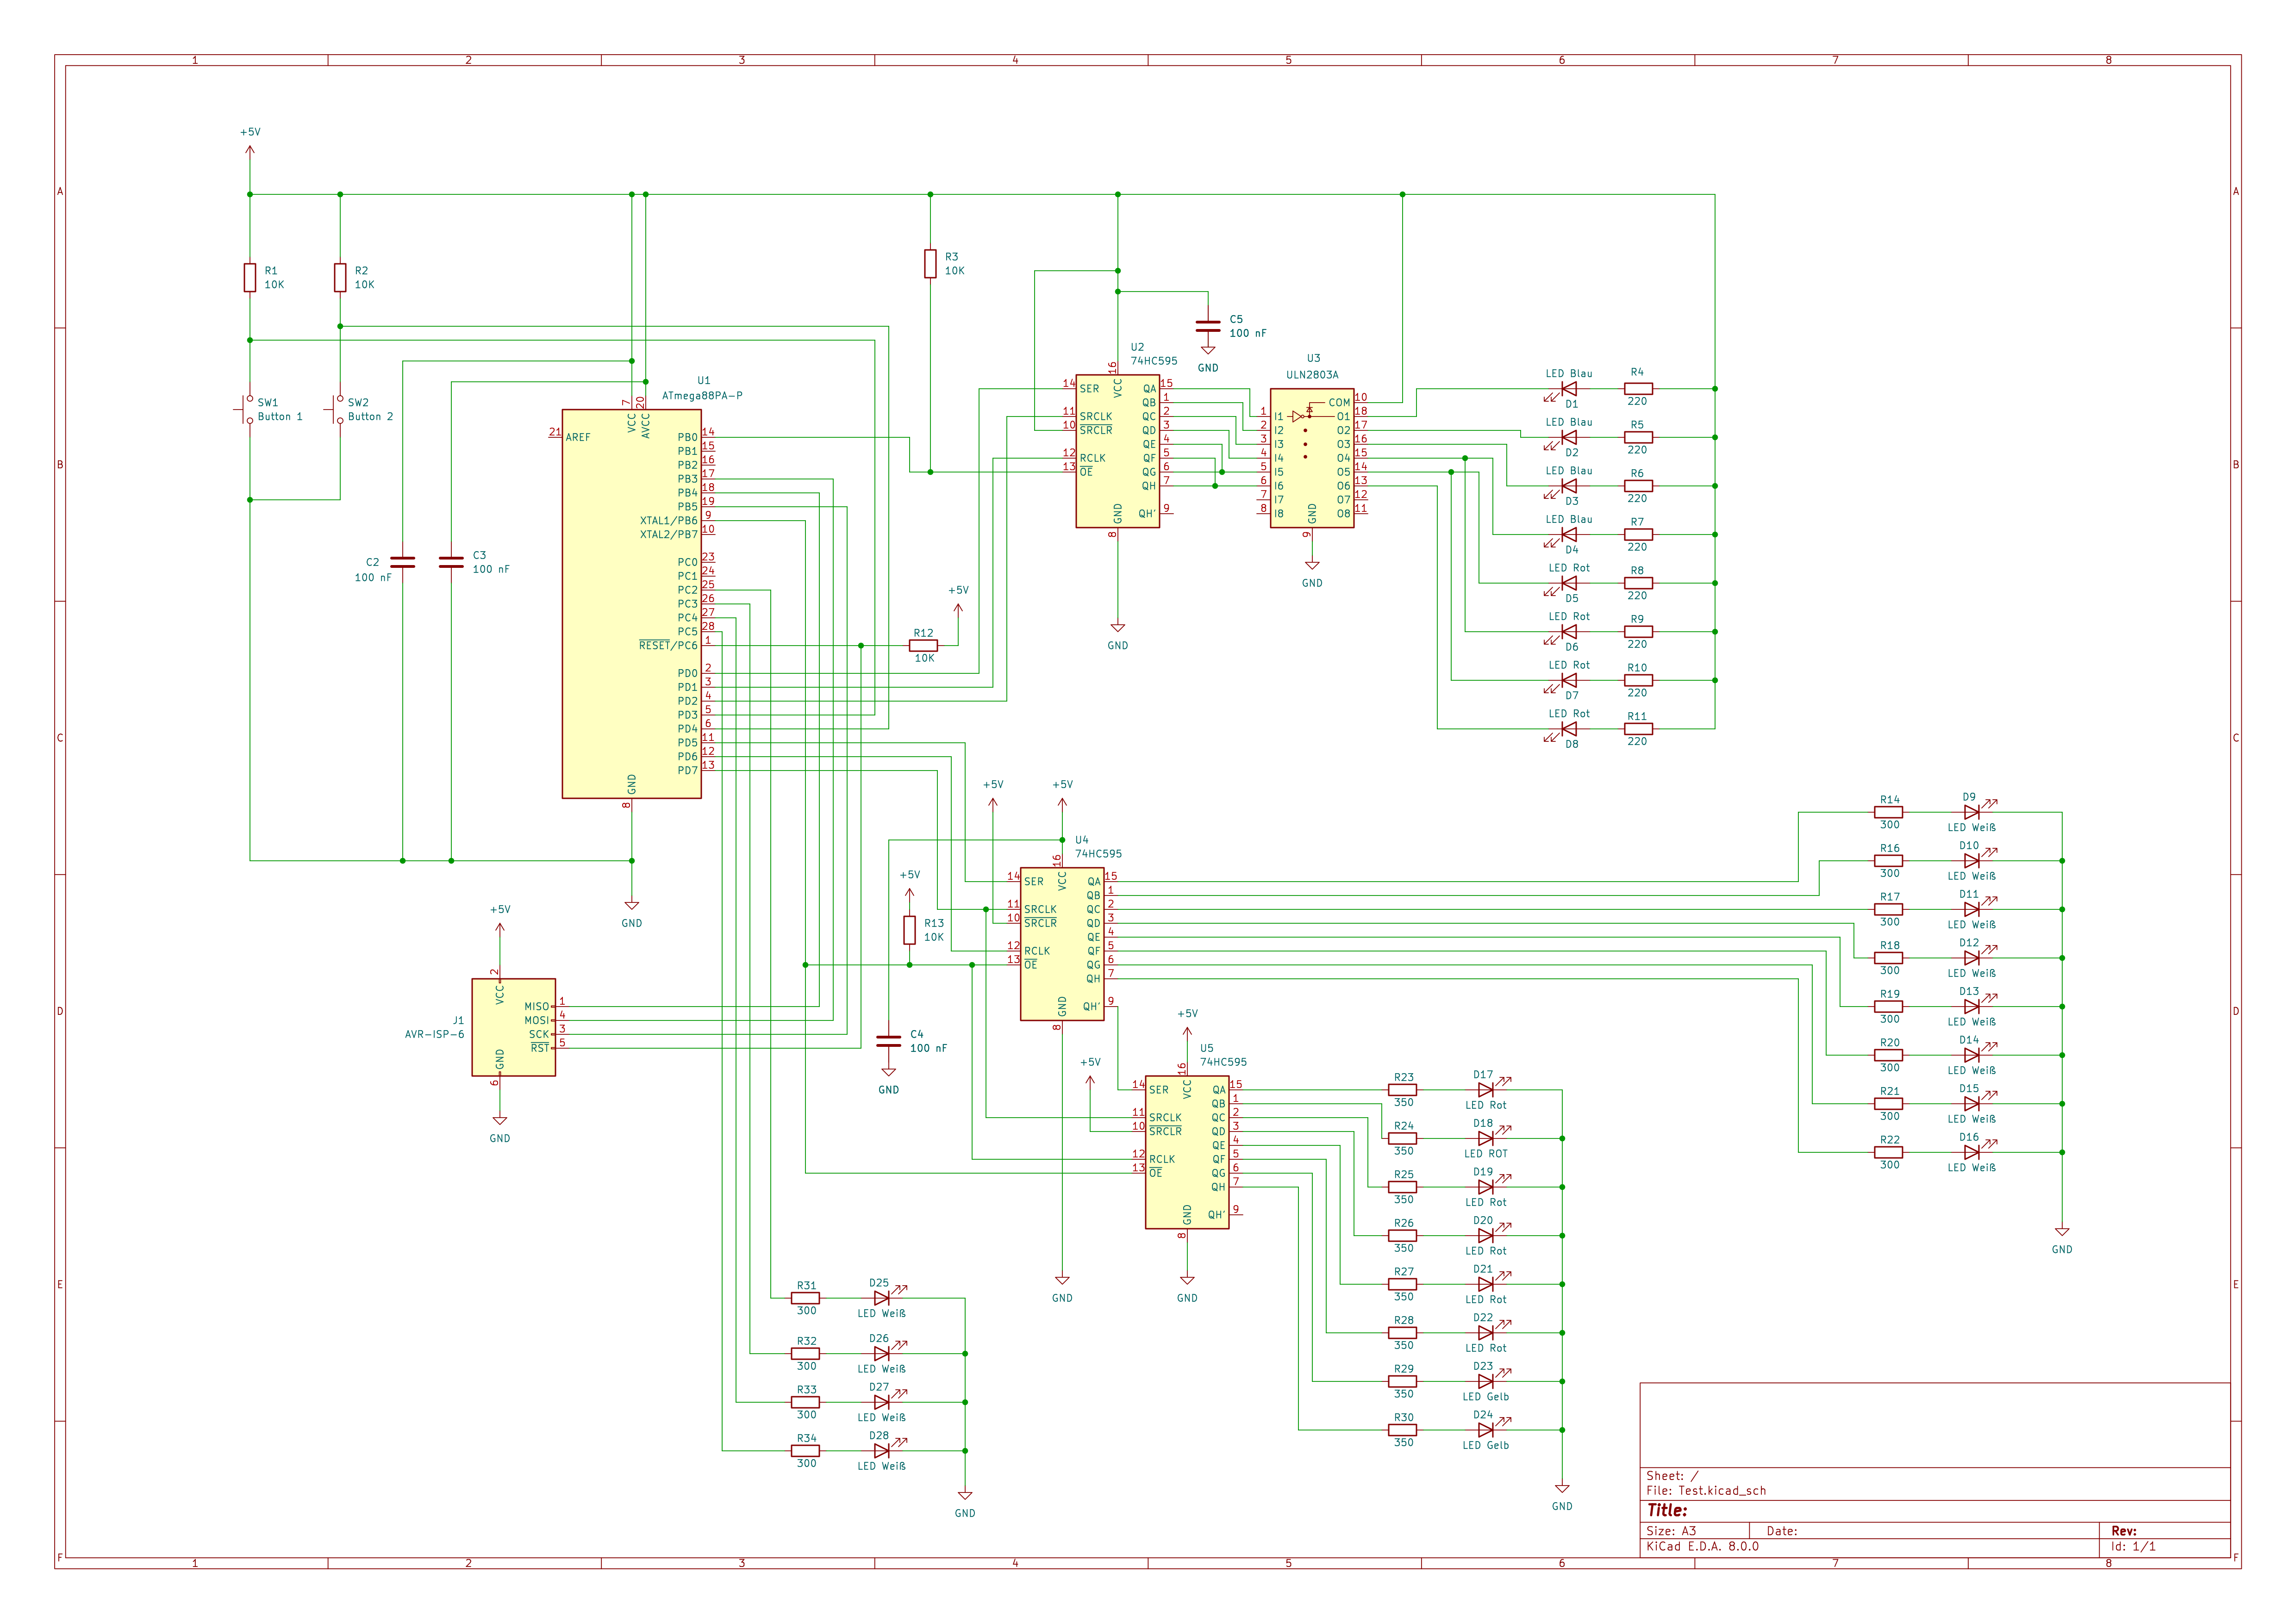
Schaltplan einer Mikrocontroller-Schaltung mit LEDs
SW1 Button 1, SW2 Button 2, R1 10K, U1 ATmega85A-P, R2 470, R3 10K, U2 74HC595, LED Blau R4 220, LED Blau R7 220, LED Rot R8 220, LED Rot R11 220, LED Rot R12 220, LED Rot R16 220, LED Rot R19 220, LED Rot R20 220, LED Rot R21 220, LED Rot R23
in „Fragen zur Schaltung“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
 Bild
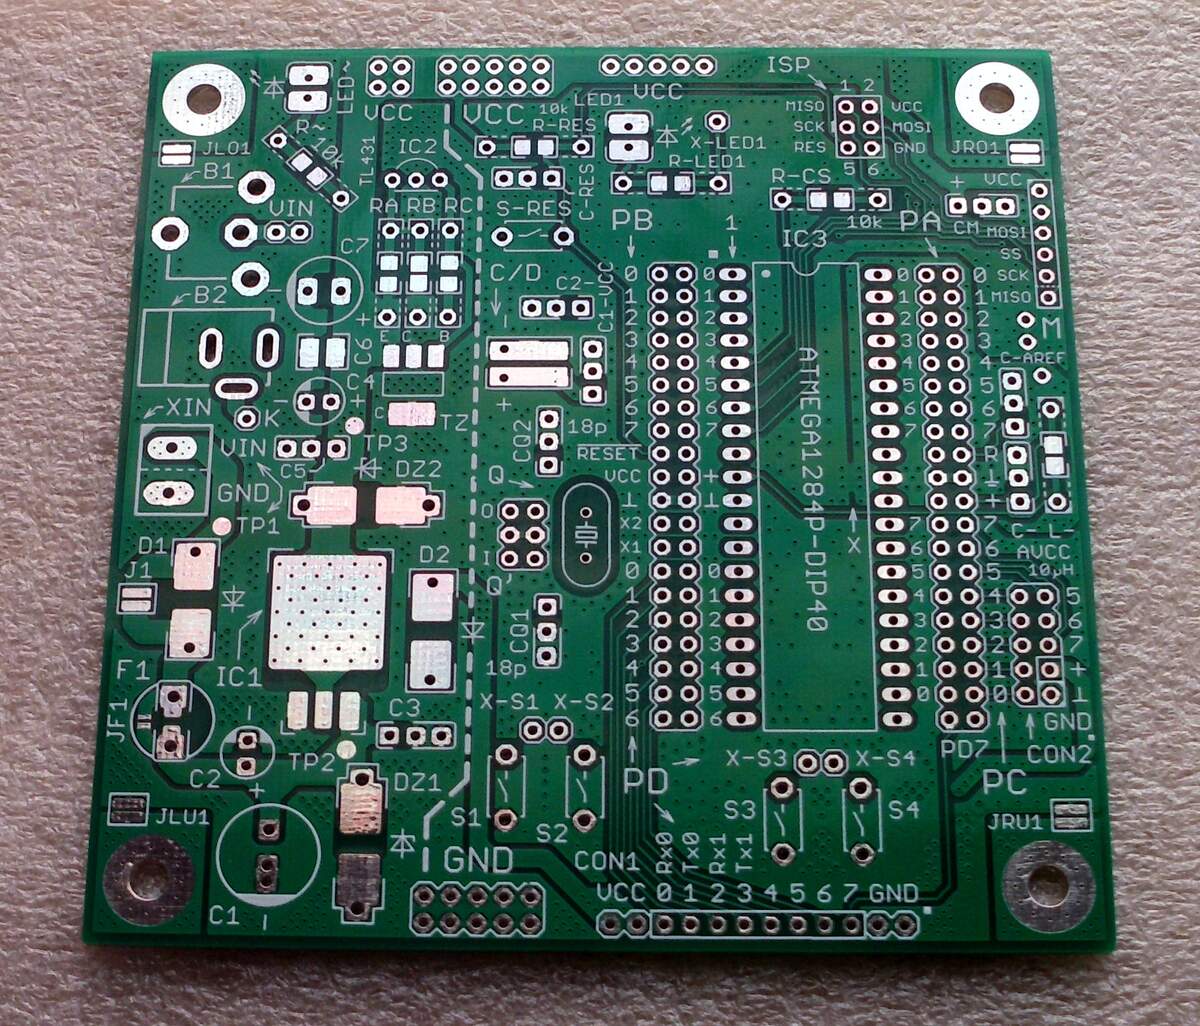
Bestückungsdruck einer grünen Leiterplatte
MIS0 2 J3 3 M 4 C-AREF 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 33 34 35 36 37 38 39 40 41 42 43 44 45 46 47 48 49 50 51 52 53 54 55 56 57 58 59 60 61 62 63 64 65 66 67 68 69 70 71 72 73 74 75 76 77 78 79 80 81 82 83 84 85 86 87 88 89 90 91 92 93 94 95 96 97 98 99 100 ATmega1284p-DIP40 AUCC 10uH GND PD7 CON2 PC S3 S4 X-S4 X-S3 6 5 4 3 2 1 0 GND 7 6 5 4 3 2 1 0 UCC 0 1 2 3 4 5 6 7 GND CON1 Rx0 Tx0 Rx1 Tx1 S2 S1 GND DZ1 TP2 C3 DZ2 TP3 RESET XIN X1 X2 X-S1 X-S2 18p 18p C2
in „Entwurf USB-UART-Converter, KiCad, bitte um Review“ · Platinen · · Platinenfotos
-
Datei
timer.c
// ATMega128L - 8 MHz #include <avr/io.h> #include <avr/interrupt.h> volatile uint8_t timer0_sys_clk; volatile uint8_t bad_vec_cnt; // Initialisierung von Timer0, CTC-Mode, 1ms, ISR enable void init_timer0( void) { // set CTC Mode, Prescaler f/32 -> ftimer = 250kHz, TCCR0 = ( 1 << CS01) | ( 1 << CS00) | ( 1 << WGM01); OCR0=250; bad_vec_cnt = 0; // clear bad interrupt counter timer0_sys_clk = 0; // clear timer0_sys_clk TIMSK = ( 1 << OCIE0); /
in „Probleme mit AVR Timer0 Interrupts“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
WvS-Sample.c
fuer eigene Projekte Version : 1.0 Date : 2007-11-34 Author : (c) Ferdinand Gierisch Chip type : ATMEGA32 Program type : Application Clock frequency : 14,756000 MHz ******************************************** */ // Include Dateien erweitern den Sprachumfang von C #include "global.h" // hier wird die
in „Probleme beim compilen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
MAIN.C
* Version: 1.0 * * Compiler: WinAVR AVRGCC 3.3 * * Datum: * * Autor: * * Takt: 8.00 MHz * * CPU: ATmega32L * * * * * *******************************************************************************/ #include <avr/io.h> // AVR I/O-Funktionen #include <math.h> #include "stdlib.h" // Standard-Funktionen
in „compilerangaben?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Timer.c
stdlib.h> #include <util/delay.h> #include <avr/interrupt.h> //... /* Es wird der Timer2 (8-Bit) eines ATmega32 verwendet, der mit einem Quarz mit 8 MHz betrieben wird. Im Abstand von 0,01 ms erzeugt der Timer einen Interrupt, also eine Frequenz von 100000 Hz (oder 100 kHz). Der Timer wird auf einen Prescaler
in „Verständnisfrage: Warten mit Timer“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
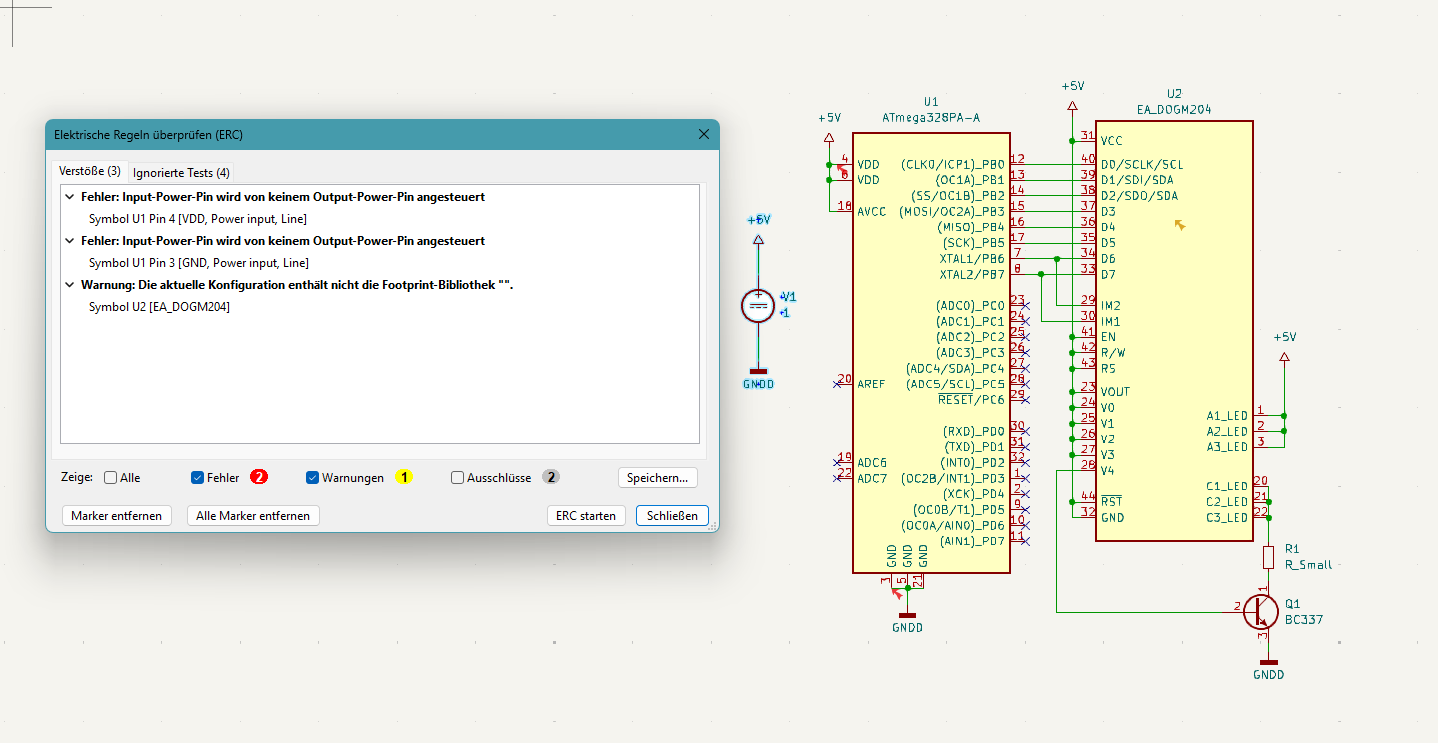
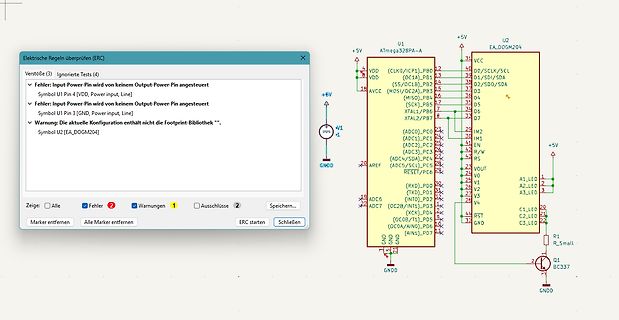
Schaltplan mit Fehlermeldung aus der ERC-Prüfung
Warnung: die aktuelle Konfiguration enthält nicht die Footprint Bibliothek. Symbol U2 [EA_DOGM204] U1 ATmega328PA-A U2 EA_DOGM204 VDD, VDD, AVCC, GND, GND, GNDD, +5V, +6V, +5V, 5V, 31, 39, 35, 36, 37, 34, 33, 32, 30, 29, 28, 27, 26, 25, 24, 23, 22, 21, 20, 19, 18, 17, 16, 15, 14, 13, 12, 11, 10, 9, 8, 7,
in „KiCAD 9.06: ERC mit unberechtigten Fehlern ?“ · Platinen · · Screenshots
-
Datei
makefile.txt
NOT tack on a 'UL' at the end, this will be done # automatically to create a 32-bit value in your source code. # Typical values are: # F_CPU = 1000000 # F_CPU = 1843200 # F_CPU = 2000000 # F_CPU = 3686400 # F_CPU = 4000000 # F_CPU = 7372800 # F_CPU = 8000000 # F_CPU = 11059200 #
in „makefile problem - multiple target patterns“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Makefile.txt
NOT tack on a 'UL' at the end, this will be done # automatically to create a 32-bit value in your source code. # Typical values are: # F_CPU = 1000000 # F_CPU = 1843200 # F_CPU = 2000000 # F_CPU = 3686400 # F_CPU = 4000000 # F_CPU = 7372800 # F_CPU = 8000000 # F_CPU = 11059200 #
in „probleme bei kompilierung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Makefile.txt
NOT tack on a 'UL' at the end, this will be done # automatically to create a 32-bit value in your source code. # Typical values are: # F_CPU = 1000000 # F_CPU = 1843200 # F_CPU = 2000000 # F_CPU = 3686400 # F_CPU = 4000000 # F_CPU = 7372800 # F_CPU = 8000000 # F_CPU = 11059200 #
in „Atmega16, LED-Blinken, Timer, C-Prog.“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Makefile.txt
NOT tack on a 'UL' at the end, this will be done # automatically to create a 32-bit value in your source code. # Typical values are: # F_CPU = 1000000 # F_CPU = 1843200 # F_CPU = 2000000 # F_CPU = 3686400 # F_CPU = 4000000 # F_CPU = 7372800 # F_CPU = 8000000 # F_CPU = 11059200 #
in „WinAVR PonyProg Makefile“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
usart.cpp
Fleury <pfleury@gmx.ch> http://tinyurl.com/peterfleury File: $Id: uart.c,v 1.15.2.4 2015/09/05 18:33:32 peter Exp $ Software: AVR-GCC 4.x Hardware: any AVR with built-in UART, License: GNU General Public License DESCRIPTION: An interrupt is generated when the UART has finished transmitting or receiving
in „ISR Code schneller machen?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
MapCom.pdf
PIU2015NLA3 DS2401 GND Y1Y OUT4T PIU1017PB7 (OC2/OC1C) PA7 (AD7) PIU1044D7 AD2 PIU207 D6 Q6 PIU2014NLA2 32.768 KHz PIU1018TOSC2/PG3 AD1 PIU208 D7 Q7 PIU2013NLA1 PIU1019 PIU10358 AD0 PIU209 PIU2012NLA0 PIY101 PIY103 TOSC1/1PG4 PC0 (A8) PIU10369 D8 Q8 INA_M0M 25 PC1 (A9) 37 A10 GND 10 P_ONO PI26025PD0 (SCL/
in „[V] Weiterer M8, GPS, GSM Siemens M20, ATmega128“ · Markt ·
-
Datei
RTC.C
unsigned char num1 ) { static char copy1[MAX_STRING]; char bak1[MAX_STRING]; strcpy(bak1, str1); if( num1<32 && num1<=strlen(bak1) ) { strncpy(copy1, bak1, num1 ); *(copy1+num1)=0; } // if( num1<32 && num1<=strlen(bak1) ) return copy1; } // char *lefts( char *str1, unsigned char num1 ) char *rights( char *str2
in „DS3231 RTCmit PC synchronisieren“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
bootload.lst
m162def.inc" 28 ;.include "m168def.inc" 29 30 ; set the FirstBootStart fuse on these AVRs: 31 ;.include "m32def.inc" 32 ;.include "m64def.inc" 33 ;.include "m644def.inc" 34 ;.include "m128def.inc" 35 ;.include "m1281def.inc" 36 ;.include "m2561def.inc" 37 38 39 ; remove comment sign to exclude API-Call: 40 ; only on ATmega >= 8kB supported 41 // #define APICALL 0 42 43 ; remove comment sign to exclude Watchdog trigger: 44 // #define WDTRIGGER 0 45 46 ; remove comment sign to exclude CRC: 47 // #define CRC 0 48 49 ; remove
in „Peter Danneggers Bootloader (fastboot) für AVR-GCC-Toolchain“ · Projekte & Code ·
-
Datei
irmp.h
IRMP_DENON_PROTOCOL 8 // Denon, Sharp #define IRMP_RC6_PROTOCOL 9 // Philips etc #define IRMP_SAMSUNG32_PROTOCOL 10 // Samsung32: no sync pulse at bit 16, length 32 instead of 37 #define IRMP_APPLE_PROTOCOL 11 // Apple, very similar to NEC #define IRMP_RECS80EXT_PROTOCOL 12 // Philips, Technisat, Thomson
in „ATmega resettet dauernd“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AVR051.pdf
application note applies to all AVRs with External RC Oscillator except ATtiny11, Note ATtiny12, ATtiny28, ATmega163, and ATmega323. For these devices, please refer to the device datasheets. Introduction This application note describes how to use the external RC oscillator for the AVR ® Microcontroller. The AVR
in „AtMega32 mit Quarz betreiben. [siehe Bild]“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
ZX81_debug_drv.h
define AD9 36 // PC1 #define AD10 35 // PC2 #define AD11 34 // PC3 #define AD12 33 // PC4 #define AD13 32 // PC5 #define AD14 31 // PC6 #define AD15 30 // PC7 //Z80 control bus #define nIORQ 38 // PD7 #define nMREQ 39 // PG2 #define nRD 40 // PG1 #define nWR 41 // PG0 #define nRESET 50 // PB2 #define nBUSREQ
-
Datei
baseTimerD.h
\Timer.h Timer0 * **************************************************************************** * ATmega48-88-168-328\Timer.h Timer1 * **************************************************************************** * ATmega-164-324-644-1284\Timer.h Timer0, Timer2(*) **************************************
in „Knoten im Kopf, Klassen und Vererbung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
displayinterface_arduino.pdf
Arduino: Serielles Displayinterface für HD44780-Textdisplays für ATmega-basierendes System Prinzipiell besteht das „Serielle Displayinterface“ aus einem Firmwaresketch und einer Arduino-Library, die dieses Displayinterface (im Folgenden nur noch Interface benannt) ansteuern
in „Arduino: serielles Ansprechen eines HD44780 Displays über SoftSerial“ · Projekte & Code ·
-
 Bild
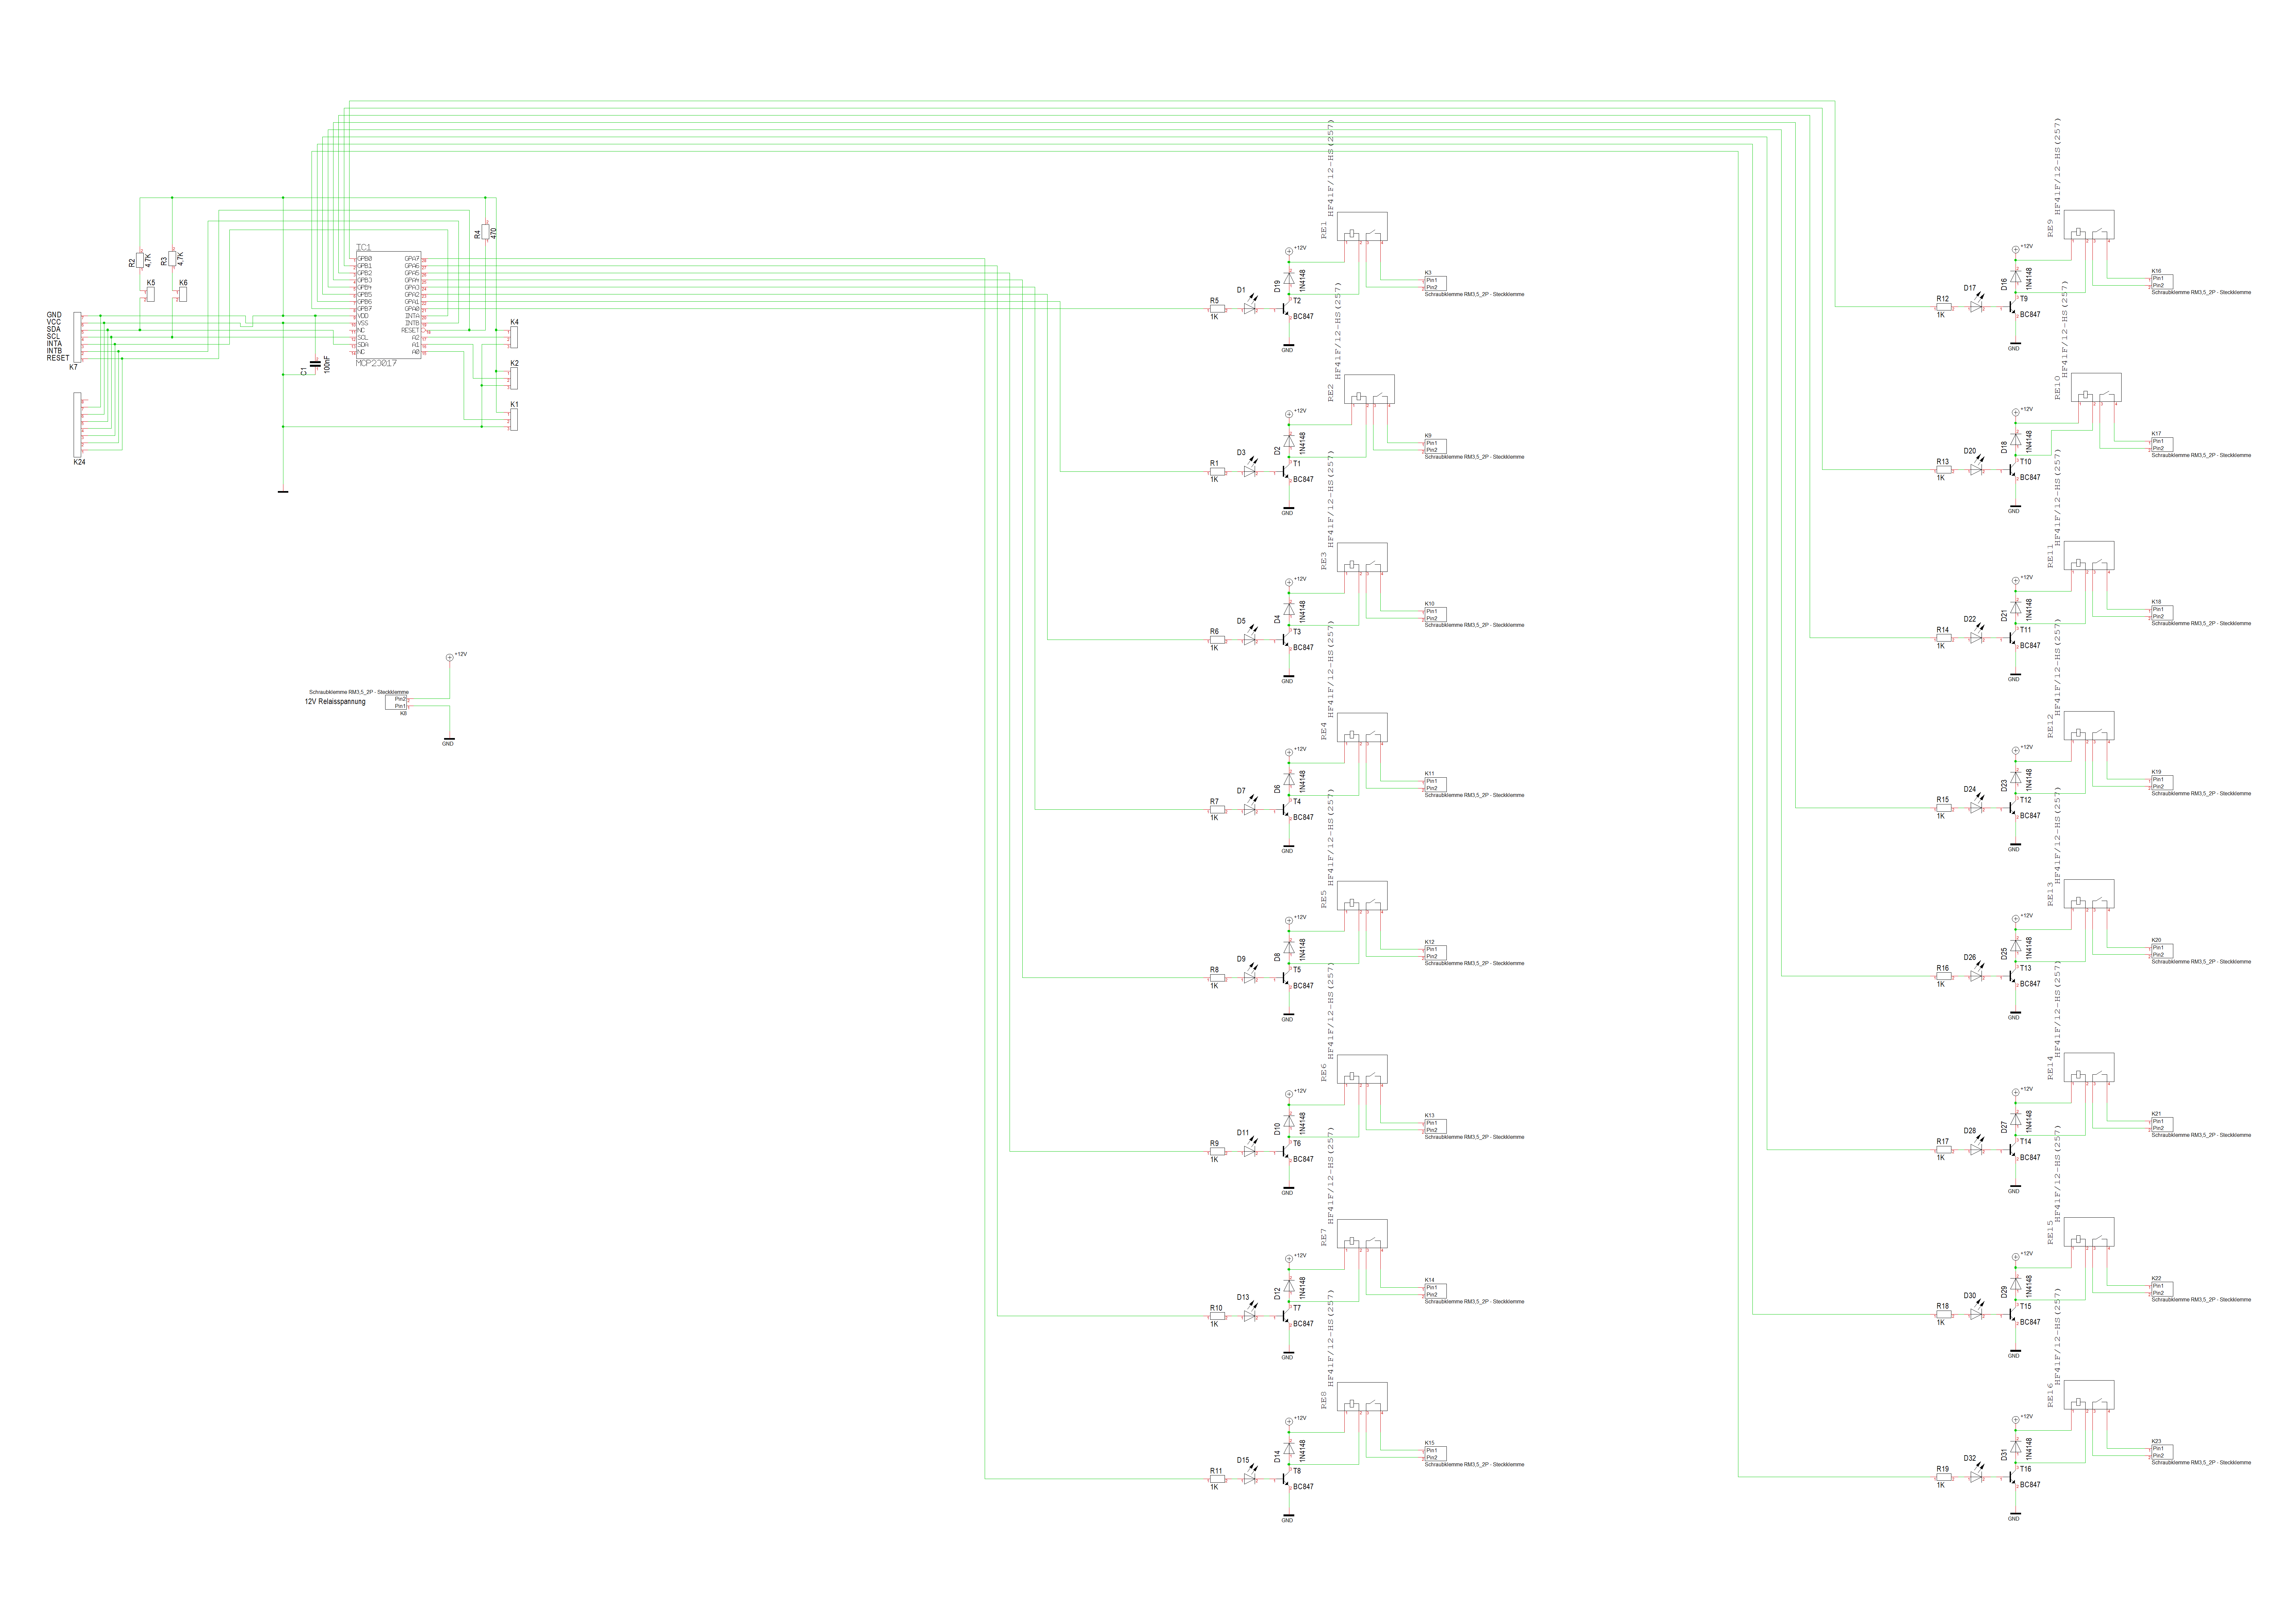
Schaltplan mit Mikrocontroller und mehreren Transistoren
ATMEGA328P, R1, R2, R3, R4, R5, R6, R7, R8, R9, R10, R11, R12, R13, R14, R15, R16, R17, R18, R19, R20, R21, R22, R23, R24, R25, R26, R27, R28, R29, R30, R31, R32, R33, R34, R35, R36, R37, R38, R39, R40, R41
in „MCP23017 und UDN2981A“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
 Bild
Schaltplan einer Mikrocontroller-Schaltung
C4, 100nF, U1, TC126A, 3.3VDBTR, VOUT, C5, 100nF, 3V3D, 3V3A, R33, 10k, HTD1, MODE1, PMODE1, U2, ATMEGA328P-PU, VCC, GND, R23, 10k, R24, 10k, R25, 10k, R26, 10k, R27, 10k, R28, 10k, R29, 10k, R30, 10k, R31, 10k, R32, 10k, C23, 100nF, C22, 100nF, C21, 100nF, C20, 100nF, C19, 100nF, C18, 100nF, C17, 100nF
in „Funktioniert diese Atmega328 Schaltung?“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
Datei
Frequenzz__hler.c
Messbereich von 0 Hz bis etwa 1 Mhz Mit einem 16 MHz Quarz sind gut Frequenzen bis 4 MHz messbar. ATmega8/16/32 Roman Mittermayr AVRBUCH.DE */ #define TAKT 3686400 #include <avr/io.h> #include <avr/interrupt.h> #include <stdlib.h> #include <string.h> #include "rs232.h" volatile uint16_t Flanke1; volatile
in „problem mit atmega8 als Frequenzzähler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Atmega644_DOGM128_094.c
Font-Generator // Version 0.94 Autor: Jan M. // http://www.mikrocontroller.net/topic/144500#new // ATMEGA644 --> DOGS102 DOGM128/132 DOGXL160 // #define LCD_A0/CD 2 // PB2 (PIN3) -> PIN 26 PIN 38 Pin 27 // #define LCD_RST 3 // PB3 (PIN4) -> PIN 27 PIN 39 Pin 29 // #define LCD_CS 4 // PB4 (PIN5) -> PIN 28 PIN 40 Pin 28 // #define SPI_MOSI 5 // PB5 (PIN6) -> PIN 25 PIN 37 Pin 32 // #define SPI_MISO 6 // --- ---- ----- ------ ------ // #define SPI_SCK 7 // PB7 (PIN8) -> PIN 24 PIN 36 Pin 31 */ #include <stdint.h> #include <avr/io.h> #include "tools.h" #include "bmp.h" static
in „Library für EA-DOGM Grafikdisplays inkl. Font-Generator“ · Projekte & Code ·
-
PDF
ULN2068B.pdf
K GND AREF VCC ADC6 5GND PB6 AVCC + 1 1 1 1 PB7 D D D B B B B B PB5 P P P P P P P P IC2 K C +5V ATMEGA8(TQFP32) C B B Vs N D V G GND GND G + GND GND B B P NC C GND SPI I C K ULN2068B +5V This document was created with Win2PDF available at http://www.win2pdf.com. The unregistered version of Win2PDF is
in „ULN2068B Defekt?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
io_expander.c
// io_expander.c // for NerdKits with ATmega168 #define F_CPU 14745600 #include <stdio.h> #include <avr/io.h> #include <avr/interrupt.h> #include <avr/pgmspace.h> #include <inttypes.h> #include "../libnerdkits/i2cmaster.h" #include "../libnerdkits
in „MCP23016 Port Expander Input Realisieren“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
disable_function_checks_and_ansi_flag.patch
--- CUnit-2.1-2/configure.in 2010-10-15 17:11:32.000000000 +0200 +++ CUnit-2.1-2-patched/configure.in 2011-11-24 18:48:52.896000140 +0100 @@ -26,7 +26,7 @@ TOPDIR=`pwd` -CFLAGS="$CFLAGS -DRELEASE=@RELEASE@ -Wall -W -pedantic -Wshadow -ansi -I${PWD}
in „CUnit auf avr portieren - Problem mit snprintf“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
TEMOD-I2C-test.bas
' BASCOM-Programm ' I2C-Scanner mit ATMega8 ' ' In: beliebige I2C-Slaves an C.4=SDA und C.5=SCL ' Out: LCD an D2 bis D.7 ' Funktion dieses Demo-Programmes: ' Scannen der Slave-Adressen $regfile = "m8def.dat" ' benutzter Mikrocontroller $crystal = 8000000 ' Taktfrequenz $hwstack = 40 ' Hardware Stack $swstack = 32 ' SW Stack $framesize = 60 ' Frame Config Lcdpin = Pin , Db4 = Portc.0 , Db5 = Portc.1 , Db6 = Portc.2 , Db7 = Portc.3 , E = Portb.2 , Rs = Portb.1 Config Lcd = 16 * 2 Cls Cursor Off Waitms 250 Config
in „Hygrosens I2C Bus Spec“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
TasterIN.c
#define F_CPU 16000000 #include "E:\AVR\ATmega32\Includes\BitUtilities.h" #include "LCD.h" #include <avr/io.h> #include <util/delay.h> #include <avr/interrupt.h> #include <stdlib.h> #include <string.h> #include <math.h> _Bool taster[8]; void tglINclk
in „74hct165 läuft nicht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
quickndirty-uhr.pdf
LED1 18 PD4 PB4 5 LED2 19 6 X1001 PD5 PB5 LED3 20 PD6 PB6 7 1 2 4x LED4 21 PD7 PB7 8 3 4 5 c 5 6 + D 32 AREF V N 12 0 G XTAL2 6POL 13XTAL1 9 AVR RESET ATmega16 ISP $rlname 1 - MISO Vtref - 2 3 - SCK MOSI - 4 Vcc AVcc 5 - nRST GND - 6 +5V +5V 1 1 0 lm 0 l m 0 vl 0 v l C 2 $$ C 2 $ $ Bartels AutoEngineer
in „Schaltpläne Woher?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
SCHALTUNG_VGA.pdf
VGA 640x480 (164x120) 7805 +12V GND 10µ 10µ 40 39 38 37 36 35 34 33 32 30 29 28 27 26 25 24 23 22 21 0 1 2 3 4 5 6 7 F D C 7 6 5 4 3 2 1 0 7 A A A A A A A A E N C C C C C C C C C D P P P P P P P P A G A P P P P P P P P P T T T T T T T T A L A C C C C C C C C S S C / / / / / / / / O C C C C C C C C A A A A A A A A ATmega1284P A B A B B A B C C C C C C C O O O O E L L O O O 0 1 2 3 4 5 6 7 S C D A A 0 1 2 3 4 5 6 P P P P P P P P R V G X X P P P P P P P 1 2 3 4 5 6 7 8 9 10 12 13 14 15 16 17 18 19 20 0 0 0 4 4 4 a 100nF
in „VGA 640x480 60Hz (164x120) RGB Vollgrafic ATmega1284p Assembler“ · Projekte & Code ·
-
PDF
Blockschaltbild_mod.pdf
W W W A O O O O x A P P P U D D D D 2 CLK0 Clock Buffer Fan 24V ~100mA SPI ISP Interface µC 3V3 (ATMEGA 32u4) SPI L P C L P C L P C C S ! C S ! C S ! Motion Motion Motion USB Interface Controller Controller Controller 6 4361 4361 4361 switches SPI SPI 3V3 3V3 3V3 I I x x 2 2 Vin 5V 3V3 24V
in „G-Code-Interpreter und µStep-Controller mit ATmega644“ · Projekte & Code ·
-
PDF
stk300.pdf
information. 1.1 Device Support The system software currently has support for the following devices. n ATmega603 n ATmega603L n ATmega103 n ATmega103L Software upgrades for new devices will be available in the AVR section of the Atmel website, which is located at http://www.atmel.com. 1 Section 2 Getting Started
in „Kanda AVR Starterboard und noch keine Ahnung“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
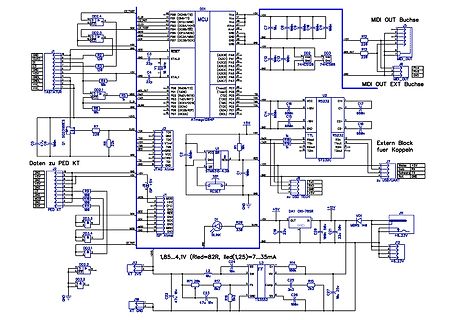
Schaltplan einer Mikrocontroller-Schaltung mit MIDI-Schnittstelle
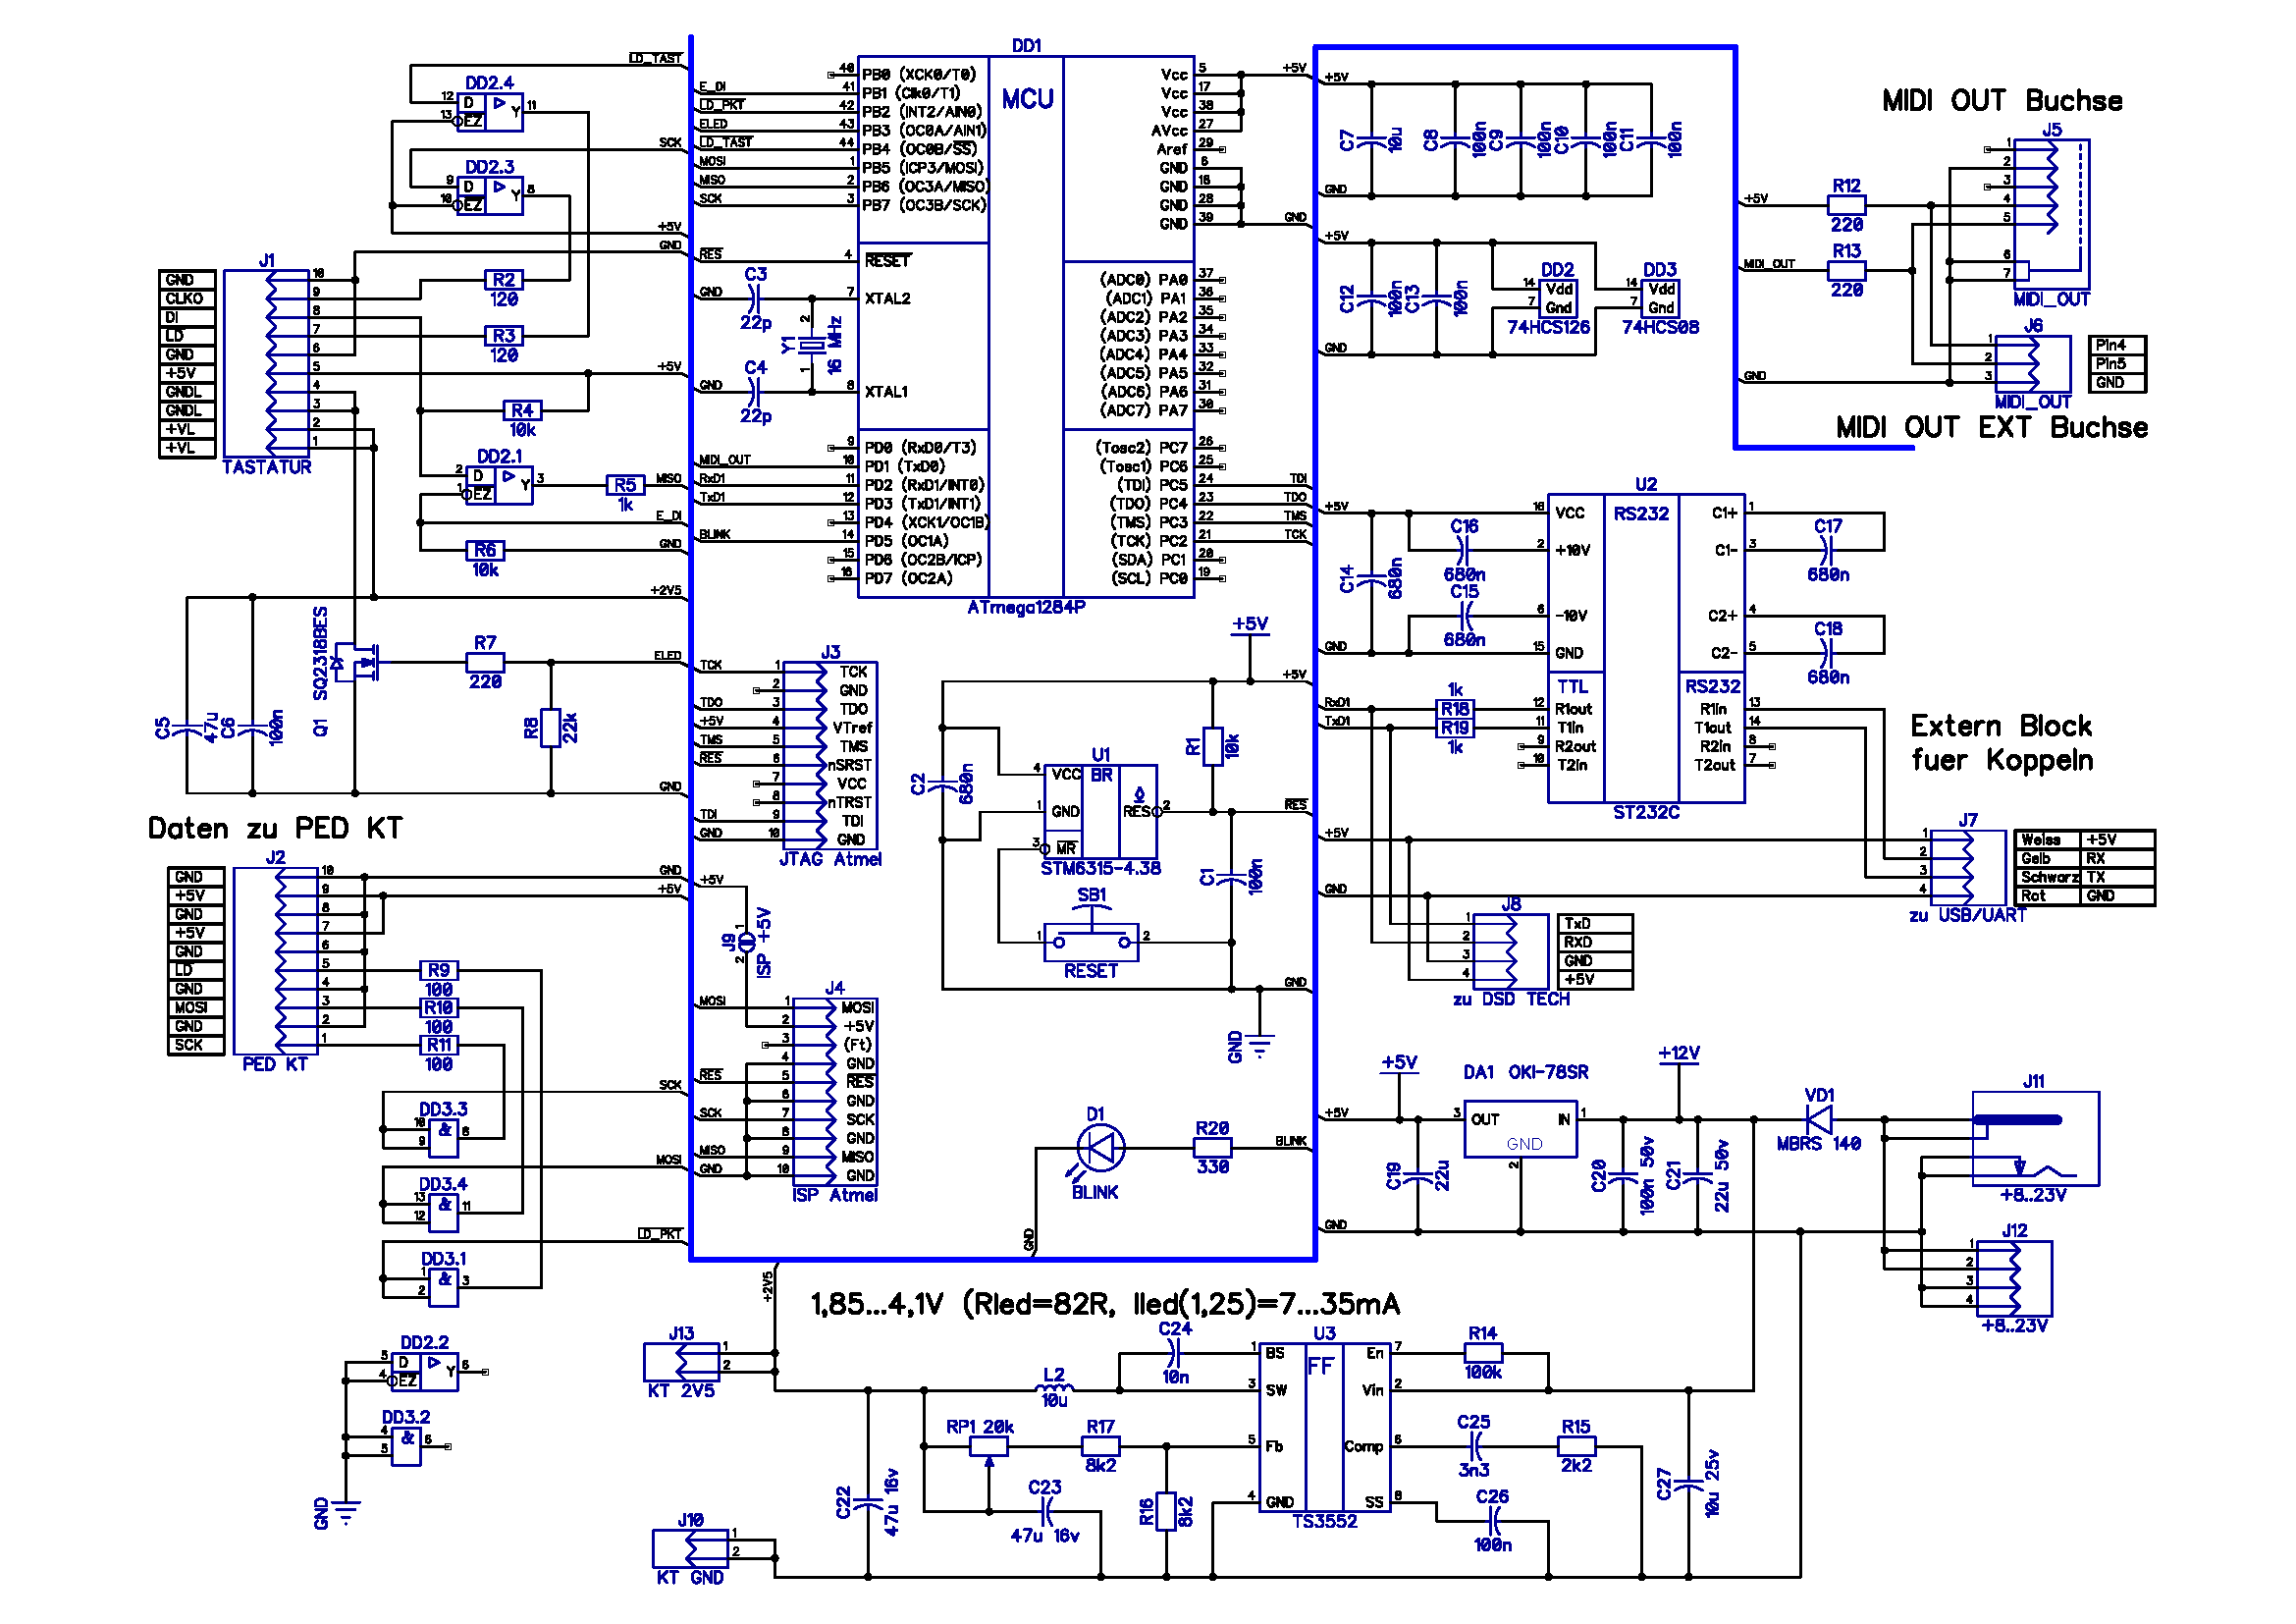
DD1 MCU ATmega1284P, MIDI OUT, MIDI IN, USB, ST7232C, RS232, 5V, 12V, GND, R12 220, R13 220, R14 220, C1 100n, C2 100n, C3 100n, C4 100n, C14 100n, C15 100n, C16 100n, C17 100n, C18 100n, C19 100n, C20 100n, C21
in „Atmel Studio 4.19 unter W10X64“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
Datei
deffinitionen_elko_sprengeinrichtung.h
// Deffinitionen für ELKO-Sprengeinrichtung // ATmega32 // LCD mit 4 Bit-Bus #define verbindenx(a,b) a##b // Damit funktionieren die #define verbinden(a,b) verbindenx(a,b) // Deffinitionen der Ports (standardmäßig CONCAT) #define LCD_Wartezeit 2 // µs
in „Cursor oder Anzeige schieben beim HD44780-LCD“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
slave.txt
// Slave ATmega32 #include <avr/io.h> #include <avr/interrupt.h> #ifndef F_CPU //#warning "F_CPU war noch nicht definiert, wird nun nachgeholt mit 4000000" #define F_CPU 8000000L // Systemtakt in Hz - Definition als
in „Problem: SPI daten von mehreren slaves zum master! aber wie?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
TWI_Mastermain.c
properly (don't forget to also ** connect GND between Master and Slave!) ** ** Used uC for Master is ATMega32 */ unsigned short Mastermain (unsigned char chanel) { /* ** Wait 1 second for POR */ _delay_ms(100); /* ** Initiate RS232 */ /* ** Initiate TWI Master Interface with bitrate of 100000 Hz */ if (!
in „Problem beim Vergleich von ADwandlerwerte zwischen Master und Slave“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Platine.pdf
Servomotor SG1 R2 R1 C F/KMB 10k 0,1% 10k 0,1 % V+ Ausgang Ultraschallsensor + - Spannungsteiler Sensor ATmega Tasten Position S4 IC1 1 2 R3 9 33 S5 RESET (ADC7)PA7 34 10k (ADC6)PA6 35 1 2 12 (ADC5)PA5 36 XTAL2 (ADC4)PA4 37 S6 13 (ADC3)PA3 38 XTAL1 (ADC2)PA2 39 1 2 32 (ADC1)PA1 40 30 AREF (ADC0)PA0 S7 31 AVCC
in „Sensor, Spannungsregler“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Platin3.pdf
R2 R1 C F/KMB 10k 0,1% 10k 0,1 % V+ Ausgang Ultraschallsensor + - Spannungsteiler Sensor S4 1 2 ATmega Tasten Position IC1 R3 9 33 S5 RESET (ADC7)PA7 34 10k (ADC6)PA6 35 1 2 12 (ADC5)PA5 36 XTAL2 (ADC4)PA4 37 S6 13 (ADC3)PA3 38 XTAL1 (ADC2)PA2 39 1 2 32 (ADC1)PA1 40 30 AREF (ADC0)PA0 S7 31 AVCC 8 E
in „Sensor, Spannungsregler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Eeprom_f_r_ATmega8.txt
9600 Baud //---------------------------------------------------------------------- // Prozessor : ATmega8 // Takt : 3,6864 MHz // Sprache : C // Datum : 14.02.2006 // Version : 1.3 // Autor : Dipl. Ing. Päd. Alexander Huwaldt //---------------------------------------------------------------------- #define
in „Inline Assembler übersetztung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
AVRGCC7.c
/* * LapBanner 3.0.1 * * Created: 26.03.2012 16:36:24 * Author: AmmannM.ch | ammannm@gmail.com * Atmega32 16PU */ #include <avr/io.h> #include <avr/interrupt.h> #define F_CPU 8000000UL //CPU Takt vorgeben int posArray = 0; // Position im Array // Static >> feste Adresse | const >> dürfen nicht verändert
in „Null im Array bricht Zählvorgang ab (AVR GCC)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
AVRGCC7.c
/* * Created: 26.03.2012 16:36:24 * Atmega32 16PU */ #include <avr/io.h> #include <avr/interrupt.h> #define F_CPU 8000000UL //CPU Takt vorgeben volatile static uint8_t posArray = 0; // Position im Array //const >> dürfen nicht verändert werden
in „Null im Array bricht Zählvorgang ab (AVR GCC)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main_new.c
/* Multitasking Demo, zweiter Versuch ATmega32 @ 3,6468 MHz LED + 1KOhm Vorwiderstand an PB0 Taster nach GND an PA0 UART an RXD und TXD */ #define F_CPU 3686400 // Baudrate, das L am Ende ist wichtig, NICHT UL verwenden! #include <avr/io.h> #
in „Leuchtschriftsteuerung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uarth.txt
/* * Doku, siehe http://www.mikrocontroller.net/articles/AVR_FAT32 * Autor: Daniel R. */ #ifndef _UART_H #define _UART_H //#define F_CPU 10000000UL #define F_CPU 1000000UL #define BAUD 9600UL //#define UBRR_VAL ((F_CPU+BAUD*8)/(BAUD*16)-1) // clever runden #define UBRR_VAL ((F_CPU+BAUD*8UL)/(BAUD*16UL)-1UL) // clever runden #if defined (__AVR_ATmega2560__) #define UDR UDR0 #define UCSRA UCSR0A #define UDRE UDRE0 #define UCSRB UCSR0B #define RXC RXC0 #define UCSRC UCSR0C #define UCSZ0 UCSZ00 #define UCSZ1 UCSZ01 #define RXEN RXEN0 #define TXEN
in „Mein UART geht nicht sendet kommische Zeichen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
/* * Doku, siehe http://www.mikrocontroller.net/articles/AVR_FAT32 * Autor: Daniel R. */ #ifndef _UART_H #define _UART_H //#define F_CPU 10000000UL #define F_CPU 1000000UL #define BAUD 9600UL //#define UBRR_VAL ((F_CPU+BAUD*8)/(BAUD*16)-1) // clever runden #define UBRR_VAL ((F_CPU+BAUD*4UL)/(BAUD*8UL)-1UL) // clever runden #if defined (__AVR_ATmega2560__) #define UDR UDR0 #define UCSRA UCSR0A #define UDRE UDRE0 #define UCSRB UCSR0B #define RXC RXC0 #define UCSRC UCSR0C #define UCSZ0 UCSZ00 #define UCSZ1 UCSZ01 #define RXEN RXEN0 #define TXEN
in „Mein UART kann keine zeichen empfangen.“ · Mikrocontroller und Digitale Elektronik ·