-
 Bild
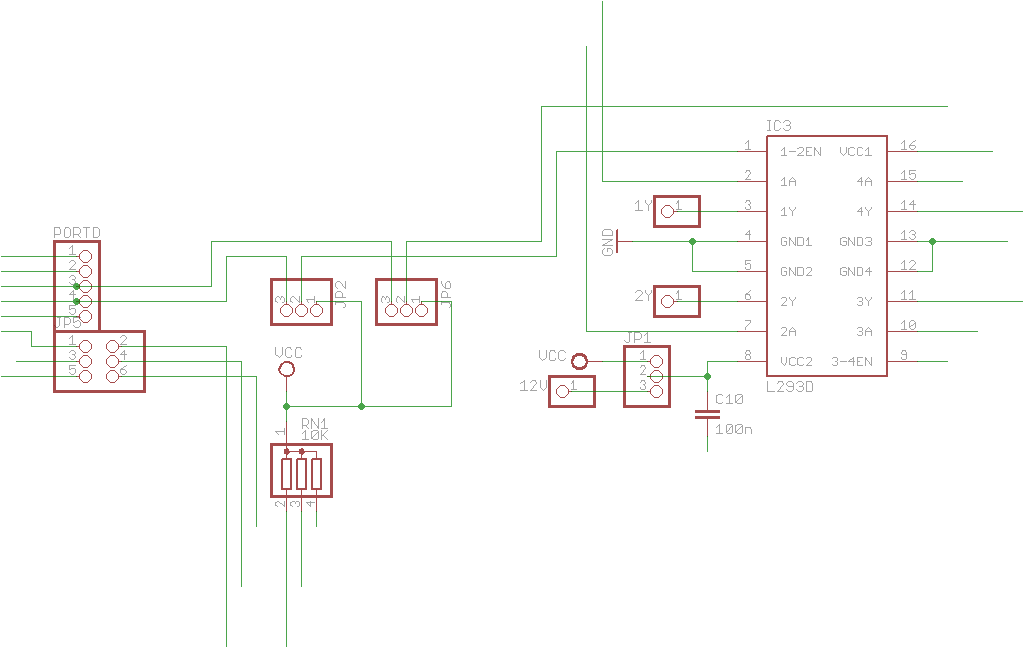
Schaltplan eines L293D Motortreibers
3Y, 2A, 3A, 10, 9, 3-4EN, VCC2, 8, 7, 2Y, 6, 5, GND2, 4, 3, 1Y, 2, 1A, 1, 16, 15, 14, 13, 12, 11, L293D, JP1, UCC, 12V, C10, 100n
in „Schaltplan und Board so OK?“ · Platinen · · Schaltpläne
-
PDF
L293.pdf
center pins toconductheat to the printedcircuit board. PIN CONNECTIONS DIP16 - L293B POWERDIP (16+2+2) - L293E April1993 1/12 L293B - L293E BLOCK DIAGRAMS DIP16 - L293B POWERDIP (16+2+2) - L293E 2/12 L293B - L293E SCHEMATIC DIAGRAM (*) In the L293 these points are not externally
in „Schrittmotoren anschließen?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
L293B_L293E_STM.pdf
center pins toconductheat to the printedcircuit board. PIN CONNECTIONS DIP16 - L293B POWERDIP (16+2+2) - L293E April1993 1/12 L293B - L293E BLOCK DIAGRAMS DIP16 - L293B POWERDIP (16+2+2) - L293E 2/12 L293B - L293E SCHEMATIC DIAGRAM (*) In the L293 these points are not externally
in „Wie Stromstitzen unterdrücken?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
l293d.pdf
L293, L293D QUADRUPLE HALF-H DRIVERS SLRS008C − SEPTEMBER 1986 − REVISED NOVEMBER 2004 L293 . . . N OR NE PACKAGE D Featuring Unitrode L293 and L293D L293D . . . NE PACKAGE Products Now From Texas Instruments
in „Motor ansteuern mit RPi & L293D“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
L293D_TI.pdf
L293, L293D QUADRUPLE HALF-H DRIVERS SLRS008B – SEPTEMBER 1986 – REVISED JUNE 2002 D Featuring Unitrode L293 and L293D N, NE PACKAGE (TOP VIEW) Products Now From Texas Instruments D Wide Supply-Voltage
in „Motortreiber gesucht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
156133-da-01-en-4_KANAL_TREIBER_IC_L293E_STM-3.pdf
heat to the printed circuit Additionally, the L293E has external connection ofoard. PIN CONNECTION (Top view) POWERDIP (16+2+2) - L293E DIP16 - L293B July 2003 1/12 L293E L293B BLOCK DIAGRAMS DIP16 - L293B POWERDIP (16+2+2) - L293E 2/12 L293E L293B
in „Motortreiber 293E“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
L293_B_E_ST.pdf
heat to the printed circuit Additionally, the L293E has external connection ofoard. PIN CONNECTION (Top view) POWERDIP (16+2+2) - L293E DIP16 - L293B July 2003 1/12 L293E L293B BLOCK DIAGRAMS DIP16 - L293B POWERDIP (16+2+2) - L293E 2/12 L293E L293B
in „L293D Motortreiber, Highsidetreiber Technologie.“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
treiber_l293B.pdf
center pins toconductheat to the printedcircuit board. PIN CONNECTIONS DIP16 - L293B POWERDIP (16+2+2) - L293E April1993 1/12 L293B - L293E BLOCK DIAGRAMS DIP16 - L293B POWERDIP (16+2+2) - L293E 2/12 L293B - L293E SCHEMATIC DIAGRAM (*) In the L293 these points are not externally
in „Aufbau der Treiberbausteine von bipolaren Schrittmotor“ · Mechanik, Gehäuse, Werkzeug ·
-
PDF
l293d.pdf
SLRS008C − SEPTEMBER 1986 − REVISED NOVEMBER 2004 D Featuring Unitrode L293 and L293D L293 . . . N OR NE PACKAGE L293D . . . NE PACKAGE Products Now From Texas Instruments D Wide Supply-Voltage Range: 4.5 V to 36 V (TOP VIEW) D Separate Input-Logic Supply 1,2EN 1 16 VCC1
in „Motorentreiber L293D“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
L293D.pdf
L293D ® L293DD PUSH-PULL FOUR CHANNEL DRIVER WITH DIODES 600mA OUTPUT CURRENT CAPABILITY PER CHANNEL 1.2A PEAK OUTPUT CURRENT (non repeti- tive) PER CHANNEL ENABLE FACILITY OVERTEMPERATURE PROTECTION LOGICAL
in „3,3V Elektromotor mit 5V AVR in beiden Richtungen betreiben?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
293d.pdf
HEREIN AND THIS DOCUMENT ARE SUBJECT TO SPECIFIC DISCLAIMERS, SET FORTH AT www.vishay.com/doc?91000 293D www.vishay.com Vishay Sprague DIMENSIONS in inches [millimeters] L W TW H TH(MIN.) Glue Pad Glue Pad P CASE CODE EIA SIZE L W H P TW T HMIN.) 0.126 ± 0.008 0.063 ± 0.008 0.063 ± 0.008 0.031 ± 0.012
in „Suche dringend passenden SMD Kondensator“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
LM393.pdf
0.015 0.020 D 9.8 0.386 E 8.8 0.346 e 2.54 0.100 e3 7.62 0.300 e4 7.62 0.300 F 7.1 0.280 I 4.8 0.189 L 3.3 0.130 Z 0.44 1.6 0.017 0.063 P001F 10/15 LM193, LM193A, LM293, LM293A, LM393, LM393A Package Mechanical Data 5.2 SO8 package SO-8 MECHANICAL DATA mm. inch DIM. MIN. TYP MAX. MIN. TYP. MAX. A 1.35
in „Spannungsregler mit Strombegrenzung - geht das so?“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
TLP293_4_datasheet_en_20190520.pdf
R L VCC 4.5 V V CE V CE 0.5 V t toff on © 2019 4 2019-05-20 Toshiba Electronic Devices & Storage Corporation TLP293-4 Characteristics Curves (Note) IF - Ta P C - Ta ) W A ( ( C F P I t i e a r i c i r r
in „Optokoppler TLP293-4 - Datenblatt lesen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
l293_driver.pdf
l293_driver.pdf
in „L293 zieht Strom ueber USB - normal?“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
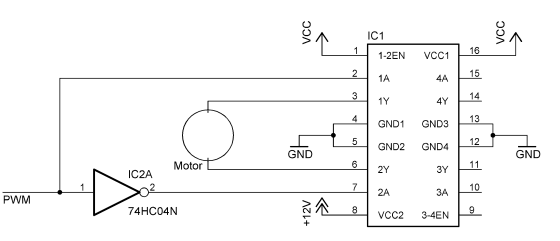
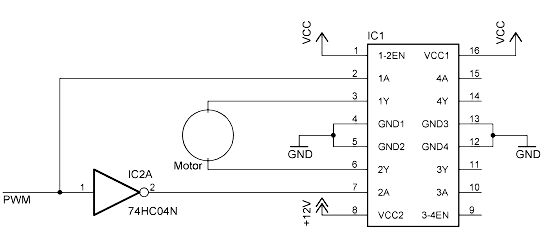
Schaltplan einer Motortreiber-Schaltung
IC1, 1-2EN, VCC1, 16, 15, 1A, 4A, 3, 1Y, 4Y, 4, GND1, GND3, 13, 12, 5, GND, GND2, GND4, 6, 2Y, GND3, 11, 3Y, 7, 2A, 10, 3A, 8, +12V, 9, VCC2, 3-4EN, IC2A, 74HC04N, 1, 2, PWM, Motor
in „Lüftersteuerung via Microcontroller“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
Datei
L293D.h
/* * L293D.h * * Created: 19.11.2016 17:26:10 * Author: Kde-PC */ #ifndef L293D_H_ #define L293D_H_ extern void MOTOR_PWM (uint16_t A, uint16_t B); #endif /* L293D_H_ */
in „Externe .c bringt nur theater“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
L293D.c
/* * L293D.c * * Created: 19.11.2016 17:25:46 * Author: Kde-PC */ #include <avr/io.h> #include <avr/interrupt.h> #include "L293D.h" void MOTOR_PWM (uint16_t A, uint16_t B) { OCR1A = A; OCR1B = B; }
in „Externe .c bringt nur theater“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Vishay-293D.pdf
HEREIN AND THIS DOCUMENT ARE SUBJECT TO SPECIFIC DISCLAIMERS, SET FORTH AT www.vishay.com/doc?91000 293D www.vishay.com Vishay Sprague DIMENSIONS in inches [millimeters] L W TW H TH(MIN.) Glue Pad Glue Pad P CASE CODE EIA SIZE L W H P TW T HMIN.) 0.126 ± 0.008 0.063 ± 0.008 0.063 ± 0.008 0.031 ± 0.012
in „Was ist das für ein Bauteil? (Aus einem Autoschlüssel)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
TEST_JUMPER PIND5 #define WATCHDOG_JUMPER PIND6 #define DOOR_OPEN PIND6 #define DOOR_CLOSED PINB0 #define L293_ENABLE PC5 #define L293_1A PC4 #define L293_2A PC3 #define LDR_VCC PC2 #define DOOR_TURNOFF_TIME 150 // * 0.1s #include <avr/io.h> #include <avr/interrupt.h> #include <util/delay.h> #include <avr/
in „Variablen werden nach aufwachen aus Power Save nicht mehr verändert“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
lm393.pdf
=1.4VDC LSR 300 300 300 ns response time V RL=5VDC, RL=5.1k , TA=25⋅C R Response time5 V RL=5VDC , L =5.1k 1.3 1.3 1.3 s TA=25⋅C 1995 Nov 27 3 Philips Semiconductors Product specification Low power dual voltage comparator LM193/A/293/A/393/A/2903 DC ELECTRICAL CHARACTERISTICS (Continued) V+=5VDC, LM193
in „200Khz Signal verstärken“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
lm393-n.pdf
Supply Current RL=∞ V =5 V 0.4 1 mA + V =36 V 1 2.5 mA Voltage Gain R ≥15 kΩ, V =15 V 50 200 V/mV L V O 1 V to 11 V Large Signal Response Time V =TTL Logic Swing, V =1.4 V 300 ns V =5V, R =5.1 kΩ REF RL L Response Time V RLV, R =L.1 kΩ (4) 1.3 μs Output Sink Current V IN)=1V, V IN)=0, V ≈O.5 V 6.0
-
PDF
LM393.pdf
Supply Current RL=∞ V =5 V 0.4 1 mA + V =36 V 1 2.5 mA Voltage Gain R ≥15 kΩ, V =15 V 50 200 V/mV L V O 1 V to 11 V Large Signal Response Time V =TTL Logic Swing, V =1.4 V 300 ns V =5V, R =5.1 kΩ REF RL L Response Time V RLV, R =L.1 kΩ (4) 1.3 μs Output Sink Current V IN)=1V, V IN)=0, V ≈O.5 V 6.0
in „Schaltung angucka“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
LM393.pdf
Supply Current RL=∞ V =5 V 0.4 1 mA + V =36 V 1 2.5 mA Voltage Gain R ≥15 kΩ, V =15 V 50 200 V/mV L V O 1 V to 11 V Large Signal Response Time V =TTL Logic Swing, V =1.4 V 300 ns V =5V, R =5.1 kΩ REF RL L Response Time V RLV, R =L.1 kΩ (4) 1.3 μs Output Sink Current V IN)=1V, V IN)=0, V ≈O.5 V 6.0
in „Acc-Sensor -> Filter/OPV -> ADC(µC) -> PC -> Filter“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
LM393-N.pdf
Supply Current RL=∞ V =5 V 0.4 1 mA + V =36 V 1 2.5 mA Voltage Gain R ≥15 kΩ, V =15 V 50 200 V/mV L V O 1 V to 11 V Large Signal Response Time V =TTL Logic Swing, V =1.4 V 300 ns V =5V, R =5.1 kΩ REF RL L Response Time V RLV, R =L.1 kΩ (4) 1.3 μs Output Sink Current V IN)=1V, V IN)=0, V ≈O.5 V 6.0
in „LM393 Komparatorschaltung gescheitert“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
Relaisansteuerung.sch__1_.pdf
QH* 9 GND 4 GND1 GND3 13 74HC595N 5 GND2 GND4 12 GND 6 11 GND 2Y 3Y 7 2A 3A 10 8 VCC2 3-4EN 9 +12V L293D 5 IC7 + 1 16 1-2EN VCC1 C7 2 15 1A 4A 100nF 3 1Y 4Y 14 GND 4 GND1 GND3 13 5 12 GND2 GND4 GND 6 2Y 3Y 11 GND 14 SER QA 15 7 2A 3A 10 1 11 QB 2 8 9 10 SCK QC 3 VCC2 3-4EN SCL QD 4 +12V +5V QE L293D
-
PDF
L297AN.PDF
tendedforusewithanL298NorL293Ebridgedriver L297Aincorporatesastep pulsedoublerand is de- in steppermotor driving applications. signed specifically for floppy-disk head positioning Itreceivescontrolsignalsfromthe system’
in „µC_Steuerung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
L297_Application_Note.pdf
tendedforusewithanL298NorL293Ebridgedriver L297Aincorporatesastep pulsedoublerand is de- in steppermotor driving applications. signed specifically for floppy-disk head positioning Itreceivescontrolsignalsfromthe system’
in „L297: Stromregelung schaltet an, nicht aus“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
IE3_5_1_Application_Notes_IC_L297.pdf
winding currents up to 2Athe L297 should be used with the L298N ; for winding currents up to 1A the L293E is recommended (the L293 will also be useful if the chopper isn’t needed). Higher currents are obtained with power transistors
in „Phase Chopping“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
tlc4545.pdf
B 2.5 L 2 − i 1.5 a 1 n 0.5 l o 0 l −0.5 r g −1 n −1.5 I L −2 I −2.5 0 10000 20000 30000 40000 50000 60000 Code Figure 2 www.ti.com 7 SLAS293 − DECEMBER 2001 TYPICAL CHARACTERISTICS FFT 0 FFT = 15 kHz, −20 V
in „Warum funktioniert das nicht? Mittelwert, AD_wandler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
PWM023.bas
Enable Interrupts Motor1_w1a Alias Portb.1 'Motorwicklung 1 Ende "a" der ersten Spule. PortB.1 geht zum L293 1A Motor1_w1b Alias Portb.2 'Motorwicklung 1 Ende "b" der ersten Spule. PortB.2 geht zum L293 2A Motor1_w2a Alias Portb.3 'Motorwicklung 2 Ende "a" der zweiten Spule. PortB.3 geht zum L293 3A Motor1
in „Mikroschrittmotor mit L293 oder PBM3960 + PBL3771: Wie programmieren?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
l293_driver_board.pdf
l293_driver_board.pdf
in „L293 zieht Strom ueber USB - normal?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
dn51_a_040220_Philips_Semiconductors_PDN.pdf
TI: LM293AD CAEN fire. No possibility of further Philips manufacture due to 76 LM293AD LM293A D LINEAR INDUSTRIA L 935008540602 T M 1 20-feb-04 20-feb-04 TI: LM293ADR CAEN fire. 4 PHILIPS SEMICONDUCTORS SPECIAL
in „Das Innenleben von Transistoren und Operationsverstärkern“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
frequenzabhaengigkeit.pdf
0.355 0.266 2.15 3.16 25 x 30 3300 SLPX332M080A9P3 0.101 0.076 3.23 4.04 22 x 50 680 SLPX681M160A7P3 0.293 0.220 2.35 3.45 22 x 40 3300 SLPX332M080C7P3 0.101 0.076 3.29 4.11 25 x 40 680 SLPX681M160C3P3 0.293 0.220 2.33 3.43 25 x 30 3300 SLPX332M080E3P3 0.101 0.076 3.25 4.06 30 x 30 680 SLPX681M160E1P3 0.293
in „Frequenzabhängigkeit Kapazität Elko“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
LUW_T6SG_-_TOPLED-473049.pdf
oniceseq ui l be l w g, i:rea ced u i en el 4 5 F F l : 4 d , oe2 od e e be ntw he n pro te is Le e ve e l5l6 b n edafow ba rc e se m 0u% b ak e ld a t r reuL L evev e aled o see r se e rti fors > 1 f r , se a M oio
in „Vorwiderstand“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
Anleitung.pdf
K5 C5 K13 K15 1 C14 R C9 K2 6 1 2 IC5 C2 C Q Q 2 K9 P C10 K K 3 2 X I 1 90S8535-Board für K16 M C L293D Roboter 2 IC4 Version: 1.1 1 C4 C12 2 4 3 5 6 7 8 9 06.04.02 M1 M2 L DLD L DLD L L L L K10 RN3 Seite 4 von 18 Kai Sachsenheimer 27.04.02 Reihenfolge der Bestückung entsprechend der Tabelle von oben
in „AVR_Ctrl mit BasCom programmieren“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
MITSUBISHI_CV-0MW7B51.pdf
R062,066,etc. 103L292O9 R-CHIP 2.2k Q001,004,etc. 260M061O6 TR-CHIP 2SA1037AK R506 103L293O0 R-CHIP 2.7k Q905 260L047O1 TR-CHIP 2SA1369 Q002,003,005 260M061O5 TR-CHIP 2SC2412K R006,511 103L293O1 R-CHIP 3.3k R508 103L293O2
in „Verstärker reparieren“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
ATmega8515.asm
rirechts ; ja -> richtung rechts stellen sbi PORTB, dir ; Pin 2 (Bit3,PortD) = HIGH -> Linkslauf siehe L293D DS ldi wr0, 0x62 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnleft = LOW out TCCR0, wr0 ; COM01 = 1 COM00 = 0 ; -> OCR0 - BOTTOM - CCR0 = LOW -> OCR0 steigend -> länger LOW -> schneller rjmp richteinstend rirechts: cbi PORTB, dir ; Pin 2 = LOW -> Rechtslauf DS von L293D ldi wr0, 0x72 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnright = HIGH out TCCR0, wr0 ; COM01 = 1 COM00 = 1 ; -> OCR0 - Bottom - CCR0 = HIGH -> OCR0 steigend -> länger HIGH -> schneller richteinstend
in „mC arbeitet nicht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
NOXO100_Recommended_External_Sensor_Circuit.pdf
2 7 0 . 2 0 9 1 : 0 5 0 C P r g a m i e \ A G L E C1 R8 10K 4 100n 10K R11 1 2 R3 R9 2 OP293FS p 1M 10K 1 o 3 e V- t A1A \ 4 1 R N 6 OP293FS 1 , O 7 R 4 S 5 n s 8 A1B r 0V n 1 4 0 R R 1 R 5 V+ e c + + m UB2 Power Supply 1 Measuring m 0V CON2 Instrument
in „Hilfe bei Schaltplan, Vermischung von OPVs?“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
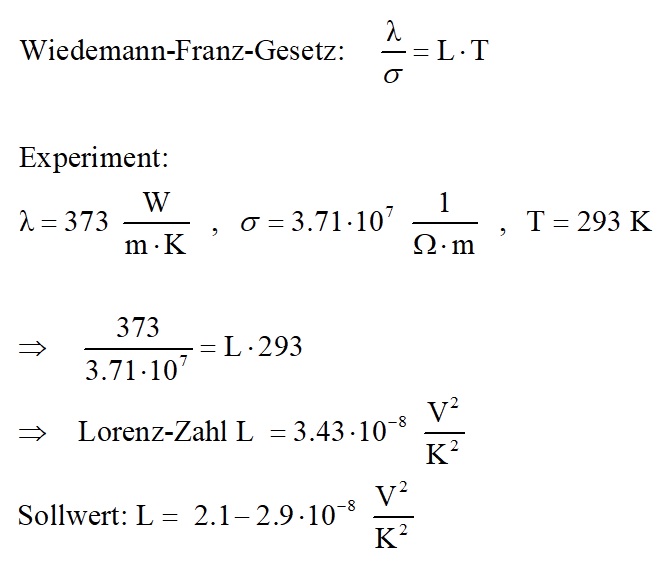
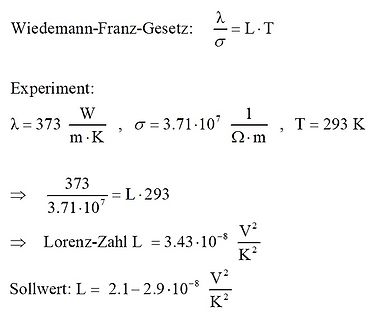
Berechnung des Wiedemann-Franz-Gesetzes
Wiedemann-Franz-Gesetz: λ/σ = L · T Experiment: λ = 373 W/(m·K), σ = 3.71·10⁷ 1/(Ω·m), T = 293 K ⇒ 373 / 3.71·10⁷ = L · 293 ⇒ Lorenz-Zahl L = 3.43·10⁻⁸ V²/K² Sollwert: L = 2.1 - 2.9·10⁻⁸ V²/K²
in „Physikprojekte“ · Offtopic · · Screenshots
-
Datei
Drehzahl-ST.asm
rirechts ; ja -> richtung rechts stellen sbi PORTD, dir ; Pin 2 (Bit3,PortD) = HIGH -> Linkslauf siehe L293D DS ldi wr0, 0x62 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnleft = LOW out TCCR0, wr0 ; COM01 = 1 COM00 = 0 ; -> OCR2 - BOTTOM - CCR0 = LOW -> OCR2 steigend -> länger LOW -> schneller rjmp richteinstend rirechts: cbi PORTD, dir ; Pin 2 = LOW -> Rechtslauf DS von L293D ldi wr0, 0x72 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnright = HIGH out TCCR0, wr0 ; COM01 = 1 COM00 = 1 ; -> OCR2 - Bottom - CCR0 = HIGH -> OCR2 steigend -> länger HIGH -> schneller richteinstend
in „Fehler im ASM-Code zur Motorsteuerung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Drehzahl-ST.asm
rirechts ; ja -> richtung rechts stellen sbi PORTD, dir ; Pin 2 (Bit3,PortD) = HIGH -> Linkslauf siehe L293D DS ldi wr0, 0x75 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnleft = HIGH out TCCR2, wr0 ; COM01 = 1 COM00 = 0 ; -> OCR2 - BOTTOM - CCR0 = HIGH -> OCR2 steigend -> länger LOW -> schneller rjmp richteinstend rirechts: cbi PORTD, dir ; Pin 2 = LOW -> Rechtslauf DS von L293D ldi wr0, 0x65 ; DS S91 T47 und DS L293 S9 Fig/Tab5 - Turnright = LOW out TCCR2, wr0 ; COM01 = 1 COM00 = 1 ; -> OCR2 - Bottom - CCR0 = LOW -> OCR2 steigend -> länger HIGH -> schneller richteinstend
in „Motorentreiber L293D“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
rnvn2dualmotor.pdf
Controllerboard. Die Steuerung ist sehr einfach, nahezu identisch mit der Ansteuerung der beliebten Motorchips L298 oder L293D. Die Geschwindigkeit ist über einem PWM-Port, der bis zu 20 Khz liefern darf, regelbar. Weitere 2 Eingänge bestimmen die Drehrichtung oder Motorbremsung. Der Anschluss erfolgt über 10 poligen
in „Ansteuerung von Motor-Treiber mit PWM“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Thermodruck.pdf
= 4:2 V bis 8.5 V. 1.2.2 Der Stepper Pro Pixel sind zwei Schritte notig. Ich steuere ihn mit einem L293D an, damit scha▯t der Stepper an einer Versorgung mit 8 V ca. 500 Steps/s (2 ms Delay). Der Spulenwi- derstand liegt bei ca. 15 , deshalb sollte der L293 zwische drin uber seine Enable{Pins abgeschaltet
in „Thermodrucker mbl1314a“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
rbook_src.txt
3 pin3: connected to vcc aka grün aka 2 pin4: connected to gnd (via pulldown) aka gelb aka 1 */ //L293B to turn the DC-motor clockwise/counter-clockwise const byte DCmotor_OutPin1 = 9; //L293B Pin2 const byte DCmotor_OutPin2 = 10; //L293B Pin7m //global variables int i=0; const unsigned long wheel_circumfence
in „mc-Roadbook: Tachosignal entstören“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
82546.pdf
Components Component Recommended Value Vishay Part Number 1 C1 100 nF VJ 1206 Y 104 J XXMT 2 C2 10 µF, 16 V 293D106X9016B2T 3 C3 100 nF VJ 1206 Y 104 J XXMT 4 C4 100 nF VJ 1206 Y 104 J XXMT 5 C5 100 nF VJ 1206 Y 104 J XXMT 6 C6 100 nF VJ 1206 Y 104 J XXMT 7 C7 1 µF. 16 V 293D105X9016A2T 8 C8 22 pF VJ 1206 A 220
in „Transparente, drahtlose Verbindung zweier RS232-Schnittst.“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
user-mannual-for-esp-12e-motor-shield.pdf
NodeMCU Lua module. This shield board is driven by the special excent large power full-bridge chip L293DD from the famous Stmicroelectronics company, which can directly drive 2-channels DC motors or one-channel stepper motor. The driven current can be arrived at 1.2A. This board is generated with national
in „Motorshield 12e / ESP8266“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Gaszyklon.pdf
Temperatur T0:= 273.15 ⋅ K Normdruck 3 pn:= 101.325 ⋅ 10 ⋅ Pa J spezifische Gaskonstante von Luft R L= 287 ⋅ kg ⋅ K − 6 dynamische Viskosität bei 20°C: η20 := 18.22 ⋅ 10 ⋅ Pa ⋅ s Eingabegrößen zur Auslegung des Zyklons Volumenstrom: l Q := 25 ⋅s Staubbeladung: B := 0.021 ρSt= 2500 ⋅ kg Staubdichte: 3
in „Einfacher Zyklon-Abscheider“ · Mechanik, Gehäuse, Werkzeug ·
-
Datei
eclipse_log.txt
java.util.concurrent.ScheduledThreadPoolExecutor$ScheduledFutureTask.run(ScheduledThreadPoolExecutor.java:293) at java.util.concurrent.ThreadPoolExecutor.runWorker(ThreadPoolExecutor.java:1142) at java.util.concurrent.ThreadPoolExecutor$Worker.run(ThreadPoolExecutor.java:617) at java.lang.Thread.run(Thread.java
in „Problem mit Breakpoints (Eclipse + JLink)“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
flipdot.pdf
R312 R314 R316 R318 R320 R322 R324 R326 R328 R330 R332 R334 R336 R338 R340 R342 R344 R346 ROW_5B R293 R295 R297 R299 R301 R303 R305 R307 R309 R311 R313 R315 R317 R319 R321 R323 R325 R327 R329 R331 R333 R335 R337 R339 R341 R343 R345 R347 L174 L175 L176 L177 L178 L179 L180 L181 L182 L183 L184 L185 L186
in „Flipdot Matrix - FP2800A“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
flipdot.pdf
D242 D244 D246 D248 D250 D252 D254 D256 D258 D260 D262 D264 D266 D268 D270 D272 D274 D276 D278 D280 L141 L142 L143 L144 L145 L146 L147 L148 L149 L150 L151 L152 L153 L154 L155 L156 L157 L158 L159 L160 L161 L162 L163 L164 L165 L166 L167 L168 ROW_5A B B D281 D283 D285 D287 D289 D291 D293 D295 D297 D299
in „Flipdot Matrix - FP2800A“ · Mikrocontroller und Digitale Elektronik ·