-
PDF
L297AN.PDF
motor interface.Unipolarsteppermotor can be driven with an L297plusa quad darlingtonarray. This note de- scribes the operation of the circuit andshows how it is used. The L297 Stepper Motor Controller is primarily in- L297 and a special version called L297A. The
in „µC_Steuerung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
l297_L6203.pdf
component are minimalized: an R.C. net- L6506 or L297, two full bridge BCD drivers anwork to set the chopper frequency, a resistive di- very few external components. Together these vider (R1; R2) to establish the comparator refer- three chips
in „Schrittmotorsteuerung mit l6203“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
L297_2.pdf
RESET INPUT & HOME OUTPUT ORDERING NUMBERS :L297 (DIP20) ENABLEINPUT L297D (SO20) DESCRIPTION featureof this device is that it requires only clock, The L297/A/D Stepper Motor Controller IC gener- direction and mode input signals.Since the phase
in „Schrittmotor+Schaltung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
L297_Application_Note.pdf
motor interface.Unipolarsteppermotor can be driven with an L297plusa quad darlingtonarray. This note de- scribes the operation of the circuit andshows how it is used. The L297 Stepper Motor Controller is primarily in- L297 and a special version called L297A. The
in „L297: Stromregelung schaltet an, nicht aus“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
IE3_5_1_Application_Notes_IC_L297.pdf
AN470 APPLICATION NOTE THE L297 STEPPER MOTOR CONTROLLER The L297 integrates all the control circuitry required to control bipolar and unipolar stepper motors. Used with a dual bridge driver such as the L298N forms a complete microprocessor-to-bipolar
in „Phase Chopping“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
rnstepp297.pdf
########################### 'Schrittmotoransteuerung mit RN-Control und 'Ansteuerungsboard RN-Stepp297 'RN-Stepp297 ist die bekannt Standardschaltung 'mit L297 und L298 (Bausatz) 'rn_stepp297_beispiele ' ' Achtung: ' Diese Demo ist mit Bascom Compiler 1.11.8.4 getestet ' Getestet mit RN-Schrittmotor
in „Frage bezüglich Schrittmotorsteuerung (RNStep297)“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
SSD1307.pdf
297.3 42 CL 2175.0 -325.0 122 SEG7 1082.2 297.3 202 SEG93 -1897.7 297.3 43 VSS 2235.0 -325.0 123 SEG6 1049.8 297.3 203 SEG94 -1930.1 297.3 44 VSS 2295.0 -325.0 124 SEG5 1017.4 297.3 204 SEG95 -1962.5 297.3
in „STM32 F103 - I2C Probleme“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
app6219-1.pdf
in Figure 6. The drivers like the L298N or L6202. To drive such a L297 implements enable chopping or one phase motor the center tap of the motor should be left chopping, selected by the control input. The unconnected and the two ends of
in „Motoransteuerung (24V, 4A) mit Mikrocontroller“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Stepper_Driving_Principles.pdf
considerthe implementation trolled by twodata : thereferencevoltageat pin15 of choppercurrent control in theL297. ofthecontrollerandthevalueofthesenseresis-tan- ceatpins1and 15oftheL298,thatis I L=V REF /RS. The oscillator on pin16 of the L297 resets the two By changingV REF it is very easy tovary the current
in „Schrittmotor ansteuern“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
3dstep_doku.pdf
betätigen des Sleep- und ggf- Boostsignals? nicht angeschlossen. Sie müssen Ist der Enable-Pin (10) an den L297 auf High-Pegel? isoliert werden, auf keinen Fall Gelegentlich wird der jeweilige L297 ebenfalls zerstört, wenn eine Endstufe kaputt geht. Im an Plus oder Masse anschließen. Zweifelsfall beide ICs
in „IC für Schrittmotor“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
3dstep_doku_1_.pdf
betätigen des Sleep- und ggf- Boostsignals? nicht angeschlossen. Sie müssen Ist der Enable-Pin (10) an den L297 auf High-Pegel? isoliert werden, auf keinen Fall Gelegentlich wird der jeweilige L297 ebenfalls zerstört, wenn eine Endstufe kaputt geht. Im an Plus oder Masse anschließen. Zweifelsfall beide ICs
in „Drehmoment des Schrittmotors zu niedrig“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
Abfotografierter Text über Schrittmotoren und Python-Code
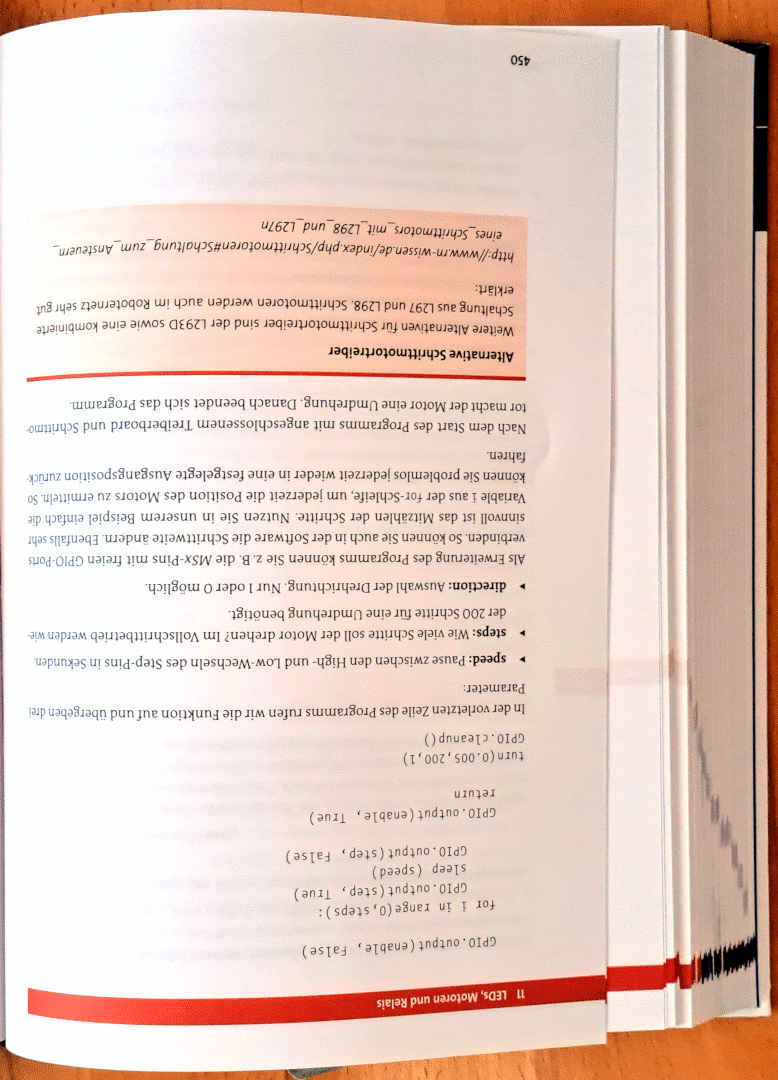
450 http://www.rn-wissen.de/index.php/Schrittmotoren_mit_L297_und_L297n Weitere Alternativen für Schrittmotortreiber sind der L293D sowie eine kombinierte Schaltung aus L297 und L298. Danach beendet sich das Programm. Nach dem Start des Programms mit angeschlossenem
in „Tipps zu: 600+ Schrittmotoren ansteuern“ · Mikrocontroller und Digitale Elektronik · · Fotos
-
PDF
AV02-0699EN.pdf
affect on the internal Display Oscillator Frequency. 11 Table2.ControlShiftRegister CONTROL WORD 0 L D6 D5 D4 D3 D2 D1 D0 Bit D7 On-Time Duty Relative Set Low PWM Brightness Oscillator Factor Brightness to Select Control Cycles (%) (%) Control Word 0 L L L L 0 0 0 L L L H 1 0.2 1.7 L L H L 2 0.4 3.3 L L H H 3 0.6 5.0 L H L L 4 0.8 6.7 L H L H 5 1.0 8.3 L H H L 7 1.4 11.7 L H H H 9 1.8 15 H L L L 11 2.1 18 H L L H 14 2.7 23 H L H L 18 3.5 30 H L H H 22 4.3 37 H H L L 28 5.5 47 H H L H 36 7.0 60 H H
in „Micro LED Dot-Matrix gesucht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Auflistung_Bauteile.pdf
driver with PWM current controller L6208N 1 DMOS driver for bipolar stepper motor L297D013TR 3 STEPPER MOTOR CONTROLLER L293E 3 PUSH-PULL FOUR CHANNEL DRIVERS DRV8811PWP 5 DRV8811 Stepper Motor Controller IC 2ED020i12-Fi 5 Half Bridge Driver L297/1 3 STEPPER MOTOR CONTROLLER L298HN 3 DUAL FULL-BRIDGE DRIVER L298P013TR 3 DUAL FULL-BRIDGE DRIVER L6208PD013TR 3 DMOS driver for bipolar stepper motor div. ICs Typ Menge Beschreibung TAS5505 5 4
in „[V] diverse Bauteile (Fets, BMS-ICs, Motor-Treiber“ · Markt ·
-
Datei
digiuhr.c
Zeilennummer (1...7) // und der anzuzeigenden Zahl (wenn in der Matrix eine 1 steht wird der Pin H sonst L) void Ziffer1(unsigned char zeilennummer, unsigned char Ziffer) { unsigned char zeile = zeilennummer - 1; unsigned int startidx = Ziffer * 5; // 1. Spalte (S1) if (PRG_RDB(&zahlen[zeile][startidx]))
in „DCF-Uhr mit DotMatrix-Anzeige für avr-gcc“ · Projekte & Code ·
-
PDF
SU1278.pdf
Description Ordering Symbol Rate Connector Aerial Mounting Number Ms/s Function Connector SU 1278/L 3112 297 12861 1 – 45 loop-through 2 x F vertical SU1278/S 3112 297 12851 1 – 45 single input 1 x F vertical SU1278/SH 3112 297 12871 1 – 45 single input 1 x F horizontal SU1278/LVA 3112 297 13011 1
in „Pollin - Receiver-Mainboard mit Twin DVB-[T,C] Tuner, NXP PNX8950EH“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Auflistung_Bauteile.pdf
Alone Multi-Cell Lithium- Ion/Polymer Precision Protectors Schrittmotor-Treiber Typ Menge Beschreibung L6207D013TR 3 DMOS dual full bridge driver with PWM current controller L6208D013TR 3 DMOS driver for bipolar stepper motor DRV8811PWP 10 DRV8811 Stepper Motor Controller IC L297D013TR 3 STEPPER MOTOR CONTROLLER DRV8811PWP 5 DRV8811 Stepper Motor Controller IC 2ED020i12-Fi 5 Half Bridge Driver L297/1 3 STEPPER MOTOR CONTROLLER L298P013TR 3 DUAL FULL-BRIDGE DRIVER L6208PD013TR 3 DMOS driver for bipolar stepper motor div. ICs Typ Menge Beschreibung TAS5504 5 4 Channel Digital Audio PWM Processor
in „[V] diverse Bauteile (Fets, BMS-ICs, Motor-Treiber“ · Markt ·
-
PDF
Auflistung_Bauteile.pdf
Alone Multi-Cell Lithium- Ion/Polymer Precision Protectors Schrittmotor-Treiber Typ Menge Beschreibung L6207D013TR 3 DMOS dual full bridge driver with PWM current controller L6208D013TR 3 DMOS driver for bipolar stepper motor DRV8811PWP 10 DRV8811 Stepper Motor Controller IC L297D013TR 3 STEPPER MOTOR CONTROLLER DRV8811PWP 5 DRV8811 Stepper Motor Controller IC 2ED020i12-Fi 5 Half Bridge Driver L297/1 3 STEPPER MOTOR CONTROLLER L298P013TR 3 DUAL FULL-BRIDGE DRIVER L6208PD013TR 3 DMOS driver for bipolar stepper motor div. ICs Typ Menge Beschreibung TAS5504 5 4 Channel Digital Audio PWM Processor
in „[V] diverse Bauteile (Fets, BMS-ICs, Motor-Treiber“ · Markt ·
-
PDF
Auflistung_Bauteile.pdf
Alone Multi-Cell Lithium- Ion/Polymer Precision Protectors Schrittmotor-Treiber Typ Menge Beschreibung L6207D013TR 3 DMOS dual full bridge driver with PWM current controller L6208D013TR 3 DMOS driver for bipolar stepper motor DRV8811PWP 10 DRV8811 Stepper Motor Controller IC L297D013TR 3 STEPPER MOTOR CONTROLLER DRV8811PWP 5 DRV8811 Stepper Motor Controller IC 2ED020i12-Fi 5 Half Bridge Driver L297/1 3 STEPPER MOTOR CONTROLLER L298P013TR 3 DUAL FULL-BRIDGE DRIVER L6208PD013TR 3 DMOS driver for bipolar stepper motor div. ICs Typ Menge Beschreibung TAS5504 5 4 Channel Digital Audio PWM Processor
in „[V] diverse Bauteile (Fets, BMS-ICs, Motor-Treiber“ · Markt ·
-
PDF
ics502.pdf
502 H 1 Revision 031105 Integrated Circuit Systems ● 525 Race Street, San Jose, CA 95126 ● tel (408) 297-1201 ● www.icst.com ICS502 LOCO™ PLL Clock Multiplier Pin Assignment Clock Decoding Table (MHz) S1 S0 CLK 0 0 x2 X1/ICLK 1 8 X2 0 1 x5 VDD 2 7 S1 M 0 x3 GND 3 6 S0 M 1 x3.33 1 0 x4 REF 4 5 CLK 1 1 x2.5
in „Logic Analyzer bauen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Schrittmotor.c
while(1) { //Bei drücken des Tasters 0 soll Pin1 HIGH gesetzt werden //dieser hängt am ENABLE des L297 if(!(PIND & (1<<PIND0))){ PORTB |= (1<<PB1); } if((PIND & (1<<PIND0)){ PORTB &= ~(1<<PB1); } } } ISR (TIMER0_OVF_vect) { // Bit-Zustand immer ändern beim aufrufen Overflow //Pin 0 geht auf Clock am L297 PORTB ^= (1<<PB0); // XOR, PORTB = PORTB ^ (1<<PB0) }
in „Schrittmotor Schritte zählen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Osram_LW_P4SG.pdf
Gruppe Cx Cy Gruppe Cx Cy Group Group 5K 0.296 0.259 7K 0.330 0.310 0.291 0.268 0.330 0.330 0.310 0.297 0.338 0.342 0.313 0.284 0.352 0.344 5L 0.291 0.268 7L 0.330 0.330 0.285 0.279 0.330 0.347 0.307 0.312 0.347 0.371 0.310 0.297 0.345 0.352 6K 0.313 0.284 8K 0.352 0.344 0.310 0.297 0.338 0.342 0.330 0.330 0.364 0.380 0.330 0.310 0.360 0.357 6L 0.310 0.297 8L 0.345 0.352 0.307 0.312 0.347 0.371 0.330 0.347 0.367 0.401 0.330 0.330 0.364 0.380 2009-04-30 5 LW P4SG Helligkeits-Gruppierungsschema Brightness Groups 1)Seite 18 2)Seite 18 Helligkeitsgruppe
in „Conrad 181801 - LED-Leiste mit NiMH Akkus betreiben“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
vestel_17ips71-r3_sch.pdf
-r3 A3 SCH NAME : 2 T. SHT: 2 DRAWN BY : <YOUR NAME HERE> 19-11-2013_13:35 1 2 3 4 5 6 7 8 AXM 1LP L P 3NC 3 1Q C 18 R 38R 4 61J 3 J 91S 22C 2 8D 4C C 7 5 7D 4 02S 4 82J 5 5 5 1 2 62D J 4 5 J 84J J J 8 2 51D 82D 1 J J 4 L 52D 2 2 1 72D C 41D L S 35J 6 5 8 42D L 13J J J 83D 93D 9D 01D L 31D 92D 3 1 7 32D J L N C 78C C 21D 22D 44J 3SH 5 5 J J 04J 11D 09C 7 4 5 5 83J C J J L 8 7 54C 37 1 1 C F F 9 0 71S F F 24J 02J 1S 31J 01J 0 C 88C 03 J 92J 1 C 22J 2 J 2U 1RT 0 0 2RT C C 1 R 9C 8 S 6 N H4 3 C T T 3 L 6 1
in „TV PSU 17IPS71 Sekundärseitig Kurzschluss?“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
vestel_17ips71-r3_sch.pdf
-r3 A3 SCH NAME : 2 T. SHT: 2 DRAWN BY : <YOUR NAME HERE> 19-11-2013_13:35 1 2 3 4 5 6 7 8 AXM 1LP L P 3NC 3 1Q C 18 R 38R 4 61J 3 J 91S 22C 2 8D 4C C 7 5 7D 4 02S 4 82J 5 5 5 1 2 62D J 4 5 J 84J J J 8 2 51D 82D 1 J J 4 L 52D 2 2 1 72D C 41D L S 35J 6 5 8 42D L 13J J J 83D 93D 9D 01D L 31D 92D 3 1 7 32D J L N C 78C C 21D 22D 44J 3SH 5 5 J J 04J 11D 09C 7 4 5 5 83J C J J L 8 7 54C 37 1 1 C F F 9 0 71S F F 24J 02J 1S 31J 01J 0 C 88C 03 J 92J 1 C 22J 2 J 2U 1RT 0 0 2RT C C 1 R 9C 8 S 6 N H4 3 C T T 3 L 6 1
in „L40f278x3cw-3DU Vestel 171ps71“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
main.c
UBRR_VAL ((F_CPU+BAUD*8)/(BAUD*16)-1) // clever runden /*---ENDE---*/ /* PORT Bezeichnungen für den L297 (Motortreiber) bzw. Attiny2313 */ #define EN PD5 #define DIR PD4 #define CLK PD3 /*---ENDE---*/ /* Globale Variablen */ volatile char received_data[20]; // Buffer wo die empfangenen Daten gespeichert
in „Nochmals Frage zu UART“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
speichenberechnung.pdf
hinzu addiert werden. F = Felgenradius N = Lochkreisradius Nabe L = Lochzahl K = Kreuzungszahl Z = Flanschversatz von Mitte ----------------------------------------------------------------------------------------------------------- Lochzahl LK-Radius Z-Maß F-Radius nicht 3-fach 4-fach 36 19 31 304 289 299 305 36 22,5 33 304 285 297 305 36 22,5 15 304 284 296 303 36 19 31 300 285 295 301 36 22,5 33 300 281 293 301 36 22,5 15 300 280 292 299 36 19 31 295 280 290 296 36 22,5 33 295 276 288 296 36 22,5 15 295 275 287 294 32 19 31
-
PDF
5WAXIAL_9WAXIAL_11WAXIAL_17WAXIAL_YAG.pdf.pdf
Kennzeichnung Klartextaufdruck Abmessungen inmm: Typ Widerstandswertbereich L 1 Min. Max. 10% 5% KH206-8 0R056 0R10 9K1 20 ±1,0 KH208-8 0R075 0R15 15K 25 ±1,0 KH210-8 0R11 0R33 33K 38 ±1,0 KH212-8 0R075 0R15 15K 25 ±1,0 KH214-8 0R11 0R33 33K 38 ±1,0 KH216-8 0R15 0R51 47K 50 ±1,5
in „Strommesswiderstand“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
YAG.pdf
Kennzeichnung Klartextaufdruck Abmessungen inmm: Typ Widerstandswertbereich L 1 Min. Max. 10% 5% KH206-8 0R056 0R10 9K1 20 ±1,0 KH208-8 0R075 0R15 15K 25 ±1,0 KH210-8 0R11 0R33 33K 38 ±1,0 KH212-8 0R075 0R15 15K 25 ±1,0 KH214-8 0R11 0R33 33K 38 ±1,0 KH216-8 0R15 0R51 47K 50 ±1,5
in „Einfache Arduino Heizungspumpensteuerung“ · Haus & Smart Home ·
-
 Bild
Schaltplan einer Spannungsregelung
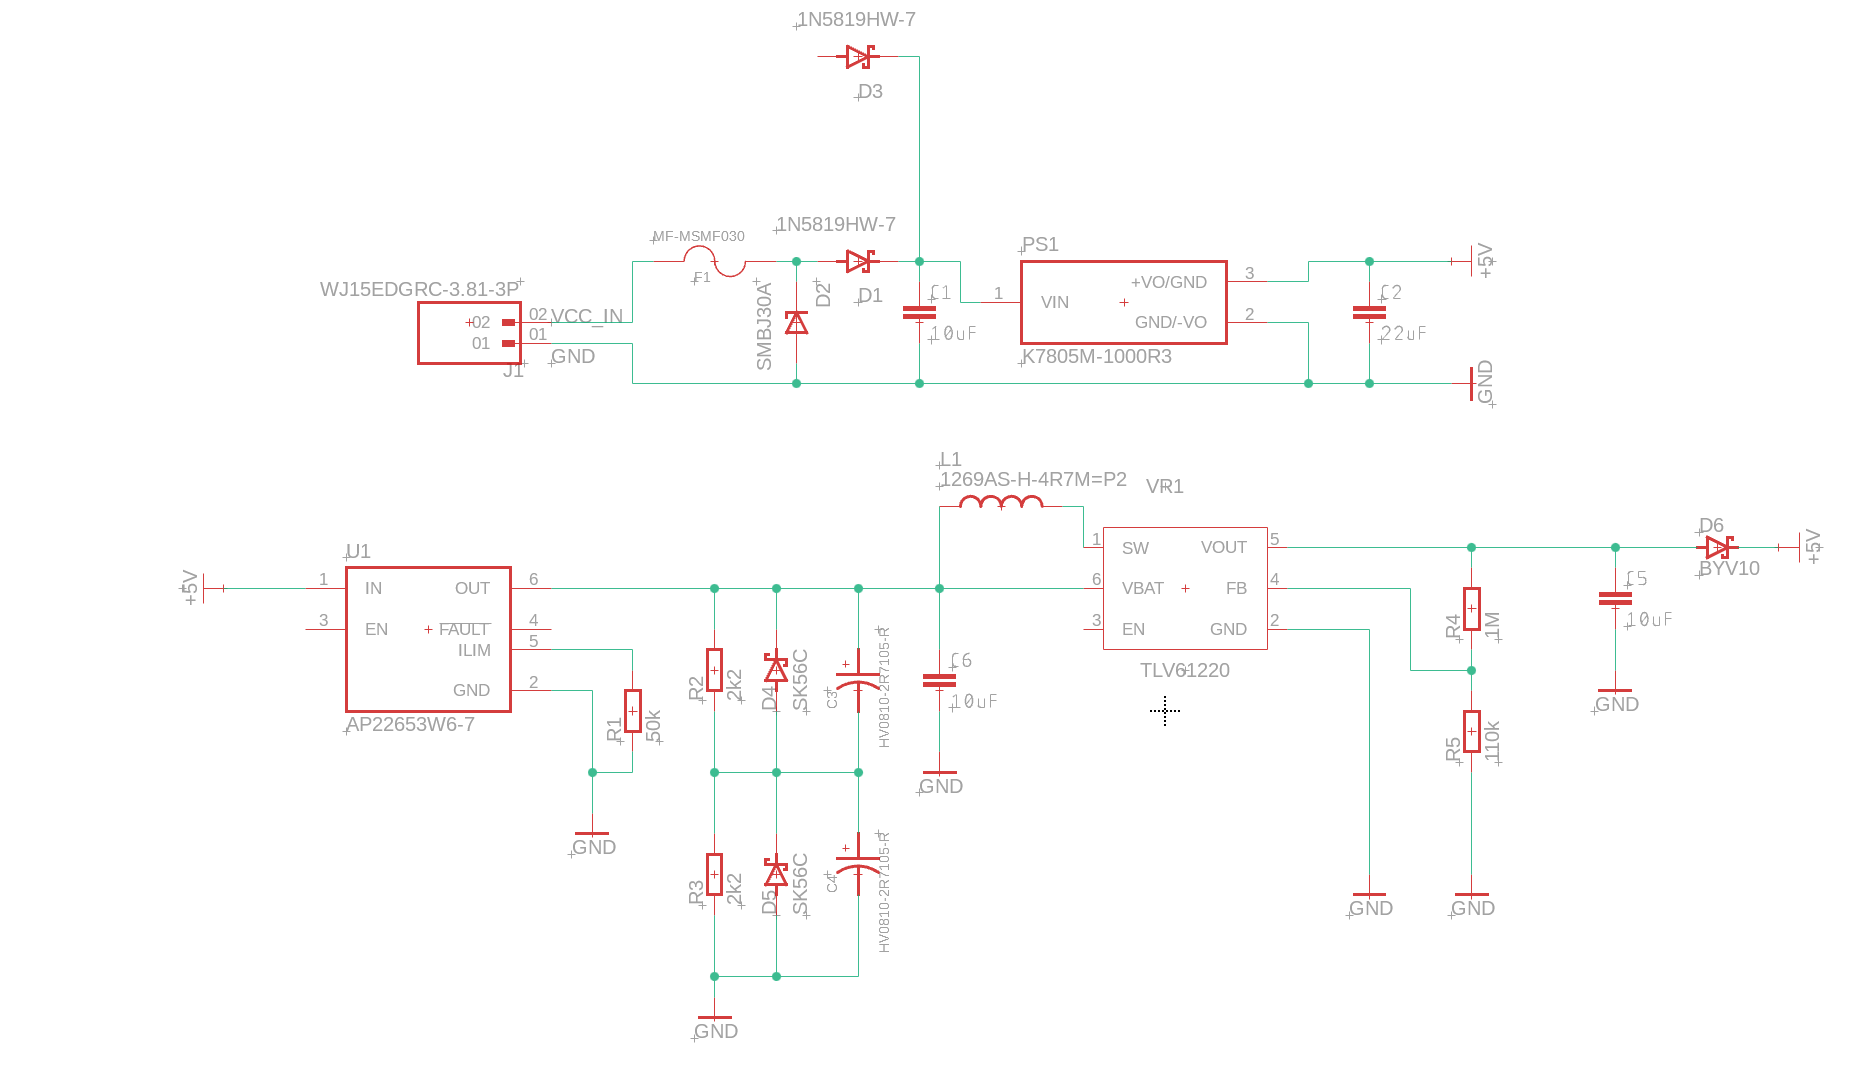
10uF WJ15EDGRC-3.81-3P J1 +02 02_VCC_IN 01 01 GND +5V PS1 1 VIN 3 2 GND/VO K7805M-1000R3 22uF GND L1 1269AS-H-47R=P2 VR1 SW VOUT FB GND U1 AP22653W6-7 1 IN 6 OUT 3 EN 4 +FAULT ILIM 5 GND 2 R1 54K R2 2K2 R3 2K2 D4 SK56C D5 SK56C C4 HV0810-297.05 10uF C5 HV0810-297.05 10uF R4 1M R5 110K TLV61220
in „"micro USV" für Rock Chip max 3,3W 30s“ · Analoge Elektronik und Schaltungstechnik · · Schaltpläne
-
PDF
Display_-_NL10276BC30-04D.pdf
Diagonal display area: 38 cm (15 inches)] Number of pixels 1024 (H)× 768 (V) pixel Dot pitch 0.099 (H)× 0.297 (V) mm Pixel pitch 0.297 (H)× 0.297 (V) mm Pixel arrangement RGB (red, green, blue) vertical stripe – Display colors 262,144 (RGB, 6 bit) color Weight 1560 (typ.), 1610 (max.) g ABSOLUTE MAXIMUM RATINGS
in „VIA Nano Board LVDS Connector“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Display_-_NL10276BC30-04D.pdf
Diagonal display area: 38 cm (15 inches)] Number of pixels 1024 (H)× 768 (V) pixel Dot pitch 0.099 (H)× 0.297 (V) mm Pixel pitch 0.297 (H)× 0.297 (V) mm Pixel arrangement RGB (red, green, blue) vertical stripe – Display colors 262,144 (RGB, 6 bit) color Weight 1560 (typ.), 1610 (max.) g ABSOLUTE MAXIMUM RATINGS
in „günstiges ITX Mainboard mit LVDS Connector“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
lproptions-mg5400-3.80EN.txt
legal Legal [8.50"x14.00" 215.9x355.6mm] a5 A5 [5.83"x8.27" 148.0x210.0mm] a4 A4 [8.27"x11.69" 210.0x297.0mm] b5 B5 [7.17"x10.12" 182.0x257.0mm] 4X6 4"x6" [4.00"x6.00" 101.6x152.4mm] 5X7 5"x7" [5.00"x7.00" 127.0x177.8mm] 8X10 8"x10" [8.00"x10.00" 203.2x254.0mm] l L [3.50"x5.00" 89.0x127.0mm] 2l 2L [5.00
in „Kann das Drucken mit Linux dem Drucker schaden??“ · PC Hard- und Software ·
-
PDF
Schrittmotor.pdf
; nicht mehr beim Hersteller (Philips) aufgelistet, bei Bauteilhändlern durchaus noch im Programm) L297 (nur Logikteil für Voll- und Halbschrittmodus, zur Kombination mit Leistungsteil L298) wobei ausführliche Informationen (auch zur Schrittmotorsteuerung allgemein) in den jeweiligen Datenblättern zu
in „Schrittmotoren“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
flipdot.pdf
R316 R318 R320 R322 R324 R326 R328 R330 R332 R334 R336 R338 R340 R342 R344 R346 ROW_5B R293 R295 R297 R299 R301 R303 R305 R307 R309 R311 R313 R315 R317 R319 R321 R323 R325 R327 R329 R331 R333 R335 R337 R339 R341 R343 R345 R347 L174 L175 L176 L177 L178 L179 L180 L181 L182 L183 L184 L185 L186 L187 L188
in „Flipdot Matrix - FP2800A“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
flipdot.pdf
D242 D244 D246 D248 D250 D252 D254 D256 D258 D260 D262 D264 D266 D268 D270 D272 D274 D276 D278 D280 L141 L142 L143 L144 L145 L146 L147 L148 L149 L150 L151 L152 L153 L154 L155 L156 L157 L158 L159 L160 L161 L162 L163 L164 L165 L166 L167 L168 ROW_5A B B D281 D283 D285 D287 D289 D291 D293 D295 D297 D299
in „Flipdot Matrix - FP2800A“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ADXL335.pdf
EightPartsSolderedtoPCB Rev. 0 | Page 7 of 16 ADXL335 20 0.320 N = 8 0.315 15 0.310 N ) I / T ( 0.305 L Y U I P 10 I 0.300 P I F S O E 0.295 % S 5 0.290 0.285 0 0.285 0.288 0.291 0.294 0.297 0.300 0.303 0.306 0.309 0.312 0.315 0.280 2 0 –40 –30 –20 –10 0 10 20 30 40 50 60 70 80 90 100 8 SENSITIVITY (V/
in „Bewegungssensor für Fahrrad Alarm“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
IL3829.pdf
Interface Control Signal Bus D7 D6 D5 D4 D3 D2 D1 D0 E R/W# CS# D/C# RES# Interface (RD#) (WR#) SPI4 L NC SDin SCLK L L CS# D/C# RES# 8-bit 8080 D [7:0] RD# WR# CS# D/C# RES# SPI3 L NC SDin SCLK L L CS# L RES# 8-bit 6800 D [7:0] E R/W# CS# D/C# RES# Note (1) L is connected toSS (2) H is connected toDDIO
in „IL3829 - E-Paper Display Treiber“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Cinni-Regler_V1-1-Partlist.pdf
Keramikkond. X7R SMD 100n C1206 2 Reichelt X7R-G1206 100N 0,050 € 0,050 € IC1 1 Low-Drop Sp.-Regler 5V L4941 TO220 1 Reichelt L 4941 0,960 € 0,960 € IC11 1 AVR-MicroController ATmega8L-28P DIL28-3 2 Reichelt ATMEGA 8L8 DIP 2,350 € 2,350 € IC12 1 RS232 Interface MAX232ECSE SO16 2 Reichelt MAX 232 ECSE 1,200 € 1,200 € K1 1 Solid-State-Relais S202S11 S2XXEX 1 Reichelt S202 S11 7,150 € 7,150 € 1) L1 1 Funk-Entstördrossel 45µ SFT830D 1 Reichelt FED 45µ 1,050 € 1,050 € L2 1 Funk-Entstördrossel 45µ SFT830D 1 Reichelt FED 45µ 1,050 € 1,050 € LED1 1 LED 3mm rot RT LED3MM 2 Reichelt LED 3MM ST RT 0,080
in „Vorstellung Drehzahlregler mit Triac in Steckergehäuse“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
20D180K-SUNSTAR.pdf
Temperature˖-40ć ~ +85ć Storage Temperature˖ -40ć ~ +125ć PART NUMBER CODE Tolerance Type K: f10% D: Disk L: f15% Element Diameter Varistor Voltage S: Square M: f20% Revision:15-Feb-12 Z O V 20ĭ SERIES PACKAGE DIMENSIONS D D D T H H1 H1 4.0 max Kİ 3.0 Kİ 3.0 d1 d d L1 L1 D1 D1 D1 F TYPE TABLE 1 TABLE 2 unit
-
PDF
ArduinoUnoSolarCalculations.pdf
21.448/3600 - 46.815/3600•T – (0.00059/3600)•T + (0.001813/3600)•T (21.2) Right ascension: -1 tan [(sin(L trueos(Obliquity)/cos(L true] (12.3) 4 Universal time is standard time at the Greenwich meridian (longitude = 0º). 2 Declination: -1 sin [sin(Obliquity) •sin(L true] (12.4) Hour angle: Greenwich hour
in „Julianisches Datum / Sonnenstandsberechnung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Cinni-Regler_V1-1a-Partlist.pdf
Keramikkond. X7R SMD 100n C1206 2 Reichelt X7R-G1206 100N 0,050 € 0,050 € IC1 1 Low-Drop Sp.-Regler 5V L4941 TO220 1 Reichelt L 4941 0,960 € 0,960 € IC11 1 AVR-MicroController ATmega8L-28P DIL28-3 2 Reichelt ATMEGA 8L8 DIP 2,350 € 2,350 € IC12 1 RS232 Interface MAX232ECSE SO16 2 Reichelt MAX 232 ECSE 1,200 € 1,200 € K1 1 Solid-State-Relais S202S11 S2XXEX 1 Reichelt S202 S11 7,150 € 7,150 € 1) L1 1 Funk-Entstördrossel 45µ SFT830D 1 Reichelt FED 45µ 1,050 € 1,050 € L2 1 Funk-Entstördrossel 45µ SFT830D 1 Reichelt FED 45µ 1,050 € 1,050 € LED1 1 LED 3mm rot RT LED3MM 2 Reichelt LED 3MM ST RT 0,080
in „Vorstellung Drehzahlregler mit Triac in Steckergehäuse“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
1N5283_1_1N5314_1-3442128.pdf
Storage Temperature T Jnd T STG -65 to +175 oC o 6 Lake Street, Thermal Resistance Junction-to-Lead @ L = .375 in RӨJL 250 C/W Lawrence, MA 01841 Thermal Impedance ZӨJX 25 OC/W Tel: 1-800-446-1158 or o (1) (978) 620-2600 Steady-State Power Dissipation @ T L +50 C, L = 3/8” PD 500 mW Fax: (978) 689-0803
-
Datei
Buffer.c
DDRC |= ((1<<0) | (1<<1) | (1<<2) | (1<<3) | (1<<4) | (1<<5) | (1<<6) | (1<<7)); //0,1,2 XYZ Ausgang(L297 Clock Eingang) 3,4,5 XYZ Richtung PORTC |= ((1<<0) | (1<<1) | (1<<2) | (1<<3) | (1<<4) | (1<<5) | (1<<6) | (1<<7)); //put to high (L297 is active-low) DDRD &= ~((1<<4) | (1<<5) | (1<<6)); //4,5,6
in „Interrupt Fehlerquellen - FIFO Buffer“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
vishayHVTantal.pdf
*040P0A 1000 34 27 1.5 195 297 400 20 - 75 + 20 + 35 82 694 1.125 1.100 XTV108*040P0A 50 WVDC AT + 85 °C 900 44 32 1.5 195 297 400 25 - 85 + 20 + 35 82 694 1.125 1.100 XTV907*050P0A Note * Insert Tolerance Code: T = - 15 + 50 % (
in „Tantal für 400V“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
Wellenplan-1926.pdf
29, Nov, bis 5, Dez, 1926 Sprachkurse RADIO-WIEN Nr, 9 L' articolo indeterminato femmlnile ha una sola Esercicio forma (una), la quäle siapostrofa dinanzi a vocale Preponete 1'articolo determinato e 1indeter , p, e, un' ora , , . plurale: le ore minato prima
-
PDF
7488930245.pdf
341345 1721 333337 25 29 329 0 33 325 37 321 41 317 -5 45 z 313 49 309 53 305 -10 57 301 61 180 ° 297 65 -15 293 69 289 73 285 -20 77 281 81 277 -25 85 90° 270 ° 273 89 269 93 x 265 97 261 101 257 105 253 109 249 113 245 117 0° 241 121 237 125 y 233 129 229 133 225 137 221217 145141 213 149 209 153
in „[V] 10 St. Würth SMD Antennen: Antennen WE-MCA Multilayer Chip 2400-2500MHz 50ohm (8€)“ · Markt ·
-
PDF
7488910245.pdf
functions or performance. Evaluation Board: [mm] Typical Return Loss: 0 -5 B [ -10 COU$ 150101 s o L r e R P2 P1 PA -15 PJJ -20 COJ101 -25 1 2 3 4 Frequency [GHz] S11 CHECKEDREVISIODATE (YYYGENERAL TOLERAMETHODTION MuK 002.0002021-07-0DIN ISO 2768-1m DESCRIPTION WE-MCA Multilayer Chip Antenna Würth
in „[V] 10St. Würth WE-MCA Multilayer Chip Antenna 2,4GHz Bluetooth, GSM, WiFi, etc“ · Markt ·
-
PDF
SPG___Motor_typ_ISG3240__.pdf
PAGE MOTOR SPECIFICATION 1 of 2 M O D E L : TS05-0449 ✝ ✞ ✟ ✠ ✡ ☛ ☞ ☛ ✌✌✍ ELECTRICAL ✎✏ ✑✒✓✔ ✕ ✖ ✗✘✔✙ ✓✚✛ ✔ ✜✢✙✣ ✤✜✚✢ ✥ ✔✦✔✙ ✧✚✑✚✦ ★✏ ✦✘✑✔✙ ✩✚ ✛✑✥ ✔ ✕ ✘✤ ✎✎✪ ✩ ✫✬ ✗✭ ✮✏ ✓✚ ✔✖ ✕ ★ ✓ ✯✏ ✢✚ ✛✚✘✙ ✤✗✘✦✘✤✑ ✔✦✜✖✑✜✤✖ ✘✰ ✥✱✲✳✱ ✴✧ ✵✰✵✳ ✘✶✶✷ ✸ ✯✹✎✏ ✤✣✦
in „crushermotor Steuerungsproblem“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
EDN_DI_6594092.pdf
comparator as when the battery voltage, after V 5V 3(11R /R ), tion as a Schmitt trigger, lighting L1D when the battery recharging,exceedsthethresh- T1 REF 1 3 is fully charged. where V REF, the internal old voltage.EDN 58 EDN | september 18, 2008 edn080807di42991DIANE designideas through D and the
in „Einstellbarer Step-Up Regler“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
EDN_DI_6594092.pdf
comparator as when the battery voltage, after V 5V 3(11R /R ), tion as a Schmitt trigger, lighting L1D when the battery recharging,exceedsthethresh- T1 REF 1 3 is fully charged. where V REF, the internal old voltage.EDN 58 EDN | september 18, 2008 edn080807di42991DIANE designideas through D and the
in „mit µc einstellbarer Spannungsregler“ · Mikrocontroller und Digitale Elektronik ·