Suchergebnisse für "STM"
COM Port betreiben */ #include "usb.h" /* For devices with 2 x 16 bits / word access schema (e.g. STM 32L0, STM 32F303xD and xE) */ //#define UMEM_SHIFT 0 //#define UMEM_FAKEWIDTH word /* For devices with 1 x 16 bits / word access schema (e.g. STM 32F103, STM 32F302, STM 32F303xB and xC) */ #define UMEM_SHIFT 1 #define UMEM_FAKEWIDTH dword /* The name of the IRQ handler must match startup_stm 32.s */ #define NAME_OF_USB_IRQ_HANDLER USB_LP_CAN_RX0_IRQHandler /* Take the number from the reference manual of your µC. */ #define USB_IRQ_NUMBER 20 // Enable trace messages #define ENABLE_TRACING
in
„USB CDC von Stefan Frings und WS“
·
Mikrocontroller und Digitale Elektronik
·
25.02.2020 21:35
/h2> */ /* Includes ------------------------------------------------------------------*/ #include "stm 32f10x.h" #include "platform_config.h" /** @addtogroup STM 32F10x_StdPeriph_Examples * @{ */ /** @addtogroup CAN_Normal * @{ */ /* Private typedef -----------------------------------------------------
in
„CAN mit STM32“
·
Mikrocontroller und Digitale Elektronik
·
13.05.2012 17:23
/* include the common STM 32F103RE sub-script */ /* Common part of the linker scripts for STM 32 devices*/ /* default stack sizes. These are used by the startup in order to allocate stacks for the different modes. */ __Stack_Size
in
„STM32: Linkerscript löst Debugging-Problem aus?“
·
Mikrocontroller und Digitale Elektronik
·
17.04.2011 18:08
/* ------------------------------------------------------- adc_test.c MCU : STM 8S103F3 Takt : interner Takt 16 MHz 19.05.2016 R. Seelig ------------------------------------------------------ */ #include "stm 8s.h" #define u_ref 331ul // gemessene Betriebsspg.: 3.31 V ( * 100 ) #
in
„STM8 und ADC“
·
Mikrocontroller und Digitale Elektronik
·
21.12.2017 12:38
-----------------------------------------------*/ #include <stdlib.h> #include <stdio.h> #include "stm 32f1xx_hal.h" #include "bme280.h" #include "u8g.h" #include "u8g_com_arm_stm 32.h" /* USER CODE BEGIN Includes */ /* USER CODE END Includes */ /* Private variables ------------------------------------
in
„STM32 F103 - I2C Probleme“
·
Mikrocontroller und Digitale Elektronik
·
02.02.2018 07:51
--------------------------------------------------------------- * Change hardware pin here for ARM STM 32 *--------------------------------------------------------------------------------------------------------------------------------------------------- */ #elif defined (ARM_STM 32) // use C13 as IR input on STM 32 # define IRMP_PORT_LETTER C # define IRMP_BIT_NUMBER 13 /*------------------------------------------------------------------------------------------------------------------------------------------
in
„IRMP-Problem“
·
Mikrocontroller und Digitale Elektronik
·
14.11.2015 00:01
false 0 /* Includes ------------------------------------------------------------------*/ #include "stm 32l4xx_hal.h" //#include "usb_device.h" TIM_HandleTypeDef htim2; uint8_t IN_BYTE, led_status, fft_status; volatile uint16_t timer_led, fft_timer; void SystemClock_Config(void); static void MX_GPIO_Init
in
„STM32L4 Disco-Board CPU arbeitet nicht korrekt?!“
·
Mikrocontroller und Digitale Elektronik
·
04.10.2016 15:25
fill_tcp_data_p(buf, plen, "</table>"); plen = fill_tcp_data_p(buf, plen, PSTR("<a style=color:red><h1>STM 32F103 WEBSERVER<h1></a>")); plen = fill_tcp_data_p(buf, plen, "<table border>" ); plen = fill_tcp_data_p(buf, plen, "<thead>"); plen = fill_tcp_data_p(buf, plen, "<tr>"); plen = fill_tcp_data_p(buf,
in
„Webpage Webserver“
·
Mikrocontroller und Digitale Elektronik
·
14.03.2015 21:02
Bild
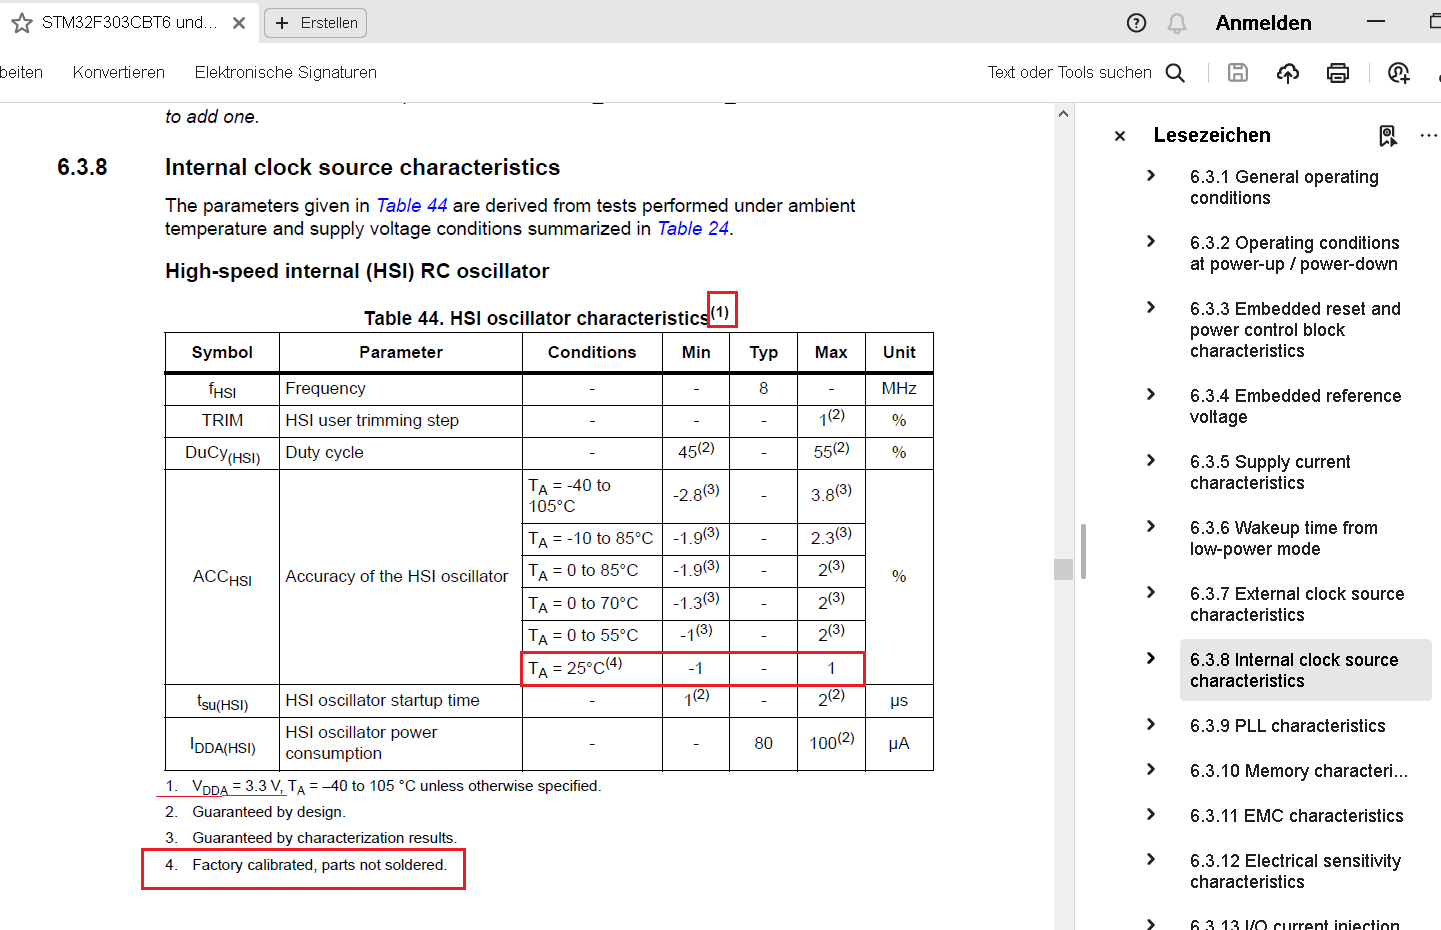
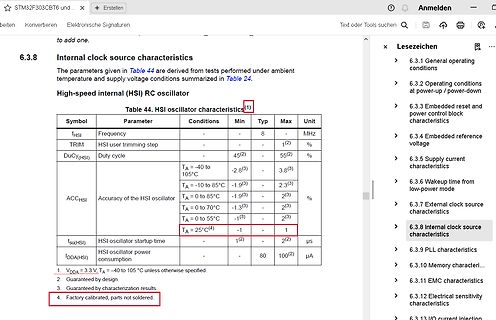
STM 32F303CBT6, Table 44. HSI oscillator characteristics, fHSI Frequency, TRIM HSI user trimming step, DuCY(HSI) Duty cycle, ACC_HSI Accuracy of the HSI oscillator, tsu(HSI) HSI oscillator startup time,
in
„Müll in serieller Übertragung wenn Kondensator am Quarz berührt wird“
·
Mikrocontroller und Digitale Elektronik
·
15.03.2024 14:32
·
Screenshots
Bild
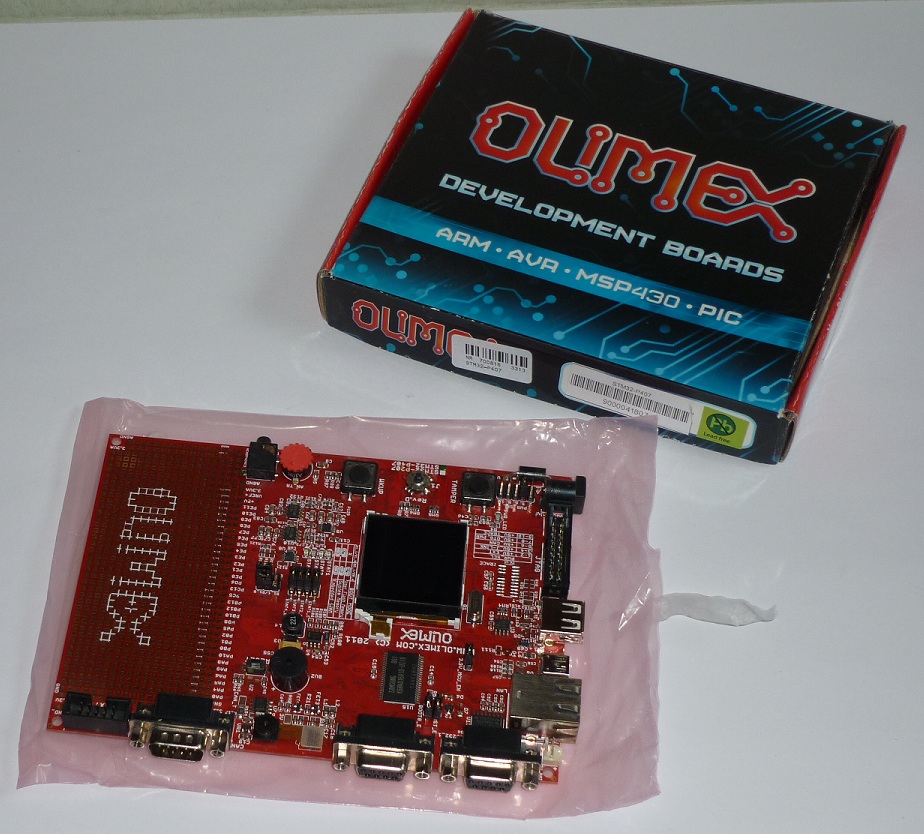
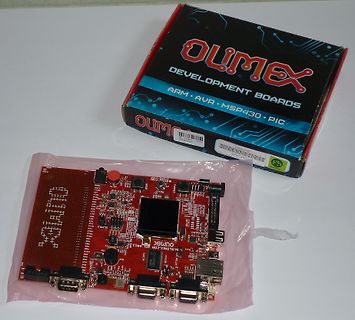
OLIMEX DEVELOPMENT BOARDS ARM AVR MSP430 PIC OLIMEX www.olimex.com
in
„[V] Evalboard Olimex STM32-P407“
·
Markt
·
19.01.2025 10:41
·
Platinenfotos
Bild
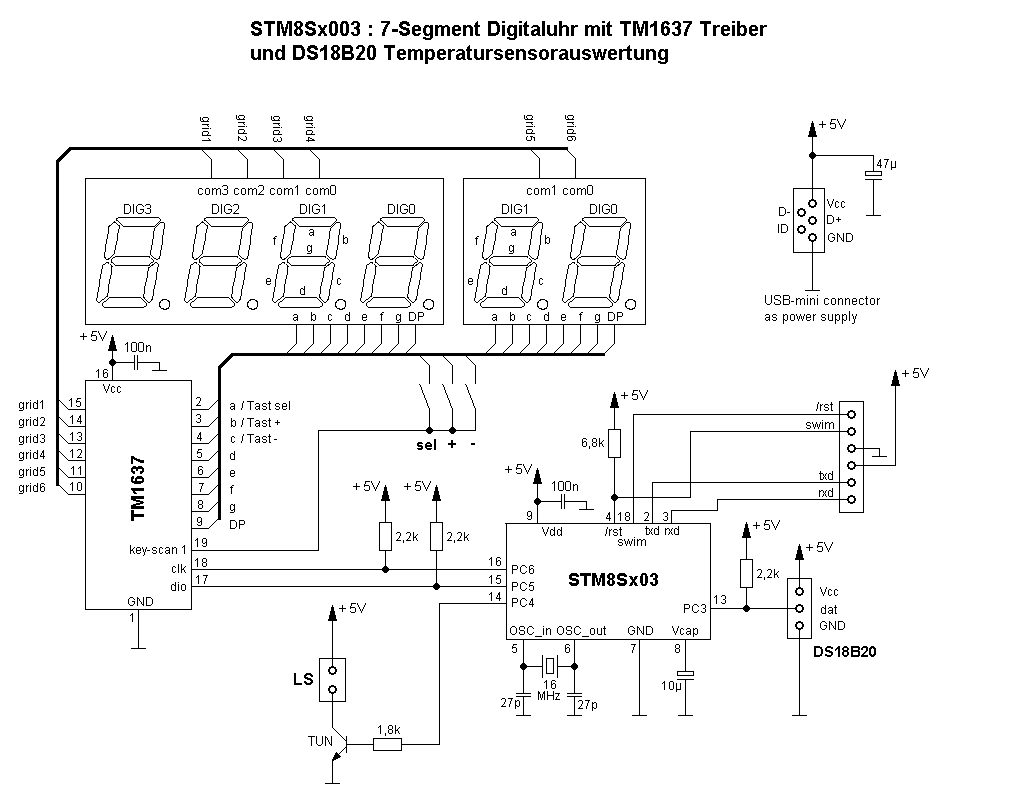
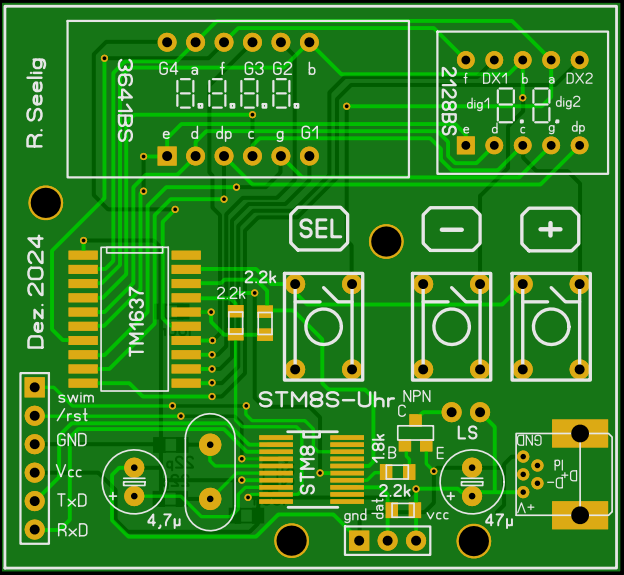
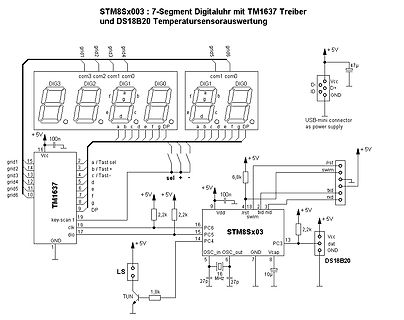
STM 8Sx003 : 7-Segment Digitaluhr mit TM1637 Treiber und DS18B20 Temperatursensorauswertung
DIG3 DIG2 DIG1 DIG0
com3 com2 com1 com0
a b c d e f g DP
TM1637
key-scan 1
clk 18
dio 17
DS18B20
USB-mini connector
in
„Uhr mit STM8Sxx3 und TM1637“
·
Projekte & Code
·
22.01.2025 16:46
·
Schaltpläne
Bild
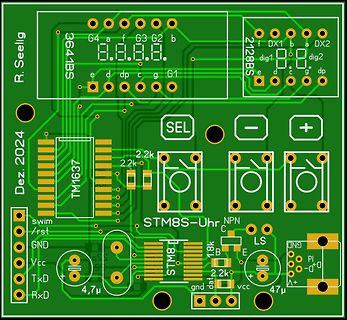
DX1 b a DX2 dig1 8. dig2 dp e d dp c g G1 SEL + - TM1637 2.2k 2.2k swim /rst GND Vcc TxD RxD 4,7µ STM 8S-Uhr NPN C LS GND PI - 0 0 4,7µ gnd dat vcc STM 8
in
„Uhr mit STM8Sxx3 und TM1637“
·
Projekte & Code
·
22.01.2025 16:46
·
Layouts
Bild
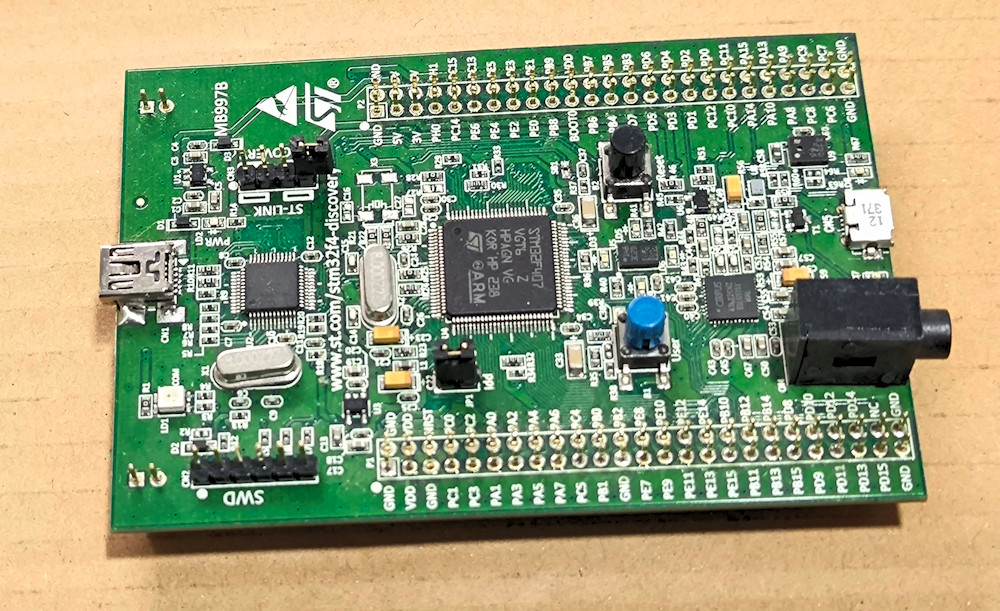
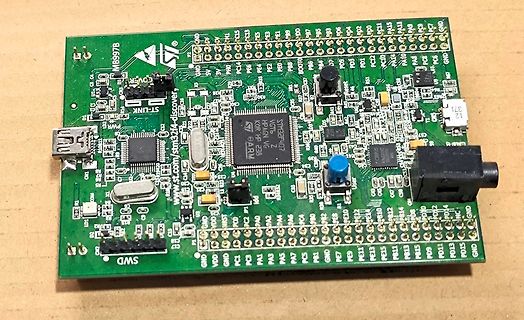
ST STM 32F407 ARM Cortex-M4 stm 32.st.com SWD PWR GND VDD PA0 bis PD15
in
„[V] Diverse Evaluation-Boards - ca. 2014-2016“
·
Markt
·
05.02.2025 08:46
·
Platinenfotos
Bild
Bild
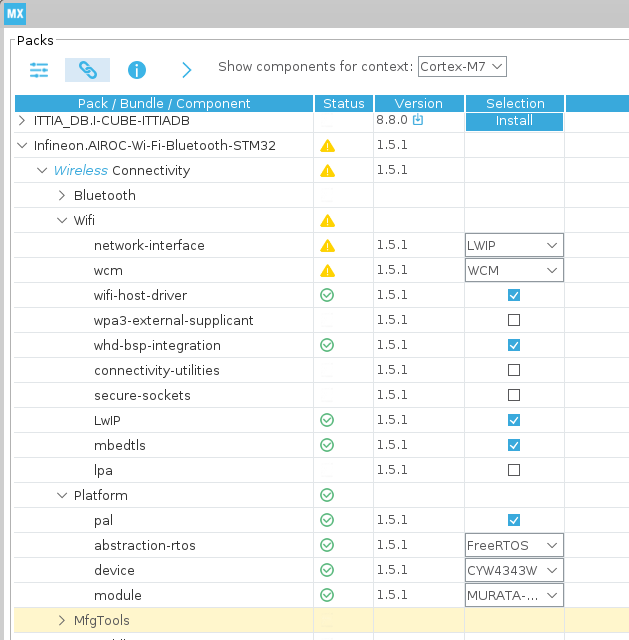
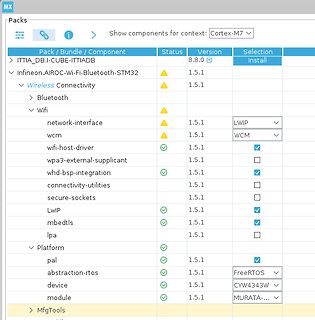
Component Status Version Selection
ITTIA_DB.I-CUBE-ITTIADB 8.8.0 Install
Infineon_AIROC-Wi-Fi-Bluetooth-STM 32 1.5.1
Wireless Connectivity 1.5.1
Bluetooth
Wifi
network-interface 1.5.1 LWIP
wcm 1.5.1 WCM
wifi-host-driver 1.5.1
wpa3-external-supplicant 1.5.1
whd-bsp-integration 1.5.1
connectivity-utilities 1.5.1
in
„STM32 + Infineon WLAN Modul: Durchsatz?“
·
Mikrocontroller und Digitale Elektronik
·
01.11.2024 12:20
·
Screenshots
Bild
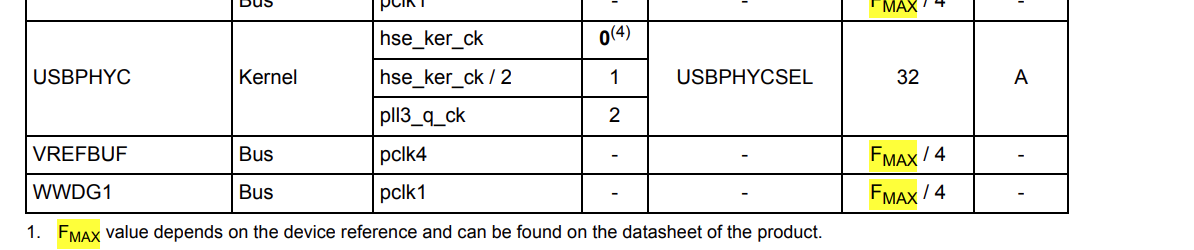
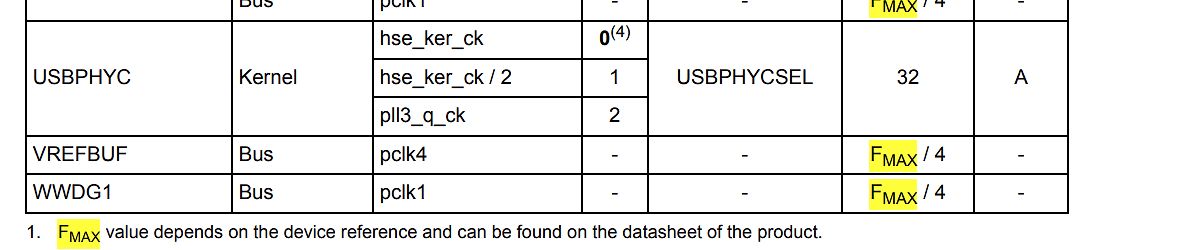
USBPHYC Kernel hse_ker_ck 0(4) USBPHYCSEL 32 A
hse_ker_ck / 2 1
pll3_q_ck 2
VREFBUF Bus pclk4 FMAX / 4
WWDG1 Bus pclk1 FMAX / 4
1. FMAX value depends on the device reference and can be found on the datasheet of the product.
in
„STM32H7Sx: Maximale Frequenz?“
·
Mikrocontroller und Digitale Elektronik
·
05.09.2025 11:29
·
Screenshots
Bild
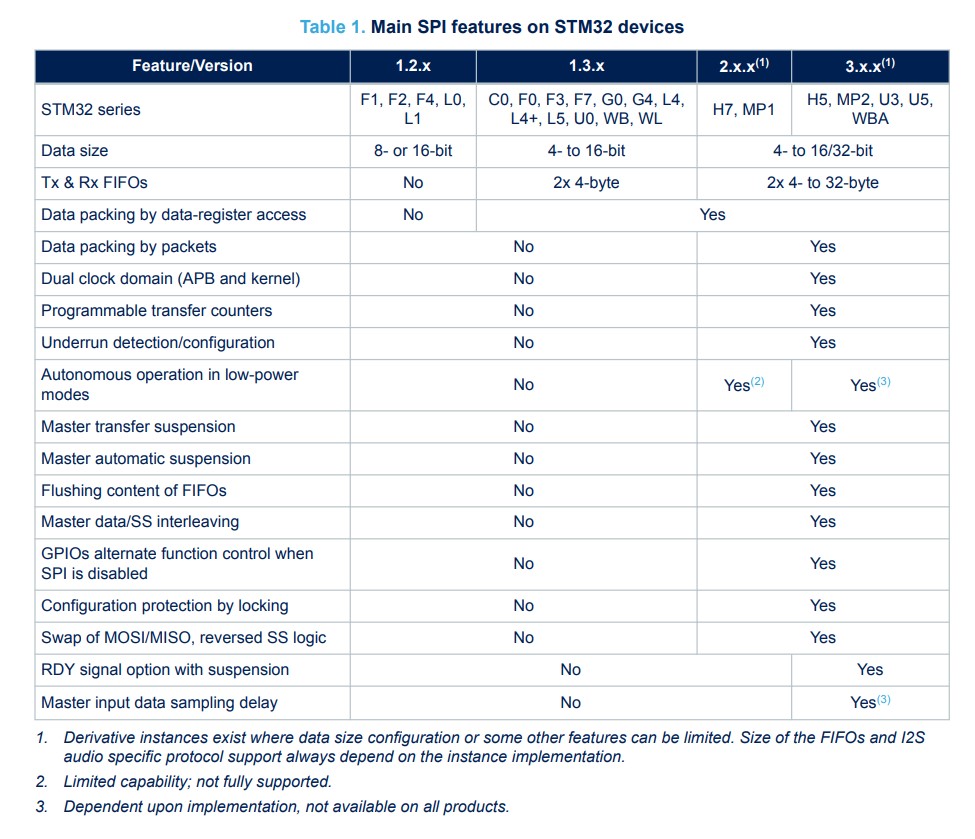
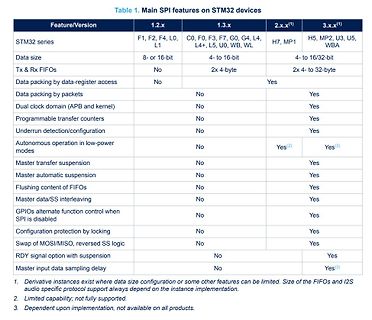
Table 1. Main SPI features on STM 32 devices
Feature/Version
1.2.x
1.3.x
2.x(1)
3.x(1)
STM 32 series
F1, F2, F4, L0, L1
C0, F0, F3, F7, G0, G4, L4+, L5, U0, WB, WL
H7, MP1
H5, MP2, U3, U5, WBA
Data size
8- or 16-bit
4- to 16-bit
4- to
in
„Multichannel DAC mit SPi-DMA beschreiben“
·
Mikrocontroller und Digitale Elektronik
·
10.08.2025 13:07
·
Screenshots
Bild
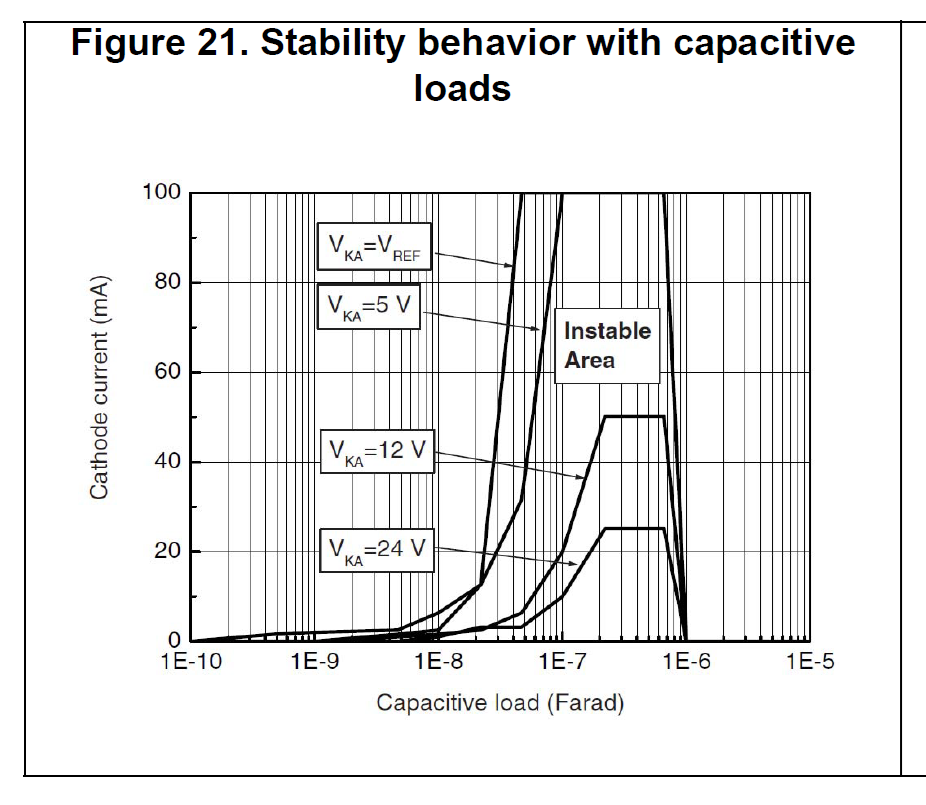
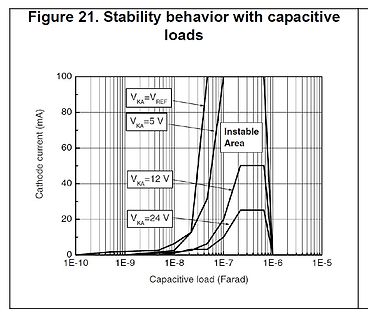
Figure 21. Stability behavior with capacitive loads
100
80
60
40
20
0
Cathode current (mA)
1E-10
1E-9
1E-8
1E-7
1E-6
1E-5
Capacitive load (Farad)
VA=VREF
VKA=5 V
Instable Area
VKA=12 V
VKA=24 V
in
„Transistor als Z-Dioden Ersatz“
·
Analoge Elektronik und Schaltungstechnik
·
20.08.2025 22:59
·
Screenshots
/* Common part of the linker scripts for STR71x devices in FLASH mode (that is, the FLASH is seen at 0) Copyright RAISONANCE 2005 You can use, modify and distribute thisfile freely, but without any waranty. */ /* Sections Definitions */ SECTIONS { /* for Cortex devices, the beginning of the startup code is stored in the .isr_vector section, which goes to FLASH */ .isr_vector : { . = ALIGN(4); KEEP(*(.isr_vector)) /* Startup code */ . = ALIGN(4); } >FLASH /* for some STRx devices, the beginning of the startup code is stored in the .flashtext section, which goes to FLASH */ .flashtext : { . = ALIGN
in
„J-Link EDU + Eclipse + STM32-H103 Board debugging problem“
·
Mikrocontroller und Digitale Elektronik
·
04.02.2011 14:57
#include "irmp.h" #include "stdlib.h" #include <stdio.h> #define F_CPU 24000000 #ifndef F_CPU #error F_CPU unkown #endif void timer2ini(void); void TIM2_IRQHandler(void){ TIM_ClearITPendingBit(TIM2, TIM_IT_Update); irmp_ISR(); // call irmp ISR } int main(void) { timer2ini(); SystemInit(); irmp_init(); // initialize irmp IRMP_DATA irmp_data; while(1){ if(irmp_get_data (&irmp_data)){ //.... } } } void timer2ini(void){ TIM_TimeBaseInitTypeDef TIM_TimeBase_InitStructure; NVIC_InitTypeDef NVIC_InitStructure; RCC_APB1PeriphClockCmd(RCC_APB1Periph_TIM2, ENABLE); //Set Timer TIM2 TIM_TimeBase_InitStructure.TIM_ClockDivision
in
„IRMP - Infrared Multi Protocol Decoder“
·
Projekte & Code
·
27.02.2013 13:14
OUTPUT_FORMAT ("elf32-littlearm", "elf32-bigarm", "elf32-littlearm") /* Internal Memory Map*/ MEMORY { rom (rx) : ORIGIN = 0x08000000, LENGTH = 0x00100000 ram (rwx) : ORIGIN = 0x20000000, LENGTH = 0x00020000 ccm (rwx) : ORIGIN = 0x10000000, LENGTH = 0x00010000 } _eram = 0x20000000 + 0x00020000; SECTIONS { .text : { KEEP(*(.isr_vector)) *(.text*) *(.rodata*) } > rom __etext = .; /* _sidata is used in coide startup code */ _sidata = __etext; .data : AT (__etext) { __data_start__ = .; /* _sdata is used in coide startup code */ _sdata = __data_start__; *(vtable) *(.data*) . = ALIGN(4); /* All data end
in
„GCC STM32F4 -> Wie Variablen auf RAM bereiche verteilen“
·
Mikrocontroller und Digitale Elektronik
·
21.02.2015 00:47
ENTRY(_reset) MEMORY { /* memory map of STM 32F100 */ Flash (rx): ORIGIN = 0x08000000, LENGTH = 256K SRAM0 (rwx): ORIGIN = 0x20000000, LENGTH = 64K } _stack_end = ORIGIN(SRAM0) + LENGTH(SRAM0); SECTIONS { .text : { _text_section_start = .; KEEP
in
„uint64_t auf STM32F103“
·
Mikrocontroller und Digitale Elektronik
·
19.12.2019 10:54
//-------------------------------------------------------------- // File : stm 32_ub_uart.c // Datum : 28.07.2015 // Version : 1.5 // Autor : UB // EMail : mc-4u(@)t-online.de // Web : www.mikrocontroller-4u.de // CPU : STM 32F4 // IDE : CooCox CoIDE 1.7.8 // GCC : 4.9 2015q2 //
in
„STM32F4 USART“
·
Mikrocontroller und Digitale Elektronik
·
22.12.2019 19:02
HCF4093B QUAD 2 INPUT NAND SCHMITT TRIGGER ■ SCHMITT TRIGGER ACTION ON EACH INPUT WITH NO EXTERNAL COMPONENTS ■ HYSTERESIS VOLTAGE TYPICALLY 0.9V at V = 5V AND 2.3V at V = 10V DD DD ■ NOISE IMMUNITY GREATER THAN 50%OF VDD (Typ.) ■ NO LIMIT ON INPUT RISE AND FALL TIMES DIP SOP ■ QUIESCENT CURRENT SPECIFIED UP TO 20V ■ STANDARDIZED SYMMETRICAL OUTPUT ORDER CODES CHARACTERISTICS PACKAGE TUBE T & R ■ 5V, 10V AND 15V PARAMETRIC RATINGS ■ INPUT LEAKAGE CURRENT DIP HCF4093BEY I = 100nA (MAX) AT V = 18V T = 25°C SOP HCF4093BM1 HCF4093M013TR I DD A ■ 100% TESTED FOR QUIESCENT CURRENT ■ MEETS ALL REQUIREMENTS
in
„Frequenz Spannungswandler“
·
Analoge Elektronik und Schaltungstechnik
·
27.10.2010 16:14
typedef enum {CAN_50KBPS, CAN_100KBPS, CAN_125KBPS, CAN_250KBPS, CAN_500KBPS, CAN_1000KBPS} BITRATE; #pragma once typedef enum {STANDARD_FORMAT = 0, EXTENDED_FORMAT} CAN_FORMAT; typedef enum {DATA_FRAME = 0, REMOTE_FRAME} CAN_FRAME; typedef struct { uint32_t id; /* 29 bit identifier */ uint8_t data[8]; /* Data field */ uint8_t len; /* Length of data field in bytes */ uint8_t ch; /* Object channel(Not use) */ uint8_t format; /* 0 - STANDARD, 1- EXTENDED IDENTIFIER */ uint8_t type; /* 0 - DATA FRAME, 1 - REMOTE FRAME */ } CAN_msg_t; bool CANInit(BITRATE bitrate, int remap); void CANReceive(CAN_msg_t
in
„Arduino Blue Pill CAN bibliothek“
·
Mikrocontroller und Digitale Elektronik
·
09.01.2025 08:58
// Programm zur initialisierung der SPI-Schnittstelle + Schreibvorgang #include "stm 32_spi_eigen.h" GPIO_InitTypeDef GPIO_InitStructure; SPI_InitTypeDef SPI_InitStructure; void initNSS() { //RCC_AHBPeriphClockCmd(RCC_AHBPeriph_GPIOA,ENABLE); GPIO_InitStructure.GPIO_Pin = GPIO_Pin_6;
in
„AD9833 mittels STM32F072 per SPI ansteuern“
·
Mikrocontroller und Digitale Elektronik
·
18.05.2015 17:10
/* Includes ------------------------------------------------------------------*/ #include "stm 32f10x.h" #include "rfm12B.h" #include "systick.h" #include <stdint.h> #include <stdio.h> #include "Param.h" /* Private variables ---------------------------------------------------------*/ /* Private
in
„ST32F103 ---> AVR RFM12B“
·
Mikrocontroller und Digitale Elektronik
·
01.12.2015 12:10
RFM12_H_ /* Includes ------------------------------------------------------------------*/ #include "stm 32f10x.h" extern unsigned char rxbuf[]; // Puffer für empfangene Daten extern unsigned char txbuf[]; // Puffer für zu sendende Daten /* Private typedef -----------------------------------------------
in
„ST32F103 ---> AVR RFM12B“
·
Mikrocontroller und Digitale Elektronik
·
01.12.2015 12:10
/** ****************************************************************************** * @file stm 8s_spi.c * @author MCD Application Team * @version V2.2.0 * @date 30-September-2014 * @brief This file contains all the functions for the SPI peripheral. *********************************************
in
„STM8 Standard Peripheral Library mit ST Visual Develop benutzen - Linker error“
·
Mikrocontroller und Digitale Elektronik
·
14.05.2016 16:22
#include <stdlib.h> #include <stdint.h> #include "stm 32f4_regs.h" #include "usart.h" #include "gpio.h" #define CONFIG_HSE_HZ 16000000 #define CONFIG_PLL_M 16 #define CONFIG_PLL_N 336 #define CONFIG_PLL_P 2 #define CONFIG_PLL_Q 7 #define PLLCLK_HZ (((CONFIG_HSE_HZ
in
„Linux auf dem STM32 externes RAM“
·
Mikrocontroller und Digitale Elektronik
·
07.01.2019 16:56
//-------------------------------------------------------------- // File : stm 32_ub_uart.c // Datum : 28.11.2013 // Version : 1.3 // Autor : UB // EMail : mc-4u(@)t-online.de // Web : www.mikrocontroller-4u.de // CPU : STM 32F4 // IDE : CooCox CoIDE 1.7.0 // Module : GPIO, USART
in
„STM32F030F4P6 und USART1“
·
Mikrocontroller und Digitale Elektronik
·
28.07.2016 19:02
typedef enum {CAN_50KBPS, CAN_100KBPS, CAN_125KBPS, CAN_125KBPS32MHZ, CAN_125P1KBPS31P9MHZ,CAN_250KBPS, CAN_500KBPS, CAN_1000KBPS} BITRATE; typedef enum {STANDARD_FORMAT = 0, EXTENDED_FORMAT} CAN_FORMAT; typedef enum {DATA_FRAME = 0, REMOTE_FRAME} CAN_FRAME; typedef struct { uint32_t id; /* 29 bit identifier */ uint8_t data[8]; /* Data field */ uint8_t len; /* Length of data field in bytes */ uint8_t ch; /* Object channel(Not use) */ uint8_t format; /* 0 - STANDARD, 1- EXTENDED IDENTIFIER */ uint8_t type; /* 0 - DATA FRAME, 1 - REMOTE FRAME */ } CAN_msg_t; bool CANInit(BITRATE bitrate, int remap); void
in
„Arduino Blue Pill & CAN mit SN65HVD230“
·
Mikrocontroller und Digitale Elektronik
·
07.03.2023 12:48
#pragma once typedef enum {CAN_50KBPS, CAN_100KBPS, CAN_125KBPS, CAN_250KBPS, CAN_500KBPS, CAN_1000KBPS} BITRATE; typedef enum {STANDARD_FORMAT = 0, EXTENDED_FORMAT} CAN_FORMAT; typedef enum {DATA_FRAME = 0, REMOTE_FRAME} CAN_FRAME; typedef struct { uint32_t id; /* 29 bit identifier */ uint8_t data[8]; /* Data field */ uint8_t len; /* Length of data field in bytes */ uint8_t ch; /* Object channel(Not use) */ uint8_t format; /* 0 - STANDARD, 1- EXTENDED IDENTIFIER */ uint8_t type; /* 0 - DATA FRAME, 1 - REMOTE FRAME */ } CAN_msg_t; bool CANInit(BITRATE bitrate, int remap); void CANReceive(CAN_msg_t
in
„Arduino Blue Pill & CAN mit SN65HVD230“
·
Mikrocontroller und Digitale Elektronik
·
07.03.2023 14:46
typedef enum {CAN_50KBPS, CAN_100KBPS, CAN_125KBPS, CAN_250KBPS, CAN_500KBPS, CAN_1000KBPS} BITRATE; #pragma once typedef enum {STANDARD_FORMAT = 0, EXTENDED_FORMAT} CAN_FORMAT; typedef enum {DATA_FRAME = 0, REMOTE_FRAME} CAN_FRAME; typedef struct { uint32_t id; /* 29 bit identifier */ uint8_t data[8]; /* Data field */ uint8_t len; /* Length of data field in bytes */ uint8_t ch; /* Object channel(Not use) */ uint8_t format; /* 0 - STANDARD, 1- EXTENDED IDENTIFIER */ uint8_t type; /* 0 - DATA FRAME, 1 - REMOTE FRAME */ } CAN_msg_t; bool CANInit(BITRATE bitrate, int remap); void CANReceive(CAN_msg_t
in
„Arduino Blue Pill & CAN mit SN65HVD230“
·
Mikrocontroller und Digitale Elektronik
·
06.05.2023 13:28
typedef enum {CAN_50KBPS, CAN_100KBPS, CAN_125KBPS, CAN_125KBPS32MHZ, CAN_125P1KBPS31P9MHZ,CAN_250KBPS, CAN_500KBPS, CAN_1000KBPS} BITRATE; typedef enum {STANDARD_FORMAT = 0, EXTENDED_FORMAT} CAN_FORMAT; typedef enum {DATA_FRAME = 0, REMOTE_FRAME} CAN_FRAME; typedef struct { uint32_t id; /* 29 bit identifier */ uint8_t data[8]; /* Data field */ uint8_t len; /* Length of data field in bytes */ uint8_t ch; /* Object channel(Not use) */ uint8_t format; /* 0 - STANDARD, 1- EXTENDED IDENTIFIER */ uint8_t type; /* 0 - DATA FRAME, 1 - REMOTE FRAME */ } CAN_msg_t; bool CANInit(BITRATE bitrate, int remap); void
in
„Arduino Blue Pill & CAN mit SN65HVD230“
·
Mikrocontroller und Digitale Elektronik
·
22.02.2023 10:36
on the left side: GND, SDA, SCL, VCC (U = 3,3V). For I2C and USB communication we use a Black Pill (STM 32F103C8T6) We only write and read the seven yellow timekeeper registers 0x00 up to 0x06. “When you power up the module the clock halt (CH) bit in the seconds register will be set to a 1.” That means
in
„I2C STM32F103“
·
Mikrocontroller und Digitale Elektronik
·
27.01.2019 11:57
PB12/SPI2_NSS/I2S2_WS/I2C2_SMBA/USART3_CK/TIM1_BKIN 51 PB12 1 C27 1 C28 0.1uF U3 22P 22P PL2303HX STM 32F10xVxT6 PA4 1 8 3V3 2 2 PA6 2 CS VCC 7 3V3 GND 3V3 3 Q HOLD 6 PA5 所有 IO均已引出 4 W C 5 PA7 1 2 1 2 4 1 9 1 2 3 D IO GND D USB 接口 V E A C E E E B B D C B B D C A A A V N GND M25Pxx 3 P P P P P P P P P
in
„Verkaufe 4 ältere Evalboards“
·
Markt
·
18.03.2024 12:18
M54HC164 M74HC164 8 BIT SIPO SHIFT REGISTER . HIGH SPEED PD = 15 ns(TYP.) AT VCC= 5 V . LOWPOWER DISSIPATION CC = 4 A(MAX.) AT T A 25 ⋅C . OUTPUT DRIVE CAPABILITY 10 LSTTL LOADS . BALANCEDPROPAGATION DELAYS B1R F1R PLH = PHL (Plastic Package) (CeramicPackage) . SYMMETRICAL OUTPUT IMPEDANCE OL = IOH = 4 mA(MIN.) . VIGH= VISE= 28 % VY (MIN.) . WIDE OPERATING VOLTAGE RANGE M1R C1R VCC (OPR) = 2 V TO6 V (MicroPackage) (Chip Carrier) . PIN ANDFUNCTION COMPATIBLE WITH 54/74LS164 M54HC164F1RDER CODM74HC164M1R M74HC164B1R M74HC164C1R PIN CONNECTIONS(top view) DESCRIPTION The M54/74HC164 is a high speed
in
„11110000 im Schieberegister rotieren lassen“
·
Mikrocontroller und Digitale Elektronik
·
07.03.2020 16:12
**** */ /* Includes ------------------------------------------------------------------*/ #include "stm 32f7xx_hal.h" /** @addtogroup STM 32F7xx_HAL_Driver * @{ */ #if defined(STM 32F756xx) || defined(STM 32F746xx) /** @defgroup LTDC LTDC * @brief LTDC HAL module driver * @{ */ #ifdef HAL_LTDC_MODULE_ENABLED
in
„STM32F7 Disco und das Display-->hard fault error“
·
Mikrocontroller und Digitale Elektronik
·
26.09.2015 22:47
Getting started with the STEVAL-SPIN3202 evaluation board, advanced BLDC controller with embedded STM 32 MCU Introduction The STEVAL-SPIN3202 3-phase brushless DC motor driver board is based on the STSPIN32F0A 3- phase controller with integrated STM 32 MCU. It implements a single shunt resistor current
in
„Problem mit ST-Board zur BLDC-Ansteuerung“
·
Mikrocontroller und Digitale Elektronik
·
14.10.2019 16:40
Bild
Bild
ST STM 32U3 STM 32 Best-in-class ultra-low-power MCUs increase energy efficiency and security
in
„STM32U3 / STM32WBA6 vorgestellt, neue Raspberry Pi Compute Modules und Steuerrechtliches“
·
Mikrocontroller und Digitale Elektronik
·
04.03.2025 17:59
·
Sonstiges
Bild
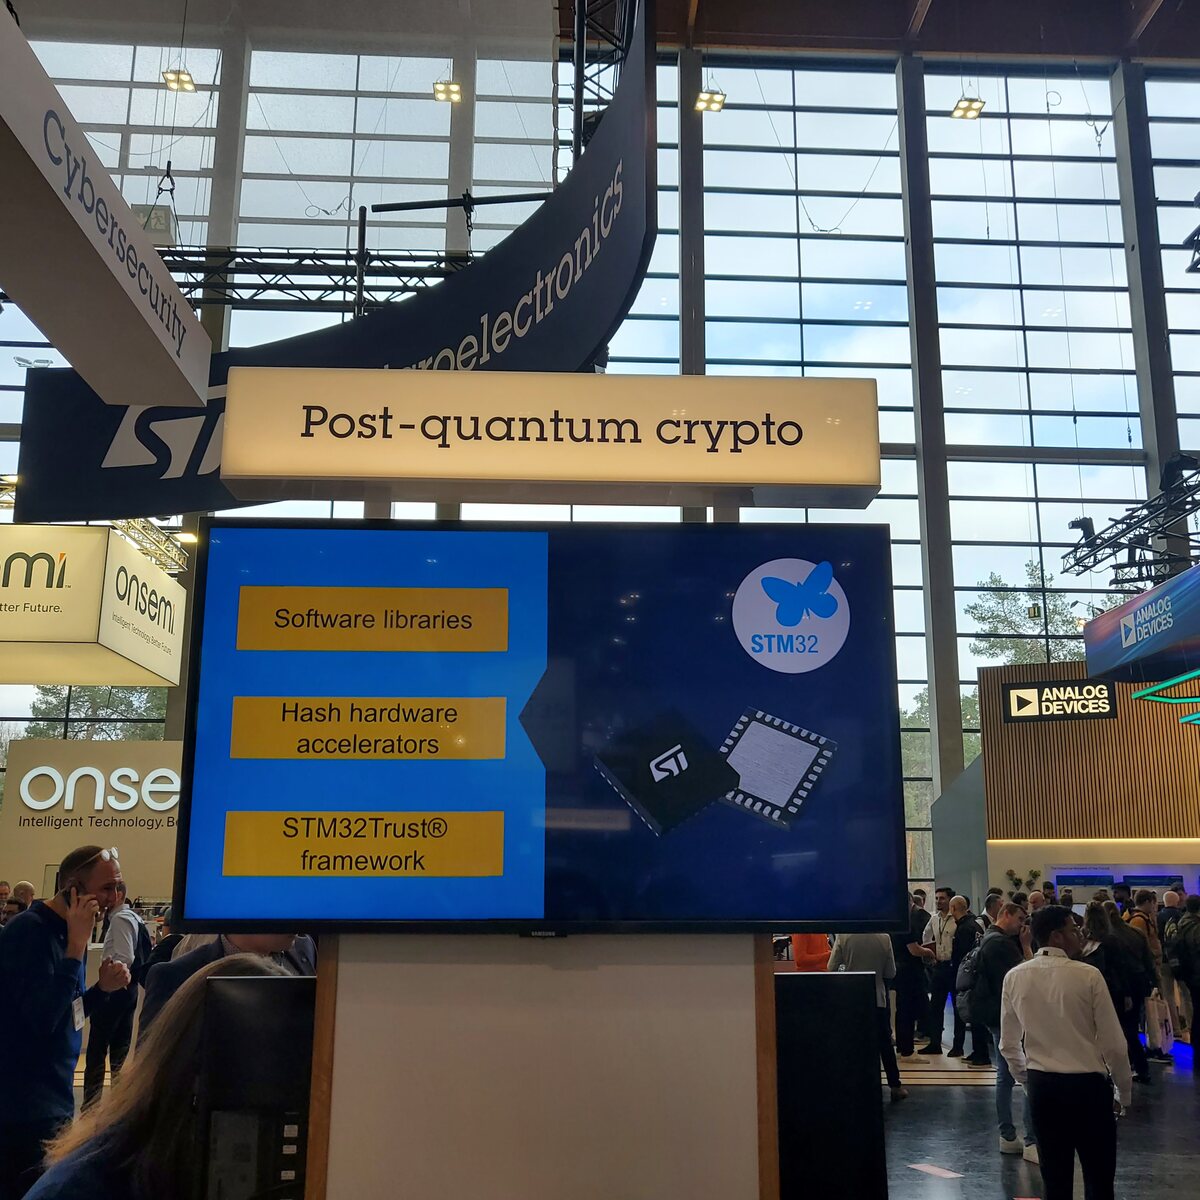
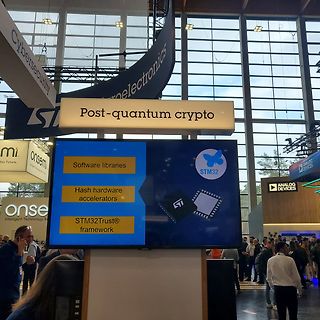
Cybersecurity electronics Post-quantum crypto Software libraries Hash hardware accelerators STM 32Trust framework STM 32 onsemi ANALOG DEVICES
in
„EmbeddedWorld 2025, Tag 1 – im Namen des Mikrocontrollers“
·
Mikrocontroller und Digitale Elektronik
·
11.03.2025 23:35
·
Fotos
Bild
STMicroelectronics
STM 32G0B1 Memory expansion board for STM 32 Nucleo
X-NUCLEO-PGEEZ1
Evaluation Boards
in
„EmbeddedWorld 2026, Tag 1 – AI fressen Elektronik auf“
·
Mikrocontroller und Digitale Elektronik
·
10.03.2026 23:21
·
Fotos
Bild
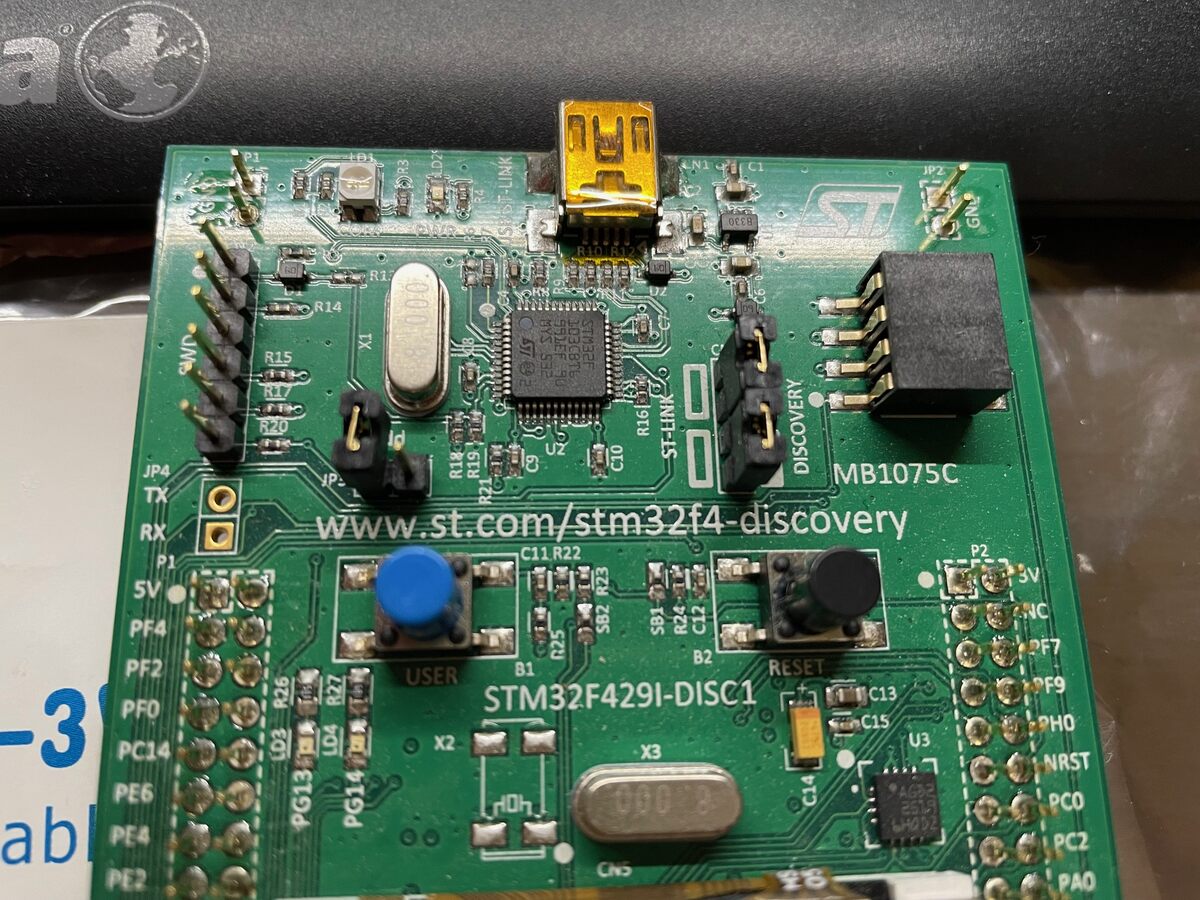
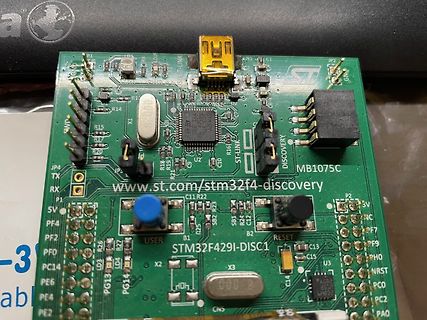
ST MB1075C www.st.com/stm 32f4-discovery STM 32F429I-DISC1 USER RESET
in
„[V] STM32F4 Discovery Board“
·
Markt
·
04.03.2025 13:20
·
Platinenfotos
Bild
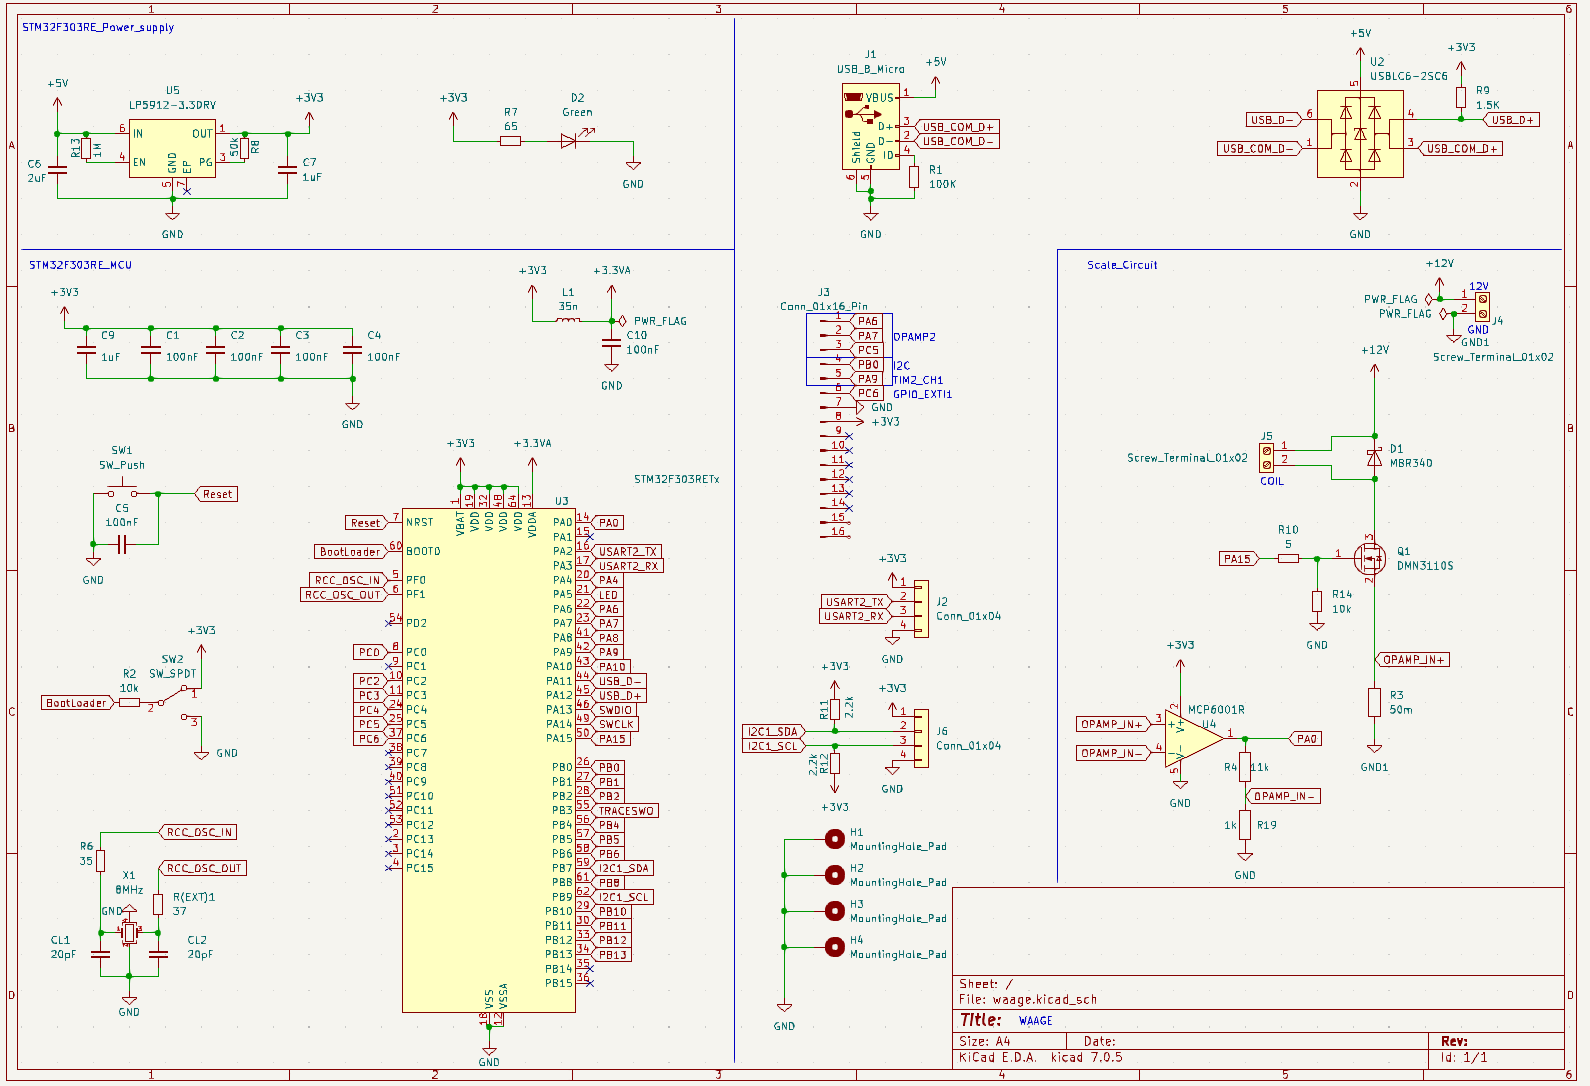
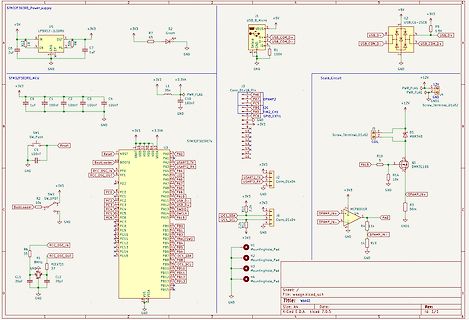
STM 32F030RE_Power_supply, LP5912-3.50RV, USB_Micro, STM 32F030RE, Scale_Circuit, HCP600IR, WAAGE
in
„Bootloader Mode STM32F303“
·
Mikrocontroller und Digitale Elektronik
·
13.07.2023 23:14
·
Schaltpläne
Bild
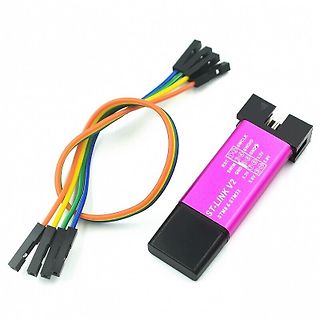
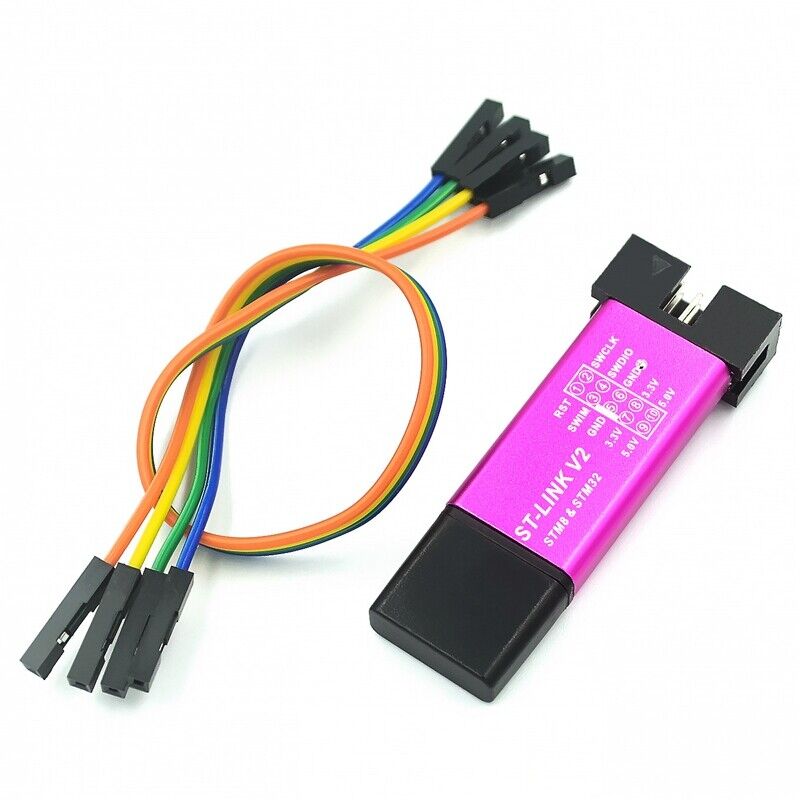
ST-LINK V2
STM 8 & STM 32
RST
SWCLK
SWDIO
GND
3.3V
SWIM
GND
3.3V
5V
5V
in
„NRF51 firmware flash mit ST-Link und openocd“
·
Mikrocontroller und Digitale Elektronik
·
14.08.2023 16:05
·
Fotos

 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild
 Bild