-
PDF
at90can-v1.1.pdf
6 1 2 3 4 5 6 A V A + 9 11 1 X XTAL1 MODE 7 2 CLK_OUT 3 H 10 6 XTAL2 13 1 TX0 CAN1TX GND EXTIF AD7 2 AD7 AD6 1 AD6 RX0 19 CAN1RX AD5 28 AD5 AD4 27 AD4 AD3 26 AD3 B AD2 25 AD2 TX1 14 B AD1 24 AD1 AD0 23 AD0
-
PDF
CAN_monitor_with_MAX32.pdf
od2.attachInterrupt(doCan2Interrupt); Serial.begin(9600); } voidloop(){ txCAN2(CAN_1_ID); delay(100); //waitsothatthecharacterhastimetobedelivered rxCAN1(); txCAN1(CAN_2_ID); delay(100); rxCAN2(); } voidinitCan1
in „Microchip springt auf den Arduino Zug auf“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
; sei(); id=1; canTX.id=0x07; canTX.RXstatus.rtr=0x00; canTX.length=4; canTX.data[0]=1; canTX.data[1]=1; canTX.data[2]=0; canTX.data[3]=0x0A; canTX.data[4]=0x0B; canTX.data[5]=0x0C; canTX.data[6]=4; canTX.data[7]=0; canTX.data[8]=0; global.ioBits.fehler=0; rampe1.eingang=&color1.green; rampe2.eingang=&color1.red; rampe3.eingang=&color1.blue; while(1){ else if(can_on){ PORTB|=(1<<PB0); } } } ISR(INT0_vect) { canError.buffer=CANReadReg(EFLG); if(canError.buffer){ if(canError.bits.rx0ovr) CANBitModify
in „Atmega und CAN“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
interrupt priority @param rxc_interrupt_level The level of the RCX (Recive) interrupt priority @param tx_buffer_size The Size of the tx buffer @param rx_buffer_size The Size of the rx buffer @param baud_a The baudratevalue a register @param baud_b The baudratevalue a register @param *port The adress of
in „XMEGA UART Library“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
TX-H2560SW21C-2770V36-03H95_WKF-DB0002.pdf
Color: Applications: ◆ GaInN ◆ White ◆ Commercial lighting ◆ Warm white ◆ General Lighting Part No. TX-H2560SW21C-2770V36-03H95 Spec No. WKF-DB0002 Page 1 of 10 www.txled.cn Version:2.0 Package Dimensions: R2 Ф21 5 . 2 1.1 0.8 2424SW1208A-60B 1 1.1 23.85 1.6±0.1 I: Warm white ; II: White Notes: 1.All
in „Implementierung einer CCT LED mit ELG-100-36-3Y Netzteil und PWM-Dimmung über Arduino“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
test.c
cli") --rx_counter1; #asm("sei") return data; } #pragma used- // USART1 Transmitter buffer #define TX_BUFFER_SIZE1 8 char tx_buffer1[TX_BUFFER_SIZE1]; #if TX_BUFFER_SIZE1<256 unsigned char tx_wr_index1,tx_rd_index1,tx_counter1; #else unsigned int tx_wr_index1,tx_rd_index1,tx_counter1; #endif // USART1
in „von Codesammlung Verlagert: ATMega128 Uart Problem“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
UART0.C
bauddivider ) { UBRR0H = bauddivider >> 8; UBRR0L = bauddivider; // set baud rate UCSR0A = 0; // no U2X, MPCM UCSR0C = 1<<UCSZ01^1<<UCSZ00 // 8 Bit #ifdef URSEL0 ^1<<URSEL0 // if UCSR0C shared with UBRR0H #endif ; UCSR0B = 1<<RXEN0^1<<TXEN0^ // enable RX, TX 1<<RXCIE0; // enable RX interrupt rx_inp =
-
Datei
liesmich.txt.txt
2 (2a + 3a waren bei mir mit Jumper gebrückt=normaler Bildinhalt zum Videomixer) 3 (1a + 3a = invertierter Bildschirminhalt?) 4 b = BAS Ausgang 1,5V .. --- 2x5 pol Steckerleiste (unten rechts - wenn VG-Leiste links ist): a-b 11 a+b = Masse 12 a b = a=Tx TTL; b=Rx TTL 13 a b = a=Tx V24; b=Rx V24 14 a b = a=Tx-20mA;b=Tx+20mA 15 a b = a=Rx-20mA;b=Rx+20mA --- Im Schaltplan ist ein AY 3-1015 Uart. Eingesetzt war bei mir ein wohl
in „[V] Alte Video-Interface-Karten 64 * 16 BAS zu verschenken“ · Markt ·
-
Datei
FileTransfer.c
{0x0A, 0x03, '1', 0, '2', 0, '3', 0, '4', 0}; __xdata BYTE USB_ProductStr[] = {0x10, 0x03, 'U', 0, 'S', 0, 'B', 0, ' ', 0, 'A', 0, 'P', 0, 'I', 0}; __xdata BYTE USB_MfrStr[] = {0x1A, 0x03, 'S', 0, 'i', 0, 'l', 0, 'i', 0, 'c
in „Puffer-Problem mit C8051F320 (8051)“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
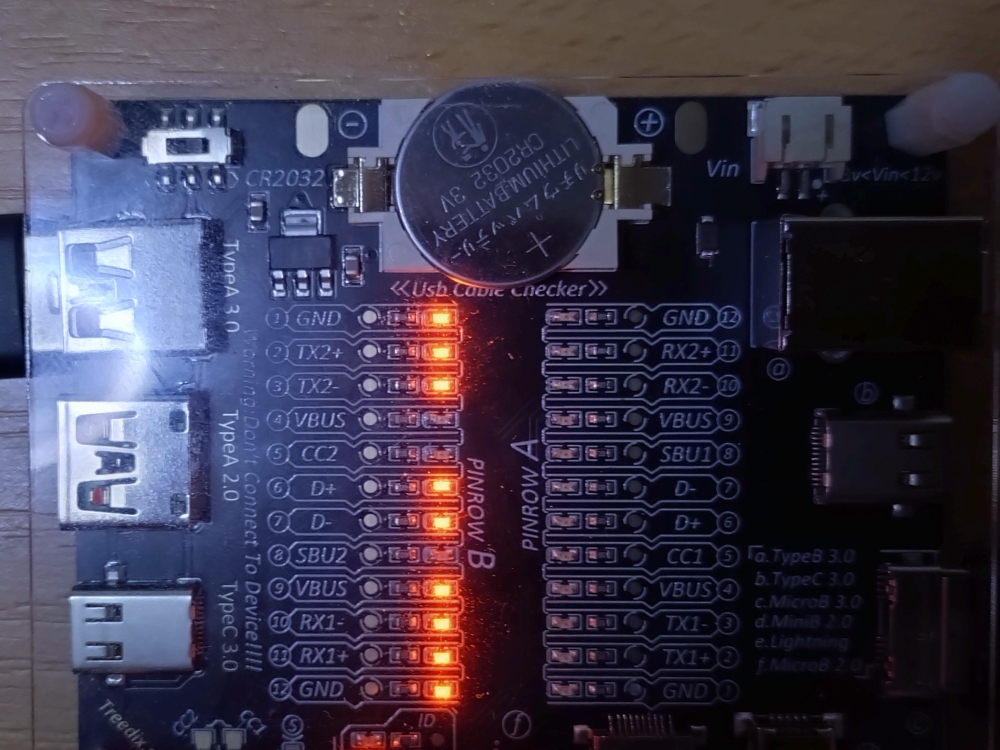
USB-C Kabel Checker Platine mit LEDs
CR2032, LITHIUM BATTERY, Vin, <<USB Cable Checker>>, GND, TX2+, TX2-, VBUS, CC2, D+, D-, SBU2, VBUS, RX1-, RX1+, GND, PINROW B, PINROW A, GND, RX2-, RX2+, VBUS, SBU1, D-, D+, CC1, TX1-, TX1+, GND, Type A 3.0, Type A 2.0, Type C 3.0, Type C 3.0, a. Type B 3.0, b. Type C 3.0, c. MicroB 3.0, d. MiniB 2.0, e. Lightning, f. MicroB 2.0
in „USB-C Kabel D+/D- nur einseitig belegt“ · Mikrocontroller und Digitale Elektronik · · Platinenfotos
-
Datei
Datenspeicherkorrigiert_d_int.c
Karte } } // einen Sektor lesen und ausgeben, per Interrupt void lesen_Karte(void) { unsigned int z,b; MB32_zuruecklesenSektor(); // 1 Sektor(512 Bytes) wird gelesen IE2 |= UTXIE1; // Enable USART1 TX interrupt P2OUT |= BIT3; // LED ROT AUS AD1_32L=AD1_32L+1; // nächster Sektor anz_sectors--; if (anz_sectors
in „MSP430 Interrupt verschachteln“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ch9121_doc2.pdf
, high level to exit configuration Operating status indicating RUN pin UART 1 RS485 RX/TX DIR1 switch (connects to external RS485 controller) UART 2 RS485 RX/TX DIR2 switch (connects to external RS485 controller) CH9121 CH9121 is the chip for network serial port transparent transmission,
in „Serieller Tunnel durch IP-Netz?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
iirBench2.c
const int bufferSize = 150; float x[150]; float y[150]; void filt() { // Filter first 9 samples y[0] = b0*x[0]; y[1] = b0*x[1] + b1*x[0] - a1*y[0]; y[2] = b0*x[2] + b1*x[1] + b2*x[0] - a1*y[1] - a2*y[0]; y[3] = b0*x[3] + b1*x[2] + b2*x[1] + b3*x[0] - a1*y[2] - a2*y[1] - a3*y[0]; for (int i = 4; i < bufferSize; i++) { y[i] = b0*x[i] + b1*x[i-1] + b2*x[i-2] + b3*x[i-3] + b4*x[i-4] - a1*y[i-1] - a2*y[i-2] - a3*y[i-3] - a4*y[i-4]; } for (int i = 0; i < bufferSize; i++) { x[i] = y[i]; } } void setup() { //softwareSerialBegin(9600
in „Wofür Propeller von Parallax ?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
BUE2014d01_Feuchtesensor.c
/Modbus init (incl. UART config) modbus_init(); //I2C Config USI_TWI_Master_Initialise(); //LED blinking TCCR0B |= 0b101; //Enable Timer0 with f_clk/1024 prescaler //Enable Interrupts sei(); PORTB |= (1<<PORTB0); //Enter infinite loop for(;;){ //45 ms
in „Attiny 2313A - ROM am Limit? Probleme mit Optimierer“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
USART.c
wird per Interrupt behandelt // // Hinweis : mögliche Pinbelegungen // UART1 : TX:[PA9,PB6] RX:[PA10,PB7] // UART2 : TX:[PA2,PD5] RX:[PA3,PD6] // UART3 : TX:[PB10,PC10,PD8] RX:[PB11,PC11,PD9] // UART4 : TX:[PA0,PC10] RX:[PA1,PC11] // UART5 : TX:[PC12] RX:[PD2] // UART6 : TX:[PC6,PG14
in „STM32F0 Discovery und UART1“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
nRF24L01.h
define SETUP_RETR 0x04 #define RF_CH 0x05 #define RF_SETUP 0x06 #define STATUS 0x07 #define OBSERVE_TX 0x08 #define CD 0x09 #define RX_ADDR_P0 0x0A #define RX_ADDR_P1 0x0B #define RX_ADDR_P2 0x0C #define RX_ADDR_P3 0x0D #define RX_ADDR_P4 0x0E #define RX_ADDR_P5 0x0F #define TX_ADDR 0x10 #define RX_PW_P0
in „Problem Linken von nRF24 Multi Network mit AVR Studio“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
STM32_F4VE_SCHEMATIC.PDF
PIU2036 PB1B LCD_BL R8R8 R5R RAM : 196K FLASH : 512K PA2A PIU2025PA2/ADC123_IN2/USART2_TX/TIM2_CH3/TIM5_CH3 BOOT1/PB2 PIU2037 PB2/BOOT1T PIR802PIR801 510R PA3A PIU2026PA3/ADC123_IN3/USART2_RX/TIM2_CH4/TIM5_CH4 (TIM2
in „Neues Entwicklungsboard STM32F407“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
STM32_F4VE_SCHEMATIC.PDF
PIU2036 PB1B LCD_BL R8R8 R5R RAM : 196K FLASH : 512K PA2A PIU2025PA2/ADC123_IN2/USART2_TX/TIM2_CH3/TIM5_CH3 BOOT1/PB2 PIU2037 PB2/BOOT1T PIR802PIR801 510R PA3A PIU2026PA3/ADC123_IN3/USART2_RX/TIM2_CH4/TIM5_CH4 (TIM2
in „STM32F407 Black und Arduino“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ESP32Radio.pdf
GND GND B R , DAC BCLK St-By 6 11 11 4 PWR off/on 12 BOOT 12 VCC GND 3 GND Tx2 IO02 GND +5V J9 13 13 Tx2 2 is PWR on Rx2 1 COM Rx2 U2 C63 C64 +5V AMS1117-3.3 +3.3V 100n þÿ2200µ 50V 3 VI VO 2 2 +3.3V +5V AMP1 C2
in „TDA7439DS Störgeräusche und ein kochender TDA7377“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
DELL_VOSTRO_3300__WIstron_Winery13_MB_DIS_.pdf
F24 DMI_TX0 L PEG_RX#12 B28 PCIE_MRX_GTX_N2 [22] DMI_CTX_PRXP1 E23 DMI_TX1 C PEG_RX#13 B30 PCIE_MRX_GTX_N1 [22] DMI_CTX_PRXP3 G23 DMI_TX2 PEG_RX#14 A31 PCIE_MRX_GTX_N0 DMI_TX3 PEG_RX#15 PCIE_MRX_GTX_P[0..15] J35
in „Bios programmieren mit Dual Bios Main.Bin und EC.Bin ?“ · Softwareentwicklung ·
-
Datei
enc28j60.h
0x09|0x20) // #define EPMM2 (0x0A|0x20) // #define EPMM3 (0x0B|0x20) // #define EPMM4 (0x0C|0x20) // #define EPMM5 (0x0D|0x20) // #define EPMM6 (0x0E|0x20) // #define EPMM7 (0x0F|0x20) // #define EPMCSL (0x10|0x20) // #define EPMCSH
in „Atmega1280 Webserver stürzt ab“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
iirBenchmark.ino
bufferSize = 150; float x[bufferSize]; float y[bufferSize]; void filt() { // Filter first 9 samples y[0] = b[0]*x[0]; y[1] = b[0]*x[1] + b[1]*x[0] - a[1]*y[0]; y[2] = b[0]*x[2] + b[1]*x[1] + b[2]*x[0] - a[1]*y[1] - a[2]*y[0]; y[3] = b[0]*x[3] + b[1]*x[2] + b[2]*x[1] + b[3]*x[0] - a[1]*y[2] - a[2]*y[1] - a[3]*y[0]; for (int i = 4; i < bufferSize; i++) { y[i] = b[0]*x[i] + b[1]*x[i-1] + b[2]*x[i-2] + b[3]*x[i-3] + b[4]*x[i-4] - a[1]*y[i-1] - a[2]*y[i-2] - a[3]*y[i-3] - a[4]*y[i-4]; } for (int i = 0; i < bufferSize; i++) { x[i] = y[i]; } } void setup() { softwareSerialBegin
in „STM32 Arduino“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
swuart.c
#include "lib.h" #define PIN_RX ((PIND >> 2) & 1) #define RX_TIME_1ST_BIT 53 #define RX_TIME_BIT_TIME 35 #define TIMER2_DIVIDER 4 #define INIT_TX_PIN DDRD |= 0x08; PORTD |= 0x08; #define SET_TX_PIN PORTD |= 0x08; #define CLR_TX_PIN PORTD &= ~0x08
in „Problem mit SW UART“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
rs232.c
endif // USART Transmitter interrupt service routine #pragma savereg- interrupt [USART_TXC] void uart_tx_isr(void) { #asm push r26 push r27 push r30 push r31 in r26,sreg push r26 #endasm if( tx_counter ) { --tx_counter; #ifdef MEGA168 UDR0 = tx_buffer[tx_rd_index]; #else UDR = tx_buffer[tx_rd_index]; #endif
in „ASCII in Hex und zurück“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
XIAO_ESP32S3_Plus_V1.0_241025.pdf
- D8/A8/SCK 12 GPIO6 SPICS0 31 SPIWP USB_D- R4 22R ESP_USB_D+ GPIO7 SPIWP D6/TX 7 8 D7/RX A7/DN1 B6/DP2 D9/A9/MISO 13 C P N 30 SPIHD U0TXD_D6/TX U0RXD_D7/RX P P GPIO8 R _ _ SPIHD A8/SBU1 B5/CC2 VBUS N N D10/A10/MOSI 14 GPIO9 _ 2 2 VDD_SPI 29 VDD_SPI IO38/DVP_VSYNC/I2S_SD 15 21 IO11
-
Datei
20141119_SoftUart.asm
bits) com Txbyte ;Inverte everything sec ;Start bit putchar0: brcc putchar1 ;If carry set cbi PORTD,TxD ;send a '0' rjmp putchar2 ;else putchar1: sbi PORTD,TxD ;send a '1' nop putchar2: rcall UART_delay ;One bit delay rcall UART_delay lsr Txbyte ;Get next bit dec bitcnt ;If not all bit sent brne putchar0
in „Perfomance bei SoftUART (AVR305) in Assembler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Modbus.c
}; static uint8_t modbusRxFrmBuffer[MODBUSRXFRMLENGTH] = {':', 'F', 'F', '0', '6', '0', '0', '0', '2', '0', '0', 'A', 'B', '9', '7', 0x0D, 0x0A}; static uint8_t modbusRxFrmIndexAct = 0; MODBUS_STAT_REG modbusStatReg; static MODBUS_RX_FRAME modbusRxFrame; char modbusTxFrameFC04[MODBUSTXFRAMELENGTHFC04
in „Attiny 2313A - ROM am Limit? Probleme mit Optimierer“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Modbus.c
}; static uint8_t modbusRxFrmBuffer[MODBUSRXFRMLENGTH] = {':', 'F', 'F', '0', '6', '0', '0', '0', '2', '0', '0', 'A', 'B', '9', '7', 0x0D, 0x0A}; volatile MODBUS_STAT_REG modbusStatReg; char modbusTxFrameFC04[MODBUSTXFRAMELENGTHFC04] = {0x3A, 0xFF, 0xFF, 0x30, 0x34, 0x30, 0x32, 0xFF, 0xFF, 0xFF, 0xFF
in „Attiny 2313A - ROM am Limit? Probleme mit Optimierer“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
untitled.pdf
10 µ D D D LP2951ACM D D N N N N N A A A A A 4 IC2P C9 100 n Microphone NF amplifier with 200 Hz high-pass and active low-pass 4 kHz (TI FilterPro) AM "modulator" :-) MC33204 B 1 B N N G G A A k k k 2 , 7 0 1 , IC2B TX_VCC R 6 R 1 R 2 3 IC2A 5 7 10 1
-
Datei
PLC-LOX-300-13-12-2019Multibus-2.ino
/* UDP syntax: signals: DS18B20 1wire sensor packet: rail1 1w2 2864fc3008082 temp 25.44 DS2438 1wire sensor packet: rail1 1w2 2612c3102004f 25.44 1.23 0.12 Sensor detected (after start): rail1 1w2 2864fc3008082 detected Sensor error
in „1 Wire auf 2 GPIO pins“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
RF_CMD(0x82,0x09); // TX off enable_interrupts(); } // TX: Datenbyte raussenden (1=warten, 0=sofort senden (nur erstes Byte)) void RF_SendByte(unsigned char data) { PORTCbits.RC2=0; SPIRF(0xB8); SPIRF(data); PORTCbits.RC2=1;
in „RFM12 - Funkmodul“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
RF_CMD(0x82,0x09); // TX off enable_interrupts(); } // TX: Datenbyte raussenden (1=warten, 0=sofort senden (nur erstes Byte)) void RF_SendByte(unsigned char data) { PORTCbits.RC2=0; SPIRF(0xB8); SPIRF(data); PORTCbits.RC2=1;
in „PIC18: Getesteter CCS C-Code für RFM12 Modul“ · Projekte & Code ·
-
Datei
main.c
RF_CMD(0x82,0x09); // TX off enable_interrupts(); } // TX: Datenbyte raussenden (1=warten, 0=sofort senden (nur erstes Byte)) void RF_SendByte(unsigned char data) { PORTCbits.RC2=0; SPIRF(0xB8); SPIRF(data); PORTCbits.RC2=1;
in „Beispielprogramm für RFM12 433MHz Funk-Module“ · Projekte & Code ·
-
Datei
rfm12.inc
@ 3,3V ldi YL, 0x40 ; 1MHz: 600b / 2MHz: c06b / 2,5MHz: c08b / 5MHz: c0cb rcall rfm_com_send pop YL pop YH ret ;------------------------------------------------------------------ rfm_receive_init: push YH push YL rcall rfm_status ;
in „RFM12 Initialisierung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
rfm12.inc
@ 3,3V ldi YL, 0x40 ; 1MHz: 600b / 2MHz: c06b / 2,5MHz: c08b / 5MHz: c0cb rcall rfm_com_send pop YL pop YH ret ;------------------------------------------------------------------ rfm_receive_init: push YH push YL ; Configuration Setting
in „RFM12 Empfängt nichts (ASM)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
stm32f4xx_spi.c
register value */ tmpreg = I2Sxext->I2SCFGR; /* Get the mode to be configured for the extended I2S */ if ((I2S_InitStruct->I2S_Mode == I2S_Mode_MasterTx) || (I2S_InitStruct->I2S_Mode == I2S_Mode_SlaveTx)) { tmp = I2S_Mode_SlaveRx
in „GCC Optimierung killt Funktion“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
suarttx.c
#include <stdbool.h> #define F_CPU 8e6 #include <util/delay.h> #define BAUD 9600 #define STOP_BITS 2 #define MARK true // direct connection //#define MARK false // with Transceiver #define STXD SBIT( PORTB, 0 ) #define STXD_oe SBIT( DDRB, 0 ) enum {TX_SRAM, TX_FLASH }; struct bits { uint8_t b0:1, b1:1, b2:1, b3:1, b4:1, b5:1, b6:1, b7:1; } __attribute__((__packed__)); #define SBIT_(port,pin) ((*(volatile struct bits*)&port).b##pin) #define SBIT(x,y) SBIT_(x,y) void sputchar(char c) { c = ~c; // complement
in „ATtiny44 -Software Uart - nur senden“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
suarttx.c
#include <stdbool.h> #define F_CPU 8e6 #include <util/delay.h> #define BAUD 9600 #define STOP_BITS 2 #define MARK true // direct connection //#define MARK false // with Transceiver #define STXD SBIT( PORTB, 0 ) #define STXD_oe SBIT( DDRB, 0 ) enum {TX_SRAM, TX_FLASH }; struct bits { uint8_t b0:1, b1:1, b2:1, b3:1, b4:1, b5:1, b6:1, b7:1; } __attribute__((__packed__)); #define SBIT_(port,pin) ((*(volatile struct bits*)&port).b##pin) #define SBIT(x,y) SBIT_(x,y) void sputchar(unsigned char c) { c = ~c;
in „ADC-Kanäle sukzessive abfragen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
suarttx.c
#include <stdbool.h> #define F_CPU 8e6 #include <util/delay.h> #define BAUD 9600 #define STOP_BITS 2 #define MARK true // direct connection //#define MARK false // with Transceiver #define STXD SBIT( PORTB, 0 ) #define STXD_oe SBIT( DDRB, 0 ) enum {TX_SRAM, TX_FLASH }; struct bits { uint8_t b0:1, b1:1, b2:1, b3:1, b4:1, b5:1, b6:1, b7:1; } __attribute__((__packed__)); #define SBIT_(port,pin) ((*(volatile struct bits*)&port).b##pin) #define SBIT(x,y) SBIT_(x,y) void sputchar(unsigned char c) { c = ~c;
in „serieller TX mit delay in Software (AVR, UART)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
Enable access to COMDIV registers COMDIV0 = 0x21; // Set baud rate to 9600. COMDIV1 = 0x00; //COMDIV2 = 0x21 + BIT11; // Enable fractional divider for more accurate baud rate setting COMCON0 = BIT0 + BIT1 + BIT2; COMIEN0 = BIT0 + BIT1; // Enable UART interrupts when Rx full and Tx buffer empty. // Configure
in „ADuC7060 ADC-Problem“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
PL68K12.pdf
I3-68901 26 I4-68901 RxD-68901 (MAX232 opt.) 27 TxD-68901 (MAX232 optional) Timer B out-68901 28 Timer A out-68901 RxC/TxC-68901 29 Timer C out-68901 I1-68901 30 I0-68901 Timer B in-68901 31 I2-68901 GND, 0 Volt 32 Timer A in-68901 5 50-pol. Steckverbinder
in „S: 68000/68HC000/68EC000/68001 CPUs min. 12MHz“ · Markt ·
-
PDF
PL68K12.pdf
I3-68901 26 I4-68901 RxD-68901 (MAX232 opt.) 27 TxD-68901 (MAX232 optional) Timer B out-68901 28 Timer A out-68901 RxC/TxC-68901 29 Timer C out-68901 I1-68901 30 I0-68901 Timer B in-68901 31 I2-68901 GND, 0 Volt 32 Timer A in-68901 5 50-pol. Steckverbinder
in „[S] MPU (Z80/6502/68k)“ · Markt ·
-
Datei
BUE2014d01_Feuchtesensor.c
/Modbus init (incl. UART config) modbus_init(); //I2C Config USI_TWI_Master_Initialise(); //LED blinking TCCR0B |= 0b101; //Enable Timer0 with f_clk/1024 prescaler //Enable Interrupts sei(); //Enter infinite loop for(;;){ //45 ms timer (@f_busclk = 12000000
in „Attiny 2313A - ROM am Limit? Probleme mit Optimierer“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
DM-KIT-SSK_for_BF533.pdf
of 16 File: D:产品化方案 \白金版 SSK533\statek定板 Drawn修By:图 .ddb 1 2 3 4 5 6 7 8 1 2 3 4 5 6 E D D A R96 BF_ABE3 0 U36 U31 BF_A2 3 A0 B0 17 A2 BF_D0 2 A0 B0 18 D0 BF_A3 4 A2 B2 16 A3 BF_D2 4 A1 B1 16 D2 BF_A5 6 A3 B3 14 A5 BF_D3 5 A3 B3 15 SD3 BF_A6 7 A5 B5 13 A6 BF_D5
-
Datei
usb_descriptors.h
EP_INTERVAL_6 0xFF //ms interrupt pooling from host // USB Endpoint 1 descriptor // Bulk IN #define TX_EP0_SIZE 0x20 #define ENDPOINT_NB_1 USB_ENDPOINT_IN | TX_EP0 #define EP_ATTRIBUTES_1 0x02 // BULK = 0x02, INTERUPT = 0x03 #define EP_SIZE_1 TX_EP0_SIZE #define EP_INTERVAL_1 0x00 // USB Endpoint 2 descriptor //Bulk OUT RX endpoint #define RX_EP0_SIZE 0x20 #define ENDPOINT_NB_2 RX_EP0 #define EP_ATTRIBUTES_2 0x02 // BULK = 0x02, INTERUPT = 0x03 #define EP_SIZE_2 RX_EP0_SIZE #define EP_INTERVAL_2 0x00 // USB Endpoint 4 descriptor // Bulk IN #define TX_EP1_SIZE 0x20 #define ENDPOINT_NB
in „Dual Role USB - Device (CDC + CDC)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
enc28j60.c
WriteCtrReg(ERXFCON,( ERXFCON_UCEN + ERXFCON_CRCEN + ERXFCON_BCEN)); // Initialise the MAC registers BankSel(2); // select bank 2 SetBitField(MACON1, MACON1_MARXEN); // Enable reception of frames WriteCtrReg(MACLCON2, 63); WriteCtrReg(MACON3, MACON3_FRMLNEN + // Type / len field will be checked MACON3_TXCRCEN
in „enc28j60 LanController initialisieren auf ARM7“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
RS232_Test.vhd
); Port ( RXD : in STD_LOGIC; RX_Data : out STD_LOGIC_VECTOR (7 downto 0); TXD : out STD_LOGIC; -- TX_Data : in STD_LOGIC_VECTOR (7 downto 0); CLK : in STD_LOGIC ); end RS232_test; architecture Behavioral of RS232_test is signal value1 : std_logic_vector (7 downto 0) := "01000000"; signal value2 : std_logic_vector
in „Vertauschte Ausgabe des std_logic_vector“ · FPGA, VHDL & Co. ·
-
PDF
C65_Diagram_Set.pdf
13 E /sheet3 13 B /sheet8 10 A IR_AC_TX PM_I2S_DAC /sheet1 15 B /sheet4 2 A TVCO VDD_AFC /sheet6 7 D /sheet8 15 F /sheet3 2 D CLK32 /sheet5 14 E MICEA /sheet5 13 C /sheet4 4 A /sheet4 2 D /sheet6 4 B /sheet6 2 C /sheet3
in „Reengineering: Siemens S65 Display“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
usbd_cdc_vcp.c
****************************************************************************** * @attention * * <h2><center>© COPYRIGHT 2012 STMicroelectronics</center></h2> * * Licensed under MCD-ST Liberty SW License Agreement V2, (the "License"); * You may not use this file except in compliance with the License
in „STM32F2xx - USB_OTG_FS“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
CanBus_RTC_Adapter.pdf
1 2 3 4 5 6 3 3 3 +3V3 3 3 38 VCC 3 + + +1 IC4 GND 15 JP3 J1P3 P$3SDA 16 SDA VBAT 14 3 4 TX0RTS DCLKOUT 3 2 1 1 SCL SQW 2 3 C6 5 TX1RTS D R5 JP1 JP3 J1P5 P$5SCL + 6 TX2RTS V A 10010 RX1BF IC2 A + 2 11 RX0BF
in „LinuxCNC mit rasberry-PI als IO-Interface -“ · PC Hard- und Software ·