-
Datei
dma.c
void gpdma_test() { char buf[255]; LPC_GPDMA->CONFIG = 1; while ( ! (LPC_GPDMA->CONFIG & 1) ) { } LPC_GPDMA->INTTCCLEAR = 0xFF; LPC_GPDMA->INTERRCLR = 0xFF; sprintf(buf, "enabled channels: 0x%X\n", LPC_GPDMA->ENBLDCHNS); debug_uart(buf); // gives 0 IP_GPDMA_001_CH_T ch = LPC_GPDMA->CH[7]; uint32_t src[512] __attribute__ ((aligned (256))); uint32_t dest[512] __attribute__ ((aligned (256))); ch.SRCADDR = src; ch.DESTADDR = dest; ch.LLI = 0; // xfersize sbsize dbsize swidth
in „HI-Empfänger: Könnte das so funktionieren?“ · HF, Funk und Felder ·
-
PDF
landtiger_v2.0_-_manual__v1.1.pdf
powersupply !!!!! The 0-Ohm resistor R58 should be removed from the mainboard. 2.9 EEPROM LandTiger LPC17XX development board includes a 24LC02 (2 kbit / 256kByte) EEPROM (U6) connected to the LPC1768 I2C_0 port (fast mode supported, upto 1 Mbit/s). IO Pin Description P0.27 EEPROM SDA P0.28 EEPROM SCL
-
Datei
flushmagic.py
--------------------------------------------------- def getPartName(partID): return { 0x00008100: "LPC810M021FN8", # 0x00008110: "LPC811M001JDH16", # 0x00008120: "LPC812M101JDH16", # 0x00008121: "LPC812M101JD20", # 0x00008122: "LPC812M101JDH20" }.get(partID, "") #-------------------------------------
-
PDF
top2008.pdf
P89C51RA2F, P89C51RB2F, P89C51RC2F, P89C51RD2F, P89C60X2, P89C61X2, P89C660, P89C662, P89C664, P89C668, P87LPC759, P87LPC760, P87LPC761, P87LPC762, P87LPC764, P87LPC767, P87LPC768, P87LPC769, P89LPC920, P89LPC921, P89LPC922, P89LPC9221, P89LPC924, P89LPC925, P89LPC930, P89LPC931, P89LPC932, P89LPC932A1, P89LPC933, P89LPC934, P89LPC935, P89LPC936, P89LPC938, V51RA2B, C922SPI, ____MPU-WINBOND W78E51, W78E51B, W78LE51, W78E51C, W78LE51C, W78L051C, W78E52, W78E52B, W78LE52, W78E52C, W78LE52C, W78L052C, W78E54, W78E54B,
in „[V] Top 853 Universal Programmer + 74er Tester“ · Markt ·
-
Datei
configx.h
if zucAVR==0 #include "C:\zuc\net\wkkstring.h" #endif #include "C:\zuc\net\config_network.h" #if zucLPC176x //#include "C:\zuc\net_lowlevel_lpc\networkdevice.h" #include "C:\zuc\net_lowlevel_lpc\target.h" #include "C:\zuc\net_lowlevel_lpc\lpc17xx_emac.h" #include "C:\zuc\net_lowlevel_lpc\lpc17xx_emac.c.h
in „Header Datei für Konfiguration erstellen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
iap_fkt.c
READ_BOOT_CODE_VERSION 55 #define COMPARE 56 //ISP_READ_MEMORY_CMD //ISP_Go <address> <mode> //PartIDs #define PART_ID_LPC2141 0x0402FF01 #define PART_ID_LPC2142 0x0402FF11 #define PART_ID_LPC2144 0x0402FF12 #define PART_ID_LPC2146 0x0402FF23 #define PART_ID_LPC2148 0x0402FF25 //IAP-Status-Codes #define CMD_SUCCESS 0 //
in „LPC2148 - IAP - Copy Ram To Flash“ · Mikrocontroller und Digitale Elektronik ·
-
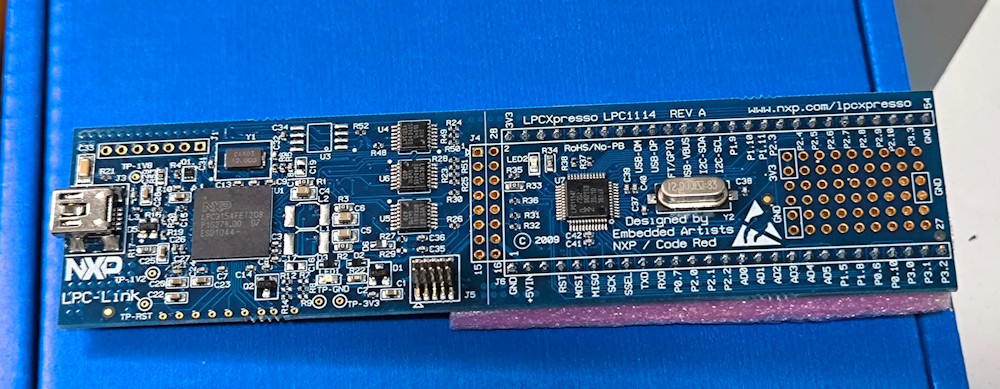
 Bild
LPCXpresso LPC1114 Mikrocontroller Development Board
LPCXpresso LPC1114 REV A www.nxp.com/lpcxpresso NXP LP2154FE1208 Designed by Embedded Artists NXP / Code Red
in „[V] Diverse Evaluation-Boards - ca. 2014-2016“ · Markt · · Platinenfotos
-
Datei
lpc-pll.c
#include "config.h" static void pllfeed() { PLL.feed = 0xAA; PLL.feed = 0x55; } // // Fosc = 14,745,600 Hz // M = 4 // P = 2 // Fcco = Fosc * M * 2 * P = 235,929,600 Hz // Fcpu = M * Fosc = 58,982,400 Hz // void PLLStart() { #if CCLK == F_CRYSTAL PLL.con = 0; // disconnect from PLL, disable PLL pllfeed(); #else #if F_CRYSTAL == 10000000 && CCLK == F_CRYSTAL*6 #define PSEL 1 // P == 2 #define MSEL 5 // M == 6 #elif F_CRYSTAL > 10000000 && F_CRYSTAL <= 12000000 && CCLK == F_CRYSTAL*5 #define PSEL 1 // P == 2 #define MSEL 4 // M == 5 #elif F_CRYSTAL > 12000000 && F_CRYSTAL <= 15000000 && CCLK == F_CRYSTAL
in „I2C Startcondition und dann nix mehr“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
-
Datei
LPC2129.ld
_stacks = 0x40004000; /* stacks grow downward, starting at end of RAM */ MEMORY { ROM (rx) : ORIGIN = 0x00000000, LENGTH = 0x0003E000 /* bootloader at 3E000 */ RAM (rw) : ORIGIN = 0x40000000, LENGTH = 0x00004000 }
in „LPC2148 ARM7 Interruptroutine beendet nicht richtig“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC2300.s
;/*****************************************************************************/ ;/* LPC2300.S: Startup file for Philips LPC2300/LPC2400 device series */ ;/*****************************************************************************/ ;/* <<< Use Configuration Wizard in Context Menu >>>
in „Heap und Stack Einstellungen beim LPC23xx“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1768.ld
/* Linker script for Cortex-M3 * * Version:CodeSourcery Sourcery G++ Lite 2007q3-53 * BugURL:https://support.codesourcery.com/GNUToolchain/ * * Copyright 2007 CodeSourcery. * * The authors hereby grant permission to use, copy, modify, distribute, * and license this software and its documentation for any purpose, provided * that existing copyright notices are retained in all copies and that this * notice is included verbatim in any distributions. No written agreement, * license, or royalty fee is required for any of the authorized uses. * Modifications to this software may be copyrighted by their
in „LPC17xx (Cortex M3) mit FreeRTOS“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC812.ld
/* Linker script for mbed LPC812-GCC-ARM based on LPC824.ld */ /* Linker script to configure memory regions. */ MEMORY { /* Define each memory region */ FLASH (rx) : ORIGIN = 0x0, LENGTH = 0x4000 /* 16K bytes */ RAM (rwx) : ORIGIN
in „warum mecket der gcc nicht wenn der Flash überfüllt wird?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1768.ld
/* Linker script for mbed LPC1768 */ /* Linker script to configure memory regions. */ MEMORY { FLASH (rx) : ORIGIN = 0x00000000, LENGTH = 512K RAM (rwx) : ORIGIN = 0x100000C8, LENGTH = (32K - 0xC8) USB_RAM(rwx) : ORIGIN = 0x2007C000
in „LPC1768 OpenOCD arm-none-eabi-gcc 5.3.0“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1768.ld
/* Linker script for mbed LPC1768 */ /* Linker script to configure memory regions. */ MEMORY { FLASH (rx) : ORIGIN = 0x00000000, LENGTH = 512K RAM (rwx) : ORIGIN = 0x10000000, LENGTH = 32K //RAM (rwx) : ORIGIN = 0x100000C8, LENGTH
in „LWIP NetConn mit RTOS bleibt stehen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1768.ld
/* Linker script for mbed LPC1768 */ /* Linker script to configure memory regions. */ MEMORY { FLASH (rx) : ORIGIN = 0x00000000, LENGTH = 512K RAM (rwx) : ORIGIN = 0x10000000, LENGTH = 32K //RAM (rwx) : ORIGIN = 0x100000C8, LENGTH
in „Heap/Stack Definition“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1549.ld
ENTRY(_reset) MEMORY { /* memory map des LPC1549 */ Flash (rx): ORIGIN = 0x00000000, LENGTH = 0x00040000 /* 256kB */ SRAM0 (rwx): ORIGIN = 0x02000000, LENGTH = 0x00009000 /* 36kB */ } _stack_end = ORIGIN(SRAM0) + LENGTH(SRAM0); SECTIONS { .text
in „LPC1549 von Grund auf verstehen“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
LPC1549.ld
ENTRY(_reset) MEMORY { /* memory map des LPC1549 */ Flash (rx): ORIGIN = 0x00000000, LENGTH = 0x00040000 /* 256kB */ SRAM0 (rwx): ORIGIN = 0x02000000, LENGTH = 0x00009000 /* 36kB */ } _stack_end = ORIGIN(SRAM0) + LENGTH(SRAM0); SECTIONS { .text
in „LPC1549 von Grund auf verstehen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Schaltung_LPC.pdf
1JP1 GND 2 SV1 6 0 7 0 8 0 R 1 R 1 R 1 9 0 R 1 B GND GND GND GND GND B USB Buttons Mikrocontroller LPC1756 +3V3 +3V3 IC1 LPC1756 3 37 76 B1 J R16 R19 R21 38 P0[0]/RD1/TXD3/SDA1 P1[0]/ENET_TXD075 B2 1 2 10k R20 33K R22 33K TXD0 79 P0[2]/TXD0/AD0[7]L1 P1[4]/ENET_TX_EN74 B3 USB_VBUS B1 B2 RXD0 80 P0[3]/
in „LPC1756 - WS2812B und Schaltplankontrolle“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
dualMotorPll.c
#include <lpc17/lpc17.h> #include <lpc17/pinConnect.h> #include <lpc17/clock.h> #include <lpc17/usTimer.h> #include <lpc17/uart.h> #include <lpc17/adc.h> #include <lpc17/fc200.h> #include <lpc17/sysTickTime.h> #include <lpc17/simpleI2c.h> #include <lpc17/fc200Ui.h> #include <lpc17/fc200Fram.h> #include <fifoPrint.h> #include <fifoParse.h> #include <macros.h> #include <lpc17/pwm.h> #include <lpc17/nvic.h> #include <sineTables.h
in „Wechselrichter zur Netzeinspeisung bauen?“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
TouchI2C.c
REG935.H> #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\NLB_LPC93xx.h" #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\PortConfig.h" #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\I2C_Lib.h" unsigned char send[8]; unsigned char DC4; unsigned char DC1=0x11; unsigned char ESC=0x23; //sbit SCL = P2^5; //sbit MOSI = P2^2; //sbit MISO = P2^3; unsigned char len
in „Edip240-7 Touchscreen läuft nicht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Porting_ucOSII_to_ARM.pdf
and add more sections, and get newlib-lpc up-and-running, but for now, this will have to do. Feel free to post comments to the LPC2000 news group, I read it. Cheers, Dave Hawkins, Caltech. dwh@ovro.caltech.edu. 3 AR1803 May 10, 2006 Privileged
in „uC/OS-II portieren“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
I2C.c
REG935.H> #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\NLB_LPC93xx.h" #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\I2C_LIB.H" #include "C:\Dokumente und Einstellungen\Franz\Desktop\Diplomarbeit\TMP100\NLB935_TMP100\NLB-LPC935\LPC9xx-Library\inc\PortConfig.h" xdata struct stI2C Slave; static bit btI2cFinished; void v_InitI2C(void) { // SDA und SCL als Open-Drain konfigurieren v_PortConfig(PCFG_PORT1, (enum ePCFG_PINADDR
in „Edip240-7 Touchscreen läuft nicht“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
USBizi_User_Manual.pdf
-LPC2388- The LPC2387/8 72Mhz ARM7 32-bit processor is the core of USBizi. The processor has a wide range of peripherals that adds a lot of functions and features to USBizi such as PWM, GPIO, LCD Controller
in „Arm7 (Usbizi) über SPI LCD“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
UM10736.pdf
UM10736 LPC15xx User manual Rev. 1.2 — 28 December 2017 User manual Document information Info Content Keywords LPC1500, LPC1500 User manual , LPC15xx UM, LPC1549, LPC1548, LPC1547, LPC1519, LPC1518, LPC1517 Abstract LPC15xx User manual NXP Semiconductors UM10736 LPC15xx User manual Revision history Rev Date Description 1.2 20171228 LPC15xx User manual Modifications: • Section 27.7.5.2 “Calculating the C_CAN bit rate
in „LPC1549 USB Virtual COM-Port“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
*************** Header files **********************************************************/ #include "lpc210x.h" /******************************************************** * devices used *********************************************************/ pLPC_TIMER_typedef mytimer = TIMER0_BASE; /****************
in „ARM: Absturz zur Laufzeit“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
#include <cr_section_macros.h> #include <NXP/crp.h> #include "lpc17xx.h" #include "lpc_types.h" #include "dac_test_.h" #include "dma.h" extern volatile uint32_t DACDMA0Done, DACDMA1Done; /****************************************************************************
in „DAC+DMA LPC1769“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
lpc210x.h
// *********************************************************************** // // LPC210X.H: Header file for Philips LPC2104 / LPC2105 / LPC2106 // // *********************************************************************** #ifndef __LPC210x_H #define __LPC210x_H /* Base Adresses */ #define TIMER0_BASE ((pLPC_TIMER_typedef)0xE0004000) #define TIMER1_BASE ((pLPC_TIMER_typedef)0xE0008000) /* 0xE0000000 //Watchdog timer 0xE000C000 //UART0 0xE0010000 //UART1 0xE001C000 //I2C0 0xE0020000 //SPI0 0xE0024000 //RTC
in „ARM: Absturz zur Laufzeit“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
adc_drv.c
Suite 330, Boston, MA 02111-1307 USA * */ #define __ADC_DRV_C__ #include <mach/registers.h> #include "lpc3131_adc.h" u16 lpc3131_adc_read(int channel, int resolution) { u16 result = 0xffff; int timeout = 0xffffff; if((ADC_INT_STATUS_REG & 1)) { // wait if there is a conversion while(ADC_INT_STATUS_REG &
in „GNUBLIN www.gnublin.org“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
iocon.h
/* lpc8/iocon.h Copyright 2013 Marc Prager This file is part of the c-lpc8 library. c-lpc8 is free software: you can redistribute it and/or modify it under the terms of the GNU General Public License as published
in „schöner Code ?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
flushmagic.py
--------------------------------------------------- def getPartName(partID): return { 0x00008100: "LPC810M021FN8", # 0x00008110: "LPC811M001JDH16", # 0x00008120: "LPC812M101JDH16", # 0x00008121: "LPC812M101JD20", # 0x00008122: "LPC812M101JDH20" }.get(partID, "") #-------------------------------------
-
 Bild
Verschiedene Mikrocontroller-Entwicklungsboards auf blauem Untergrund
ST Nucleo XNUCLEO F103RB ARM Cortex-M3/M4 mbed 16. Waveshare XNUCLEO F103RB 17. HAOYOU LPC1768-Mini-DK2 18. NXP LPC1549xpresso V2 19. Panutt LPC1768 20. NXP LPC-Link 2 (LPC XPresso) 19.02.2024
in „[V] Sammlung diverser Entwicklungsboards“ · Markt · · Platinenfotos

-
Datei
lpc43xx_cgu.h
/********************************************************************** * $Id$ lpc43xx_cgu.h 2011-06-02 *//** * @file llpc43xx_cgu.h * @brief Contains all macro definitions and function prototypes * support for Clock Generation and Clock Control firmware * library on lpc43xx * @version
in „Cortex M0/M4 SPI nach CMSIS ?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
asmfunc.S
VIC_VectAddr] @ Issule EOI command MOVS PC, LR RegVect: CMP R0, #32 @ Range check MOVCSS PC, LR LDR IP, =(LPC_BASE_VIC+VIC_VectAddr0) STR R1, [IP, R0, LSL #2] @ Set VICVectVectAddr<n> LDR IP, =(LPC_BASE_VIC+VIC_VectPriority0) STR R2, [IP, R0, LSL #2] @ Set VICVectPriority<n> MOV R1, #1 MOV R1, R1, LSL R0 LDR IP, =LPC_BASE_VIC LDR R2, [IP, #VIC_IntSelect] @ Set corresponding bit in the VICIntSelect BIC R2, R1 CMP R3, #1 ORREQ R2, R1 STR R2, [IP, #VIC_IntSelect] STR R1, [IP, #VIC_IntEnable] @ Enable corresponding
in „GCC ARM: writeback of base register is UNPREDICTABLE“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
asmfunc.S
VIC_VectAddr] @ Issule EOI command MOVS PC, LR RegVect: CMP R0, #32 @ Range check MOVCSS PC, LR LDR IP, =(LPC_BASE_VIC+VIC_VectAddr0) STR R1, [IP, R0, LSL #2] @ Set VICVectVectAddr<n> LDR IP, =(LPC_BASE_VIC+VIC_VectPriority0) STR R2, [IP, R0, LSL #2] @ Set VICVectPriority<n> MOV R1, #1 MOV R1, R1, LSL R0 LDR IP, =LPC_BASE_VIC LDR R2, [IP, #VIC_IntSelect] @ Set corresponding bit in the VICIntSelect BIC R2, R2, R1 CMP R3, #1 ORREQ R2, R2, R1 STR R2, [IP, #VIC_IntSelect] STR R1, [IP, #VIC_IntEnable] @ Enable corresponding
in „FIQ interrupt using asmfunc.S or startup.S“ · µC & Digital Electronics ·
-
PDF
Frage.pdf
{ c = UART0_Getchar(); //Anfragen der Gerätezustände vom Computer empfangen switch(c) { case '9' : LPC_GPIO1->FIOSET=1<<18;LPC_GPIO1->FIOSET=1<<19;LPC_GPIO1->FIOSET=1<<20; for(n=0;n<5000000;n++); pin1=(LPC_GPIO0->FIOPIN>>21) &1 ; //Zustand an P0.21(0 oder 1) pin2=(LPC_GPIO0->FIOPIN>>27) &1 ; //Zustand
in „Microcontroller NXP LPCXpresso Board 1769“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
SCH_CP_JR_ARM7_USB_LPC2148_1_OF_3.pdf
1 2 3 4 OPTION FOR LPC2148 ONLY +3V3 +VUSB +VUSB +VUSB D LPC2138/LPC2148 D 16 19 USB LINK 560 P1.16 12 P1.16/TRACEPKT0 P0.0/TXD0/PWM1 21 P0.0 P1.17 8 P1.17/TRACEPKT1 P0.1/RXD0/PWM3/EINT0 22 P0.1 P0.31 2 P1.18 4 P1.18/TRACEPKT2
in „ARM-USB-OCD mit Eclipse“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ETT_2148.pdf
1 2 3 4 OPTION FOR LPC2148 ONLY +3V3 +VUSB +VUSB +VUSB D LPC2138/LPC2148 D 16 19 USB LINK 560 P1.16 12 P1.16/TRACEPKT0 P0.0/TXD0/PWM1 21 P0.0 P1.17 8 P1.17/TRACEPKT1 P0.1/RXD0/PWM3/EINT0 22 P0.1 P0.31 2 P1.18 4 P1.18/TRACEPKT2
in „Einstieg in die ARM Welt“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main_A.cpp
###############################*/ void procFile(char *root, char *oldname, time_t mtime, long int *lpcF) { char st[PATH_MAX], *cp; // newname[PATH_MAX]; // // int c; // struct tm *t; printf("prüfe Datei %s, pcF=%ld \n", oldname, *lpcF); cp = strrchr(oldname, '.'); // Returns a pointer to the last occurrence
in „Mit C mehrstufige Verzeichnisstruktur durchsuchen;“ · Softwareentwicklung ·
-
Datei
main_B.cpp
###############################*/ void procFile(char *root, char *oldname, time_t mtime, long int *lpcF) { char st[PATH_MAX], *cp; // newname[PATH_MAX]; // printf("prüfe Datei %s, pcF=%ld \n", oldname, *lpcF); cp = strrchr(oldname, '.'); // Returns a pointer to the last occurrence of character in the
in „Mit C mehrstufige Verzeichnisstruktur durchsuchen;“ · Softwareentwicklung ·
-
Datei
main.c
if(sender==1){ //TX SPI_Send_Strobe(SIDLE); PowerDown(); SPI_Send_2Byte(0x3F, 0xB6); // tempTaster=(LPC_GPIO1->DATA & (1<<4)); //Pin26 PIO1_4 Steigensde Flanke // if(tempTaster == 0 && (LPC_GPIO1->DATA & (1<<4))){ // //In TX_Fifo wird B6 geschrieben // SPI_Send_2Byte(0x3F, 0xB6); // } TxModus(); } else
in „CC2500 Programm Ablauf (Tx/Rx Modus)“ · HF, Funk und Felder ·
-
Datei
diff.txt
/andy/Electronic/Soldering/T962/T-962-improvements-master_original/src/main.c /home/andy/workspace/LPC/T-962-improvements-master/src/main.c 53c53 < return "no version info"; --- > return "abr 08/13/2019"; 76a77,78 > " sensors Show which sensors are present\n" \ > " scan1w New scan of the 1-wire bus\n
in „Überspannung Quarzheizstäbe“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
Vorlage_100x75.pdf
1 2 3 4 5 6 LPC1752_PORT0 LPC1752_POWER Port 0 37 V SDA1/P0.0 38P0.0-CAN:RX 16 3 A SCL1/P0.1 79P0.1-CAN:TX VBAT VBAT 1 + A TXD0/P0.2 80 BLD SWO/TDO 2 TDI/TDO +3V3/2.1B RXD0/P0.3 64 C27 C26 10 TDI 3 SSEL1/P0.6 63 +3V3
-
Datei
pllsetup.S
#0x55 str r1, [r0, #PLLFEED_OFFSET] str r2, [r0, #PLLFEED_OFFSET] /* Set clock divider */ mov r1, #LPC23XX_CCLK_DIV str r1, [r0, #LPC23XX_CCLKCFG_OFFSET] /* Wait until PLL Locked */ 1: ldr r3, [r0, #PLLSTAT_OFFSET] ands r3, r3, #PLLSTAT_PLOCK beq 1b /* Enable and connect PLL */ @mov r3, #(PLLCON_PLLE
-
PDF
io-controller-hub-9-datasheet.pdf
...............................................................................439 13.1.22LPC_EN—LPC I/F Enables Register (LPC I/F—D31:F0)................................440 13.1.23GEN1_DEC—LPC I/F Generic Decode Range 1 Register (LPC I/F—D31:F0) .............................................
in „FLASH Memory Chip im Lenovo X200 von 8 MB auf 16 MB vergroessern“ · PC Hard- und Software ·
-
Datei
platformio.ini
/archive/1.5.0.zip build_flags = ${common.build_flags} -DU8G_HAL_LINKS -IMarlin/src/HAL/LPC1768/include -IMarlin/src/HAL/LPC1768/u8g # debug options for backtrace #-funwind-tables #-mpoke-function-name # # NXP LPC176x ARM Cortex-M3 # [env:LPC1768] platform = ${common_LPC.platform} extends = common_LPC board = nxp_lpc1768 [env:LPC1769] platform = ${common_LPC.platform} extends = common_LPC board = nxp_lpc1769 ################################# # # # STM32 Architecture # # # ########################
in „Ender3 Z-Achse fährt mit Marlin nur nach oben“ · Mechanik, Gehäuse, Werkzeug ·
-
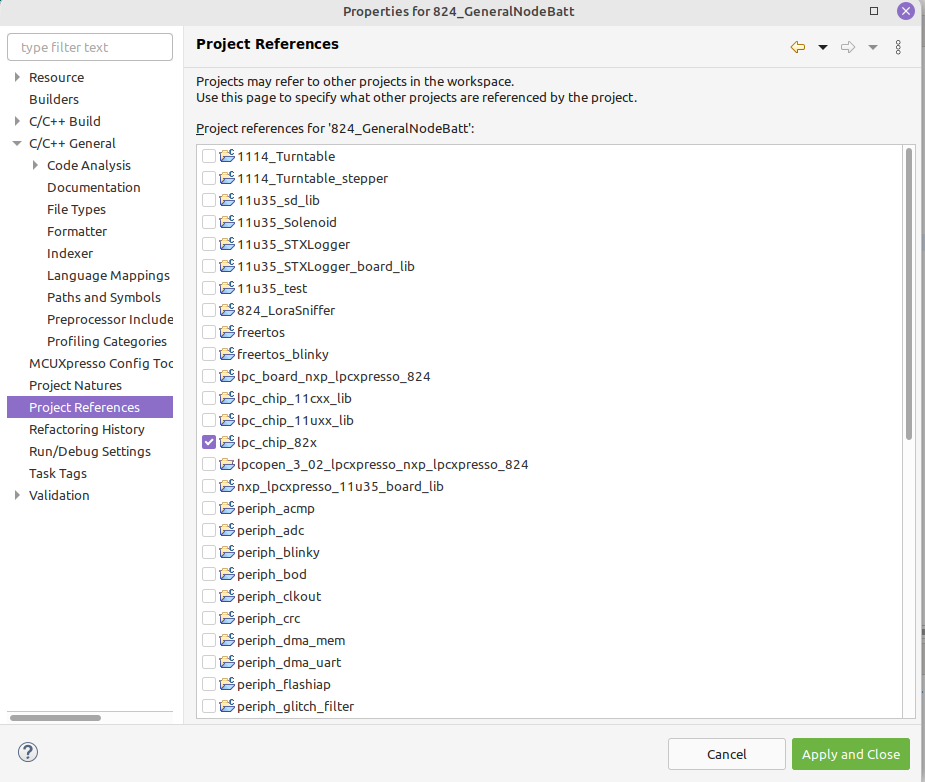
 Bild
Projektreferenzen in einer Software-Entwicklungsumgebung
Solenoid 11u35_STXLogger 11u35_STXLogger_board_lib 11u35_test 824_LoraSniffer freertos freertos_blinky lpc_board_nxp_lpcxpresso_824 lpc_chip_11cxx_lib lpc_chip_11uxx_lib lpc_chip_82x lpcopen_3_02_lpcxpresso_nxp_lpcxpresso_824 nxp_lpcxpresso periph_acmp periph_adc periph_blinky periph_bod periph_clkout periph_crc
in „Nicht finden der Header-Datei in MCUXpresso IDE“ · Mikrocontroller und Digitale Elektronik · · Screenshots
-
PDF
Erkl_rung_von_BlinkLED.pdf
*************** Header files **********************************************************/ #include "LPC22xx.h" #include "LCD.h" /********************************************************** MAIN **********************************************************/ #define LED 1<<30 int main (void) { float spannung
in „LPC2294: LCD Ausgabe“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
#include <lpc17xx.h> #include <lpc17xx_pinsel.h> #include <lpc17xx_emac.h> #include <lpc17xx_gpio.h> uint8_t MAC_Address[] = {0x01, 0x23, 0x45, 0x67, 0x89, 0xAB}; int main(void) { PINSEL_CFG_Type PinConf; EMAC_CFG_Type
in „LPC1768 Ethernet mit DP83848J“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.cpp
<< ret << endl; return false; } cout << "Registry erfolgreich geoeffnet!" << endl << endl;; do { //lpcValueName = MAX_PATH; //lpcbData = MAX_PATH; ret = RegEnumValue( Result, dwIndex++, lpValueName, &lpcValueName, NULL, NULL, lpData, &lpcbData); if (ret == ERROR_NO_MORE_ITEMS) { cout << " "; for (int i = 0; i < lpcValueName; i++) cout << lpValueName[i]; cout << " "; for ( int i = 0 ; i < lpcbData ; i++ ) { cout << lpData[i]; } cout << endl << endl; } } while (ret != ERROR_NO_MORE_ITEMS); if ( RegCloseKey ( Result
in „Serielle Schnittstelle mit C/C++ ansteuern“ · Softwareentwicklung ·