-
Datei
m8def.inc
; For compatibility, .equ MCUCSR =$34 ; keep both names until further .equ TCCR0 =$33 .equ TCNT0 =$32 .equ OSCCAL =$31 .equ SFIOR =$30 .equ TCCR1A =$2f .equ TCCR1B =$2e .equ TCNT1H =$2d .equ TCNT1L =$2c .equ OCR1AH =$2b .equ OCR1AL =$2a .equ OCR1BH =$29 .equ OCR1BL =$28 .equ ICR1H =$27 .equ ICR1L =$26
in „AVR ASM Timer-Interrupt“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
m8def.inc
; For compatibility, .equ MCUCSR =$34 ; keep both names until further .equ TCCR0 =$33 .equ TCNT0 =$32 .equ OSCCAL =$31 .equ SFIOR =$30 .equ TCCR1A =$2f .equ TCCR1B =$2e .equ TCNT1H =$2d .equ TCNT1L =$2c .equ OCR1AH =$2b .equ OCR1AL =$2a .equ OCR1BH =$29 .equ OCR1BL =$28 .equ ICR1H =$27 .equ ICR1L =$26
in „def. inc Datei“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
m8def.inc
; For compatibility, .equ MCUCSR =$34 ; keep both names until further .equ TCCR0 =$33 .equ TCNT0 =$32 .equ OSCCAL =$31 .equ SFIOR =$30 .equ TCCR1A =$2f .equ TCCR1B =$2e .equ TCNT1H =$2d .equ TCNT1L =$2c .equ OCR1AH =$2b .equ OCR1AL =$2a .equ OCR1BH =$29 .equ OCR1BL =$28 .equ ICR1H =$27 .equ ICR1L =$26
in „Anfänger Frage zu Assembler“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Schrittmotor.asm
1 ;Marke +- PWMAdr1: .byte 1 PWMAdr2: .byte 1 Motb: .byte 3 ;Motor Betrieb - Schritte/U Moth: .byte 2 ;Motor Betrieb - Schritte/U / 100 Bmot: .byte 1 ;derzeitiger Motor Betriebsart .org 0x0200-32 ;Anfangsadresse Puffer Serielle Schnittstelle
in „Spielerei mit einem 5-Phasen-Schrittmotor“ · Projekte & Code ·
-
Datei
ausfuehrliche_ausgabe.txt
skipping Using Port : /dev/ttyUSB0 Using Programmer : arduino Overriding Baud Rate : 115200 AVR Part : ATmega328P Chip Erase delay : 9000 us PAGEL : PD7 BS2 : PC2 RESET disposition : possible i/o RETRY pulse : SCK Serial program mode : yes Parallel program mode : yes Timeout : 200 StabDelay : 100 CmdexeDelay : 25 SyncLoops : 32 PollIndex : 3 PollValue : 0x53 Memory Detail : Block Poll Page Polled Memory Type Alias Mode Delay Size Indx Paged Size Size #Pages MinW MaxW ReadBack ----------- -------- ---- ----- ----- ---- -----
in „Arduino Uno Bootloader verwenden“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AVR-ASM-Tutorial_16_05_08_v1.pdf
Binärzahlen von Dezimalzahlen zu unterscheiden, wird ein 0b vorangestellt): 0b10011010 = 1 * 128 ( 128 = 2 hoch 7 ) + 0 * 64 ( 64 = 2 hoch 6 ) + 0 * 32 ( 32 = 2 hoch 5 ) + 1 * 16 ( 16 = 2 hoch 4 ) + 1 * 8 ( 8 = 2 hoch 3 ) + 0 * 4 ( 4 = 2 hoch 2 ) + 1 * 2 ( 2 = 2 hoch 1 ) + 1 * 1 ( 1 = 2 hoch 0 ) Ausgerechnet
in „AVR-ASM-Tutorial: PDF 16.5.08“ · www.mikrocontroller.net ·
-
Datei
ProgrammV2.asm
----------------- ;ADC ; ADC initialisieren: ADC0, AVcc als Referenz, Single Conversion, Vorteiler 32 ;ADLAR=1 linksbündig ergebniss in ADCH + niederwertigste 2 bit in ADCL 6 u 7 ldi temp1, (0<<REFS1)|(1<<REFS0) out ADMUX, temp1 ;ADEN=ADC ein,ADPS2-0= Vorteiler 32 (sollte zwischen 50-200kHz liegen(4.000khz/32=125kHz)) ldi temp1, (1<<ADEN) | (1<<ADPS2) | (0<<ADPS1) | (1<<ADPS0) out ADCSRA, temp1 ;--------------------------------PWM Initialisierung-------------------------------------- ;PWM initialisieren 14Fast
in „Analog zu PWM. Fehler im Programm?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
ProgrammV2.asm
---------------------- ; ADC initialisieren: ADC0, AVcc als Referenz, Single Conversion, Vorteiler 32 ; ADLAR=1 linksbündig ergebniss in ADCH + niederwertigste 2 bit in ADCL 6 u 7 ldi temp1, (0<<REFS1)|(1<<REFS0) out ADMUX, temp1 ; ADEN=ADC ein,ADPS2-0= Vorteiler 32 (sollte zwischen 50-200kHz liegen(4.000khz/32=125kHz)) ldi temp1, (1<<ADEN)|(1<<ADPS2)|(0<<ADPS1)|(1<<ADPS0) out ADCSRA, temp1 ;--------------------------------PWM Initialisierung-------------------------------------- ; PWM initialisieren 14Fast
in „Analog zu PWM. Fehler im Programm?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Dokument1.txt
string.h> typedef uint8_t ui8; typedef int8_t i8; typedef uint16_t ui16; typedef int16_t i16; typedef uint32_t ui32; typedef int32_t i32; typedef unsigned char ucha; typedef unsigned char byte; // ***** Defines. #if !defined (F_CPU) #define F_CPU 7372800 // uC-Takt 7,3728 MHz #endif #define TAKT F_CPU #define
in „ATmega128 USART kriegs nicht zum Laufen / bin am verzweifeln“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
ControlPrint.pdf
C11 C12 C13 C14 C15 C17 D9 D10 100nF 100nF 100nF 100nF 100nF 100nF 100nF 100nF 100nF 100nF 100nF 220uF 4.7uF 7 LL4148 R4 7 LL4148 R5 4 C18 470k 4 C19 470k GND 1nF K 1nF K C C +5V GND GND P3 B 2 B 1 C22 +5V 4.7uF FAN_CON Q1 U1 2N7002FAN R +5V +5V R6 P4 E 40 37 ADC0 IC1 IC2 470k P5 O 41 PB0 (XCK/T0) PA0
in „LCD Display funktioniert nur wenn ich den uC Flashe“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Component_tester_T7-dreieck.pdf
1 B C 6 U1 28 B GND GND C17 ATmega644PA-A 2 7 27 C XTAL2 AVCC VUSB C4 Y1 16MHz VCC +5V 8 26 XTAL1 PC7 R0 C16 0R82 C3 9 25 R15 C1 1 VBAT PD0 PC6 470k 1 3 2 4 þÿ1µ R1 ca. +3V7 1 0 U6 TP4057 C2 R13 C 2 S + D I 4
-
PDF
DenisK_SCH.pdf
1 2 3 4 5 +3.3V AVR ISP 6pol R5,R6,R7 nicht best▯ückt. R6 R5 47K 47K R3 470 R7 U1 C10 A ISP_MISO ISP 47K ATMEGA128A-AU A 210-72-03GB01 10nF R2 1 2 R4 1 PEN# AVCC 64 +3.3V 470 ISP_SC3 1 2 4 470 ISP_MOSI 2
in „ATMEGA128A-AU vs 128A U-TH und 3V vs 5V ISP Programmierspannung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Component_tester_T7-dreieck.pdf
P P P B B B B B N C P o A A A 100k R3_{d A0 1 P P P P P G V 7 m P P P 33 K . R2_{d} 10k PB5 n r PA4 þÿU_{Zener}/_{10} ! 8 e 10k SDA P k W i R1_{d} SCL 2 32 R16 1 s i 10k PB6 PA5 þÿU_{Battery} ! VBAT 8 2 5 t e R C D e g Display (on separate board). 3 31 n l PB7 PA6 TP1 Z v 4 ~{RESET} PA7 30 0k R1 C21 DZ2_{1} C 5 VCC AREF 29 V 8 Internal B C U_{Ref} Buffer B 6 GND U1 GND 28 ATmega644PA 0 C17 2 VCC 7 27 C XTAL2 AVCC VUSB C4 Y1 16MHz OVP VCC +5V 1 8 26 5 0 8 XTAL1 PC7 R0 1 1 R C16 0R82 C3 "EN" 9 25 R15
-
PDF
doc4779atr2406.pdf
GAUSSIAN PU_REG RAMP FILTER PU_TRX RAMP_OUT GEN PLL CTRL LOGIC RX_ON TX_ON nOLE CP REF_CLK TX_DATA VTUNE 2. Pin Configuration Figure 2-1. Pinning QFN32 - 5 × 5 A A L K A A R N B A C D D T E O N A L X X U O X E D C T R P n T 32 31 30 29 28 27 26 25 PU_REG 1 24 RX_ON REF_CLK 2 23 IC RSSI 3 22 IC VS_IFD 4 ATR2406
in „Gauss Anpassung Register“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
extended_serial_library.pdf
gewohnte Funktionen wie print und println ebenfalls verfügbar. extendedSerial wurde auf AVR-, STM- und CH32V003 Systemen getestet. Anmerkung zu CH32V003: Der Arduino-Core von CH32V003 ist in einigen Teilen noch fehlerbehaftet und im Falle von HardwareSerial sind nicht alle Funktionen komplett implementiert
in „Arduino und struct gefallen sich nicht !“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
910.asm
FLASH delay ;====== ':' - Universal Command ============================================ w19: cpi u_data,':' ; ':' Universal Command brne w20 rcall getc ; get data1 mov cmd1,u_data ; cmd1 = data1 rcall getc ; get data2 mov cmd2,u_data ; cmd2 = data2 rcall getc ; get data3 mov cmd3,u_data ; cmd3 = data3
in „avr910 programmer“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
CAMXTOOL_V3_5_Sch_rev0_.pdf
1 2 3 4 5 6 7 8 J? 1 2 3 4 X-MOT J? 1 2 3 4Y-MOT J? 1 2 3 4 Z-MOT R? R? R? R? R? R? GND GND GND GND GND GND 0.1 0.1 0.1 0.1 0.1 0.1 C? +24V C? C? +24V C? C? +24V C? 100u/35V 100u/35V 100u/35V 100u/35V 100u/35V 100u/35V GND C? 8 7 6 5 4 3 2 C? GND GND C? 8 7 6 5 4 3 2 C? GND GND C? 8 7 6 5 4 3 2 C? GND 2 2 2 2 2 2 2 5V 2 2 2 2 2 2 2 5V 2 2 2 2 2 2 2 5V 1u? 1u? 1u? 1u? 1u? 1u? D 0 0 0 D pad B E A C A E B R? pad B
in „Endstop CNC 3018 CAM TOOL v 3.5“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
millisek_demo.c
Protokoll: 8 Daten-, 1 Stopbit -------------------------------------------------- */ void uart_init(uint32_t baud) { uint16_t ubrr; if (baud> 57600) { baud= baud>>1; ubrr= (F_CPU/16/baud); ubrr--; UCSR0A |= 1<<U2X0; // Baudrate verdoppeln } else { ubrr= (F_CPU/16/baud-1); } UBRR0H = (uint8_t)(ubrr>>8); //
in „Arduino Zeitmessung mit externes Modul das ms messen kann?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AVR_Stamp_sheet_V1_1.pdf
26 26 RXD0 (XCK1)PD5 29 MREQ 27 27 TXD0 (ICP1)PD4 28 RD CLKO 28 28 RD (TXD1/INT3)PD3 WR WR (RXD1/INT2)PD2 27 29 29 (SDA/INT1)PD1 26 SDA 30 30 M1 25 SCL 31 31 MREQ (SCL/INT0)PD0 32 32 IORQ 9 CLKO C (CLKO/ICP3/INT7)PE7 C (T3/INT6)PE6 8 INT6 PINHD-1X32 PINHD-1X32 (OC3C/INT5)PE5 7 INT5 6 PE4 (OC3B/INT4)PE4
in „Z180-Stamp Modul“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Schematic.pdf
1 2 3 4 A A U1 10 PB0(SS) PA0 (AD0) 51 11 PB1(SCK) PA1 (AD1) 50 12 PB2(MOSI) PA2 (AD2) 49 13 48 14 PB3(MISO) PA3 (AD3) 47 15 PB4(OC0) PA4 (AD4) 46 16 PB5(OC1A) PA5 (AD5) 45 CON1 U2A 17 PB6(OC1B) PA6 (AD6) 44 PB7(OC2/OC1C) PA7 (AD7) 5 GND 1 2 18 TOSC2/PG3 9 19 TOSC1/1PG4 PC0(A8) 35 B 4 VCC SN74HCT04 PC1(A9) 36 B 8 25 PD0 (SCL/INT0) PC2(A10) 37 GND 10 3 U2B 26 PD1 (SDA/INT1) PC3(A11) 38 7 27 39 11 2 4 3 28 PD2 (RXD1
-
Datei
partlist.txt
100n C0805 rcl (30.1625 115.8875) R90 CON1 SCDA5A0201 SCDA5A0201 SCDA5A0201 (20.6375 30.48) R0 IC1 ATmega88-20P DIL28-3 atmel (37.465 50.165) R270 IC2 74S08D SO14 74xx-eu (18.0975 18.7325) MR90 IC3 FT232RL SSOP28 ftdichip (44.7675 21.59) R180 IC4 ATmega88-20P DIL28-3 atmel (20.32 99.695) R0 IC7 74AC08D
in „CP/M auf ATmega88“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
HCS-3602_schematics_opt.pdf
!OOuF ESID 3.3uH J 25V s +5V Cl I I 0.6SuF 275VAC + C27 CIO Ul 0.0luF C19 R33 IOOuF * * IR1150 s R22 R32 C20 PC!~ 120 6.3V RI R2 !SK 0.047uFI !SOK 4700pF IOV lLP781 s i 150K !SOK Rl3 1% 630V R29 * 630V I s s 100 750K I ('' s s 1% D C29 cl I RIO RI! Rl2 R14 Cl2 R23 ZD3 J IOOOpF/lKV Fl 0.1 0.1 0.1 130K O.OIUF 17.4K RJO 5.IV SA 2W 2W 2W 1% s 1% * 750K s s 1% -SV Q3 C2120 C13 + Cl4 0.22uF 22uF Input 200-240VAC C21 O.luF s NOTE: [) 1: ALL RESISTORS ARE
in „Manson HCS-3602 HCS-3600 Reparatur“ · Analoge Elektronik und Schaltungstechnik ·
-
PDF
AVR_Roboter_Dokumentation.pdf
s r ATMega 644-20PO Motorsteuerung CNY70 e c PWM über I²C S L RS232 Reflexlichtschranke CNY70 I²C Bus Motor 2 Uhr LED mit Fototransistor Stomversorgung über I²C Fernbedienung ISF471F / LD274 4* 1,2V Akku mit
in „Anfängerprobleme“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
fernvale-31c3.pdf
talk to give... Goals 1) Access the MT6260 as a microcontroller (e.g. cost-equivalent upgrade to ATMega328U) – GSM/BT is a tertiary goal 2) Create an open (by Western standards) hardware and software platform around the MT6260 Develop a legal methodology for pulling IP from the China ecosystem into the
in „After ESP8266 New Chip Alarm: MT6260 < 3 USD“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
PV-_berwachung.c
300); if(zahler<1) {zahler=3;} } switch (zahler) //Menü in Optionen { case 1: //Uhr einstellen if((u==1)||(u==2)) {ks0108FillRect(5, 19, 110, 41, WHITE); u=0;} ks0108GotoXY(15,25); ks0108SelectFont(SC, ks0108ReadFontData, WHITE); ks0108Puts_P(PSTR("Uhr")); ks0108GotoXY(15,45); ks0108SelectFont(SC, ks0108ReadFontData
in „externer Interrupt Problem“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Ender3_schematic.PDF
PI0TP1 Y-STOPP PI0TP0 Z-STOPP P030nF PC COC PI0TP2 PI0TP2 PI0TP0 ATMEGA1284P-AU 28 HP128-5.0-2P HP128-5.0-2P XH2.54-2A XH2.54-2A PC PC PC 100uF XH2.54-2A C55 XH2.54-2A C66 XH2.54-2A C77 VCC GND VCC PC GND PC4.7uF GND PC4.7uF GND PC4.7uF ISP MISO 1 2
in „Problem mit SD Card Melzi Creality3D V1.1.3 Sanguino Atmega 1284“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
problem.c
-------- zacwire.c-Datei // software-only implementation of the ZACwire(R) protocol #ifdef __AVR_ATmega644__ // ATMega644 supports pin change interrupt (ATMega32 does not) #include "zacwire.h" // globals volatile uint16_t ZACWIRE_Temperature; // current temperature volatile uint8_t ZACWIRE_Flag; // current
in „Interrupt-Problem (TSic und ZACwire)“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
uniflaechentaster.pdf
1 2 3 4 5 6 VCC VCC VCC VCC A A 2U? LDR_VCC MOSI 7 MISO C CSN 4 CSN ? 0 U? 2 P? MISO 6 V 8 C? C? R 1 1 R MOSI IRQ C 2 D SCK 5 SCK N CE 3 CE V 100nF L G 4.7uF 100nF ATSHA_SDA 1 SDA D LDR_IN 1NRF24L01 G C
in „Stromsparend Helligkeit messen“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
icecubev1.2-sch.pdf
R15 DCF / C4 C3 F 4 1 100V/33 F 0.1uF R 1 9 10 0.1uF 2 1 GND GND 2 D 5 0 VCC 150 150 10uF/25V 2 0 Q F D 6 GND BOOST I GND GND GND GND GND GND C C C C V Q3 D 0.1uF ZVP2106A N 2 G C VFDPWR R3 R8 LED_B +UB N 0.1uF RST 1 PC6(/RESET/PCI14) (PCI8/ADC0)PC0 23 150 G 1 (PCI9/ADC1)PC1 24 C N 22 AGND (PCI10/ADC2)PC2 25 TEMP 2 1 G 21h AREF (PCI11/ADC3)PC3 26 R6 N 031uF 20 AVCC (PCI12/ADC4/SDA)PC4 27 LED_R C G 1H 2 6 (PCI13/ADC5/SCL)PC5 28 150 V C BOUT0 26 C0 L 22pf 1 . WHLED1 k 1 V VOUT1 25 1 C9 Q 32 PB6(XTAL1
in „Röhrenuhr IV-18“ · Projekte & Code ·
-
Datei
irmp.c
GPIO_PinSource2 # define STM32_UART_AF GPIO_AF_USART2 # define STM32_UART_COM USART2 # define STM32_UART_BAUD 115200 // 115200 Baud # include "stm32f4xx_usart.h" #elif defined(ARM_STM32F10X) # define STM32_UART_COM
in „IRMP - Infrared Multi Protocol Decoder“ · Projekte & Code ·
-
Datei
irmp.c
GPIO_PinSource2 # define STM32_UART_AF GPIO_AF_USART2 # define STM32_UART_COM USART2 # define STM32_UART_BAUD 115200 // 115200 Baud # include "stm32f4xx_usart.h" #elif defined(ARM_STM32F10X) # define STM32_UART_COM
in „IRMP - Infrared Multi Protocol Decoder“ · Projekte & Code ·
-
Datei
main.c
Aktualisieren mit NE555 Rechteckgeber 5HZ Signal Duty-cycle ca 5% analog_IL=0; analog_IH=0; analog_U=0; analog_T=0; analog_IL=adc_read10bit(0,2); analog_IH=adc_read10bit(1,2); analog_U=adc_read10bit(2,2); analog_T=adc_read10bit(3,2); calc_U=analog_U*adc_10; lcd_gotoxy(3,1); lcd_puts(" "); if(analog_U==1023) { dtostrf( calc_U, 3, 1, s ); } else { dtostrf( calc_U, 3, 2, s ); } lcd_gotoxy(3,1); lcd_puts(s); lcd_puts("V"); if(analog_IL>=1020)//Wenn 1000mA Kanal am Maximum (mit Reserve) { calc_I=analog_IH*adc_10;//umschalten
in „ATMEGA 32 mit LCD - Probleme mit Interrupt INT0“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
RobotV220.asm
temp reti ;---------------------------------------------------------------------------------- Timer2_COM: ;-------------- Ultraschalltakt push temp ;Zähler 32 Bit ldi ZL,Low(US_Z32) ldi ZH,High(US_Z32) count32: ld temp,Z inc temp st Z+,temp sbrs ZL,2 breq count32 ;Servobewegung ldi temp,40 ;Servo in
in „Assembler Befehl BRLO“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
main.c
/*ATMega8*/ // avrdude -p m8 -c ponyser -P /dev/ttyS0 -U flash:w:main.hex -U lfuse:w:0xe0:m -U hfuse:w:0xd9:m #ifndef F_CPU #error F_CPU undefined #endif #define STR_HELPER(x) #x #define STR(x) STR_HELPER(x
in „AVR/GCC: pgm_read_byte funktioniert, pgm_read_word nicht?“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Tastatur.c
Alarmanlage sicherstellen Compiler: AVR Studio 4.14 Ersteller: Ranftl Version/Datum: 1.0 / 11/08 Hardware: ATMEGA32, AVR Dragon, Steckbrett Änderungen: ***********************************************/ #include <avr/interrupt.h> // include interrupt header #include <string.h> // include string header #include "LCD.h" // LCD-Header #include <avr\io.h> typedef unsigned char u8; typedef unsigned short u16; #define NOP(); asm volatile("nop"::); #define KEY_PIN PINC #define KEY_PORT PORTC #define KEY_DDR DDRC u8 keyscan( void ) { u8 col = 0, row = 0; //KEY_PORT = 0xFF; // all
in „4x4 Tastaturabfrage“ · Mikrocontroller und Digitale Elektronik ·
-
 Bild
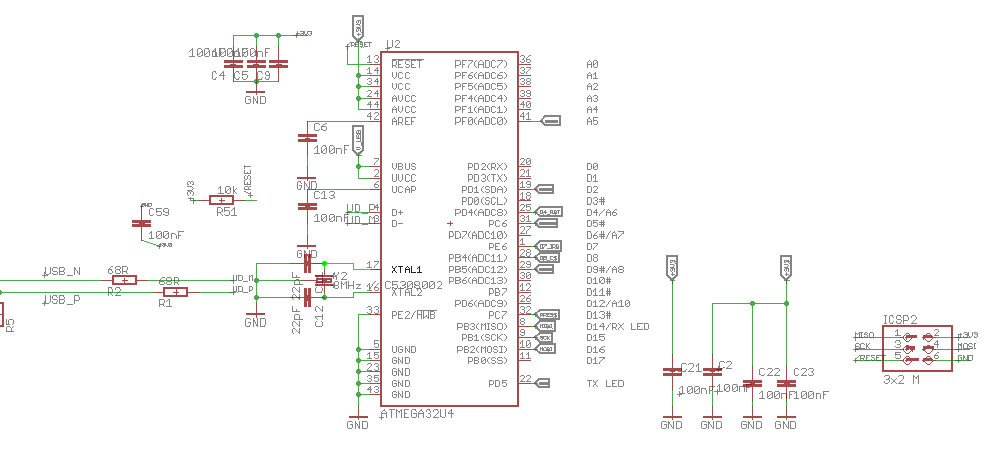
Schaltplan eines ATmega32U4 Mikrocontrollers
U2 ATMEGA32U4, C4 100nF, C5 100nF, C6 100nF, C9 100nF, C12 100nF, C13 100nF, C21 100nF, C22 100nF, C23 100nF, R1, R2, R51 10k, USB_N, USB_P, USB, VBUS, VCC, AVCC, AREF, GND, XTAL1, XTAL2, 16MHz, PD2(RX), PD3(TX), PD1(SDA), PD0(SCL), PC6, PC7, PB0(SS), PB1(SCK), PB2(MOSI), PD5, PF0 bis PF7, PD0 bis PD7, PC0 bis PC7, PB0 bis PB7, ICSP2, MISO, MOSI, RESET, SCK, GND, 3x2 M
in „ATMega32u4 unter Linux“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
PDF
DMX_Volume_Control.pdf
3 6 7 1 0 0 0 0 0 0 0 0 0 0 0 0 0 P0K106 P0K107 0 P 1 2 3 4 P P 1 2 3 4 P P ) 2 ) 4 )P P P DGND ( ( ( K1 1 0 1 ) ) ) ) ) ) ) ) E d E E 3 1 K 1 1 2 4 8 ( ( ( ( ( ( r e r r V3 0 30 1P 0 t t t t N N N N U d U U P 1P P8 n n n n U U 0 n 0 n 0 0 N u N N 0 6 7 K
in „Frage zu PGA2311 und SPI“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AtMega1284_Miniboard_SCH.PDF
Vraw VCC K3 K4 VCC 1 VCC 1 GND 2 GND 2 SCL SDA U 1 3 3 M C P 1 7 5 4 S T - 3 3 0 2 E / C B SDA 4 SCL 4 K2 MS5611 INA226 1 1G N D V I N 3 2 V O U T 2 3 4 EMPF VCC 2 F 2 n BASSER3 1 1 0 2 1 u C 1 C 1 2 2 TX1 2 2 2 , 1 , 2 R 1 4 R 1 4
in „Debuggen über JTAG Atmega1284p bricht mit Fehler ab“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
DOGM162W-A.asm
----------------------------------------------+ ; OCF2 - Output Compare Flag 2 ; TOV2 - Timer/Counter2 Overflow Flag 2 ; SFIOR - Special Function IO Register ................ ATMEGA8A Data Sheet P. 115 ; +-------------------------------------------------
in „DVM mit DOGM162W-A, ATMEGA8A, AVRASM“ · Projekte & Code ·
-
PDF
DMX_volume_control.pdf
P P P P P P P P P P P P P P0K106 P0K107 DGND 1 2 3 4 1 2 3 4 1 2 4 4 ) K1 1 ( ( ( 2 0 1 ) ) ) ) ) ) ) ) e e e V K P ( 2 ( 8 ( ( ( 2 ( 8 ( ( d d d r V3 P 1P 1 i i i i n n n n n n n 1 6 7 U U U U T T T T H H H V P0K206 P0K207 1N4148 P K2 1 2 K 0 K 3P 1P O E I ) ) ) ) 1 +5VDIG X T E T N D D t 2 t 8 t t M U U C S G N V n n n n i i RESET D M / M Z C D + U U U U 4 3 2 1 0 6 5 4 3 2 1 4 4 4 414 4 +5VDIG 1 1 V1 V2 0 1 P 0 3 2 1 0 1 P0V201616 B 0 ) 1 0 0 1 0 DP C0 001 203 0 ZCEN P0VZCEN VIN_L B P
in „PGA2310/CS3310 mit Bascom via SPI?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
DMX-vol.pdf
P P P P P P P P P P P P P P0K106 P0K107 DGND 1 2 3 4 1 2 3 4 1 2 4 4 ) K1 1 ( ( ( 2 0 1 ) ) ) ) ) ) ) ) e e e V K P ( 2 ( 8 ( ( ( 2 ( 8 ( ( d d d r V3 P 1P 1 i i i i n n n n n n n 1 6 7 U U U U T T T T H H H V P0K206 P0K207 1N4148 P K2 1 2 K 0 K 3P 1P O E I ) ) ) ) 1 +5VDIG X T E T N D D t 2 t 8 t t M U U C S G N V n n n n i i RESET D M / M Z C D + U U U U 4 3 2 1 0 6 5 4 3 2 1 4 4 4 414 4 +5VDIG 1 1 V1 V2 0 1 P 0 3 2 1 0 1 P0V201616 B 0 ) 1 0 0 1 0 DP C0 001 203 0 ZCEN P0VZCEN VIN_L B P
in „Digipoti fernsteuern“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
CPU_CONNECTORS.CE3.pdf
A B C D E F G H 2 of the 3 capacitors are direct at the processor pins (VCC and AVCC). +5V 3x 100n 1 20k 1 220u ISPCON 1 MISO VCC 2 1 3 SCL MOSI 4 2 3 5 6 4 RST GND 1 40 5 (XCK/T0) PB0 PA0 (ADC0) 6 2 39 7 (T1) PB1 PA1
in „10stelliges 7-Segment DRO für WABECO Messschieber“ · Projekte & Code ·
-
 Bild
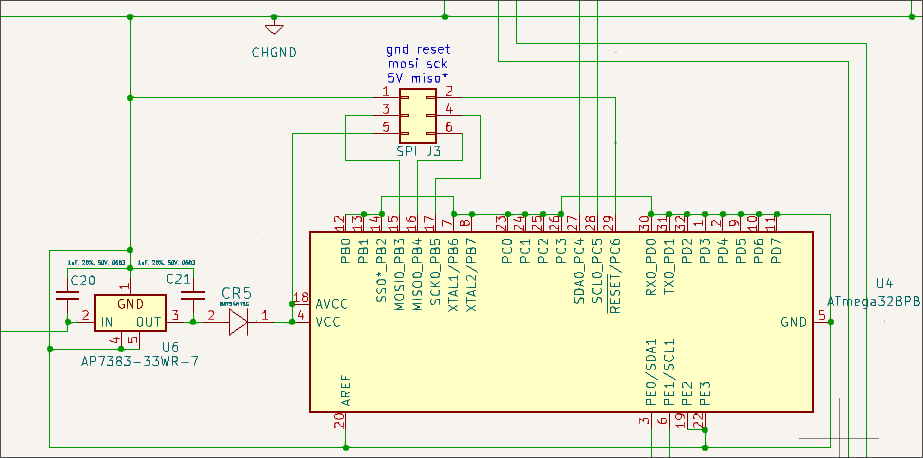
Schaltplan mit ATmega32BP Mikrocontroller
gnd, reset, mosi, sck, 5V, miso, SPI J3, PB0, PB1, SS0, MOSI0, PB3, MIS0, PB5, SCK0, XTAL1/PB6, XTAL2/PB7, PC0, PC1, PC2, PC3, PC4, SDA0, SCL0, PC5, RESET/PC6, PD0, TXD0, PD2, PD3, PD4, PD5, PD6, PD7, U4 ATmega32BP, GND, PE0, PE1, PE2, PE3, C20, C21, CR5, U6 AP7383-33WR-7, GND, IN, OUT, VCC, AVCC, AREF
in „Atmega 328PB lässt sich nicht programmieren“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
PDF
atmega_fusebit_doctor_V2h_schematic.pdf
1 2 3 4 5 6 7 8 9 A A V 10K T1 BC557 R2 +12V 1K 2 100 + R3 T2 BC547 R24 1K B R4 B 4K7 GND C V T3 BC557 IC1 LED2n 4K7 + 7805 C +5V 2 R6 +5V 5 V V 2 1 2 3 2 + X1-2 IN OUT J R + + R25 C1 GND C2 C3 R5 100 100uF 10uF 10nF red 330 X1-1 GND LED1 E R27 1 A VCC 10K J E GND GND GND 1 2 C IC3 C GND 2 9 33 S1 R26 GND + RESET (ADC7)PA7 34 START 1K ATMEGA8-DOC (ADC5)PA5 35 3 1 DATA 12 XTAL2 (ADC4)PA4 36 4 2 1 PC6(/RESET)
in „Gibt's ein Gerät zum RSTDISBL zurücksetzen?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Schematic_Atmega_1284p_Mini_Lora_2021-11-18.pdf
1 2 3 4 5 TP4056 SOLAR Optional Laderegler SOLAR AKKU HDR-M-2.54_1x2 HDR-M-2.54_1x2 HDR-M-2.54_1x2 4 VCC BAT 5 1 1 1 2 2 2 C13 VCC-IN 8 CE 9 10uF EP A CHRG A 7 CHRG# TEMP 1 C8 10uF 6 STDBY# PROG 2 D N R1 G 1.2K 3 GND SPANNUNGSREGLER U1 B ATMEGA1284P-AU B 1 44 VCC MOSI 2 PB5(PCINT13/MOSI) PB4(SS#/OC0B/PCINT12) 43 PB4 U2 MISO 3 PB6(PCINT14/OC3A/MISO) PB3(AIN1/OC0A/PCINT11) 42 PB3 HT7333-A SCK 4 PB7(PCINT15/OC3B
in „Hilfe bei Schaltplan 1284p, Mosfet usw, MCU neustart“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
fft3.asm
Y+, _0 ;/ dec CL brne ms_l1 ret do_fft: ; Execute butterfly operations (not optimized) ldi XH, 1 ;u ldi EL, FFT_N/2 ;l df_l1: ldiw Z, BflyBuf ;Z = BflyBuf ldiw Y, BflyBuf ;Y = BflyBuf + l * 4 muli EL, 4 ; addw Y, T0 ;/ mul AL, XH ;T10L = u * 4 mov T10L, T0L ;/ mov XL, XH ;w = u df_l2: clr T14L ;p=0
in „Schnelle FFT in Assembler“ · Digitale Signalverarbeitung / DSP / Machine Learning ·
-
Datei
Schrittmotor.asm
Marke +- MEprom: .byte 1 ;Marke, ob ein Programm aus dem EEPROM geladen wurde PWMAdr1: .byte 1 PWMAdr2: .byte 1 Motb: .byte 3 ;Motor Betrieb - Schritte/U Moth: .byte 2 ;Motor Betrieb - Schritte/U / 100 Bmot: .byte 1 ;derzeitiger Motor Betriebsart .org 0x0200-32 ;Anfangsadresse Puffer Serielle Schnittstelle
in „Spielerei mit einem 2- und 5-Phasen-Schrittmotor“ · Projekte & Code ·
-
PDF
CPU_CONNECTORS.CE3.pdf
A B C D E F G H 2 of the 3 capacitors are direct at the processor pins (VCC and AVCC). +5V 3x 100n 1 20k 1 220u ISPCON 1 MISO VCC 2 1 3 SCL MOSI 4 2 3 5 6 4 RST GND 1 40 5 (XCK/T0) PB0 PA0 (ADC0) 6 2 39 7 (T1) PB1 PA1
in „10stelliges 7-Segment DRO für WABECO Messschieber“ · Projekte & Code ·