
-
Datei
24Sender.c
uart */ USART_Init(MYURBB); /* simple greeting message */ uart_write("\r\n> TX device ready\r\n"); /* uart_write("send_complete?\r\n"); itoa(var,itoabuffer,10); uart_write(itoabuffer); uart_write("\r\n"); */ /* init hardware pins */ nrf24_init(); /* Channel #2 , payload length: 4 */ nrf24_config(2,4); /* Set the device addresses */ nrf24_tx_address(tx_address); nrf24_rx_address(rx_address); while(1) { /* Fill the data buffer */ data_array[0] = 0x00; data_array[1] = 0xAA; data_array[2] = 0x55;
in „NRF24L01 und Atmega328P“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
TEM_uni_5_adc_stream_bench.vhd
std_logic; AD7356_12_SDO_A: in std_logic; AD7356_12_SDO_B: in std_logic; AD7356_34_nCS: out std_logic; AD7356_34_SCK: out std_logic; AD7356_34_SDO_A: in std_logic; AD7356_34_SDO_B: in std_logic; AD7356_56_nCS: out std_logic; AD7356_56_SCK: out std_logic; AD7356
in „Wie Clockdomain crossing für FT232H, wie debuggen?“ · FPGA, VHDL & Co. ·
-
PDF
pic-PIC-Logger.pdf
- Test Versuch 1: +5V 4 Gnd Pic 12F675 ADC 0....5 Dreh-poti 0...5 Volt Versuch 2: +5V Gnd Rx Pic 12F675 Tx ADC Dreh-poti 0...5 Volt 2 4 Pic 18 F xxx PIC Projekt: PIC Sensor 1 +12V +5V Gnd Rx Gnd Pic 12F675Tx ADC 2 Dreh-poti 0...5 Volt 2 4 x Pic 18 F xxx PIC Projekt: PIC Logger SD mit Sensor 1 +12V +5V Gnd Rx Gnd Pic 12F675Tx ADC 2 Dreh-poti 0...5 Volt 2 4 x Pic 18 F xxx SD 1G
in „PIC 12F675 + ADC-Eingang +Code +Dresden“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
eBusLoggerV2.pdf
3,3V PB6 (XTALPB5 SCK GND PB7 (XTALPB4 MISO VCC K1 K K K DI C3 PD5 PB3 MOSI RESET 3 3 3 CS g PD6 PB2 SS SCK MISO 22PF MQ1 PD7 PB1 MOSI R R R K2 C4 1 PB0 ATMEGA8(DIL28S) 1 VCC 2 Reset 22PF 3 SCK 4 MISO 5 MOSI 6 GND SD Karte Interface VDD 0 K KL2 LTC485CN8 R 0 GND DI 1 IC2a A DE - R14 B RE K eBusTX VCC RO vBusTx 1 3 + 10K R 1 , K VBus 100nF IC5 LM358N D D 1 , VCC P R 4 D4 Z C11 R12 R13 eBUS+ vBus RS485 - RS232 2,21K 100K 1N41486 1 0 R optional eBus Pegelwandler +5V VCC +3,3V VSS IC4 KL1 B250C1500 ~BR2 F IN DOUT
in „ebus protokoll mitschnitt bei einem Wolf Heizkessel“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
tbf5030_c3a_3.c
UBRR0L); /* set baud rate */ //outp( 103, UBRR0L); /* set baud rate */ //init_eep(); /* enable RxD2/TxD2 and interrupts */ outp(0x0, UCSR1A); //outp(BV(RXCIE)|BV(TXCIE)|BV(RXEN)|BV(TXEN), UCSR1B); outp(0x98, UCSR1B); //Œ³Á€È®œÇÈ÷ ÇÒ°Í???? //outp(0x86, UCSR1C); outp(0x86, UCSR1C); outp( 0x0, UBRR1H)
in „Fehler beim Compilieren“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
landtiger_v2.0_-_manual__v1.1.pdf
16 RS485 interface description CN10 Pin Description IO Pin 1 485A UART3_TX (P4.28) 2 485B UART3_RX (P4.29) IO Pin Description Comment P4.28 485_TX P4.29 485_RX P2.8 485_DIR TX/RX Direction (RX is active low, TX is active high) Note1: The 458A and 458B inputs/outputs are terminated
-
PDF
PIC18f6622.pdf
priority over port data. 1 I ST ECCP3 capture input. P3A 0 O DIG ECCP3 Enhanced PWM output, channel B. May be configured for tri-state during Enhanced PWM shutdown events. Takes priority over port data. RG1/TX2/CK2 RG1 0 O DIG LATG<1> data output. 1 I ST PORTG<1> data input. TX2 0 O DIG Asynchronous
in „PIC 18F6622 Zeit um EEPROM zu schreiben“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „UART Auswertung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „µC rechnet falsch oder ich finde den Fehler nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „ATmega UART spinnt“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „avr dude Programm zu groß? Eclipse GCC“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
i2cdem0_test.c
DEV_ADDR 0x50 #define baud_rate 9600 #define baud FOSC/16/baud_rate-1 void usart_init(unsigned int b_rate) { UBRR0H=0x00; UBRR0L=0x00; UCSR0B=0x00; UCSR0C=0x00; UDR0 =0x00; UBRR0H =(unsigned char)b_rate>>8; UBRR0L =(unsigned char)b_rate; UCSR0B = ( (1<<RXEN0) | (1<<TXEN0) ); UCSR0C = ( (1<<UCSZ00) |
in „I2C Atmega328p als Master und 24LC256 EEPROM IC als slave“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „UART mit Atmega8 (Peter Fleury Library)“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „AVR bootloader Probleme“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „UART Bibliothek funktioniert nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „AVR Bootloader in C - Artikel“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
WC_MiniDev_Shield_v6.pdf
+ 5 + verwendet wird verwendet wird + B10 A3 + (R9, R10, R11, D1, D2, Q1, T1) + 0 R13 RESET TX Dann werden Drain und Source R 1 LM358N 5 0 ADC RX A2 von T1 gebrückt. 3 9 8 2 R 1 10k B3 CH_PD GPIO5 7 0 3 R R 1 A B8 1 JP3 GPIO16 GPIO4 BOOT0
-
Datei
startup_stm32f10x_cl.s
_TX_IRQHandler .word CAN2_RX0_IRQHandler .word CAN2_RX1_IRQHandler .word CAN2_SCE_IRQHandler .word OTG_FS_IRQHandler .word 0 .word 0 .word 0 .word 0 .word 0 .word 0 .word 0 .word 0 .word 0 .word 0 .word
in „STM32 Rücksprung defekt von IRQ“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
603A.pdf
, 08h[4:0]= 0 1110) XSEL= 1 or 2: P2[12:0]= 670 (=0 0010 0101 1111b) (07h[7:0]= 0101 1111, 08h[4:0]= 0 0010) Minimum value: XSEL= 0 or 3: P2[12:0] = 3702 (=0 1110 0111 0110b) (07h[7:0]= 0111 0110, 08h[4:0]= 0 1110) XSEL= 1 or 2: P2[
in „[AVR] FM-Transmitter für 1,50EUR --> Ansteuerung?“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
KSZ8851SNL_DEMO_BOARD_Schematic_V1.1.pdf
SO8 U5 B FB4 MIC5209YM B 1 2 2 3 IN OUT RXP1 1 6 RXM1 C22 FBEAD 1 4 R25 . . D2 + C23 EN N N N N ADJ LED3 T C29 G G G G 1.50K C24 220 RX1P RX1M A 1 2 1 . . 2 T47uF 0.1uF + 5 6 7 8 + C25 R26 Power 3.3V 22uF C26 R27 N0uF 0.1uF (red LED) GND 2 GND VR 5 3.3VA GBLC03C_0 T VDD 470pF 2.49K ON: EEPROM present D3 EED_IO 1 JP2 2 R28 4.7K TX1P 1 2 TX1M VOUT = 1.24 X [ 1 + ( 2.49k/ 1.5K ) ] . . TXP1 TXM1 3 . . 4 VDD GBLC03C_0 Vin_5.0V Strapping Options
in „KSZ8851 Ethernet komplizierte Frage.“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
Neues_Textdokument__2_.txt
------------------------------------------------*/ SPI_InitStructure.SPI_Direction = SPI_Direction_2Lines_FullDuplex;//SPI_Direction_2Lines_FullDuplex; //SPI_Direction_1Line_Tx; SPI_InitStructure.SPI_Mode = SPI_Mode_Master; SPI_InitStructure.SPI_DataSize = SPI_DataSize_16b; SPI_InitStructure.SPI_CPOL
in „SPI -> STM32F100RB; ich finde den Fehler nicht.“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
RF02_code_en.pdf
wireless alarm, wireless sensor, wireless keyboard/mouse, home-automation and wireless data collection. 2. Commands 1. Timing diagram 2. Configuration Setting Command bit 15 14 13 12 11 10 9 8 7 6 5 4 3 2 1 0 POR 1 0 0 b1 b0 d2 d1 d0 x3 x2 x1 x0 ms m2 m1 m0 8080h b1..b0: band select: b1 b0 band[MHz] 0 1
in „Datenübertragung mit Funkmodul RFM01-RFM02“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
top.ucf
tx2_n" LOC = "P6" | IOSTANDARD = LVDS_33; # Bank = 2, Pin name = IO_L64N_D9, Sch name = JA-D2_N NET "tx2_p" LOC = "N5" | IOSTANDARD = LVDS_33; # Bank = 2, Pin name = IO_L64P_D8, Sch name = JA-D2_P NET "
in „LVDS Display per Spartan 6 ansteuern“ · FPGA, VHDL & Co. ·
-
PDF
B154EW04_VB.pdf
(National semiconductor) ( Computer side ) (TFT-LCD side ) DS90C*363 DS90CF364 6 TxIN 0~ 5 RXIN0+(6) RxOUT0~5 6 R0~R5 R0~R5 6 TxIN 6~11 RXIN0-(5) RxOUT6~11 6 G0~G5 G0~G5 6 TxIN12~17 RXIN1+(9) RxOUT12~17 6 B0~B5 D T B0~B5 L T O RXIN1-(8) E s r L L i l TxIN18 E RXIN2+(12) R RxOUT18 u r Hsync L P Hsync i t TxIN19 R RXIN2-(11) O RxOUT19 c o Vsync P - Vsync a C L D n TxIN20 T L RxOUT20 e ENAB ENAB t RXCLKIN+(1) I TxCLK IN RxCLK OUT CLK PLL RXCLKIN-(14)(14) PLL CK B154EW04 V.B Page /23 4-3. Backlight driving
in „Notebookdisplay als "normalen" Bildschirm verwenden“ · PC Hard- und Software ·
-
Datei
ch557.h
bUEPn_TX_EN & bUEPn_BUF_MOD: USB endpoint 1/2/3 buffer mode, buffer start address is UEPn_DMA // 0 0 x: disable endpoint and disable buffer // 1 0 0: 64 bytes buffer for receiving (OUT endpoint) // 1 0
in „uC für 0,20€ CH552 / CH554 von WCH Billig Micro mit USB Funktion, Chip vorstellung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
Koppler_Platine.pdf
U$6 VCC_A Vdd1 Vdd2 VCC_B Vi 0.1 uF Vo C8 501568-0409 VCC_B _ GND1 GND2 X1 D 15 pF0.1 uF Vcc X2 B G FOD0710 A Rx X3 D C5 C6 D Tx X4 N N GND G G U$2 U$3 _ _ X4 GND N N X3 Tx G 0.1 uF 15 pF A G X2 Rx FOD0710 D X1 Vcc C10
in „Schaltung mit Optokoppler FOD0710“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
iotn841.h
#define TOV1 0 #define OCF1A 1 #define OCF1B 2 #define ICF1 5 #define TIMSK1 _SFR_IO8(0x0F) #define TOIE1 0 #define OCIE1A 1 #define OCIE1B 2 #define ICIE1 5 #define TIFR2 _SFR_IO8(0x10) #define TOV2 0 #define OCF2A 1 #define OCF2B 2 #define ICF2
in „Neue ATtinies 441 und 841“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
arm.pdf
4 6 8 9 8 6 6 74 8 4 0 GND 10n B1 CR1632FH GND 1 6 7 8 1 1 1 1 1 1 2 8 1 3 2 2 2 1 3 4 1 2 4 3 8 ) ) ) ) ) ) ) ) ) ) ) ) ) 134 TRST 3 3 3 3 3 3 3 3 3 3 3 3 3 A E D P2.8 / TD2 / TXD2 / TRACEPKT3 GND 6 5 4 TDI ( 3(3(3 ( 3(3(3 ( 3( ( (
in „LPC2468 External Memory Controller Frage“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
RasperryPI_CAN-S.pdf
MISO 21 22 IN_I 22 21 B SCK 23 24 CS0 24 23 B 25 26 IN_J 26 25 27 28 28 27 ENC_A 29 30 30 29 ENC_B 31 32 IN_F 32 31 ENC_PUSH 33 34 34 33 IN_A 37 38 IN_E 38 37 IN_B 39 40 IN_D 40 39 IN_C X1 X2 GND GND GND GND +5V 1 7 R C C R4 60R R8 +3V3 60R C5 k 9 1 R 3k3 2k2 4n7 k N R 1 G R5 R6 IC1 D 100k IC2 GND GND Q1 2 RXCAN TXCAN 3 N 5 RS CANH 6 CANH 2 10MHz 8 CLKOUT/SOF 4 G R3 VREF CANL CANL 3 OSC1 TX0RTS 5 1 4 +5V 7 TX1RTS 6 TXD RXD A A X3 D OSC2 TX2RTS 11 3 B B
in „MCP2515 CAN-Bus Modul“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
BC04_Manual.pdf
19.0 mA Standby Host connection - 38.4 40 µA Function Diagram PDFmyURL.com Schemetic File:BLK-MD-BC04-B DEMO schematic.pdf PDFmyURL.com Dimension PDFmyURL.com BC04-A Basic Connection To computer 1. Convert TTLlevel RS232 2. Module power supply 3.3 V 3. TX and RX connected to RX and TX To other devices 1. TX and RX connected to RX and TX 2. Module supply 3.3V Module into the AT test methods 1. Module power supply 3.3 2. Open HyperTerminal or other serial debugging tools 3. Open HyperTerminal or other serial
in „HC-06 / HC-05 Bluetooth Modul“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
t.c
APB2 peripheral clock for USART1 * note that only USART1 and USART6 are connected to APB2 * the other USARTs are connected to APB1 */ RCC_APB2PeriphClockCmd(RCC_APB2Periph_USART1, ENABLE); /* enable the peripheral clock for the pins used by * USART1, PB6 for TX and PB7 for RX */ RCC_AHB1PeriphClockCmd(RCC_AHB1Periph_GPIOB, ENABLE); RCC_AHB1PeriphClockCmd(RCC_AHB1Periph_GPIOA, ENABLE); /* This sequence sets up the TX and RX pins * so they work correctly with
in „STM32F405 clocktree und USART“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
AFu-Selbstbau.pdf
ZF von 2,7 bis 3,2 MHz. Auf der 2.ZF von 455kHz werkeln ein mechanisches Filter von Kokusai mit 2,1kHz Bandbreite für SSB und ein sehr steilflankiges Doppelbrücken-Filter mit 4 FT241-Quarzen und 200Hz Bandbreite
-
Datei
Bootloader230.a51
inc DPTR movc A, @A+DPTR cjne A, #0xFF, ROM_F92B ROM_F8FE: ; mov A, CHIP_ID ;if (CHIP_ID != 0x57)//there is no ch557 at WCH xrl A, #0x57 ;{ jz Init_key clr A mov USB_CTRL, A ; mov DPTR, #0x2447 ; UEP2_3_MOD = bUEP2_RX_EN | bUEP2_TX_EN mov A, #bUEP2_RX_EN or bUEP2_TX_EN ; movx @DPTR, A clr A inc DPTR ; UEP0_DMA= &EP0_BUFFER; movx @DPTR, A ; inc DPTR ; movx @DPTR, A mov DPTR, #0x244C ; UEP2_DMA= = &EP2_BUFFER movx @DPTR, A ; inc DPTR mov A, #low EP2_BUFFER
in „uC für 0,20€ CH552 / CH554 von WCH Billig Micro mit USB Funktion, Chip vorstellung“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
howto_-tasmota-sml.pdf
den Fall, dass eine Sendediode von nöten ist, muss diese deklariert werden. +1,3,o,0,9600,OBIS,1,10,2F3F210D0A Nach dem Zählernamen “OBIS” wird der TX GPIO angegeben (Der Pin an dem die Sendediode hängt)(1). 10 gibt die Verzögerung der Sendesequenz an. Sie wird mit 100ms multipliziert. 2F3F210D0A ist
in „Wärmezähler über optische M-Bus-Schnittstelle auslesen“ · Haus & Smart Home ·
-
PDF
H616_JC_6Z_V1_2_MCU.pdf
PA0/WKUP/USART2_CTS(8)/ADC123_IN0/TIM2_C PD9/_FSMC_D14//USART3_RX C55 V3 13 MC_K_FAN1 24 PA1/USART2_RTS(8)/ADC123_IN1/TIM5_CH2/TI PD8/_FSMC_D13//USART3_TX 55 LCD_D6 MC_K_FAN2 25 PA2/USART2_TX(8)/TIM5_CH3/ADC123_IN2/
in „Induktiver Näherungsschalter tauschen Probleme“ · Analoge Elektronik und Schaltungstechnik ·
-
Datei
tft-lcd-controller-Overview-OpenCores.html
DevTools/MultiICE.html</a> (RealView Multi-ICE) <br> - <a href="https://www.arm.com/pdfs/DUI0048F_MICE2_2.pdf" target="_blank">http://www.arm.com/pdfs/DUI0048F_MICE2_2.pdf</a> (Multi-ICE User Guide) <br> - <a href="https://www.arm.com/pdfs/DUI0154B_MICE_2_2_TapOp.pdf" target="_blank">http://www.arm.com
in „Universal LCD+Input Modul mit MachXO2“ · FPGA, VHDL & Co. ·
-
PDF
Arduino_-_PinMapping2560.pdf
PinMapp2560.zip) Arduino Mega 2560 PIN mapping table Pin Number Pin Name Mapped Pin Name 1 PG5 ( OC0B ) Digital pin 4 (PWM) 2 PE0 ( RXD0/PCINT8 ) Digital pin 0 (RX0) 3 PE1 ( TXD0 ) Digital pin 1 (TX0) 4 PE2 ( XCK0/AIN0 ) 5 PE3 ( OC3A/AIN1 ) Digital pin 5 (PWM) 6 PE4 ( OC3B/INT4 ) Digital pin 2 (PWM)
in „3D Drucker zum Laserengraver umbauen?“ · Mechanik, Gehäuse, Werkzeug ·
-
Datei
fft_sin_rect.m
rectArt) case "b2" sinRect(i)= 0; %Einweggleichrichter case "b4" sinRect(i)= -sinus(i); %Brueckengleichrichter otherwise sinRect(i)= sinus(i); %Ohne end %switchEnd else sinRect(i) = sinus(i); end end %===============
in „Signalabtastung“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
image2c.c
anz-3; i += 3) { if ( !(cnt % worprow )) { fprintf(cfile,"\n "); } r= buffer[i+0]; g= buffer[i+1]; b= buffer[i+2]; rgb565= rgbfromvalue(r, g, b); // vh= rgb565 >> 8; vl = rgb565 & 0xff; fprintf(cfile,"0x%.4x, ", rgb565); cnt++; } r= buffer[anz-1]; g= buffer[anz-2]; b= buffer[anz-3]; rgb565= rgbfromvalue
-
PDF
Rollix_Core_SRAM.pdf
Gnd (AD7) PA7 44 MA7 MA7 MAD7 CAP 22P NPO 1206 X2001 (A8) PC0 35 MA8 MA8 MA8 CRYSTAL 16MHZ M23ROXTAL2 (A9) PC1 36 MA9 MA9 MA9 R2010 R 4K7 KS 24 37 MA10 MA10 R2011 R 4K7 KS C2007 25 XTAL1 (A10) PC2 38 MA11 MA11 MA10 RxD_DEBUG Gnd 26 PD0 (SCL/ INT0) (A11) PC3 39 MA12 MA12 MA11 B TxD_DEBUG CAP 22P NPO 1206 27 PD1 (SDA / INT1) (A12) PC4 40 MA13 MA13 MA12 B RxD_BT PD2 (RXD1 / INT2) (A13) PC5 MA13 TxD_BT 28 PD3 (TXD1 / INT3) (A14) PC6 41 MA14 MA14 MA14 IRIN 29 PD4 (ICP1) (A15) PC7 42 MA15 MA15 MA15 LCD_#RD 30 PD5 (XCK1) EX_CLK 31 PD6 (T1) MA[0..15] 2 4 32
in „Externes SRAM Problem:“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
PCM9574.pdf
bit TFT 36-bit TFT PD0 LD0 R5 R7 Ro5 PD1 LD1 R4 R6 Ro4 PD2 LD2 R3 R5 Ro3 PD3 LD3 R2 R4 Ro2 PD4 LD4 G5 G7 Go5 PD5 LD5 G4 G6 Go4 PD6 LD6 G3 G5 Go3 PD7 LD7 G2 G4 Go2 PD8 UD0 B5 B7 Bo5 PD9 UD1 B4 B6 Bo4 PD10 UD2 B3 B5 Bo3 PD11 UD3 B2 B4 Bo2 PD12 UD4 R1 R3 Re5 PD13 UD5 R0 R2 Re4 PD14 UD6 G1 G3 Re3 PD15 UD7 G0 G2 Re2 PD16 B1 B3 Ge5 PD17 B0 B2 Ge4 PD18 R1 Ge3 PD19 R0 Ge2 PD20 G1 Be5 PD21 G0 Be4 PD22 B1 Be3 PD23 B0 Be2 PD24 Ro1 PD25 Ro0 PD26 Go1 PD27 Go0 PD28 Bo1 PD29 Bo0 PD30
in „16 Pin Postenstecker auf 15pol-Sub-D (Advantech PCM 9574)“ · PC Hard- und Software ·
-
 Bild
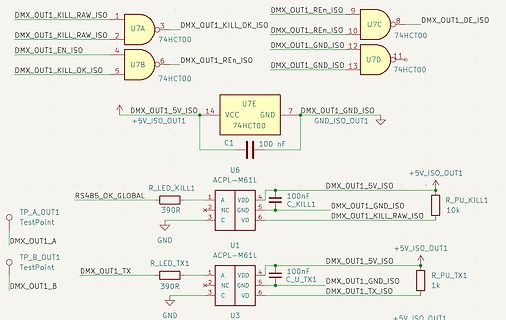
Schaltplan eines elektronischen Teils mit Logikgattern und Isolatoren
DMX_OUT1_KILL_RAW_ISO 1, U7A, 3, DMX_OUT1_KILL_OK_ISO, DMX_OUT1_RE_ISO 9, U7C, B, DMX_OUT1_DE_ISO, DMX_OUT1_KILL_RAW_ISO 2, U7B, 6, DMX_OUT1_REN_ISO, DMX_OUT1_EN_ISO 4, 74HCT00, DMX_OUT1_KILL_OK_ISO 5, U7D, 11, DMX_OUT1_GND_ISO 12, DMX_OUT1_GND_ISO 13, U7E, 14, VCC, GND, 7, DMX_OUT1
in „Artnet-DMX-Node mit 2× DMX Out + 1× DMX In, komplett galvanisch getrennt - gibt es ähnliche Projekte“ · Mikrocontroller und Digitale Elektronik · · Schaltpläne
-
PDF
BluePillPlus_V10_SchDoc.pdf
1 2 3 4 5 6 7 8 3.3V BOOT0 CO1B2 P T R11 CO B GND PID10K PID10A PI12 PI11 PB2 R2 R3 V CO1 1K NC SWW1 GND PI32 PI31 GND PC0 PI10 GND P1PIW11 PIS10 蓝灯 0603 KECOW2 2 PIS10 10KΩ 2 1 100nF CD2 R4 1 3 PIW12 PPS
in „BluePill STM32 Bezugsquelle“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
uart.h
circular buffers * for buffering received and transmitted data. * * The UART_RX_BUFFER_SIZE and UART_TX_BUFFER_SIZE constants define * the size of the circular buffers in bytes. Note that these constants must be a power of 2. * You may need to adapt this constants to your target and your application by
in „AVR Bootloader in C, geht mit mega8 nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
OPS_ATMEGA8.asm
0x00 rjmp RESET ; Reset Handler rjmp EXT_INT0 ; IRQ0 Handler rjmp EXT_INT1 ; IRQ1 Handler rjmp TIM2_COMP ; Timer 2 Compare Handler rjmp TIM2_OVF ; Timer 2 Overflow Handler rjmp TIM1_CAPT ; Timer 1 Capture Handler rjmp TIM1_COMPA ; Timer 1 CompareA Handler rjmp TIM1_COMPB ; Timer 1 CompareB Handler
in „AtMega8 - ret geht manchmal nicht“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
rs485.c
/ //////////////////////////////////////////////////////////// // Aktivierung Ports etc. // RCC_APB2PeriphClockCmd(RCC_APB2Periph_GPIOA, ENABLE); // Port A RCC_APB2PeriphClockCmd(RCC_APB2Periph_GPIOB, ENABLE); // Port B RCC_APB2PeriphClockCmd(RCC_APB2Periph_GPIOC, ENABLE); // Port C RCC_APB2PeriphClockCmd
in „STM32 Tutorial“ · Mikrocontroller und Digitale Elektronik ·
-
Datei
avreth-netlist.txt
between ICs sorted by IC pins of each IC / Connector - = not connected | AT ENC 10 FL 5 1 7 1 5 PB5 MOSI 2 6 8 1 PB6 MISO 3 8 2 4 PB7 SCK 4 3 -Reset (PullUp) 5 Vdd 9 56 Vcc +3.6 6 Vss 2 7 2 Gnd 7 XTAL2 (Xtal+C) 8 XTAL1 (Xtal+C) 9 8 PD0 RxD (Camera TxD) 10 10 PD1 TxD (Camera RxD) 11- PD2 Int0 12 4 PD3 Int1
in „winziger Webserver mit enc28j60+mega32“ · Mikrocontroller und Digitale Elektronik ·
-
PDF
0b-esp8266_system_description_en.pdf
1. ESP8266EX Specifications Categories Items Parameters Standard FCC/CE/TELEC/SRRC Protocols 802.11 b/g/n/e/i Frequency Range 2.4G ~ 2.5G (2400M ~ 2483.5M) 802.11 b: +20 dBm 802.11 g: +17 dBm Tx power Wi-Fi 802.11 n: +14 dBm 802.11 b: -91 dBm (11 Mbps) Rx Sensitivity 802.11 g: -75 dBm (54 Mbps) 802.11
in „Wassermelder mit ESP8266 realisieren“ · Mikrocontroller und Digitale Elektronik ·
